Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 43kg94.8lbOur conversion from 43 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking not stated
- Runtime A 120minWarning: load condition not stated
- Max speed A 6km/h3.73mphOur conversion from 6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (2)
Runtime
Caveat Walking figure used (no carried-weight load is given). The producer separately states 4 hours for standing and 1.5 hours to charge.
Max speed
Caveat From marketing text describing sustained walking speed, not the specification table: "Maintaining a steady running pace of 6 km/h; all-terrain speedy walking."
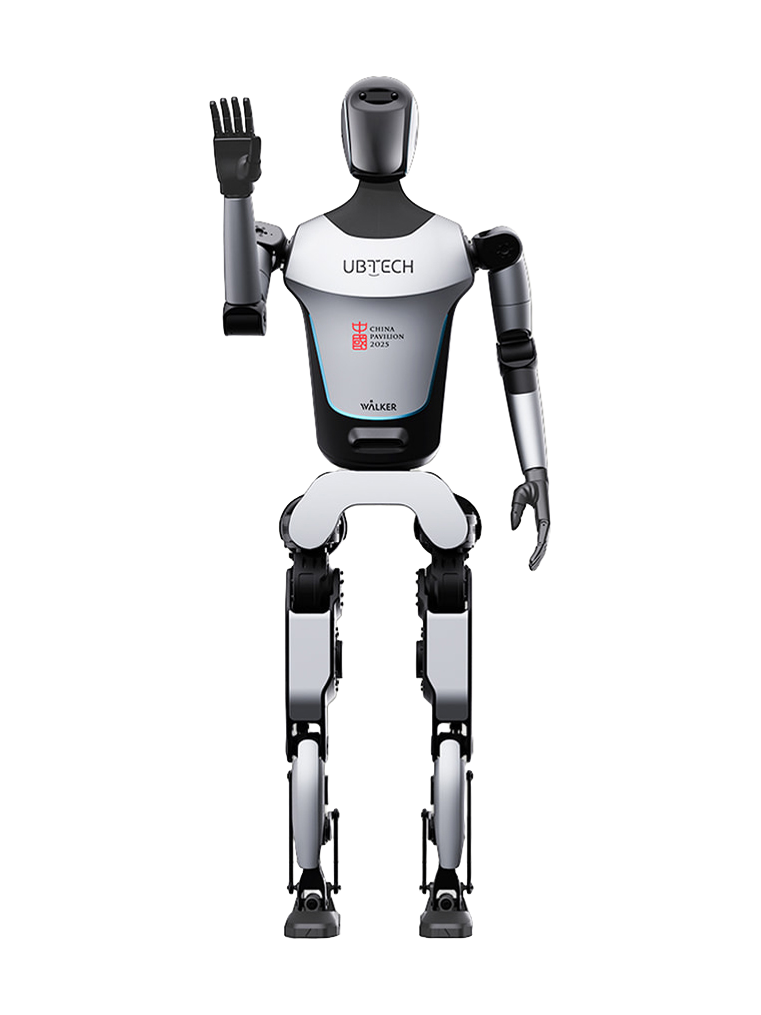
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
deliver intelligent interactive entertainment experiences
Source: ubtrobot.com · Retrieved
This category is not our assessment.
Full specifications
8 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 43kg94.8lbOur conversion from 43 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Length | not stated | |
| Width | not stated | |
| Height | 163cm64.2inOur conversion from 163 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Degrees of freedom | 20DoF | Note Given as a single total, with no per-limb breakdown. A |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | 6km/h3.73mphOur conversion from 6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat From marketing text describing sustained walking speed, not the specification table: "Maintaining a steady running pace of 6 km/h; all-terrain speedy walking." A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | 720Wh | Note Not stated in Wh: the producer gives "Lithium Battery 48V 15Ah", and 48 V x 15 Ah = 720 Wh. A |
| Runtime | 120minWarning: load condition not stated | Caveat Walking figure used (no carried-weight load is given). The producer separately states 4 hours for standing and 1.5 hours to charge. A |
| Hot-swap battery | not stated | |
| Charge time | 90min | Note Charging figure taken from the page's combined "Working Hours" line, which also gives walking and standing runtime. A |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | 2 RGBD cameras plus 2 all-scenario binocular structured-light 3D cameras. | Note Also fitted with a high-precision inertial measurement unit (IMU). A |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Note No named autonomy level is given; the notes describe the navigation. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Walker C is marketed as a commercial/exhibition humanoid for guided tours, reception and greeting duties in exhibition halls, office buildings, shopping malls and transport hubs - for example as the tour-guide robot for the China Pavilion at Expo 2025, Osaka.
- The producer states a per-arm figure, "Arm: Wingspan:500mm, Weight:5kg"; it is not stated as a whole-body payload.
- The page also lists "Open Interfaces: Joint Control Interface, Communication Interface", without further detail on either interface.
- Connectivity is stated as Wi-Fi and Bluetooth, with no further detail.
- Walker C navigates autonomously along guided-tour routes using a "U-SLAM" navigation system, with AI-based obstacle detection for adapting to its environment; multilingual interaction and Q&A are handled by UBTECH's own "Embodied Interactive Large Model". No single named autonomy level is given, and the robot is not described as teleoperated.
- The UBTECH product page says Walker C debuted at the Spring Banquet of Guangdong Province 2025.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Walker Chttps://www.ubtrobot.com/en/humanoid/products/walker-c
Sources
-
A
Manufacturer product page. www.
ubtrobot. · Retrievedcom/ en/ humanoid/ products/ walker-c
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.