Key figures as stated by the manufacturer
1 of 6 stated · 5 gaps- Weight A 43kg94.8lbOur conversion from 43 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking not stated
- Runtime not stated
- Max speed not stated
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (1)
Weight
Caveat Including the battery, without the skin.
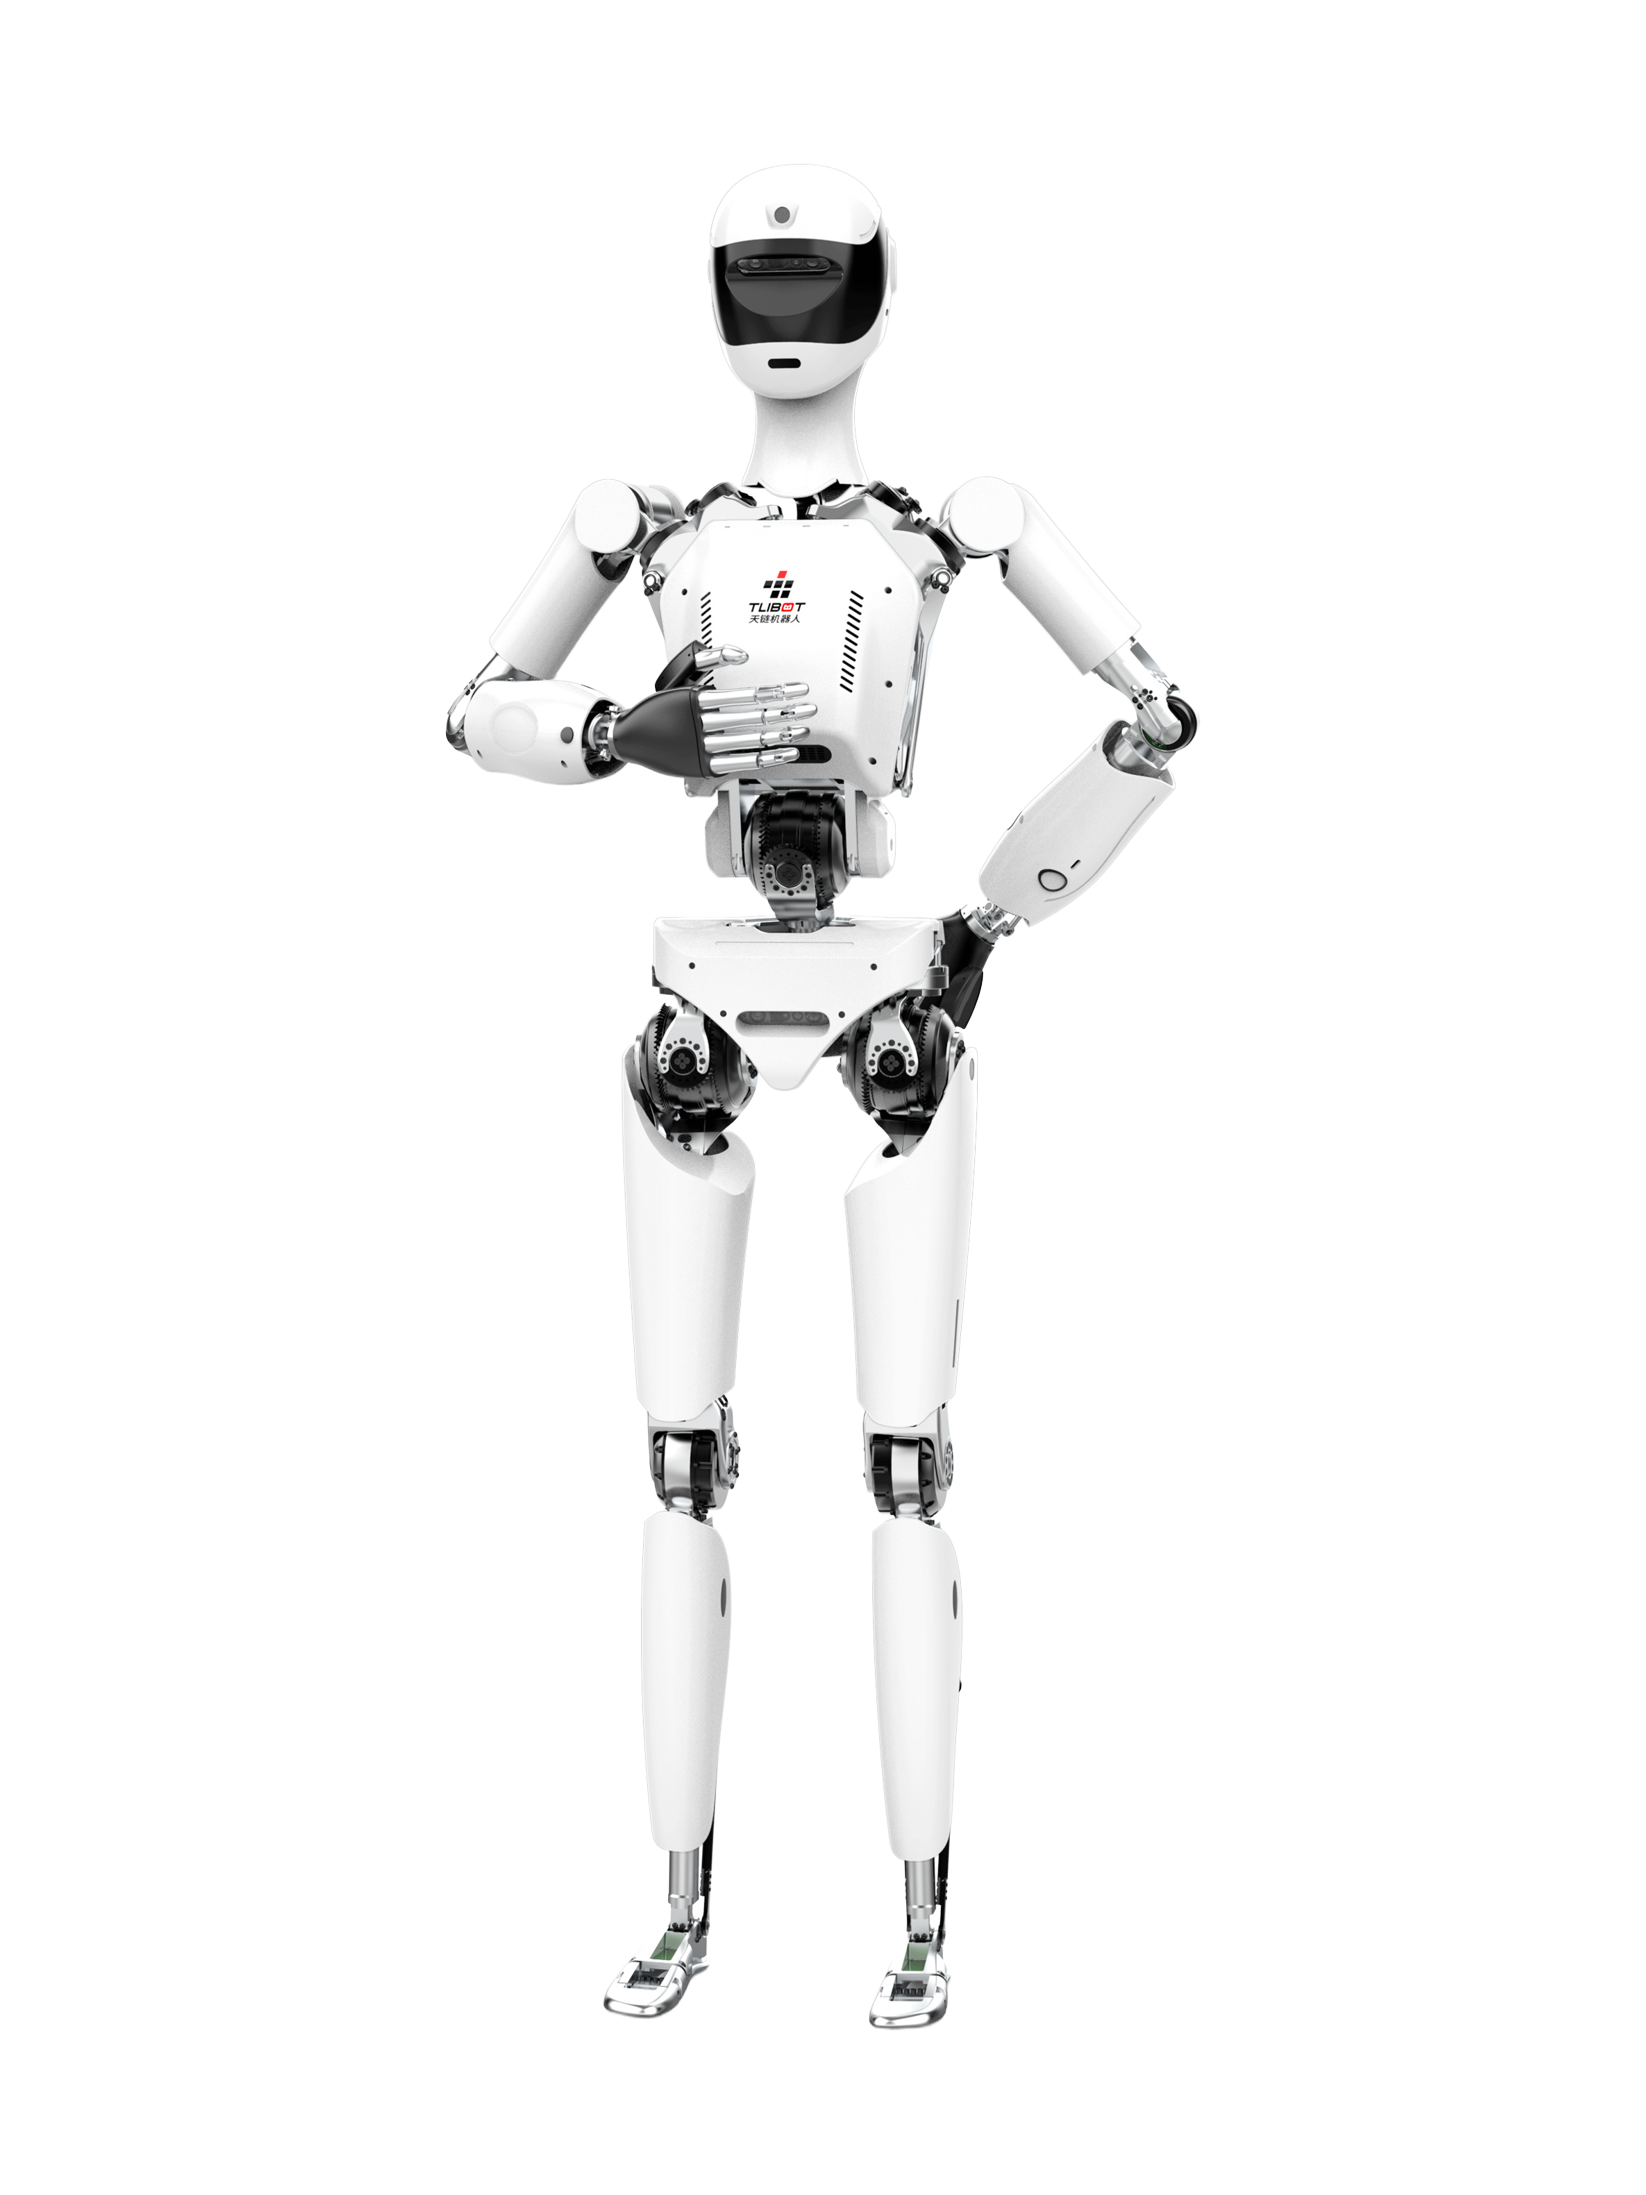
Manufacturer's own photo.
Intended use, per the manufacturer
Source: tlibot.com · Retrieved
This category is not our assessment.
Full specifications
3 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 43kg94.8lbOur conversion from 43 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Including the battery, without the skin. A |
| Length | not stated | |
| Width | not stated | |
| Height | not stated | |
| Degrees of freedom | 41DoF | Caveat Body total without dexterous hands: 5 in the head and neck, 9 in each arm, 4 in the waist and 7 in each leg, which sums to 41. A |
| Payload, walking | not stated | |
| Payload, standing | not stated | Caveat The table gives a load-bearing figure of more than 100 kg for a deep load without saying whether it is carried standing or walking, and a maximum arm load of 10 kg, which is an arm-specific figure. A |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | 1,110Wh | Note Specification table. A |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | not stated | |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer calls T1 a bipedal humanoid robot (translated from the Chinese).
- The specification table gives a maximum joint speed of 720 degrees per second, with a limit of 900, and peak torques of 450 N·m at the hip, 281 N·m at the knee and 148 N·m at the ankle.
- The producer's site gives its headquarters in Mianyang High-tech Zone, Sichuan, China.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for T1https://www.tlibot.com/product_detail/36.html
Sources
-
A
Manufacturer product page. www.
tlibot. · Retrievedcom/ product_ detail/ 36. html
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.