Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight A 65kg143lbOur conversion from 65 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking not stated
- Runtime A 150minWarning: load condition not stated
- Max speed not stated
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (1)
Runtime
Caveat Headline battery-autonomy figure; no task/load condition given.
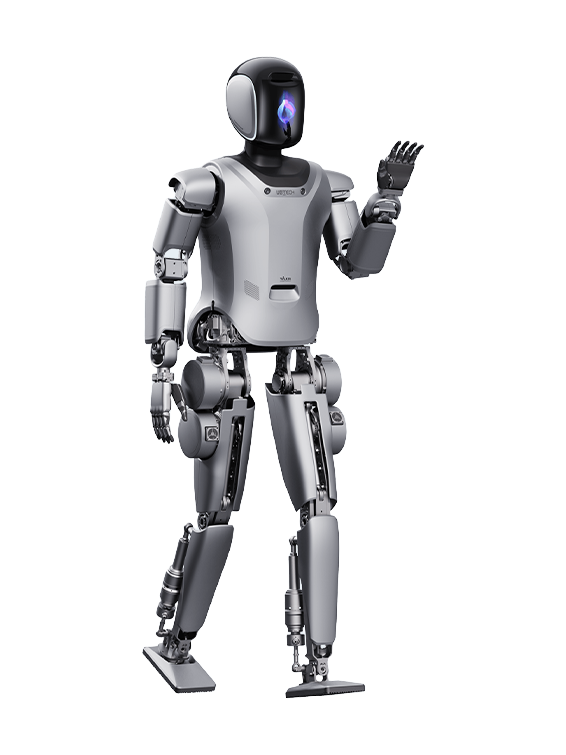
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Walker S can now achieve precise and safe synchronized operations on the factory assembly line, empowering industries with AI and robotics technologies.
Source: ubtrobot.com · Retrieved
This category is not our assessment.
Full specifications
5 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 65kg143lbOur conversion from 65 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Length | not stated | |
| Width | not stated | |
| Height | 170cm66.9inOur conversion from 170 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Degrees of freedom | 41DoF | Note Given as a single total; elsewhere the same page separately states "41 servo joints with force feedback". A |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | 150minWarning: load condition not stated | Caveat Headline battery-autonomy figure; no task/load condition given. A |
| Hot-swap battery | not stated | Note "Quick-Swap Solution" language, from the battery-autonomy line, does not confirm the robot stays powered during a swap. A |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | Multi-camera stereo vision system (resolution/count not specified), alongside an 8-inch curved AMOLED head display and a 6-microphone array. | Note From the page's "Perception & Interaction" row, which also lists the head display and microphone array. A |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Note No named autonomy level is given; the notes describe the integration with large language models. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The page's "Robotic Configuration Overview" lists two configurations side by side, "Walker S" and "Walker S Lite". This is the standard Walker S, not the Lite configuration.
- Servo motors: torque up to 300 N*m, rotational speed up to 130 rpm (a component spec, not a whole-body figure).
- Single arm length: 600mm, with an optional E-skin covering (a per-limb figure, not a whole-body dimension).
- Perception hardware: 8-inch curved AMOLED head display, 6-microphone array with 360-degree auditory perception, and multi-camera stereo vision.
- UBTECH names its own software framework "ROSA 2.0"; ROS and ROS 2 are not named.
- No named autonomy level is given. The page describes multimodal large-model-based decision making with hand-eye coordination and whole-body manipulation, and states that Walker S integrates an LLM for intent understanding and task planning on top of its perception and motion control; not described as teleoperated.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Walker Shttps://www.ubtrobot.com/en/humanoid/products/walker-s
Sources
-
A
Manufacturer product page. www.
ubtrobot. · Retrievedcom/ en/ humanoid/ products/ walker-s
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.