Key figures as stated by the manufacturer
4 of 6 stated · 2 gaps- Weight A 63kg139lbOur conversion from 63 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking A 3kg6.61lbOur conversion from 3 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Runtime A 120minWarning: load condition not stated
- Max speed A 3km/h1.86mphOur conversion from 3 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (2)
Payload, walking
Caveat Producer states "It can carry 10kg of weight or walk with 3kg of weight on both hands."
Runtime
Caveat Producer's own label is "combined working conditions", not a specific carried load.
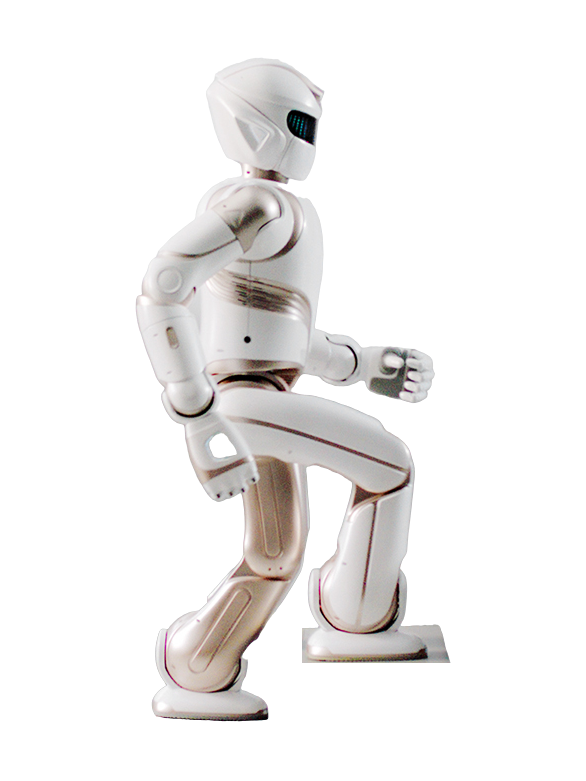
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Be able to use of refrigerators, coffee machines, vacuum cleaners and other household appliances
Source: ubtrobot.com · Retrieved
This category is not our assessment.
Full specifications
13 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 63kg139lbOur conversion from 63 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Length | not stated | |
| Width | not stated | |
| Height | 130cm51.2inOur conversion from 130 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Degrees of freedom | 41DoF | Note Producer breaks this down as Legs 6x2, arms 7x2, hands 6x2, neck 3 (=41 total). A |
| Payload, walking | 3kg6.61lbOur conversion from 3 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Producer states "It can carry 10kg of weight or walk with 3kg of weight on both hands." A |
| Payload, standing | 10kg22lbOur conversion from 10 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Producer states "It can carry 10kg of weight or walk with 3kg of weight on both hands." A |
| Max speed | 3km/h1.86mphOur conversion from 3 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Max slope | 20° | A |
| Single obstacle | not stated | |
| Stair step, continuous | 15cm5.91inOur conversion from 15 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer separately states "Stairs climbing up and down: 15cm" earlier on the same page under "Structured terrain walking", confirming this step-height figure refers to stairs. A |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Caveat Producer states only voltage and amp-hours, not a Wh figure. A |
| Runtime | 120minWarning: load condition not stated | Caveat Producer's own label is "combined working conditions", not a specific carried load. A |
| Hot-swap battery | not stated | Note "Removable battery" language does not confirm the robot stays powered during removal. A |
| Charge time | 120min | A |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | Built-in four-eye camera system with dual RGBD sensors, used for hand-eye coordination and object manipulation. | Note From the page's "four-eye system and dual RGBD sensors" line. A |
| Onboard compute | Intel i7 8665U (1.9 GHz x2) with an NVIDIA GT1030 graphics card (384 cores). | Note Combines the page's separate processor and graphics-card lines. A |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Note No named autonomy level is given; the notes describe the navigation. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | Wi-Fi 802.11 a/b/g/n, 5G/2.4GHz dual-band Gigabit RJ45 Ethernet interface EtherCAT high-speed real-time bus USB 3.0 high-speed port | Note Combines the page's Wi-Fi, Ethernet, EtherCAT and USB connectivity rows. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer states "It can carry 10kg of weight or walk with 3kg of weight on both hands," without labelling which figure is standing and which is walking. The 3 kg figure matches the separately stated "Load: Single arm 1.5kg in extended state" (x2 arms), so it is entered here as the walking capacity and the 10 kg figure as the standing capacity.
- The producer states "Maximum up and down step height: 15cm" under the same "Walking" heading as "Stairs climbing up and down: 15cm" elsewhere on the page.
- UBTECH names its own software framework "ROSA"; ROS and ROS 2 are not named.
- Battery is stated only as "Lithium battery 54.6V/10Ah/3.6 kg"; no Wh figure is given.
- Processor: Intel i7 8665U (1.9 GHz x2) plus an NVIDIA GT1030 graphics card (384 cores) - not a robotics-specific "compute" module name, but the producer's own stated processor.
- Producer states "Maximum uneven terrain adaptation: 3cm", which is not clearly a single-obstacle height.
- No named autonomy level is given. The page describes built-in visual and 3D navigation (U-SLAM) using first-person-view AR navigation and 2.5D obstacle avoidance, plus object and facial recognition; not described as teleoperated.
- IEEE Spectrum's Video Friday of 9 July 2021 quotes UBTECH saying it unveiled Walker X, the latest version of its bipedal humanoid.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Walker Xhttps://www.ubtrobot.com/en/humanoid/products/walker-x
Sources
-
A
Manufacturer product page. www.
ubtrobot. · Retrievedcom/ en/ humanoid/ products/ walker-x
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.