Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 63kg139lbOur conversion from 63 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking not stated
- Runtime A 120minWarning: load condition not stated
- Max speed A 5km/h3.11mphOur conversion from 5 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 1,100mmB43.3inB
- A dashed letter marks a secondary source – a datasheet, manual or developer documentation from the manufacturer, or a press report used only where the manufacturer gives no figure.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Weight
Note From the brochure's technical specifications table.
Runtime
Caveat The brochure gives an average runtime and no load or task condition.
Max speed
Note From the performance rows of the specification table.
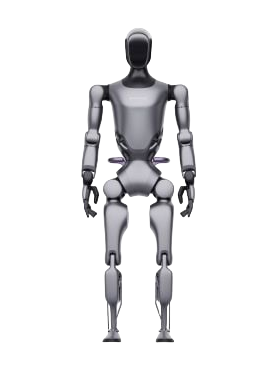
Product image from a reseller's page (robotsinternational.com), not the manufacturer's own site; taken from the curated list of Chinese humanoid cutouts.
Intended use, per the manufacturer
The manufacturer’s words
Fourier's GRx robots provide groundbreaking solutions across diverse sectors, including academic research, reception services, manufacturing, and rehabilitation.
Source: fftai.com · Retrieved
This category is not our assessment.
Full specifications
10 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 63kg139lbOur conversion from 63 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note From the brochure's technical specifications table. A |
| Length | not stated | Note The table gives one combined entry for height, length and width, without saying which of 552 mm and 275 mm is the body depth or the shoulder width. A |
| Width | not stated | Note The table gives one combined entry for height, length and width, without saying which of 552 mm and 275 mm is the body depth or the shoulder width. A |
| Height | 175cm68.9inOur conversion from 175 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note First of the three combined dimensions in the table, given as 1750 mm. A |
| Degrees of freedom | at most 53DoF | Note Stated as "up to"; the table ties the maximum to the 12-DoF dexterous hand version, so a robot with the basic hand has fewer. A |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | 5km/h3.11mphOur conversion from 5 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note From the performance rows of the specification table. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | 950Wh | Note From the battery rows of the specification table. A |
| Runtime | 120minWarning: load condition not stated | Caveat The brochure gives an average runtime and no load or task condition. A |
| Hot-swap battery | not stated | Caveat The brochure calls the battery a "Detachable Design"; it does not say the robot stays powered during a swap. A |
| Charge time | 120min | Note From the battery rows of the specification table. A |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | Stereo camera. | Note From the sensor rows of the specification table. A |
| Onboard compute | Intel Core i7 14-core CPU; an optional module adds a 275 TOPS computing unit. | Note Standard configuration plus the optional module named in the table. A |
| ROS 2 | not stated | Caveat The brochure names ROS among the supported frameworks but does not say which ROS version. A |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | Caveat The table's "Power Output 930 W" sits under the electronic specifications and describes the robot itself, not a port that powers a payload. A |
| Data ports | Type-C USB 3.0 | Note From the central processing unit rows of the specification table. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Fourier describes GR-2 as its second-generation general-purpose humanoid robot. The producer's brochure lists a 12-DoF dexterous hand version alongside a basic 6-DoF hand, and the degrees of freedom split as head 2, waist 1, each arm 7, each leg 6.
- The specification table gives a single-handed payload of 3 kg. That is an arm-specific figure, not a figure for what the whole robot can carry.
- The brochure names no price and no purchase route; its closing block lists a business-development e-mail address and a telephone number.
- Fourier's press release of 30 September 2024 (PR Newswire, reprinted by Adnkronos) announces the launch of GR-2.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for GR-2https://www.fftai.com/pdf/en/gr2.pdf
Sources
-
A
Secondary: www.
fftai. · Retrievedcom/ pdf/ en/ gr2. pdf
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.