Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight A 63.5kg140lbOur conversion from 63.5 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking not stated
- Runtime A at least 120minWarning: load condition not stated
- Max speed not stated
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Weight
Note Weight row of the basic-parameters table, KUAVO 5 column.
Payload, walking
Note The performance panel gives a whole-body maximum load of 20 kg without saying whether it applies standing or walking. The 5 kg in the table is an arm-specific figure, not a figure for what the whole robot can carry.
Runtime
Caveat No load or task condition is given.
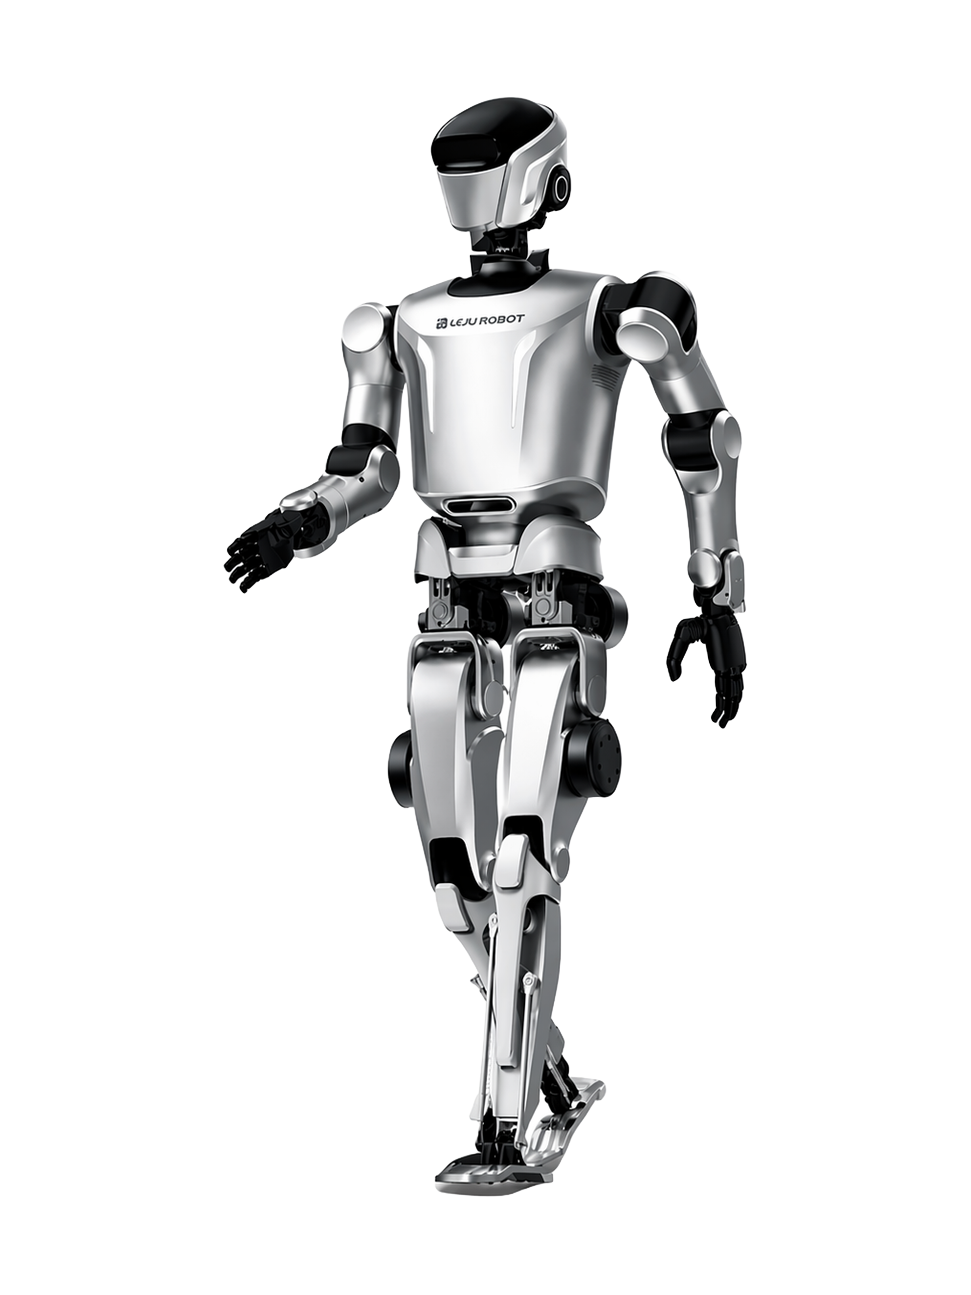
Product image from a reseller's page (sonnyrobotics.com), not the manufacturer's own site; taken from the curated list of Chinese humanoid cutouts.
Intended use, per the manufacturer
The manufacturer’s words
Fit industrial production rhythm, empower efficient execution of multi-scenario and multi-task operations
Source: lejurobot.com · Retrieved
This category is not our assessment.
Full specifications
9 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 63.5kg140lbOur conversion from 63.5 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Weight row of the basic-parameters table, KUAVO 5 column. A |
| Length | not stated | Caveat The dimensions row reads 607x270x1730mm without labelling the three values. A |
| Width | not stated | Caveat The dimensions row reads 607x270x1730mm without labelling the three values. A |
| Height | 173cm68.1inOur conversion from 173 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Third value of the dimensions row 607x270x1730mm; the row does not label its values. A |
| Degrees of freedom | 41DoF | Note Listed as 41 with 6-DOF dexterous hands. A |
| Payload, walking | not stated | Note The performance panel gives a whole-body maximum load of 20 kg without saying whether it applies standing or walking. The 5 kg in the table is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Payload, standing | 20kg44.1lbOur conversion from 20 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat The performance panel (an image on the page) gives a whole-body maximum load of 20 kg without saying whether it applies standing or walking. The 5 kg in the specification table is a single-arm maximum load. A |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | at least 120minWarning: load condition not stated | Caveat No load or task condition is given. A |
| Hot-swap battery | yes | Note The "continuous work" highlight says the battery can be swapped quickly without powering the robot down. A |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | 3D LiDAR. | Note The sensor row reads "4 depth cameras / 3D LiDAR". A |
| Cameras | 4 depth cameras. | Note The sensor row reads "4 depth cameras / 3D LiDAR"; the diagram shows a head depth camera and a waist camera. A |
| Onboard compute | 100-2070 TOPS computing power. | Note The page gives the figure as a range and names no computing hardware. A |
| ROS 2 | not stated | Note The table says secondary development is supported and names no ROS version. A |
| SDK languages | not stated | Note The table says secondary development is supported and names no programming languages. A |
| Autonomy level | not stated | Note The table lists autonomous positioning and navigation as available, without a named autonomy level. A |
| Payload and expansion | ||
| Mounting interface | not stated | Note The end effector is a two-finger gripper or a five-finger dexterous hand, and the page says whole hand modules can be removed quickly. No mounting interface is named. A |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Note The page shows EMC testing but names no CE, FCC, UL or 3C certification. A Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- KUAVO 5-W is the version of KUAVO 5 on an omnidirectional wheeled base.
- The performance panel gives a whole-body maximum load of 20 kg, a waist rotating ±180° and quick removal of the whole hand or leg modules.
- Mike Kalil's technology news site reported in late 2025 that Leju had just launched the Kuavo 5, the fifth iteration of its industrial humanoid.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for KUAVO 5https://www.lejurobot.com/en/products/kuavo-5
Sources
-
A
Manufacturer product page. www.
lejurobot. · Retrievedcom/ en/ products/ kuavo-5
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.