MagicLabChina2025
MagicDog Y1
- In production
- Over 40 kg
- Industry
- Inspection
- Defence and emergency response
Key figures as stated by the manufacturer
5 of 6 stated · 1 gap- Weight 70kg154lbOur conversion from 70 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- Payload, walking 45kg99.2lbOur conversion from 45 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- Runtime more than 240minWarning: at load 20 kgA
- Max speed 21.6km/h13.4mphOur conversion from 21.6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- IP rating IP67A
- Indicative price not stated
Deviations and variants in the key figures (4)
Weight
NoteIncluding battery.
Payload, walking
NoteThe manufacturer’s label: Dynamic Payload (CN: movement load).
Runtime
NoteThe manufacturer states 4-6h ( >4 h continuous walking with 20 kg load ). The figure is used here with the load condition. Worded identically to Unitree B2’s phrasing, down to the operator.
Max speed
NoteWithout an operator. Unitree B2 states > 6 m/s for the same figure — Y1 is therefore NOT above B2 on this field.
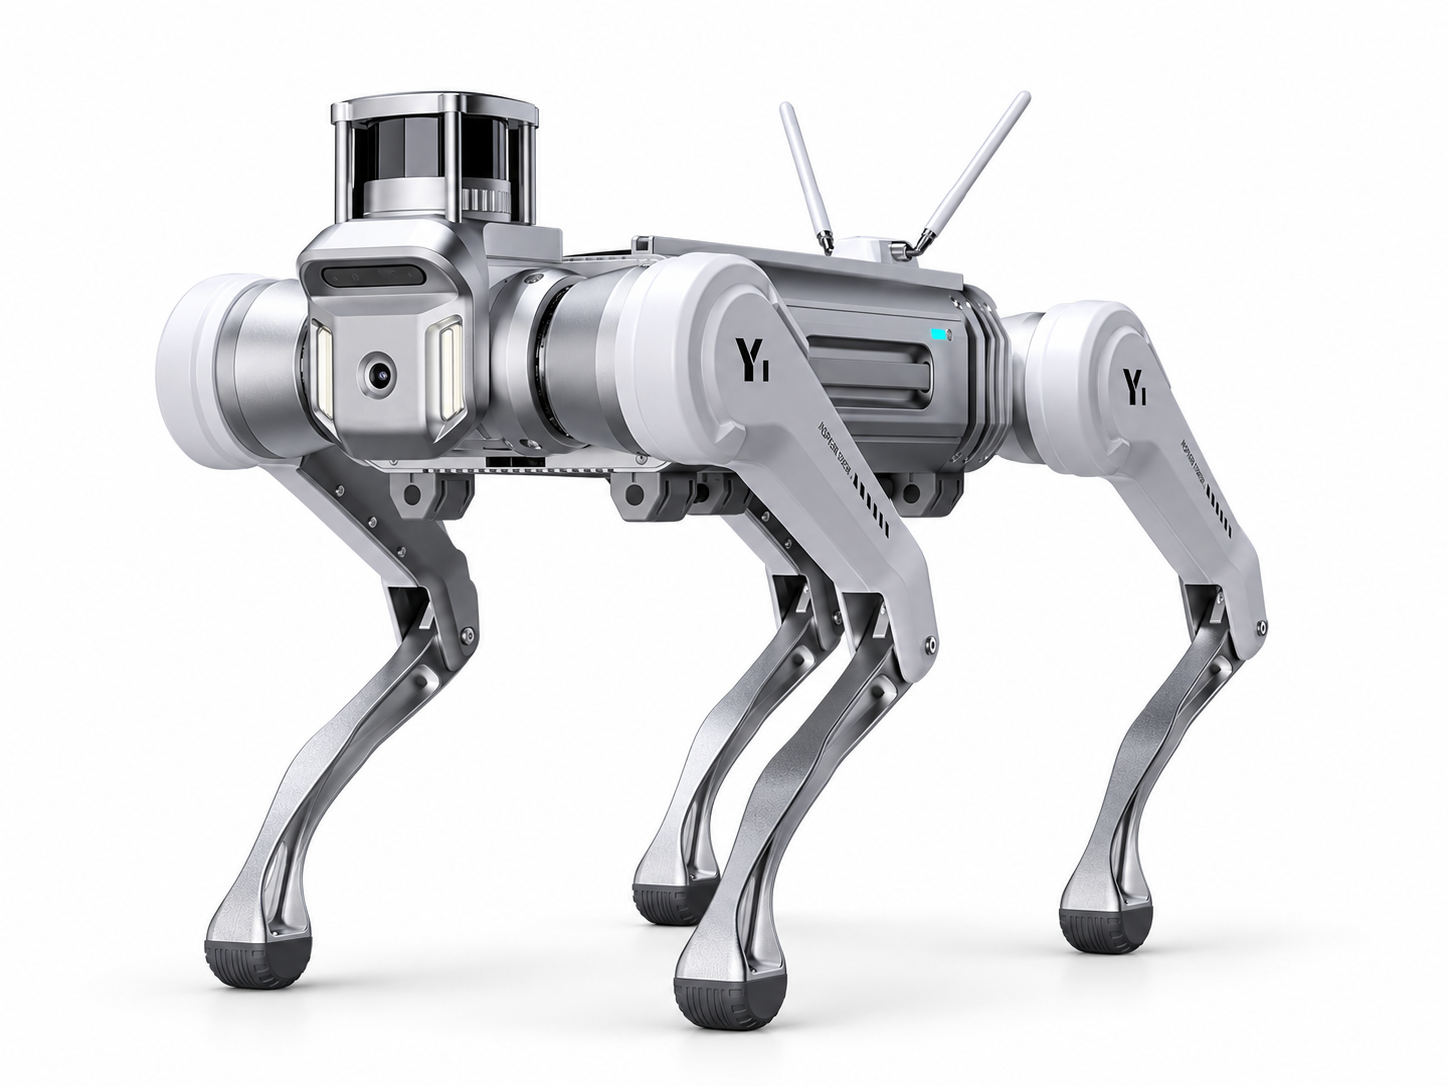
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
MagicDog Y1 is an industrial quadruped robot engineered for inspection, emergency response, rescue support and demanding outdoor operations.
MagicLab Industrial Quadruped Robot
Source: magiclabglobal.com · Retrieved
The two manufacturer domains say the same thing: magiclab.top states "MagicLab Industrial Quadruped Robot"; the Chinese-language page states the equivalent designation in Chinese.
This category is not our assessment.
Every field in the schema
19 of 33 fields statedImperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 70kg154lbOur conversion from 70 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteIncluding battery. |
| Length | 105cm41.3inOur conversion from 105 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Width | 45.8cm18inOur conversion from 45.8 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Height | 81cm31.9inOur conversion from 81 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Degrees of freedom | not stated | |
| Payload, walking | 45kg99.2lbOur conversion from 45 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteThe manufacturer’s label: Dynamic Payload (CN: movement load). |
| Payload, standing | 150kg331lbOur conversion from 150 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A CaveatThe manufacturer’s label: Maximum Payload (CN: max. load). The page does not explicitly say standing; the placement follows the same interpretation as Unitree’s two load fields. |
| Max speed | 21.6km/h13.4mphOur conversion from 21.6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteWithout an operator. Unitree B2 states > 6 m/s for the same figure — Y1 is therefore NOT above B2 on this field. |
| Max slope | at least 45° | A |
| Single obstacle | at least 60cmat least 23.6inOur conversion from 60 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A CaveatThe manufacturer’s label is Maximum Climbing Height (CN: max. climbing height). NEITHER EN NOR CN says whether it is a single step or a continuous staircase — here the Chinese page does not help, unlike Lite3. The placement in obstacle_single is an interpretation, chosen so the figure CANNOT contaminate the comparison that needs the continuous field. |
| Stair step, continuous | not stated | |
| IP rating | IP67 | A |
| Operating temperature, low | -20°C-4°FOur conversion from -20 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A CaveatStated in body text, not in the table. |
| Operating temperature, high | 55°C131°FOur conversion from 55 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A CaveatStated in body text, not in the table. |
| Power | ||
| Battery | 2,400Wh | A CaveatThe manufacturer prints 45Ah (2400Wh), Voltage 54V. 45 x 54 = 2430 Wh, not 2400 — a discrepancy of 30 Wh (1.2%). We reproduce the printed figure and note the discrepancy. Note: neither Y1’s nor Unitree B2’s Wh figure matches their own Ah x V. |
| Runtime | more than 240minWarning: at load 20 kg | A NoteThe manufacturer states 4-6h ( >4 h continuous walking with 20 kg load ). The figure is used here with the load condition. Worded identically to Unitree B2’s phrasing, down to the operator. |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | A Note3D LiDAR x1 — type without model, does not count under D4. |
| Cameras | depth cameras x2 + optical cameras x2 | A NoteThe manufacturer adds configurations may vary. The whole string (3D LiDAR x1 + Depth Cameras x2 + Optical Cameras x2 + caveat) is the same construction as Unitree B2’s. |
| Onboard compute | 8-core CPU + high-performance compute module (157 TOPS) | A |
| ROS 2 | not stated | B NoteNEGATIVE RESULT, measured, not sensed: the Y1 guide’s navigation has 25 routes (C++ API 7 services, Python API 7 services, 5 examples, SLAM navigation, FAQ, etc.) and NONE of them is ROS2 — unlike MagicDog and MagicDog-W, which both have it. The status code is not proof: /docs/y1/ros2_sdk returns 200, but so does any path under /docs/<product>. The field is set to not stated rather than no, because the absence is our own count, not the manufacturer’s statement. |
| SDK languages | not stated | B NoteThe developer documentation states C++ and Python. Not filled in, because D1 is open. The documentation is Chinese-only. |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | expansion plates, sliding rails, screw mounts, payload platform | A |
| Power out | (24 V + RS485) x4; (12 V + Ethernet) x3 | A NoteVoltage stated, wattage not. |
| Data ports | USB 3.0 x4 Ethernet EtherCAT x1 | A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Stair step and payload each exist in two variants. Only compare fields with the same label.
Notes
- The manufacturer's own site states it is headquartered in Suzhou, China — not Wujiang, a city sometimes attributed to it.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for MagicDog Y1https://www.magiclab.top/en/dog-y
Sources
- A Manufacturer product page. www.magiclab.top/en/dog-y · Retrieved
- B support.magiclab.top/docs/y1/about · Retrieved
- C www.magiclabglobal.com/products/magicdog-y1/ · Retrieved
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.