LLAMA
A quadruped robot from the United States, first released 2018.
Sources retrieved: 6 September 2026 (A, B, C)
- Status
- Discontinued
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- Rough, uneven terrain navigation; first responder support; security and disaster response operationsSource and note: Intended use, per the manufacturerA jpl.nasa.gov/robotics-at-jpl/llama/ · Retrieved 6 September 2026
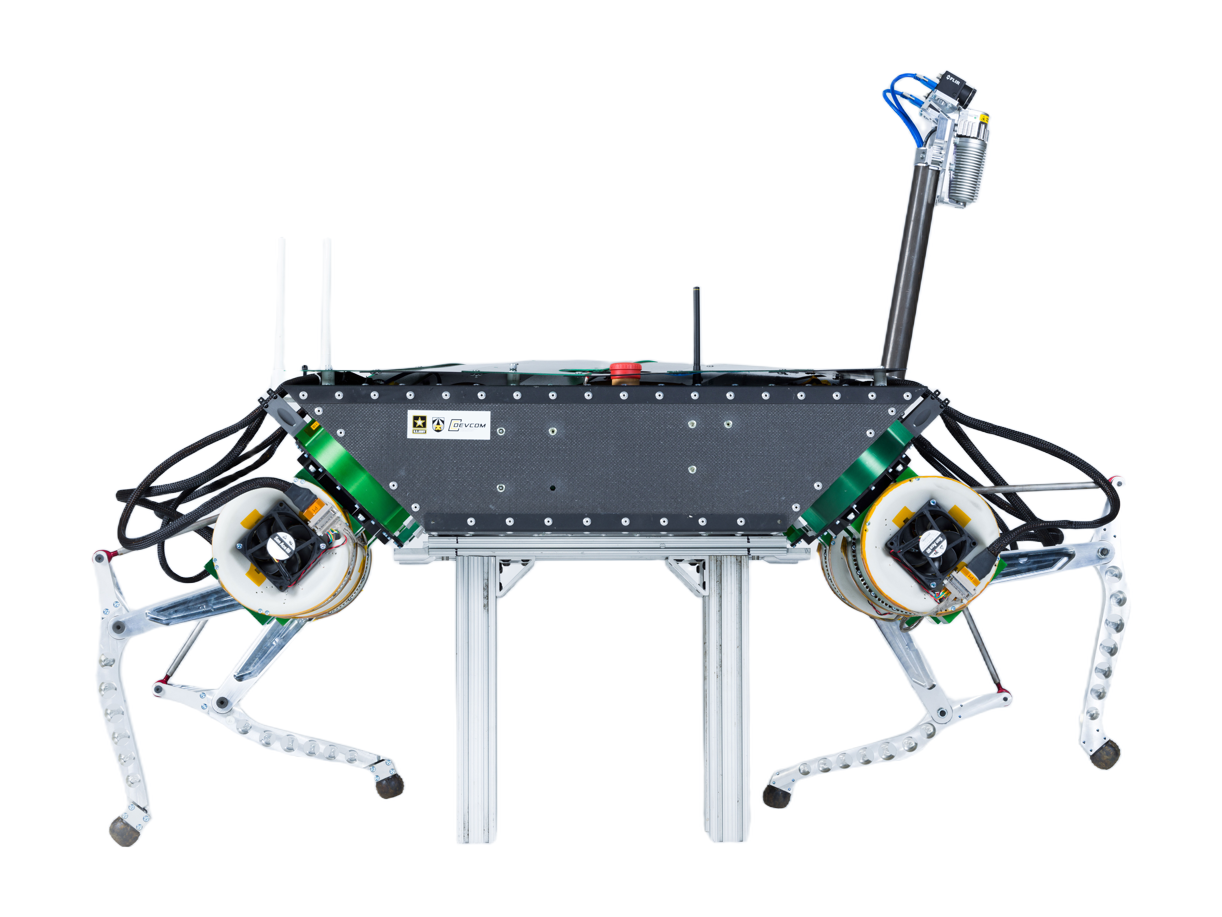
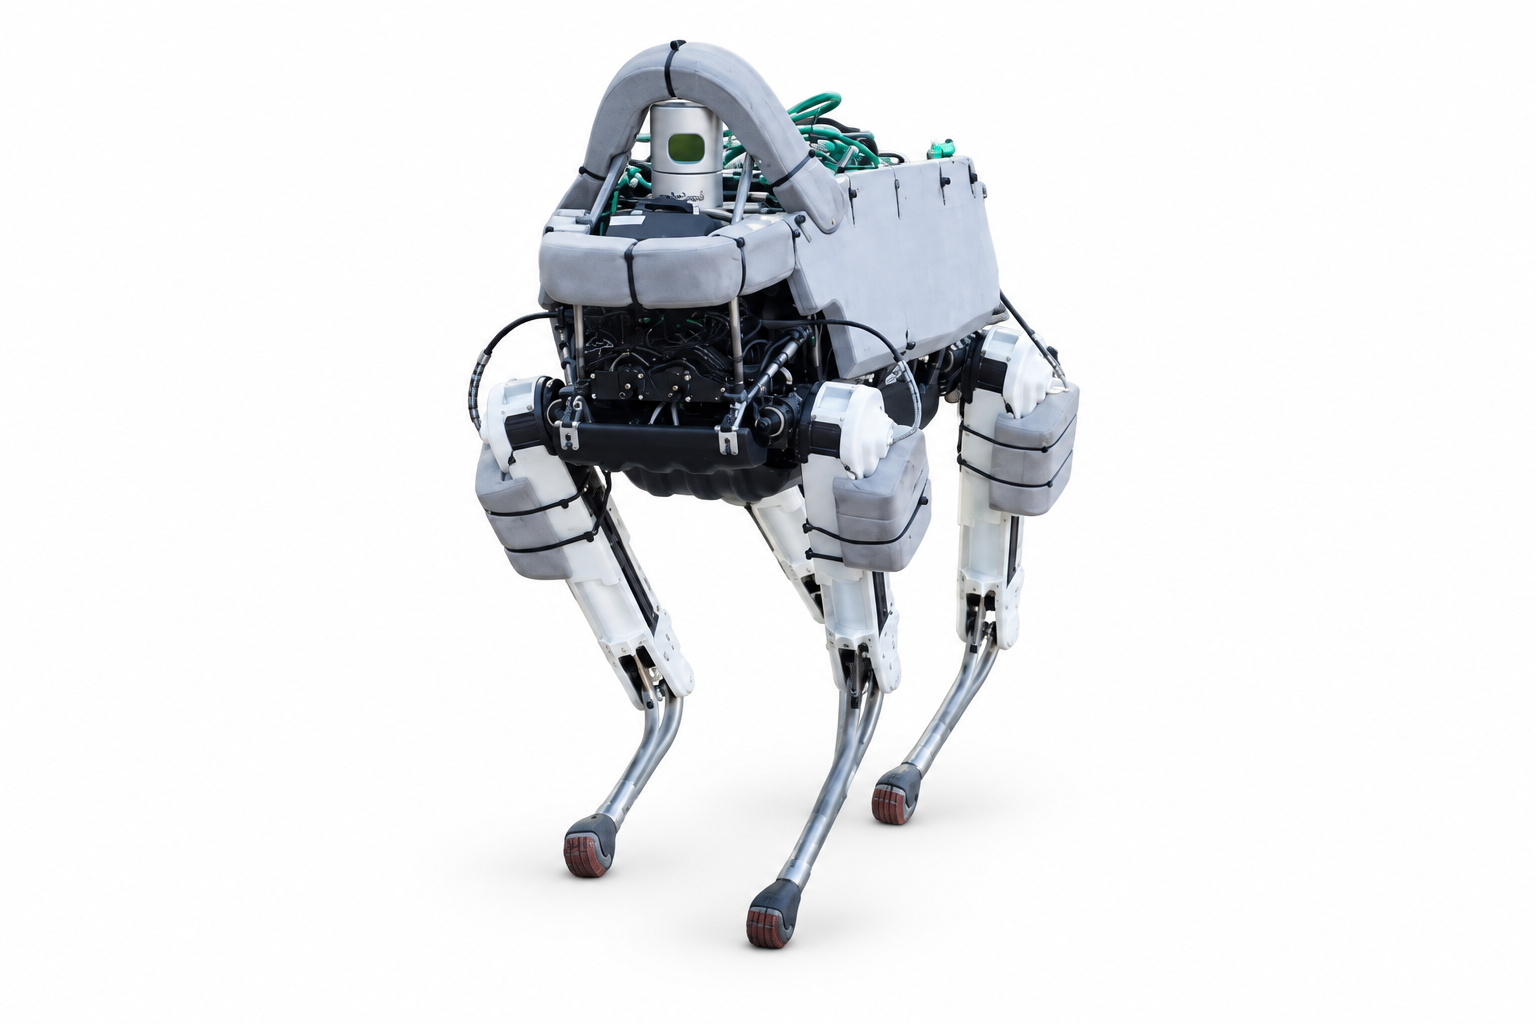
Manufacturer's own photo.
Specifications
6/33 specifications disclosed 27 not stated
27 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical4/14 disclosed
Power0/5 disclosed
Sensing and autonomy2/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Weight
70kg154lbOur conversion from 70 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
124 quadrupeds state a weight
16 state a higher figure, 104 a lower one. 1 more states exactly the same figure. Log scale: each step along the axis multiplies the value.
Degrees of freedom
12DoF
76 quadrupeds state degrees of freedom
15 state a higher figure, 4 a lower one. 56 more state exactly the same figure.
Max speed
at most 6.48km/hat most 4.03mphOur conversion from 1.8 m/s. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
113 quadrupeds state a top speed
LLAMA states an upper limit, not one figure, so it is shown open-ended and not ranked against the others.
Notes
LLAMA is a human-scale, all-electric quadruped built under the U.S. Army Research Laboratory's RCTA program, with NASA JPL (hardware) and IHMC (software).
Uses custom quasi-direct-drive actuators on 3-DOF serial-parallel legs — described as the first all-electric quadruped at this scale, built to keep pace with a dismounted infantry squad.
Sources
One line per source, not per figure: a source has one retrieval date.
- Ajpl.nasa.gov/robotics-at-jpl/llama/Main source. Retrieved 6 September 2026
- Bieeexplore.ieee.org/document/10876051/Retrieved 6 September 2026
- Cihmc.us/quadrupedal-locomotion/Retrieved 6 September 2026