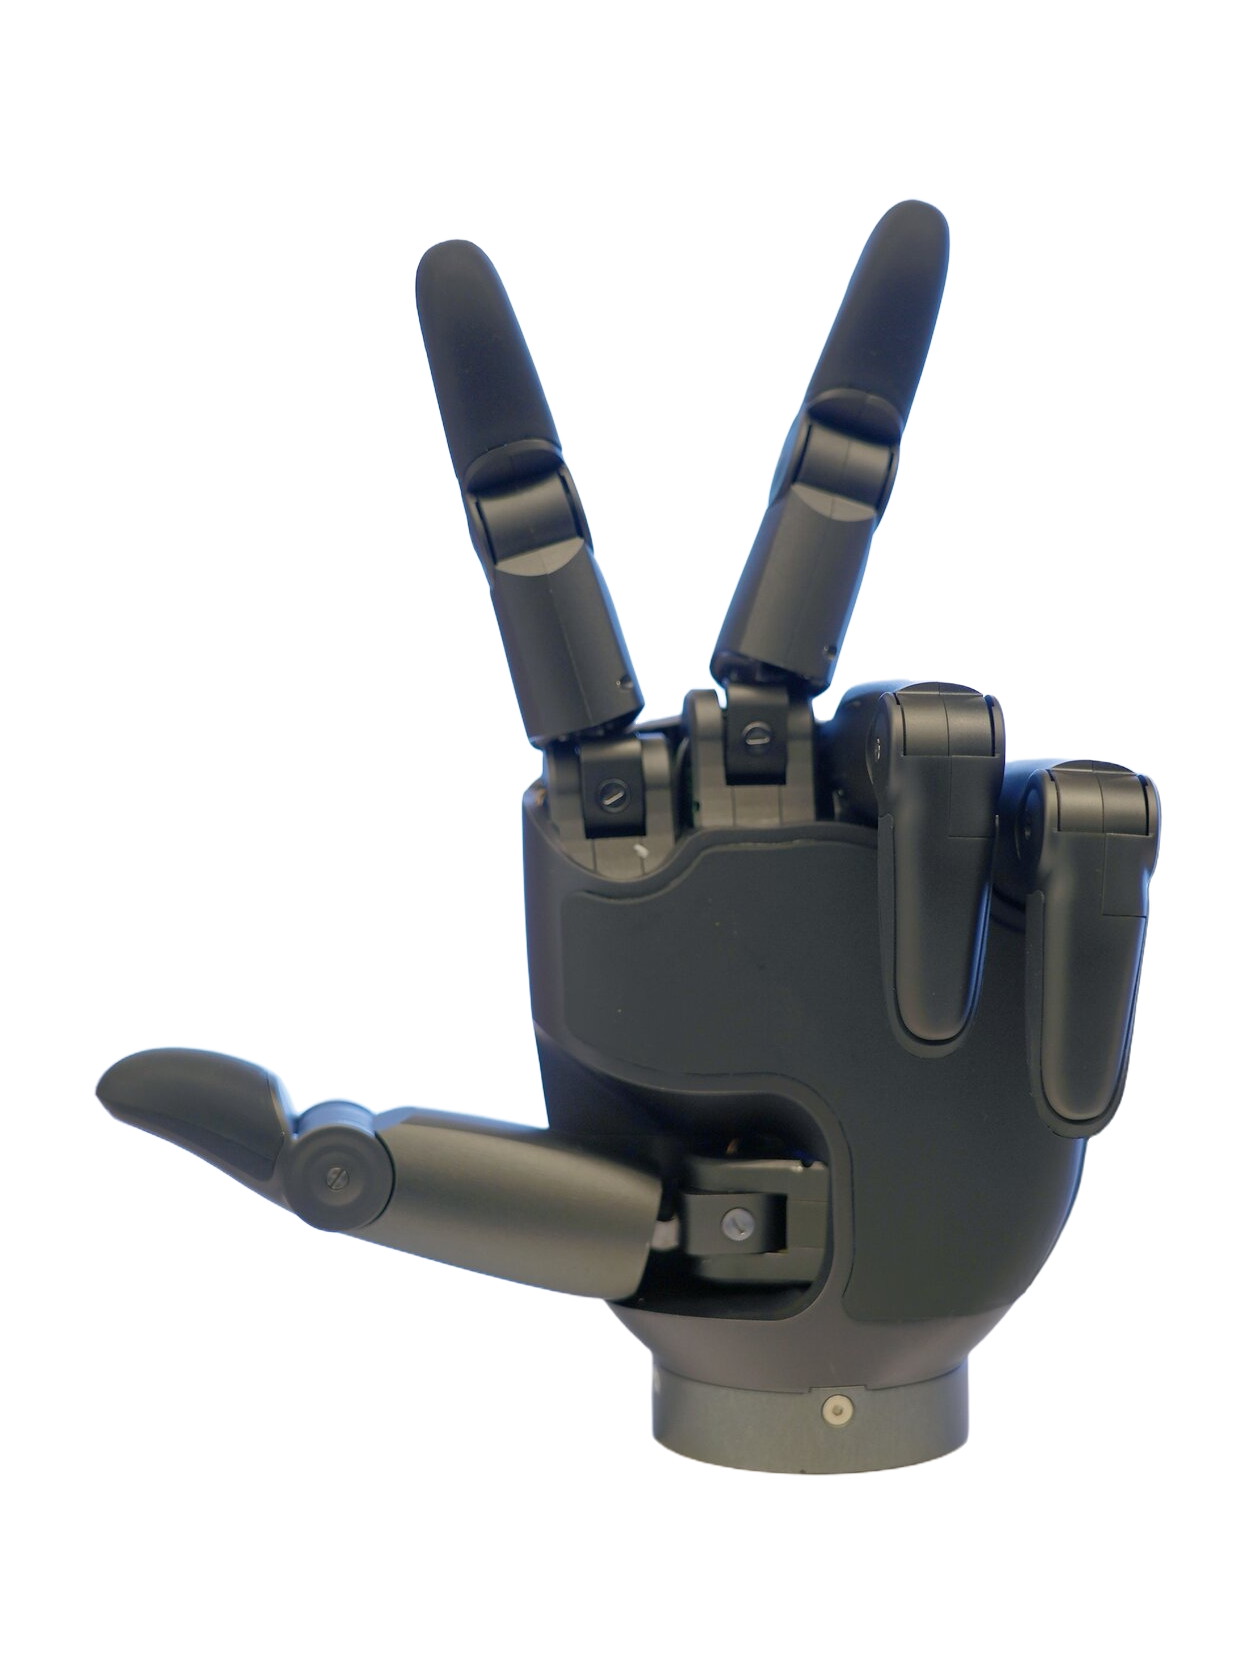
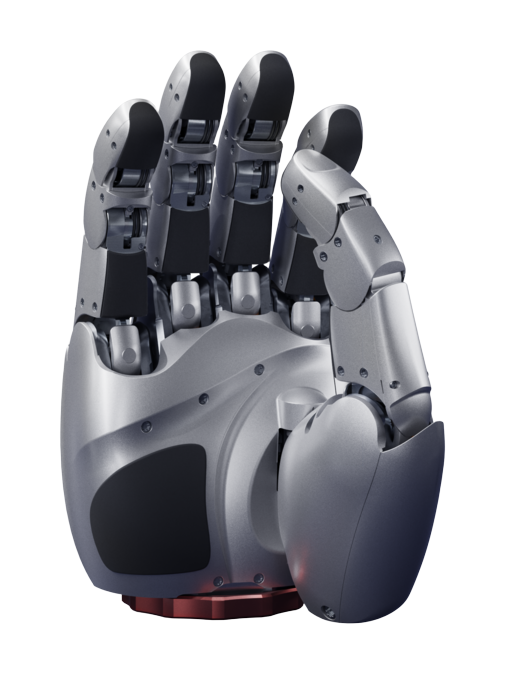
Dex5-1
Other variants Dex5-1P
Figures below are for Dex5-1.
A robot hand from China.
Sources retrieved: 4 November 2026 (A)
- Applications
- Intended use, per the manufacturer
- making operations smoother and more convenient for reinforcement learning(RL) trainingSource and note: Intended use, per the manufacturerA unitree.com/Dex5-1/ · Retrieved 4 November 2026
- Indicative price
- Not stated
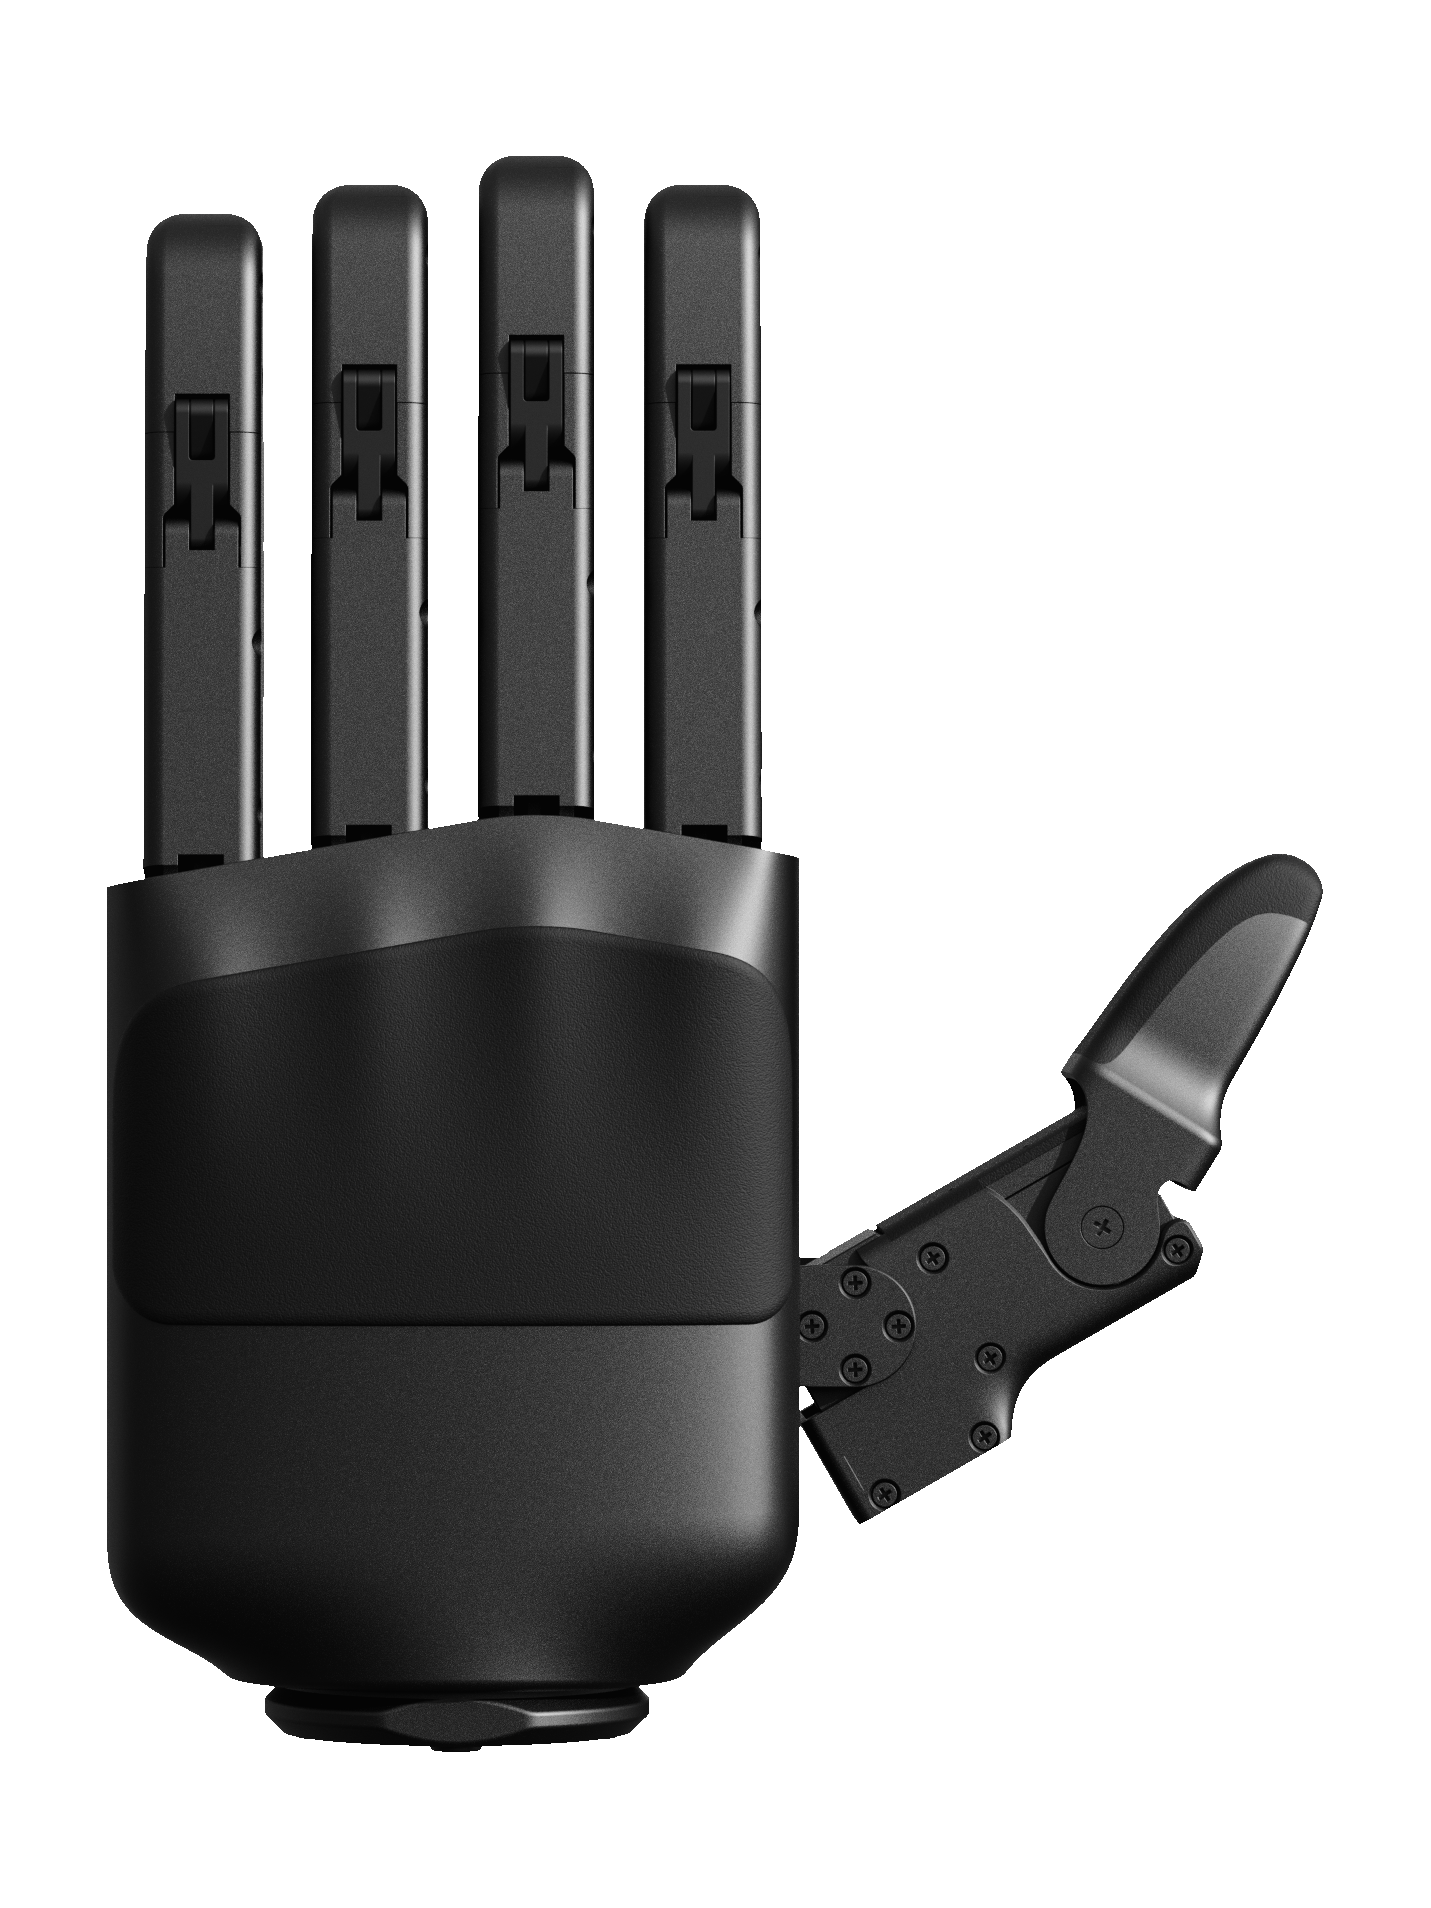
Product render from the manufacturer's own website (unitree.com).
Specifications
10 of 18 stated 8 not stated
8 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- VariantsDiffers between variants
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand4/4 disclosed
Performance3/4 disclosed
Physical2/2 disclosed
Sensing and autonomy1/3 disclosed
- Variants
- Dex5-1P
- yes
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Fingertip force
10N
38 robot hands state a fingertip force
19 state a higher figure, 4 a lower one. 1 more states exactly the same figure. 1 states a range that includes this figure. 12 state only a bound (≥ or ≤) and are not ranked. DG-5F-M lies beyond the end of the axis and is drawn at its edge as an open bar.
Lifting capacity
4.5kg9.92lbOur conversion from 4.5 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
48 robot hands state a lifting capacity
36 state a higher figure, 4 a lower one. 7 state only a bound (≥ or ≤) and are not ranked.
Weight
1,100g2.43lbOur conversion from 1,100 g. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
59 robot hands state a weight
11 state a higher figure, 42 a lower one. 1 more states exactly the same figure. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
16DoF
66 robot hands state degrees of freedom
22 state a higher figure, 36 a lower one. 6 more state exactly the same figure. 1 states a range that includes this figure.
Notes
The product page gives the size as 217.3 mm x 127.5 mm x 72.1 mm and adds “The final shipped version may vary.”
The product page gives a four-finger lateral swing of ±22°, a minimum grip diameter of 10 mm and a fingertip repeat positioning accuracy of ±1 mm.
The product page gives a static current of 58 V at 0.2 A, a maximum current of 58 V at 4 A and USB 2.0 as the communication interface.
The product page gives a working temperature range of -20 °C to 60 °C.
The Dex5-1P has 12 pressure sensor arrays with 94 pressure sensors in total and a perception range of 10 g to 2500 g.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aunitree.com/Dex5-1/Main source. Retrieved 4 November 2026
More robots
Same manufacturer
Dex5-SUnitree Robotics
A1Unitree RoboticsQuadruped
A2Unitree RoboticsQuadruped
A2-WUnitree RoboticsQuadruped
AlienGoUnitree RoboticsQuadruped
As2Unitree RoboticsQuadruped
All robots from Unitree Robotics