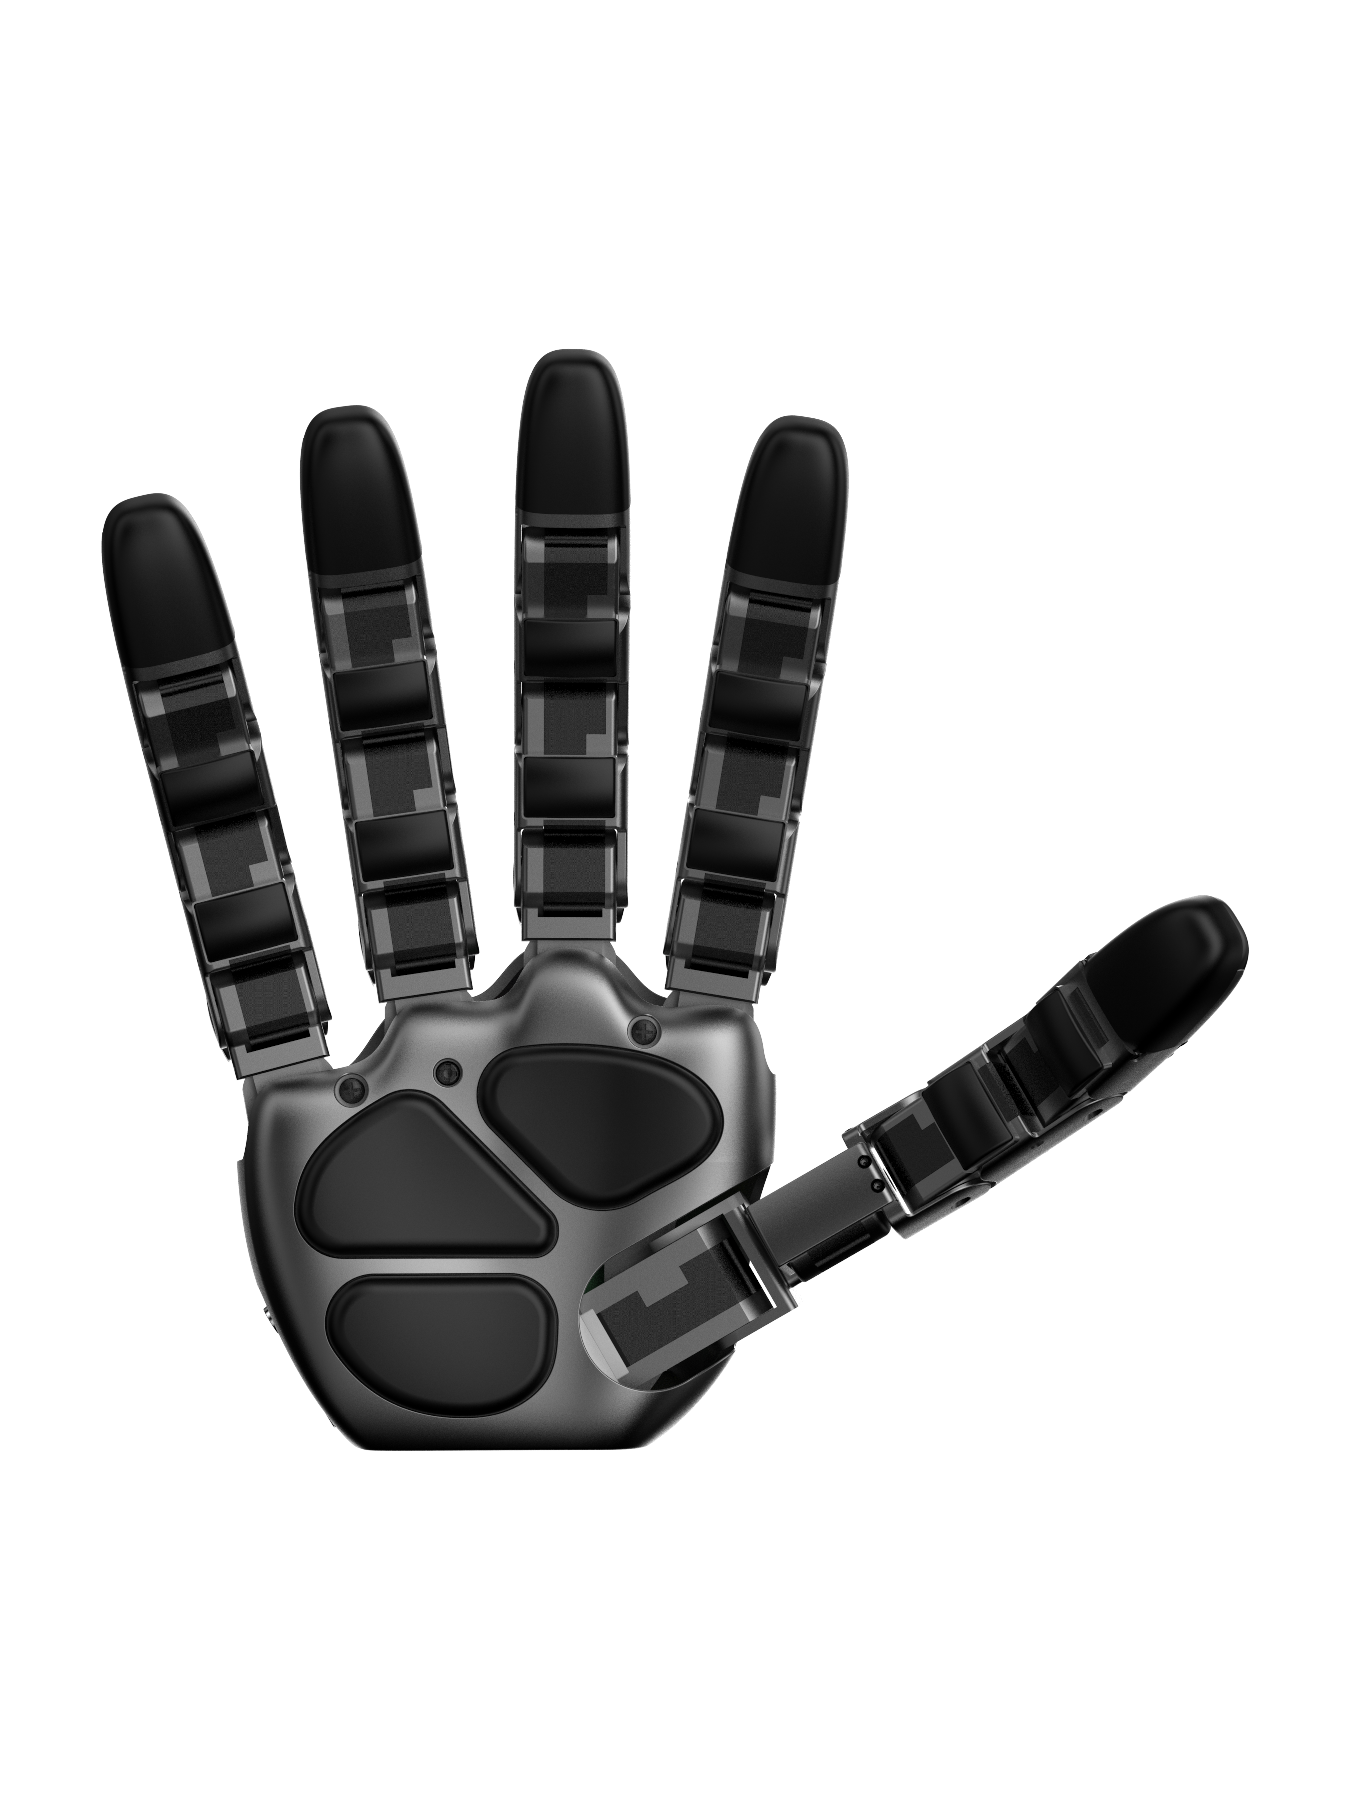
AIDIN Hand Gen2
A robot hand from South Korea, announced 2026.
Sources retrieved: 9 November 2026 (A, H) · 10 November 2026 (B, C, D, E, F, G)
- Intended use, per the manufacturer
- Not stated
- Indicative price
- Not stated
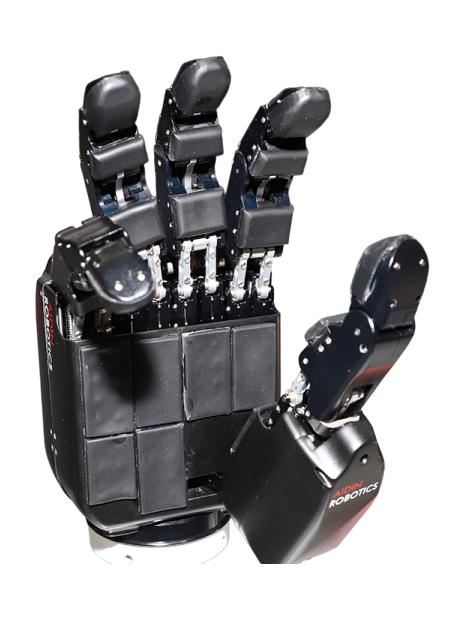
Manufacturer's own photo. Press photo: The Korea Industry Daily (as published on aidinrobotics.co.kr).
Specifications
7 of 18 stated 11 not stated
11 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand1/4 disclosed
Performance3/4 disclosed
Physical0/2 disclosed
Sensing and autonomy3/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Lifting capacity
20kg
48 robot hands state a lifting capacity
15 state a higher figure, 21 a lower one. 4 more state exactly the same figure. 7 state only a bound (≥ or ≤) and are not ranked.
Notes
AIDIN ROBOTICS showed the hand at AW 2026 in Seoul; its news page describes it as a product due for release this year (translated from the Korean).
The producer's LinkedIn post of 6 November 2026 describes the hand with “16 degrees of freedom” and does not separate the actively driven degrees of freedom from the total joint count.
AIDIN ROBOTICS' news page on the AW 2026 showing reproduces a trade-press report that says the payload was raised from 15 kg in the first generation to 20 kg (translated from the Korean). The grasp type and test conditions are not documented.
The producer's product page, which does not use the name Gen2, says: “Robot Hand Version 2 is scheduled for release in the second quarter of 2026”.
The producer's downloads page gives its address in “Dongan-gu, Anyang-si, Gyeonggi-do, South Korea”.
Sources
One line per source, not per figure: a source has one retrieval date.
- Akr.linkedin.com/company/aidin-roboticsMain source. Retrieved 9 November 2026
- Bgithub.com/aidinrobotics/aidin-hand2-ros2Secondary. Retrieved 10 November 2026
- Cgithub.com/aidinrobotics/aidin-hand2-sdk/blob/main/docs/en/10_python_usage_guide.mdSecondary. Retrieved 10 November 2026
- Dgithub.com/aidinrobotics/aidin-hand2-sdk/blob/main/docs/en/05_can_fd_setup.mdSecondary. Retrieved 10 November 2026
- Egithub.com/aidinrobotics/aidin-hand2-sdk/blob/main/docs/en/07_cpp_usage_guide.mdSecondary. Retrieved 10 November 2026
- Faidinrobotics.co.kr/post/%EC%97%90%EC%9D%B4%EB%94%98%EB%A1%9C%EB%B3%B4%ED%8B%B1%EC%8A%A4-aw-2026%EC%84%9C-2%EC%84%B8%EB%8C%80-%EB%A1%9C%EB%B4%87%ED%95%B8%EB%93%9C-%EA%B3%B5%EA%B0%9CSecondary. Retrieved 10 November 2026
- Ggithub.com/aidinrobotics/aidin-hand2-sdkSecondary. Retrieved 10 November 2026
- Haidinrobotics.co.kr/en/robotic-handRetrieved 9 November 2026