Key figures as stated by the manufacturer
4 of 6 stated · 2 gaps- Weight 16kg35.3lbOur conversion from 16 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- Payload, walking at most 5kgat most 11lbOur conversion from 5 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- Runtime not stated
- Max speed at most 13.32km/hat most 8.28mphOur conversion from 13.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- IP rating IP54A
- Indicative price not stated
Deviations and variants in the key figures (4)
Weight
NoteBase curb weight.
Payload, walking
NoteMaximum walking payload for dynamic gait.
Max speed
NoteMaximum running speed.
IP rating
NoteHigh dust/water resistance; easily copes with splashing, damp, muddy, and sandy environments.
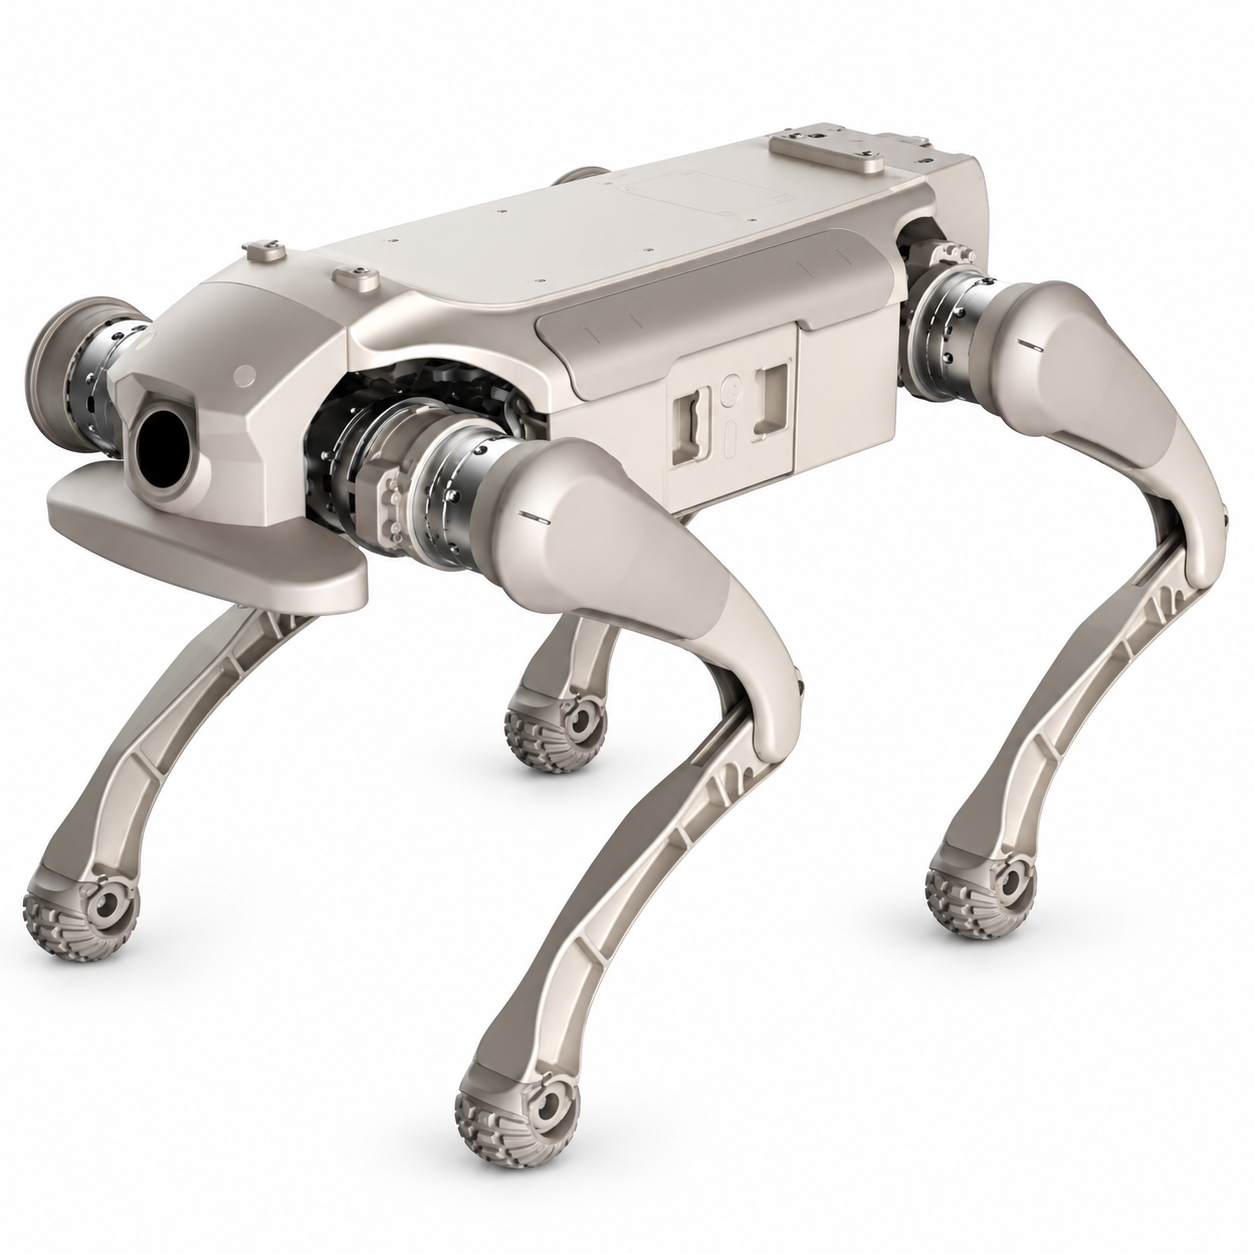
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Robust mobility to handle various complex terrains. Standardized interfaces supporting various mounted modules for multi-scenario deployment
Source: agibot.com · Retrieved
This category is not our assessment.
Every field in the schema
16 of 33 fields statedImperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 16kg35.3lbOur conversion from 16 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteBase curb weight. |
| Length | 63cm24.8inOur conversion from 63 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteBody length. |
| Width | 36cm14.2inOur conversion from 36 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteBody width. |
| Height | 42cm16.5inOur conversion from 42 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteStanding height. |
| Degrees of freedom | 12DoF | A Note12 active joint degrees of freedom (3 per leg). |
| Payload, walking | at most 5kgat most 11lbOur conversion from 5 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteMaximum walking payload for dynamic gait. |
| Payload, standing | not stated | |
| Max speed | at most 13.32km/hat most 8.28mphOur conversion from 13.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteMaximum running speed. |
| Max slope | at most 40° | A NoteMaximum slope angle. |
| Single obstacle | at most 35cmat most 13.8inOur conversion from 35 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteForward/upward jumping clearance above ground. |
| Stair step, continuous | at most 16cmat most 6.3inOur conversion from 16 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteSupports continuous climbing of stairs up to 16 cm high. |
| IP rating | IP54 | A NoteHigh dust/water resistance; easily copes with splashing, damp, muddy, and sandy environments. |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | Compatible with optional LiDAR module via payload mounting interface | A NoteOptional expansion module, not base sensor. |
| Cameras | Compatible with depth camera and image transmission modules | A NoteModular expansion. |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | C++ Python | A NoteOpen SDK for secondary development; URDF modeling supported for Isaac Sim and MuJoCo simulation. |
| Autonomy level | RL gait control, self-balancing, anti-tipping, disturbance rejection; intelligent follow requires user secondary development | A NoteIntelligent follow requires secondary development. |
| Payload and expansion | ||
| Mounting interface | Standardized mechanical interfaces supporting various mounted modules | A NoteProvides standardized interfaces supporting various mounted modules for multi-scenario deployment. |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Stair step and payload each exist in two variants. Only compare fields with the same label.
Notes
- Developed by AGIBOT Innovation (Shanghai) Technology Co., Ltd., also known as Zhiyuan Robotics.
- Dual-encoder joint motors deliver 48 N·m peak torque and need no zero-position calibration; an open SDK supports payload mounting.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for AGIBOT D1 Ultrahttps://www.agibot.com/products/D1Ultra
Sources
- A Manufacturer product page. www.agibot.com/products/D1Ultra · Retrieved
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.