Key figures as stated by the manufacturer
4 of 6 stated · 2 gaps- Weight 23kg50.7lbOur conversion from 23 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- Payload, walking 10kg22lbOur conversion from 10 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- Runtime 40minWarning: load condition not statedB
- Max speed 11.88km/h7.38mphOur conversion from 11.88 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- IP rating not stated
- Indicative price not stated
Deviations and variants in the key figures (3)
Payload, walking
CaveatThe producer's label is Max.load, without distinguishing walking/standing. The placement is an inference.
Runtime
CaveatTHE PRODUCER ITSELF FLAGS THE FIGURE AS DOUBTFUL. The Chinese table writes 40min followed by the characters for doubtful, pending verification. It appears ONLY in Chinese and is invisible to anyone reading English.
Max speed
CaveatSpeed and slope are in ONE row, separated by a full-width semicolon (U+FF1B): 3.3m/s; 30 degrees. A parser that reads the row as ONE field gets nonsense.
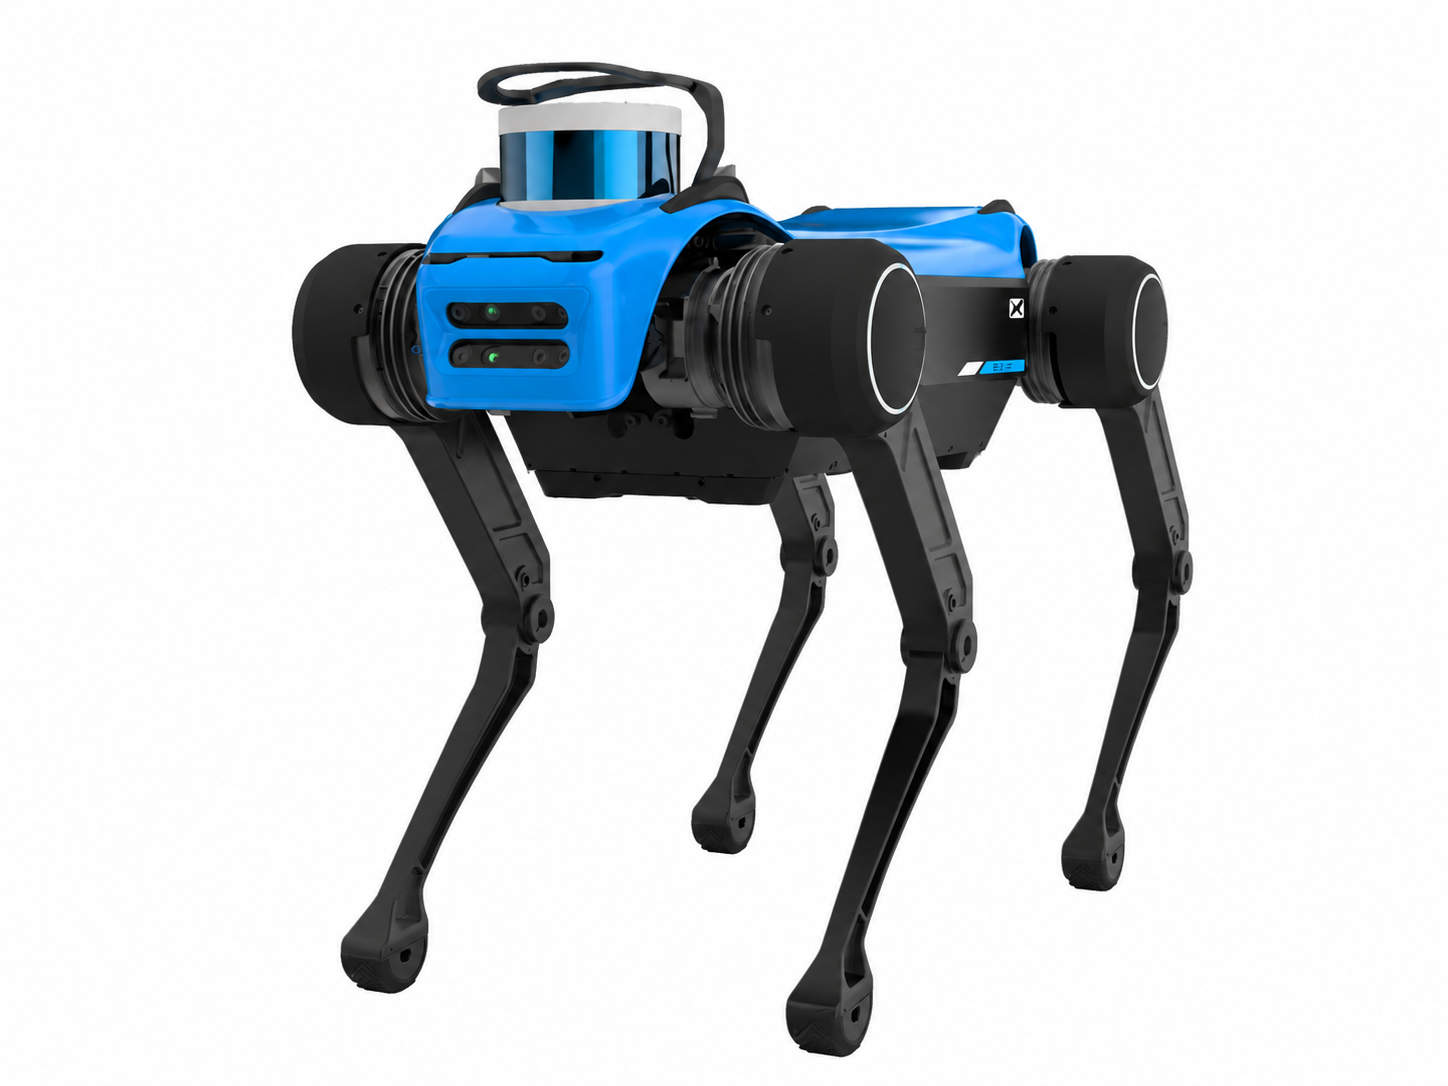
Manufacturer's own photo.
Intended use, per the manufacturer
Source: deeprobotics.cn · Retrieved
READ IN FULL, NOTHING FOUND. The Mini also isn’t in the producer’s Chinese product panel, where Lite3, X20, and X30 each get an application label. The page’s own text is about technology ("deep learning", "visual perception"), not about who the robot is for.
This category is not our assessment.
Every field in the schema
11 of 33 fields statedImperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 23kg50.7lbOur conversion from 23 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Length | 70cm27.6inOur conversion from 70 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Width | 40cm15.7inOur conversion from 40 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Height | 50cm19.7inOur conversion from 50 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A |
| Degrees of freedom | not stated | |
| Payload, walking | 10kg22lbOur conversion from 10 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A CaveatThe producer's label is Max.load, without distinguishing walking/standing. The placement is an inference. |
| Payload, standing | not stated | |
| Max speed | 11.88km/h7.38mphOur conversion from 11.88 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A CaveatSpeed and slope are in ONE row, separated by a full-width semicolon (U+FF1B): 3.3m/s; 30 degrees. A parser that reads the row as ONE field gets nonsense. |
| Max slope | 30° | A CaveatIt's in the same row as the speed – see speed. |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | 620Wh | B NoteONLY the Chinese page is usable. The English page prints Battery capacity 10kg – kilograms in an energy field, probably Max.load 10kg copied into the wrong row. The correct figure can only be found by reading the original language, not the English translation. |
| Runtime | 40minWarning: load condition not stated | B CaveatTHE PRODUCER ITSELF FLAGS THE FIGURE AS DOUBTFUL. The Chinese table writes 40min followed by the characters for doubtful, pending verification. It appears ONLY in Chinese and is invisible to anyone reading English. |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | not stated | |
| Onboard compute | Perception processor: Intel Core i7; CPU: NVIDIA Jetson Xavier NX | A NoteThe producer spells it NIVIDIA. The misspelling is the producer’s own; we render the name correctly here and note the error. Note the split: the perception processor is an Intel i7, while the row labeled CPU is a Jetson. |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | WiFi USB Bluetooth | A NoteWiFi and Bluetooth are connections, not physical ports. The field is counted as filled because the producer itself lists them as an interface list. |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Stair step and payload each exist in two variants. Only compare fields with the same label.
Notes
- The manufacturer's English-language page has a unit error in the battery figure; the Chinese-language page states the correct value.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Jueying Minihttps://deeprobotics.cn/en/index/product2.html
Sources
- A Manufacturer product page. deeprobotics.cn/en/index/product2.html · Retrieved
- B www.deeprobotics.cn/robot/index/product2.html · Retrieved
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.