ESA / ETH Zurich Robotic Systems LabSwitzerland2018
SpaceBok
- Demonstrator
- 20–40 kg
- Research and development
Key figures as stated by the manufacturer
1 of 6 stated · 5 gapsDemonstrator- Weight 22kg48.5lbOur conversion from 22 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.A
- Payload, walking not stated
- Runtime not stated
- Max speed not stated
- IP rating not stated
- Indicative price not stated
Deviations and variants in the key figures (1)
Weight
NoteTotal mass of 22 kg including reaction wheel attitude stabilization mechanism.
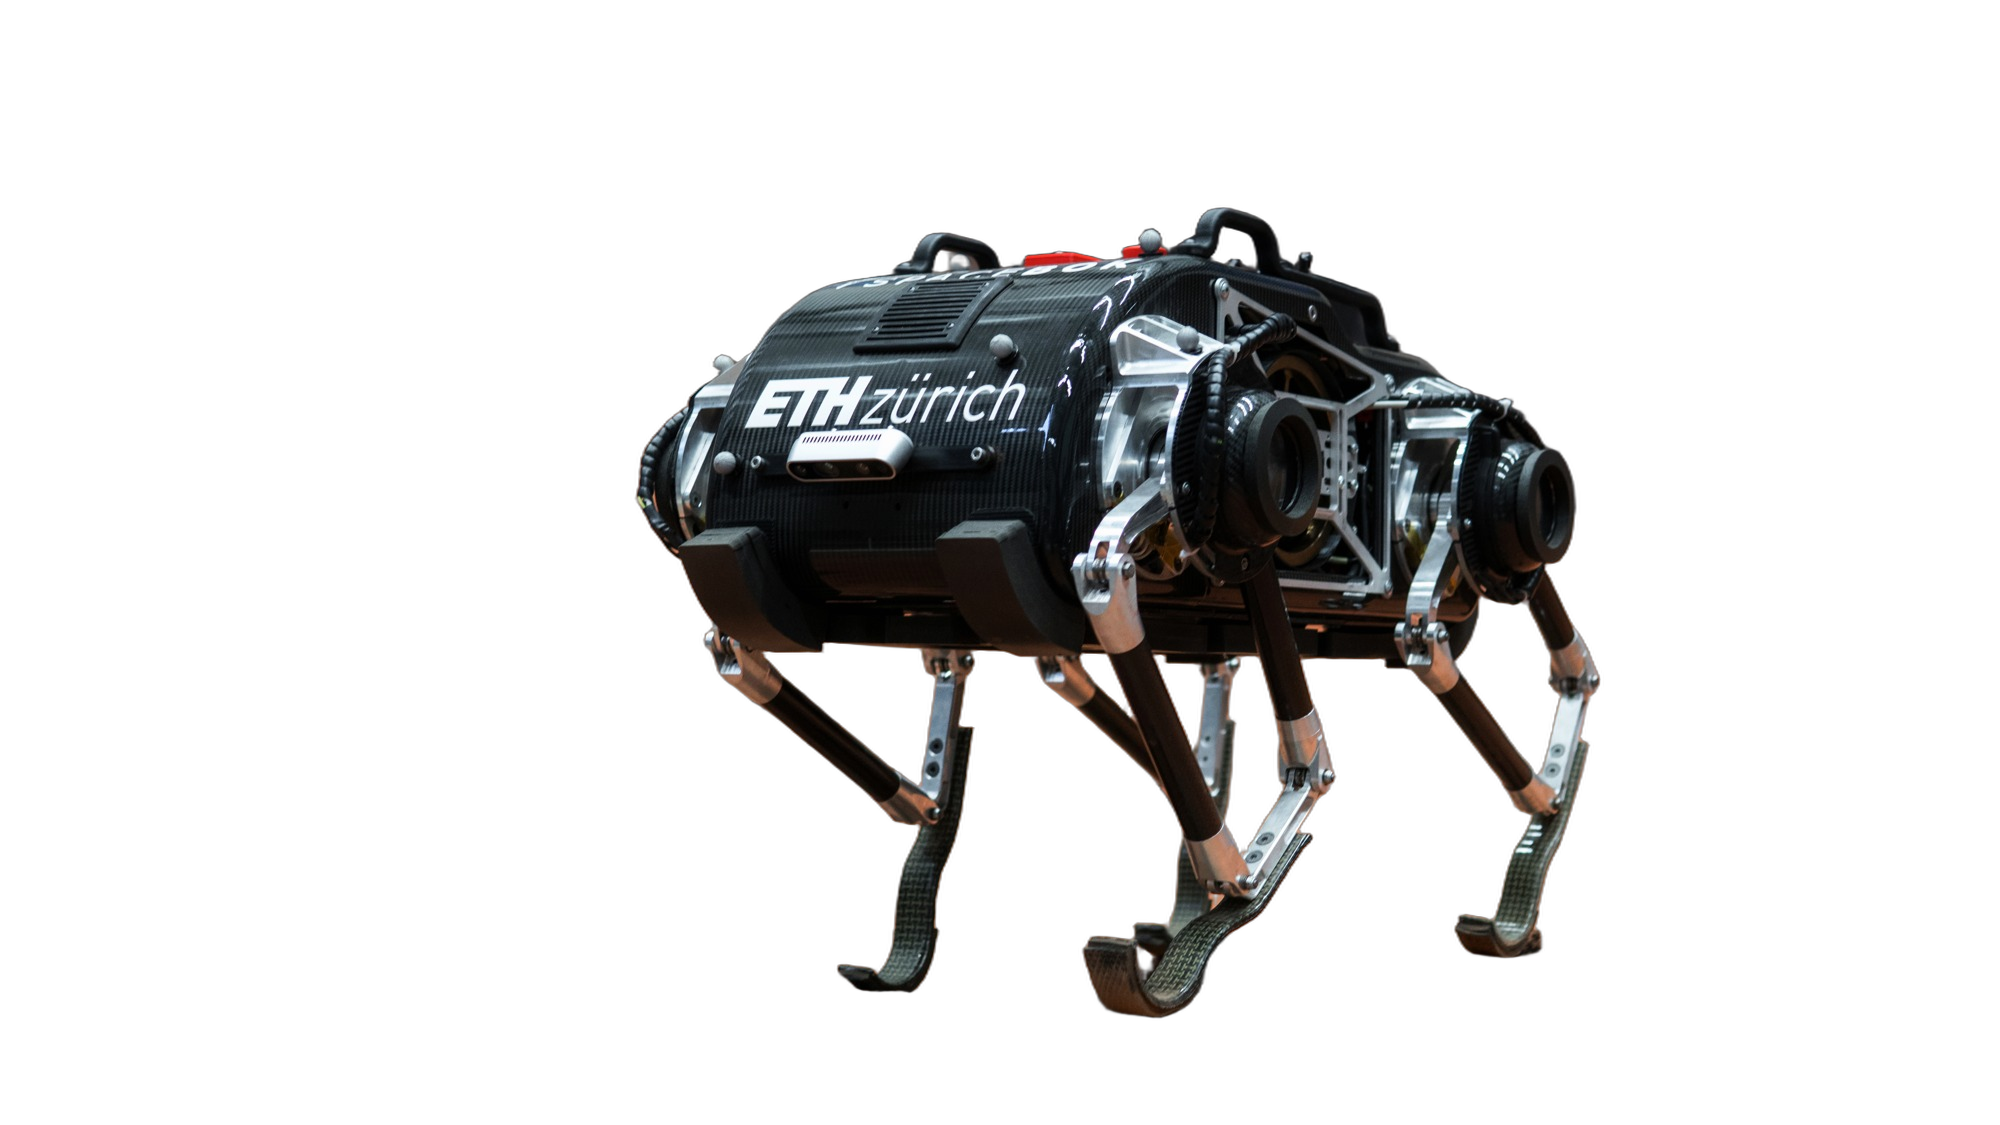
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Designed to explore low-gravity celestial bodies such as asteroids and the Moon through repetitive dynamic jumping and attitude-controlled flight phases.
Source: esa.int · Retrieved
This category is not our assessment.
Every field in the schema
3 of 33 fields statedImperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 22kg48.5lbOur conversion from 22 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteTotal mass of 22 kg including reaction wheel attitude stabilization mechanism. |
| Length | not stated | |
| Width | not stated | |
| Height | not stated | |
| Degrees of freedom | 8DoF | A Note8 actuated leg joints (2 DoF per leg: hip and knee flexion/extension) plus internal reaction wheel for flight attitude control. |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | 200cm78.7inOur conversion from 200 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | A NoteDemonstrated dynamic jumping height up to 2.0 m in simulated lunar gravity. |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | not stated | |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Stair step and payload each exist in two variants. Only compare fields with the same label.
Notes
- A planetary-exploration quadruped developed by ETH Zurich and ZHAW Zurich under the Robotic Systems Lab.
- Tested at ESA's ESTEC centre to study dynamic jumping and walking in simulated low-gravity environments like the Moon and asteroids.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for SpaceBokhttps://www.esa.int/ESA_Multimedia/Images/2019/07/Spacebok_jumping_in_simulated_lunar_gravity
Sources
- A Manufacturer product page. www.esa.int/ESA_Multimedia/Images/2019/07/Spacebok_jumping_in_simulated_lunar_gravity · Retrieved
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.