Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight A 230kg507lbOur conversion from 230 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime not stated
- Max speed A 6km/h3.73mphOur conversion from 6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Weight
Note Weight including battery.
Payload, moving
Note The page gives 3 kg rated and 7 kg maximum load for a single arm. That is an arm-specific figure, not a figure for what the whole robot can carry.
Max speed
Note Maximum speed of the mobile base.
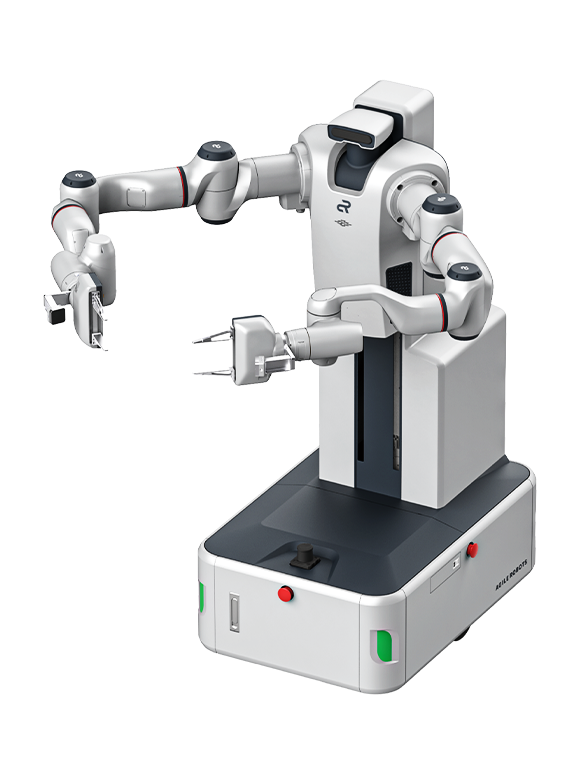
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
H10-W is an intelligent robot for research, education, commercial and consumer use.
Source: agile-robots.cn · Retrieved
This category is not our assessment.
Full specifications
5 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 230kg507lbOur conversion from 230 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Weight including battery. A |
| Length | not stated | |
| Width | not stated | |
| Height | not stated | Note The page gives overall dimensions of 934 × 929 × 1820 mm without saying which figure is length, width or height. A |
| Degrees of freedom | at least 21DoF | Note Whole-body figure excluding the hands, given as "21+". Each arm is a 7-DoF arm (Diana 3) with joint torque sensors; a two-finger gripper or a dexterous hand is optional. A |
| Payload, moving | not stated | Note The page gives 3 kg rated and 7 kg maximum load for a single arm. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Note The page gives 3 kg rated and 7 kg maximum load for a single arm. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | 6km/h3.73mphOur conversion from 6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum speed of the mobile base. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | 2D LiDAR and 3D LiDAR. | Note Listed under environment perception, together with four depth cameras. A |
| Cameras | 4 depth cameras. | Note Listed under environment perception, together with a 2D and a 3D LiDAR. A |
| Onboard compute | not stated | |
| ROS 2 | not stated | Note The page lists Fast DDS and gRPC as the distributed communication interfaces, at up to 1 kHz; it does not mention ROS 2. A |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The page describes H10-W as an assistant robot for research, education, commercial and consumer use, built from a wheeled base, two 7-DoF arms and a linearly lifting torso, that picks up, carries and places objects on spoken commands.
- The torso lifts at up to 300 mm/s.
- The mobile base uses two-wheel differential drive.
- The model is listed on the Chinese website of Agile Robots, whose footer gives the company's Munich address first and a Beijing office second.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for H10-Whttps://www.agile-robots.cn/product/29
Sources
-
A
Manufacturer product page. www.
agile-robots. · Retrievedcn/ product/ 29
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.