Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A approximately 260kgapproximately 573lbOur conversion from 260 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A 240–300minWarning: load condition not stated
- Max speed A 4.32km/h2.68mphOur conversion from 4.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Weight
Note The page's weight row is qualified as approximate (Chinese page; no English version exists for this site).
Runtime
Caveat No task/load condition given for the 4-5h runtime figure; the page separately also states a 5-hour figure in a core-parameters summary elsewhere (Chinese page).
Max speed
Note The speed row is qualified as an unloaded, real-machine measurement (Chinese page).
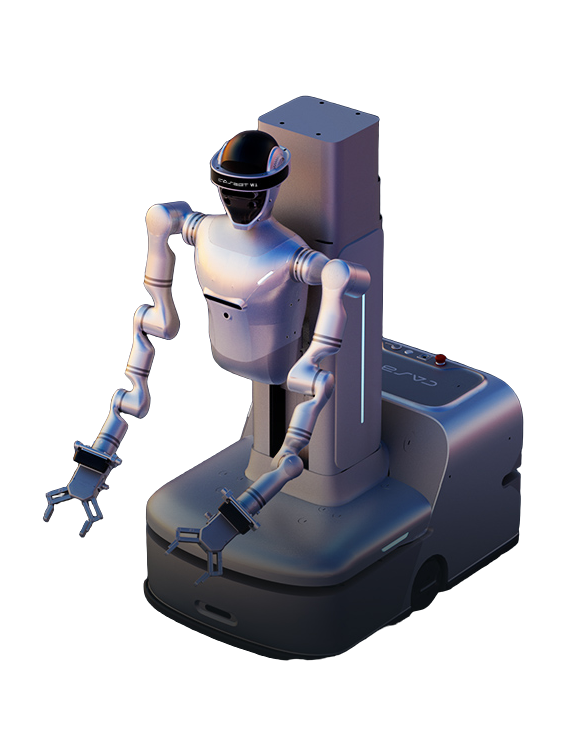
Manufacturer's own photo.
Intended use, per the manufacturer
Source: casbot.tech · Retrieved
The page lists five scenario headings with short Chinese descriptions covering industrial manufacturing, warehousing pick-and-place, retail product picking and guidance, machine-room/workshop inspection, and education/research task customization. No English-language version of this page exists (checked with a ?lang=en request, byte-identical to the Chinese page), so no verbatim English quote can be given for these categories.
This category is not our assessment.
Full specifications
18 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | approximately 260kgapproximately 573lbOur conversion from 260 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note The page's weight row is qualified as approximate (Chinese page; no English version exists for this site). A |
| Length | 95cm37.4inOur conversion from 95 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Compact-footprint length, from the whole-machine dimensions row; the third dimension (height) is adjustable via the lift column. A |
| Width | 61.5cm24.2inOur conversion from 61.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Same footprint row as length. A |
| Height | 112–210cm44.1–82.7inOur conversion from 112–210 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Adjustable via the lift column; consistent with the footprint's varying third dimension (1.12-2.1m). A |
| Degrees of freedom | 20DoF | Note Breakdown: head 2 + waist 1 + lift column 1 + chassis 2 + arms 7x2 = 20; the 2-DoF gripper end-effector is listed separately. A |
| Payload, moving | not stated | |
| Payload, standing | 10kg22lbOur conversion from 10 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Whole-machine load-capacity figure from the core-parameters summary (Chinese page), distinct from the 5 kg single-arm rated payload; the page does not say whether it applies while moving. A |
| Max speed | 4.32km/h2.68mphOur conversion from 4.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note The speed row is qualified as an unloaded, real-machine measurement (Chinese page). A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | IP68 | Note From the page's IP-protection row (Chinese page; no English version exists for this site). A |
| Operating temperature, low | 5°C41°FOur conversion from 5 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer also states humidity 25-85% (non-condensing) alongside the temperature range. A |
| Operating temperature, high | 40°C104°FOur conversion from 40 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer also states humidity 25-85% (non-condensing) alongside the temperature range. A |
| Power | ||
| Battery | not stated | Note Producer states 48V, 25Ah (LiFePO4); no combined Wh figure is given. A |
| Runtime | 240–300minWarning: load condition not stated | Caveat No task/load condition given for the 4-5h runtime figure; the page separately also states a 5-hour figure in a core-parameters summary elsewhere (Chinese page). A |
| Hot-swap battery | not stated | |
| Charge time | 120min | Note From the page's power-system table (Chinese page; no English version exists for this site). A |
| Docking station | yes | Note From the accessories list, one charging dock (Chinese page), distinct from the separately named autonomous-charging method. A |
| Sensing and autonomy | ||
| LiDAR | 360° expandable spherical LiDAR at the abdomen. | Note From the page's interaction-components row. A |
| Cameras | 2x RGB-D (structured-light) cameras, one at each arm end; 1x RGB-D camera on the chest; 1x binocular camera on the head. | Note Combines the arm-parameter row with the interaction-component and head rows. A |
| Onboard compute | Industrial PC: Intel i9 CPU + NVIDIA RTX 4060 GPU. | Note From the page's compute/connectivity table, main and motion-control row (Chinese page; no English version exists for this site). A |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Note No named autonomy level is given. The page describes a three-layer "CASBOT Embodied Brain 2.0" software architecture instead: a brain layer for language understanding, spatial reasoning and task decomposition; a cerebellum layer for reinforcement-learning-based strategy optimisation; and a body layer coordinating the arms, lift and chassis (Chinese page; no English version exists for this site). A |
| Payload and expansion | ||
| Mounting interface | Standard structural and communication interface at the wrist, supporting a gripper, dexterous hand, suction cup, or other end effectors. | Note From the page's extensibility row (Chinese page; no English version exists for this site). A |
| Power out | not stated | |
| Data ports | Ethernet (100 Mbps) | Note Producer's own row also lists WiFi, 4G and Bluetooth as wireless connectivity, not physical data ports. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- CASBOT's own site also lists a separate bipedal product, CASBOT 02 (CASBOT O2), distinct from W1, the wheeled product.
- Total degrees of freedom (20) is broken down on the page as: head 2 (yaw, pitch) + waist 1 (pitch) + lift column 1 + chassis 2 + arms 7x2 = 20; the gripper end-effector's own 2 DoF is listed separately and can be upgraded to a dexterous hand.
- Height is adjustable via the lift column (112-210cm); the same range is confirmed separately as the third figure in the compact/extended footprint dimensions (0.95x0.615x1.12m / 0.95x0.615x2.1m).
- A whole-machine load-capacity figure of 10kg appears in the page's core-parameters summary (Chinese page; no English version exists for this site), separate from the 5kg per-arm rated payload in the arm-parameters table; the robot does not walk, so this whole-machine figure is the closest available match to a whole-body payload.
- Battery is stated as 48V, 25Ah; no combined Wh figure is given.
- The page's accessories list includes one charging dock, distinct from the separately named autonomous-charging method described elsewhere on the page.
- Page disclaimer: all parameters and performance figures are stated as derived from theoretical calculation and laboratory testing, and actual performance may vary by environment and conditions.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for W1https://casbot.tech/product/w1
Sources
-
A
Manufacturer product page. casbot.
tech/ · Retrievedproduct/ w1
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.