Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A approximately 220kgapproximately 485lbOur conversion from 220 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime B 240–360minWarning: load condition not stated
- Max speed A 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Weight
Note About 220 kg in the Chinese specification table; the English page gives 220kg.
Payload, moving
Caveat The page gives a rated payload of 12 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry.
Runtime
Caveat Continuous runtime; no load condition is given.
Max speed
Note Maximum speed in the Chinese specification table.
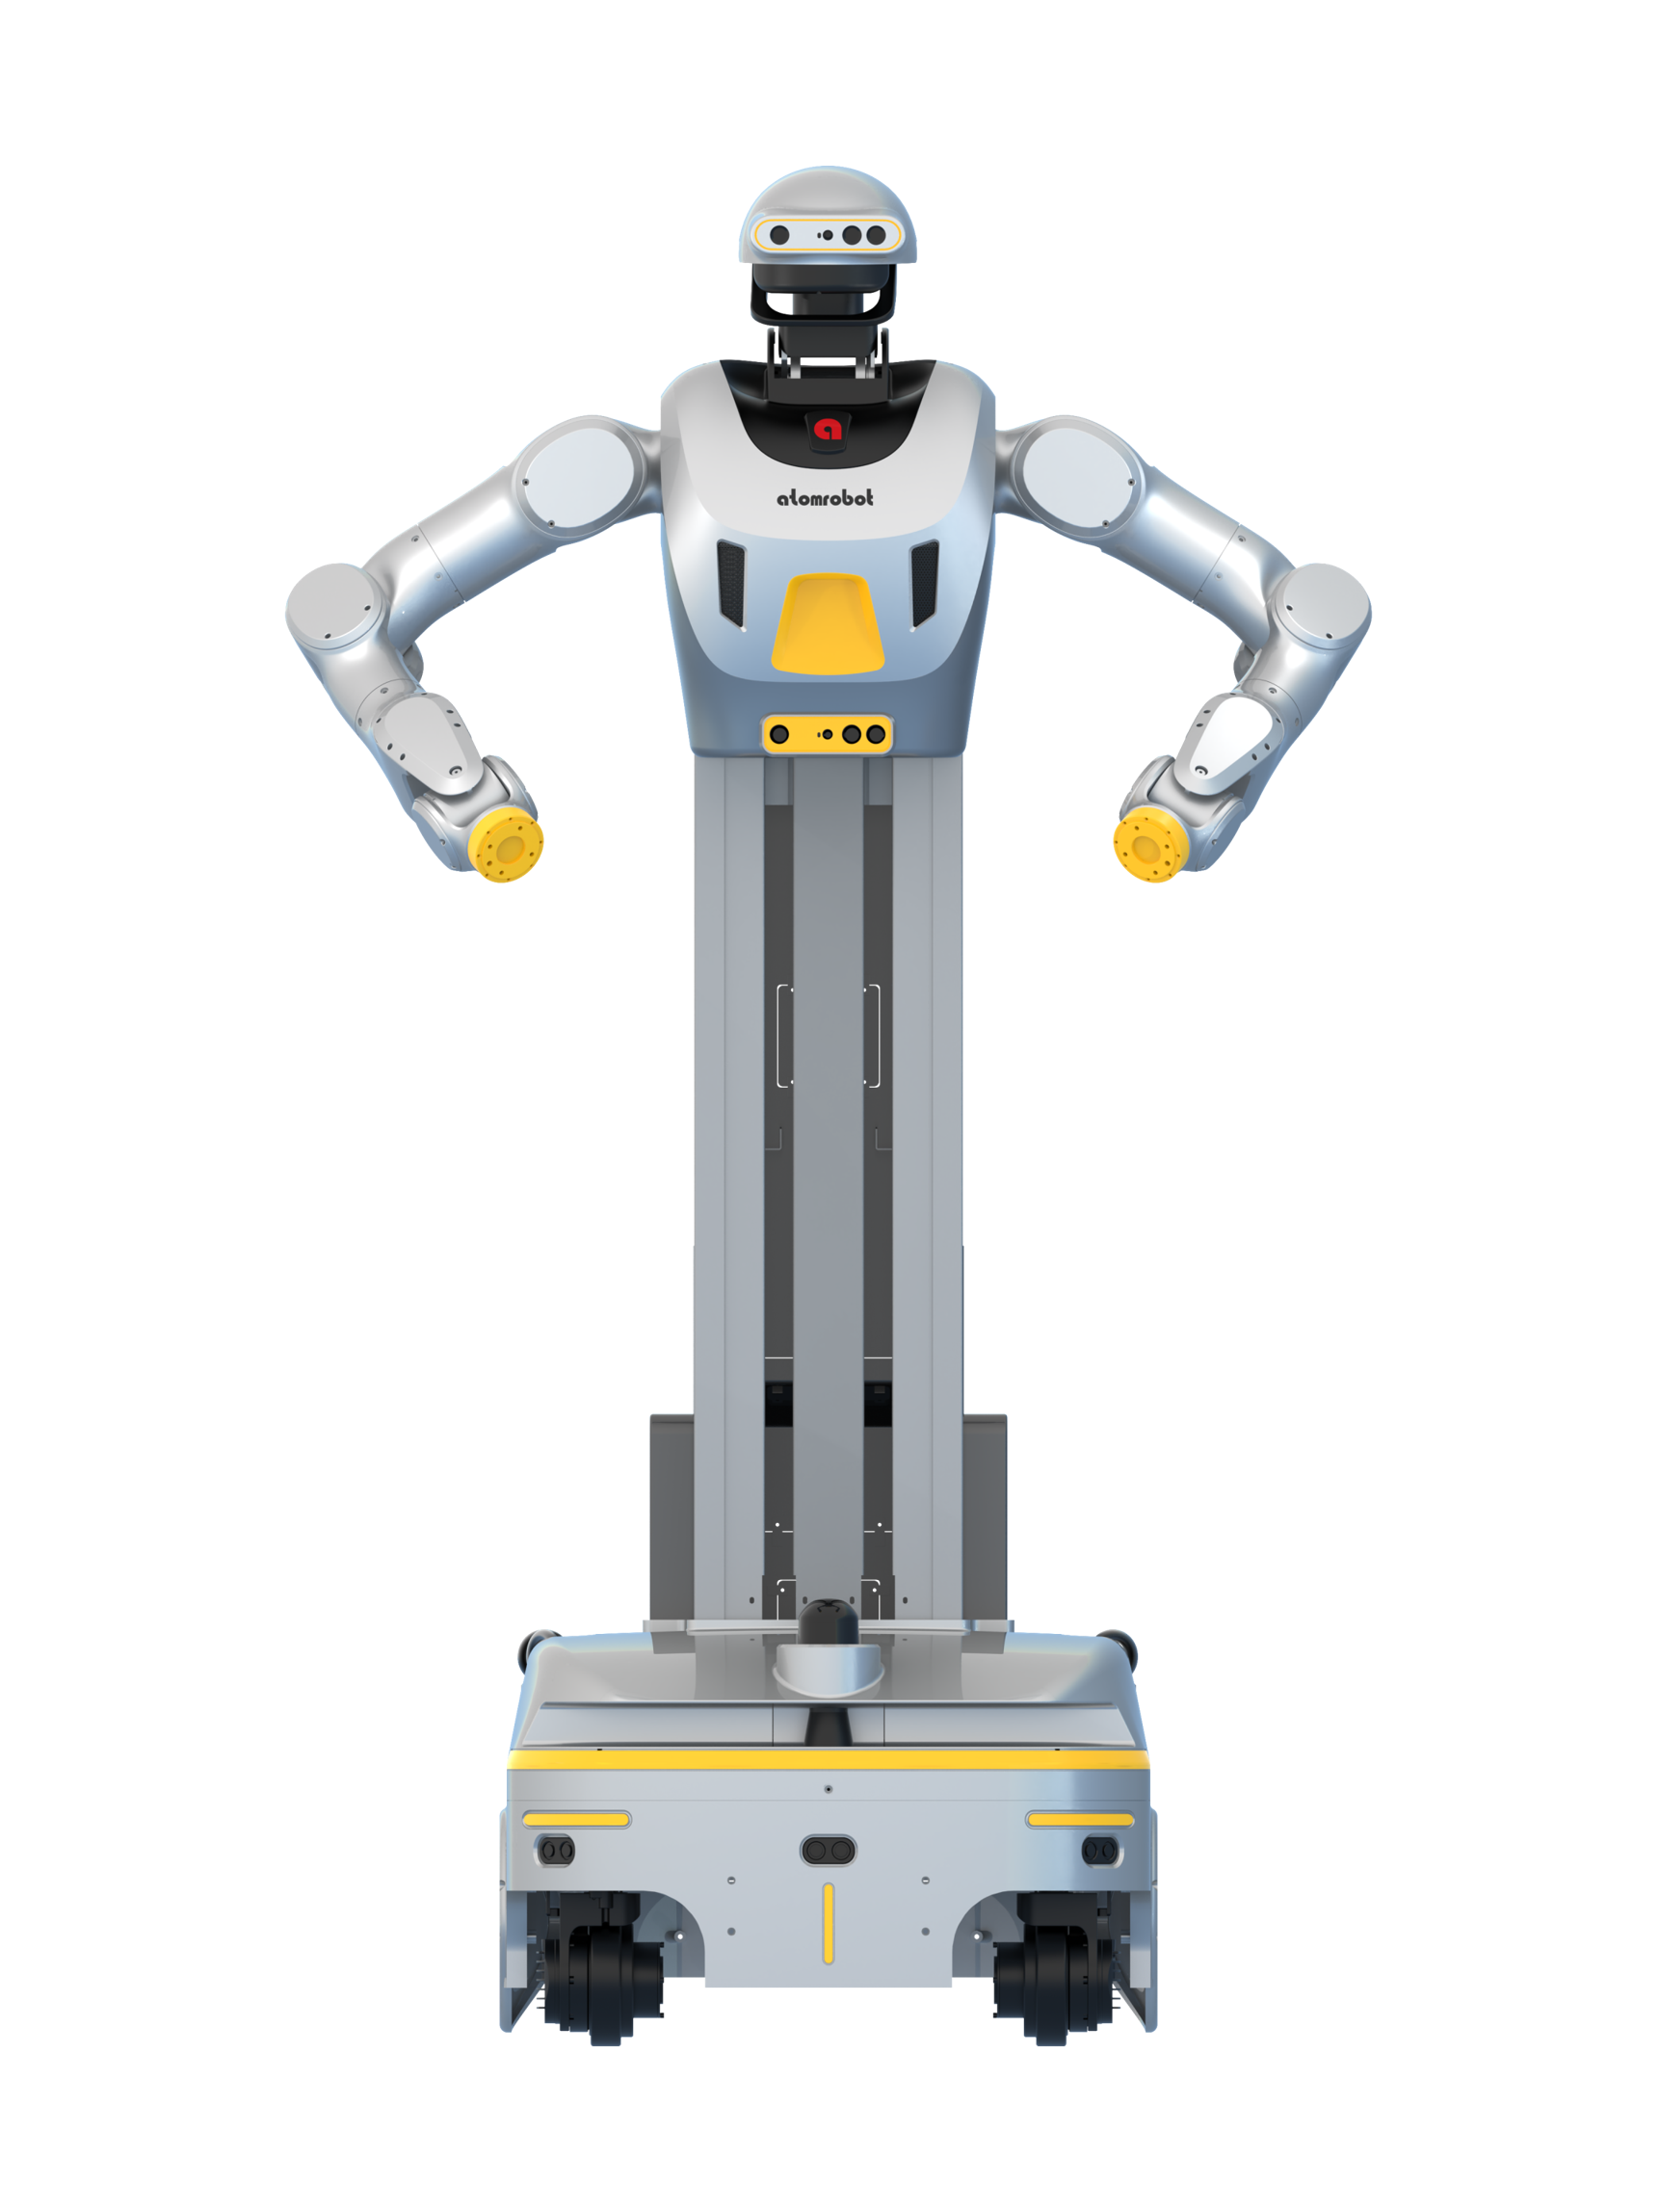
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
it is widely deployed in 3C & new energy flexible production lines, warehouse rack logistics, hotel front desk reception and intelligent home service scenes.
Source: atomrobot.ai · Retrieved
This category is not our assessment.
Full specifications
13 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | approximately 220kgapproximately 485lbOur conversion from 220 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note About 220 kg in the Chinese specification table; the English page gives 220kg. A |
| Length | 73.5cm28.9inOur conversion from 73.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size in the Chinese specification table, given as L*W*H 735*644*1851 mm. A |
| Width | 64.4cm25.4inOur conversion from 64.4 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size in the Chinese specification table, given as L*W*H 735*644*1851 mm. A |
| Height | 185.1cm72.9inOur conversion from 185.1 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size in the Chinese specification table. The torso lifts through 800 mm. A |
| Degrees of freedom | 25DoF | Note The page gives 7 in each arm, an adjustable lifting torso and 4 in the chassis, without a figure for the torso. B |
| Payload, moving | not stated | Caveat The page gives a rated payload of 12 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry. B |
| Payload, standing | not stated | Caveat The page gives a rated payload of 12 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry. B |
| Max speed | 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum speed in the Chinese specification table. A |
| Max slope | 6° | Note Maximum climbing angle in the Chinese specification table. A |
| Single obstacle | at most 4cmat most 1.57inOur conversion from 4 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Maximum obstacle height in the Chinese specification table. A |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Caveat The page gives a 48 V battery and no energy figure. B |
| Runtime | 240–360minWarning: load condition not stated | Caveat Continuous runtime; no load condition is given. B |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | yes | Note The page lists wired charging and automatic charging docking. B |
| Sensing and autonomy | ||
| LiDAR | 2 multi-line LiDAR and 2 single-line LiDAR. | Note The sensor suite also has 8 ultrasonic radars. B |
| Cameras | 2 depth cameras. | Note Sensor suite as listed on the page. B |
| Onboard compute | 12-core Arm Cortex A78AE CPU and 2048-core NVIDIA CUDA GPU. | Note Computing platform named on the page. B |
| ROS 2 | not stated | |
| SDK languages | not stated | Note The page names open secondary development interfaces and no programming language. B |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer calls the SkyRise AR-H2 a mobile dual-arm humanoid robot with an 800 mm vertical lifting stroke.
- The chassis has omnidirectional four-wheel drive and turns in place.
- The wrist interface offers RS-485 communication and a 24 V power supply for custom end tools.
- The producer's Chinese site gives an address in Binhai New Area, Tianjin, China.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for SkyRise AR-H2https://www.atomrobot.ai/products/embodied-intelligent-robots/skyrise-ar-h2/
Sources
-
A
www.
atomrobot. · Retrievedcom/ robot/ 163/ 1881 -
B
Manufacturer product page. www.
atomrobot. · Retrievedai/ products/ embodied-intelligent-robots/ skyrise-ar-h2/
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.