Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 75kg165lbOur conversion from 75 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A 360minWarning: load condition not stated
- Max speed A 4.32km/h2.68mphOur conversion from 4.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Weight
Note Weight in the basic parameters.
Payload, moving
Caveat The mobile platform is listed with a maximum load of 50 kg. That is a chassis figure, not a figure for what the whole robot can carry.
Runtime
Caveat Full-load operating time; no load figure is given. Standby time is 8 h.
Max speed
Note Maximum speed of the mobile platform.
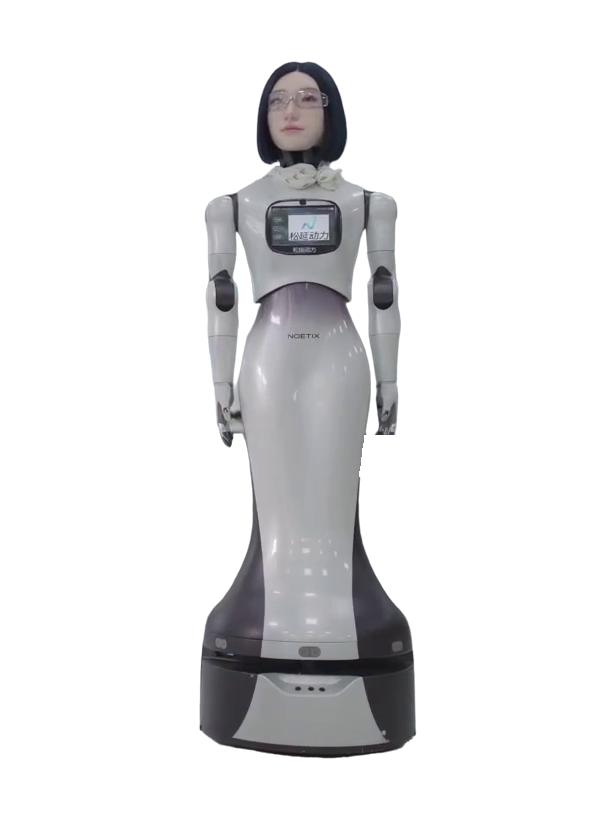
Manufacturer's own photo.
Still frame from the manufacturer's video.
Intended use, per the manufacturer
Source: noetixrobotics.com · Retrieved
The product page lists showroom guided tours, government and enterprise services, corporate front desk reception, school education and research, and hospital medical triage.
This category is not our assessment.
Full specifications
13 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 75kg165lbOur conversion from 75 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Weight in the basic parameters. A |
| Length | 52.5cm20.7inOur conversion from 52.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size, labelled length, width and height. A |
| Width | 52.5cm20.7inOur conversion from 52.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size, labelled length, width and height. A |
| Height | 170cm66.9inOur conversion from 170 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall size, labelled length, width and height. A |
| Degrees of freedom | 54DoF | Note Active degrees of freedom of the wheeled full-body form. B |
| Payload, moving | not stated | Caveat The mobile platform is listed with a maximum load of 50 kg. That is a chassis figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Caveat Each arm is rated for 2 kg. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | 4.32km/h2.68mphOur conversion from 4.32 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum speed of the mobile platform. A |
| Max slope | 10° | Note Maximum incline of the mobile platform. A |
| Single obstacle | 1.8cm0.71inOur conversion from 1.8 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum step height; the maximum gap width is 30 mm. A |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Caveat The battery is listed as 32 Ah (21 V~29.4 V); no watt-hour figure is given. A |
| Runtime | 360minWarning: load condition not stated | Caveat Full-load operating time; no load figure is given. Standby time is 8 h. A |
| Hot-swap battery | not stated | |
| Charge time | 390min | Note Standard charging time; fast charging takes 2 h. A |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | LiDAR with a scan radius of 0–30 m. | Note LiDAR sensor of the mobile platform. A |
| Cameras | 2 RGB cameras in the eyes and 1 RGB camera in the chest. | Note Listed under the biomimetic head parameters, together with a linear four-microphone array on the chest. A |
| Onboard compute | Intel J1900 quad-core 2.0 GHz CPU; NPU 6 TOPS*2. | Note Main controller of the mobile platform. A |
| ROS 2 | not stated | |
| SDK languages | not stated | Caveat An Android platform SDK is provided; no programming languages are named. B |
| Autonomy level | not stated | Caveat The page describes indoor positioning, navigation and obstacle avoidance; it names no autonomy level. B |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Noetix's company timeline calls the robot W1, formerly Hobbs W1; the specification page still gives its full name as Biomimetic Robot Hobbs W1 (translated from the Chinese).
- Noetix's company timeline lists the release of the bionic robot W1 under October 2025 (translated from the Chinese).
- The head has biomimetic platinum silicone skin paired with real human-hair material.
- The specification page says the delivered product may differ in appearance from the version shown on the website.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for W1https://www.noetixrobotics.com/en/spec/W1
Sources
-
A
Manufacturer product page. www.
noetixrobotics. · Retrievedcom/ en/ spec/ W1 -
B
www.
noetixrobotics. · Retrievedcom/ en/ detail/ W1
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.