Key figures as stated by the manufacturer
1 of 6 stated · 5 gaps- Weight A 32kg70.5lbOur conversion from 32 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking not stated
- Runtime not stated
- Max speed not stated
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (1)
Weight
Note Producer's own English wording: "Weight (with Battery): 32 kg".
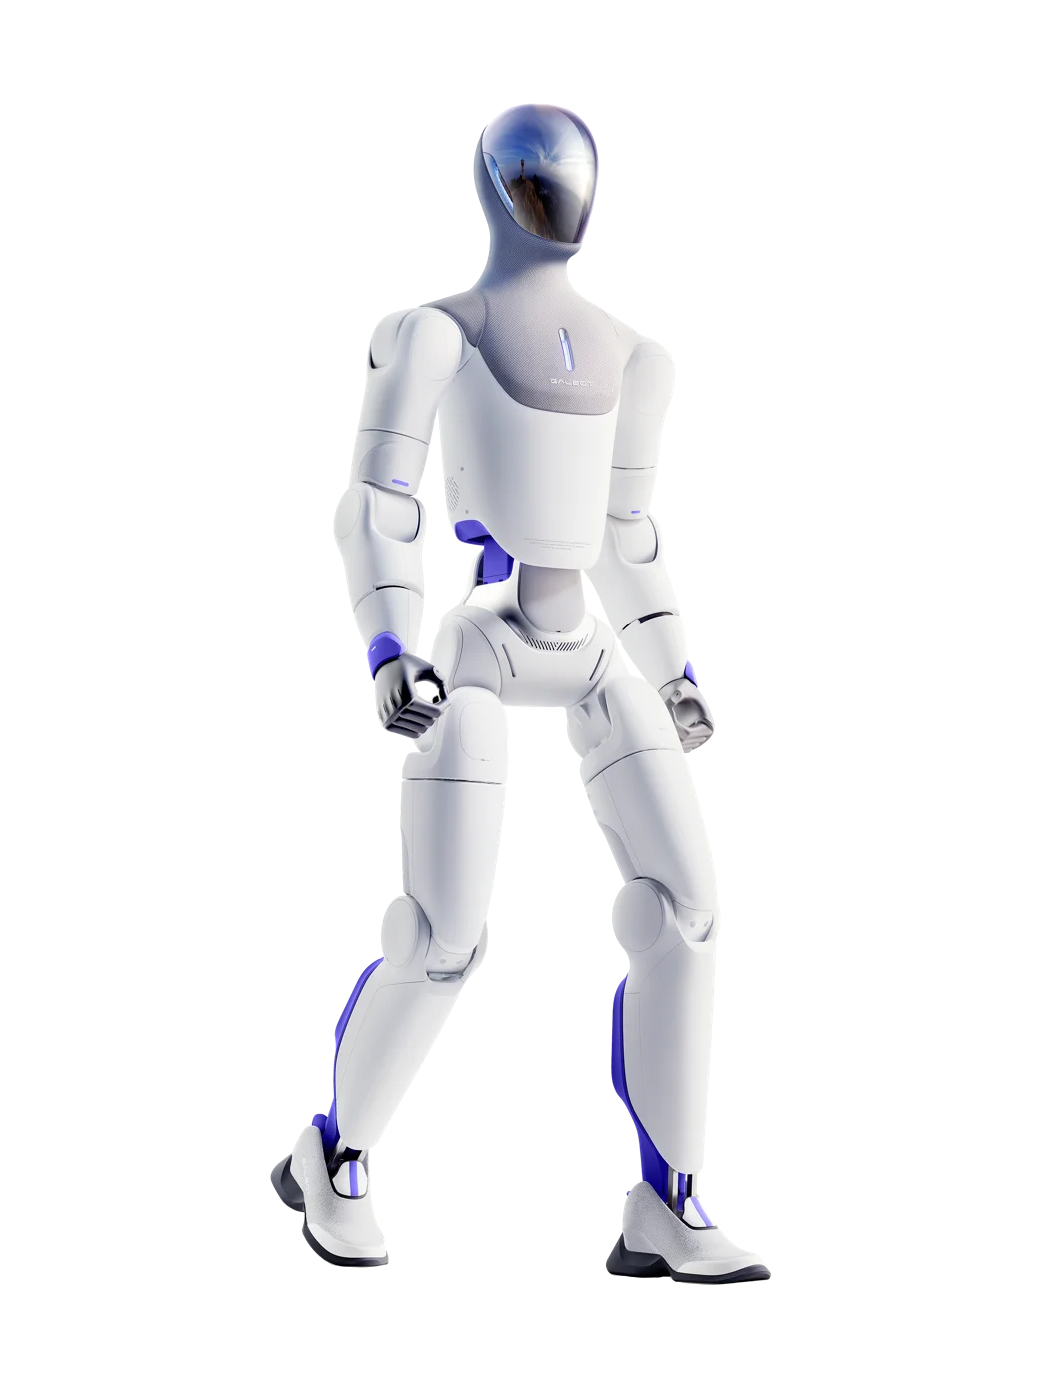
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Galbot ET1 - a humanoid robot for entertainment and performance
Source: galbot.com · Retrieved
This category is not our assessment.
Full specifications
5 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 32kg70.5lbOur conversion from 32 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer's own English wording: "Weight (with Battery): 32 kg". A |
| Length | not stated | |
| Width | not stated | |
| Height | 125cm49.2inOur conversion from 125 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer's own English wording: "Standing Height: 1250 mm". A |
| Degrees of freedom | 26DoF | Note Standard configuration total ("Standard: 26"). Pro/Flagship configurations state "26 + 12 (with dexterous hands)". A |
| Payload, walking | not stated | |
| Payload, standing | not stated | Note Same as the walking-payload figure above. A |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | not stated | |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | Note Only a stereo camera is named under "Visual Perception"; no lidar is mentioned. A |
| Cameras | Stereo camera. | Note From the page's "Visual Perception" row. A |
| Onboard compute | RK3588 + RDK X5 (main processor). | Note Base/Standard main processor. Pro configuration adds an Orin Nano (40 TOPS) module and Flagship configuration adds an NX (100 TOPS) module, described as "high-performance compute" - not included in the base compute value here. A |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Note The page describes real-time perception, reasoning and action planning, and learning new movement skills through human interaction under "Core Capabilities" - but this is a capability description, not a named operational autonomy level. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Galbot's own site names three humanoid/service robots - ET1, G1 (Galbot's own G1, unrelated to Unitree's G1) and S1 - at www.galbot.com; each is listed separately.
- Source: Galbot's bilingual Chinese/English product page (www.galbot.com/et1).
- Degrees of freedom is 26 for the Standard configuration; Pro and Flagship configurations add a pair of dexterous hands for a stated "26 + 12" total. The figure given is the Standard one (26).
- The page describes four specific use scenarios: theme-park interaction, storefront greeting, live dance performance, and live comedy/talk-show performance.
- The page does not say where Galbot is based. The city comes from the Beijing Municipal Bureau of Investment Promotion (invest.beijing.gov.cn), which places Galbot's headquarters in Haidian, Beijing.
- TechEBlog reported on 28 August 2026 that Galbot's ET1, its first two-legged machine, debuted at the World Robot Conference in August 2026.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for ET1https://www.galbot.com/et1
Sources
-
A
Manufacturer product page. www.
galbot. · Retrievedcom/ et1
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.