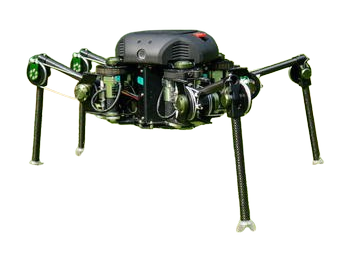
LittleDog
A quadruped robot from the United States, first released 2006.
Sources retrieved: 6 September 2026 (A)
- Status
- Discontinued
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- LittleDog was designed to explore the fundamental relationships among motor learning, dynamic control, perception of the environment, and rough terrain locomotion.Source and note: Intended use, per the manufacturerA cs.cmu.edu/~cga/bdi/LittleDog_User_Guide_V1.0.0.pdf · Retrieved 6 September 2026
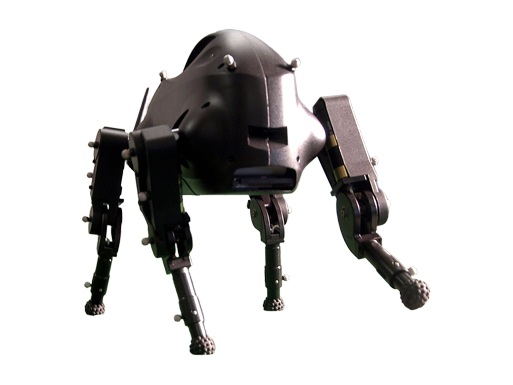
- Person
175 cm68.9 in - 34 cm13.4 inHeight
14.3 cm5.63 in
Manufacturer's own photo.
Drawn at one scale next to a 175 cm person, from the figures the maker states: height 14.3 cm and length 34 cm.Drawn at one scale next to a 68.9 in person, from the figures the maker states, converted to inches: height 5.63 in and length 13.4 in.
Specifications
13/33 specifications disclosed 20 not stated
20 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical5/14 disclosed
Power2/5 disclosed
Sensing and autonomy5/6 disclosed
C++Payload and expansion1/3 disclosed
RS232 USB Analog/Digital I/O VGA Keyboard EthernetCommercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Height
14.3cm5.63inOur conversion from 143 mm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
89 quadrupeds state a height
86 state a higher figure, 0 a lower one.
Weight
3kg6.61lbOur conversion from 3 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
124 quadrupeds state a weight
116 state a higher figure, 3 a lower one. Log scale: each step along the axis multiplies the value.
Degrees of freedom
12DoF
76 quadrupeds state degrees of freedom
15 state a higher figure, 4 a lower one. 56 more state exactly the same figure.
Runtime
approximately 30minNote: load condition not stated
104 quadrupeds state a runtime
96 state a higher figure, 0 a lower one.
Notes
A small four-legged robot built for DARPA's Learning Locomotion program, used by university teams including Stanford, CMU, USC and MIT from about 2006 to 2010.
About a dozen identical units, each with a common software API and a motion-capture rig, were distributed to research teams so results could be compared directly.
Sources
One line per source, not per figure: a source has one retrieval date.
- Acs.cmu.edu/~cga/bdi/LittleDog_User_Guide_V1.0.0.pdfSecondary. Retrieved 6 September 2026
More robots
Same manufacturer
BigDogBoston Dynamics
- No photograph
CheetahBoston Dynamics
LS3 (Legged Squad Support System)Boston Dynamics
SpotBoston Dynamics
Spot ClassicBoston Dynamics
WildCatBoston Dynamics
All robots from Boston Dynamics