Cheetah-Cub
A quadruped robot from Switzerland, first released 2013.
Sources retrieved: 7 September 2026 (A, B)
- Status
- Discontinued
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- Light, fast, robust and affordable feline-inspired platform for locomotion researchSource and note: Intended use, per the manufacturerA epfl.ch/labs/biorob/research/quadruped/quadruped-past/cheetah-cub-2/ · Retrieved 7 September 2026
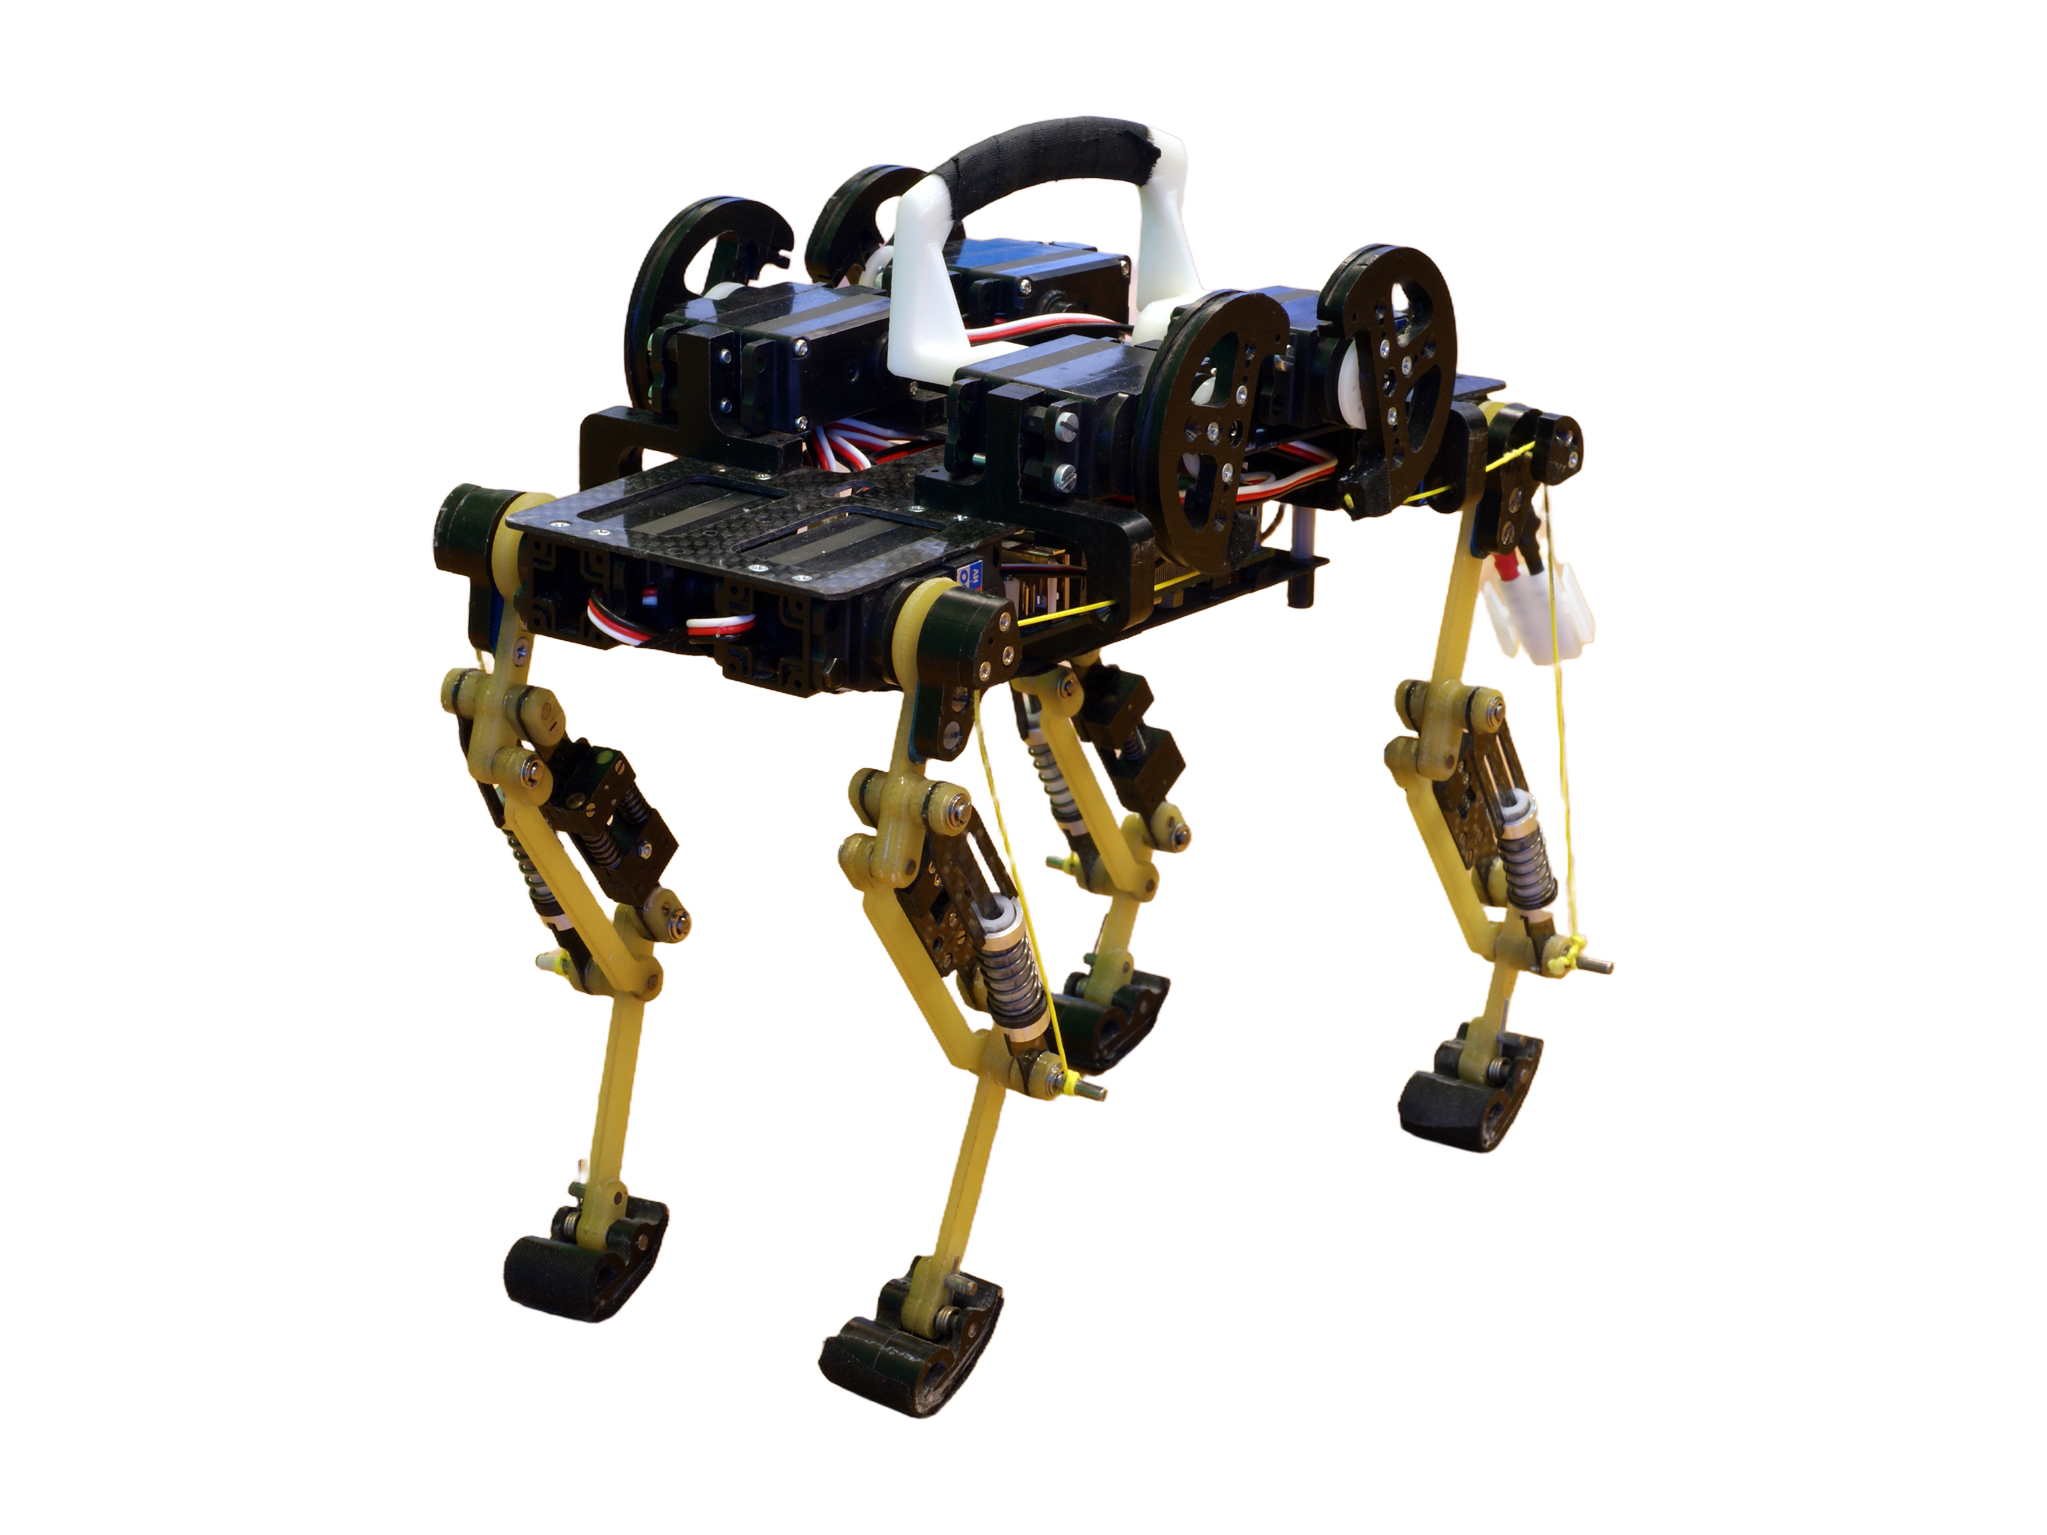
Manufacturer's own photo.
Specifications
5/33 specifications disclosed 28 not stated
28 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical3/14 disclosed
Power0/5 disclosed
Sensing and autonomy2/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Weight
1.1kg2.43lbOur conversion from 1.1 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
124 quadrupeds state a weight
119 state a higher figure, 0 a lower one. Log scale: each step along the axis multiplies the value.
Degrees of freedom
8DoF
76 quadrupeds state degrees of freedom
72 state a higher figure, 0 a lower one. 3 more state exactly the same figure.
Max speed
2.124km/h1.32mphOur conversion from 0.59 m/s. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
113 quadrupeds state a top speed
82 state a higher figure, 0 a lower one.
Notes
A compact research quadruped from EPFL's Biorobotics Lab; its walk and trot gaits were learned from horse motion-capture data. Galloping failed since its trunk is rigid, unlike a cat's spine.
A later enhanced variant is reported by EPFL as the fastest robot in its weight class (under 30 kg), reaching about 6.9 body lengths per second.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aepfl.ch/labs/biorob/research/quadruped/quadruped-past/cheetah-cub-2/Main source. Retrieved 7 September 2026
- Bspectrum.ieee.org/epfl-iit-cheetah-cub-quadruped-kmpsSecondary. Retrieved 7 September 2026
More robots
Same manufacturer
All robots from EPFL Biorobotics Laboratory