Solo 12
A quadruped robot from Germany, first released 2020.
Sources retrieved: 4 September 2026 (B) · 7 September 2026 (A)
- Status
- In production
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- Designed as an open-source, accessible research platform for dynamic locomotion, reinforcement learning, and whole-body control.Source and note: Intended use, per the manufacturerB open-dynamic-robot-initiative.github.io · Retrieved 4 September 2026
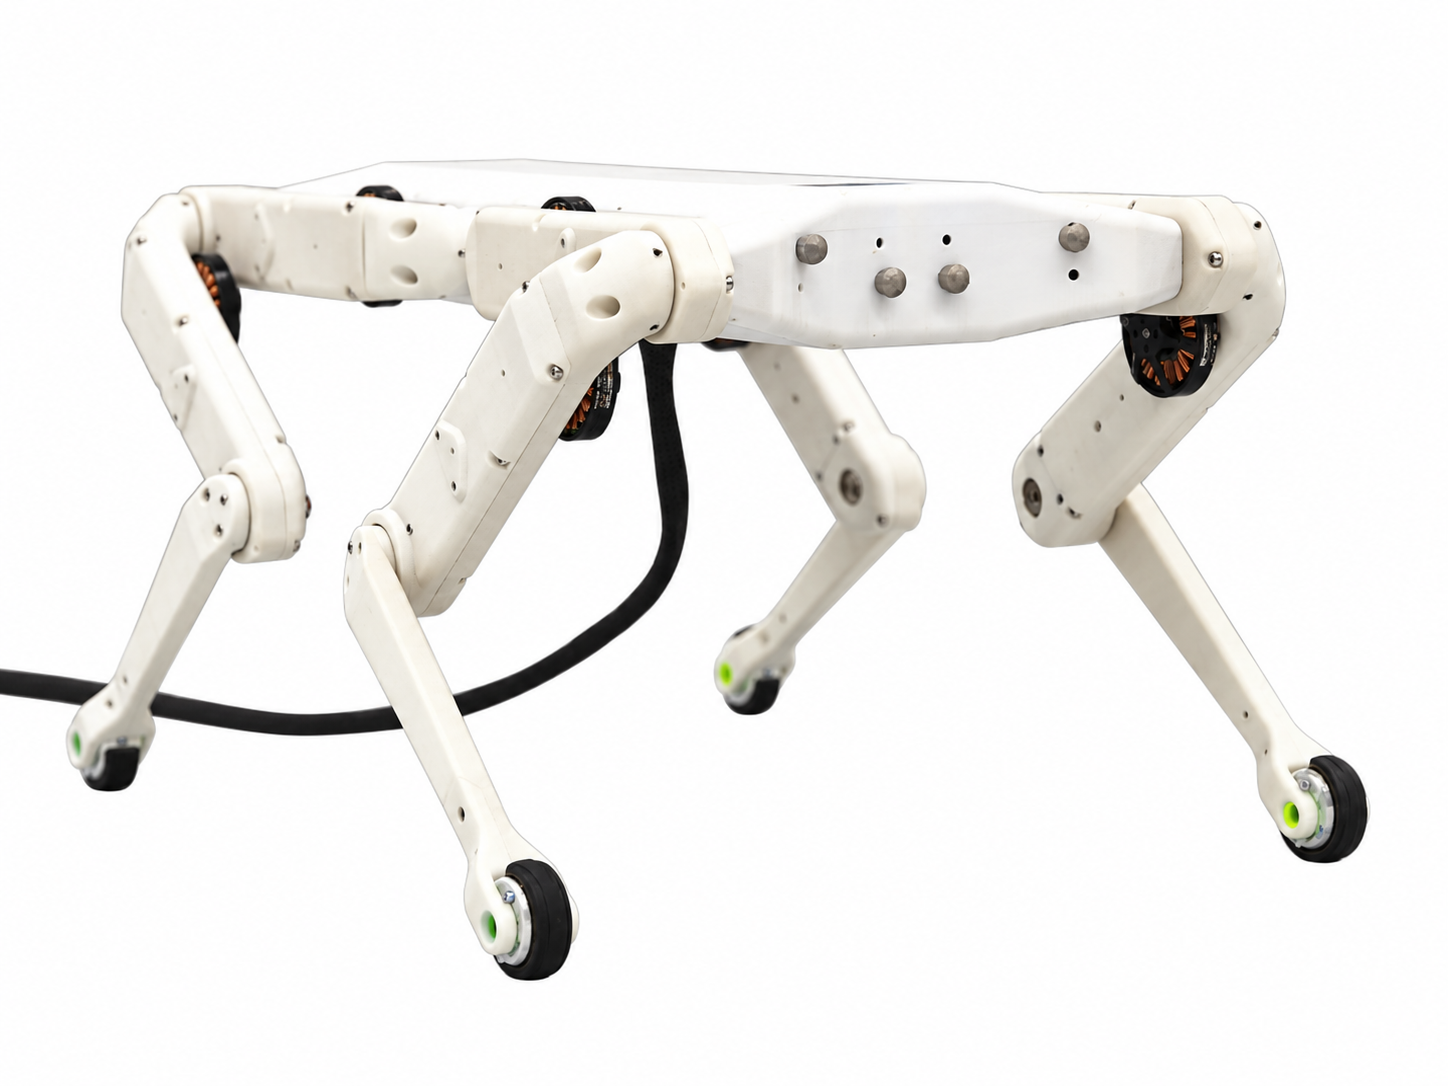
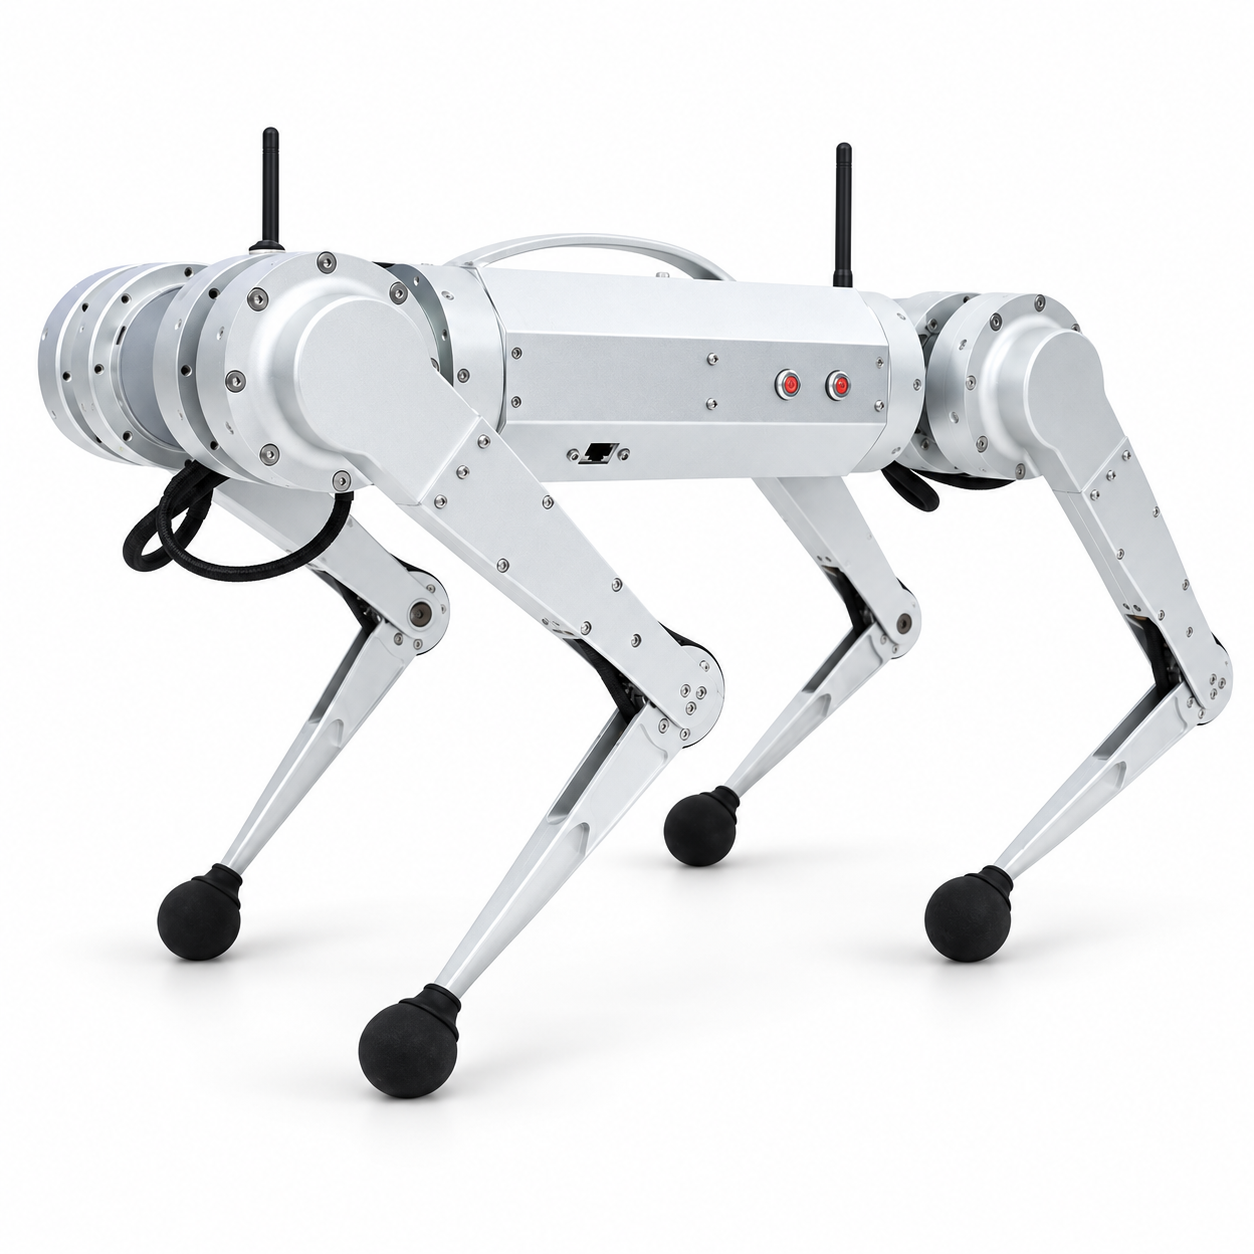
Manufacturer's own photo.
Specifications
4/33 specifications disclosed 29 not stated
29 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical4/14 disclosed
Power0/5 disclosed
Sensing and autonomy0/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Weight
2.5kg5.51lbOur conversion from 2.5 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
124 quadrupeds state a weight
117 state a higher figure, 2 a lower one. Log scale: each step along the axis multiplies the value.
Degrees of freedom
12DoF
76 quadrupeds state degrees of freedom
15 state a higher figure, 4 a lower one. 56 more state exactly the same figure.
Notes
A lightweight open-source research quadruped from LAAS-CNRS, the Max Planck Institute for Intelligent Systems, and NYU.
Manufactured and sold by PAL Robotics in Barcelona; uses 12 torque-controlled brushless actuator modules with high impact compliance.
The initiative names its partners as the Max Planck Institute for Intelligent Systems in Germany, New York University in the USA and LAAS-CNRS in France; it does not give one home country.
Sources
One line per source, not per figure: a source has one retrieval date.
- Agithub.com/open-dynamic-robot-initiative/open_robot_actuator_hardware/blob/master/mechanics/quadruped_robot_12dof_v1/README.mdRetrieved 7 September 2026
- Bopen-dynamic-robot-initiative.github.ioMain source. Retrieved 4 September 2026
More robots
Same manufacturer
All robots from Open Dynamic Robot Initiative