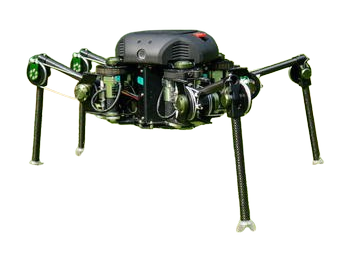
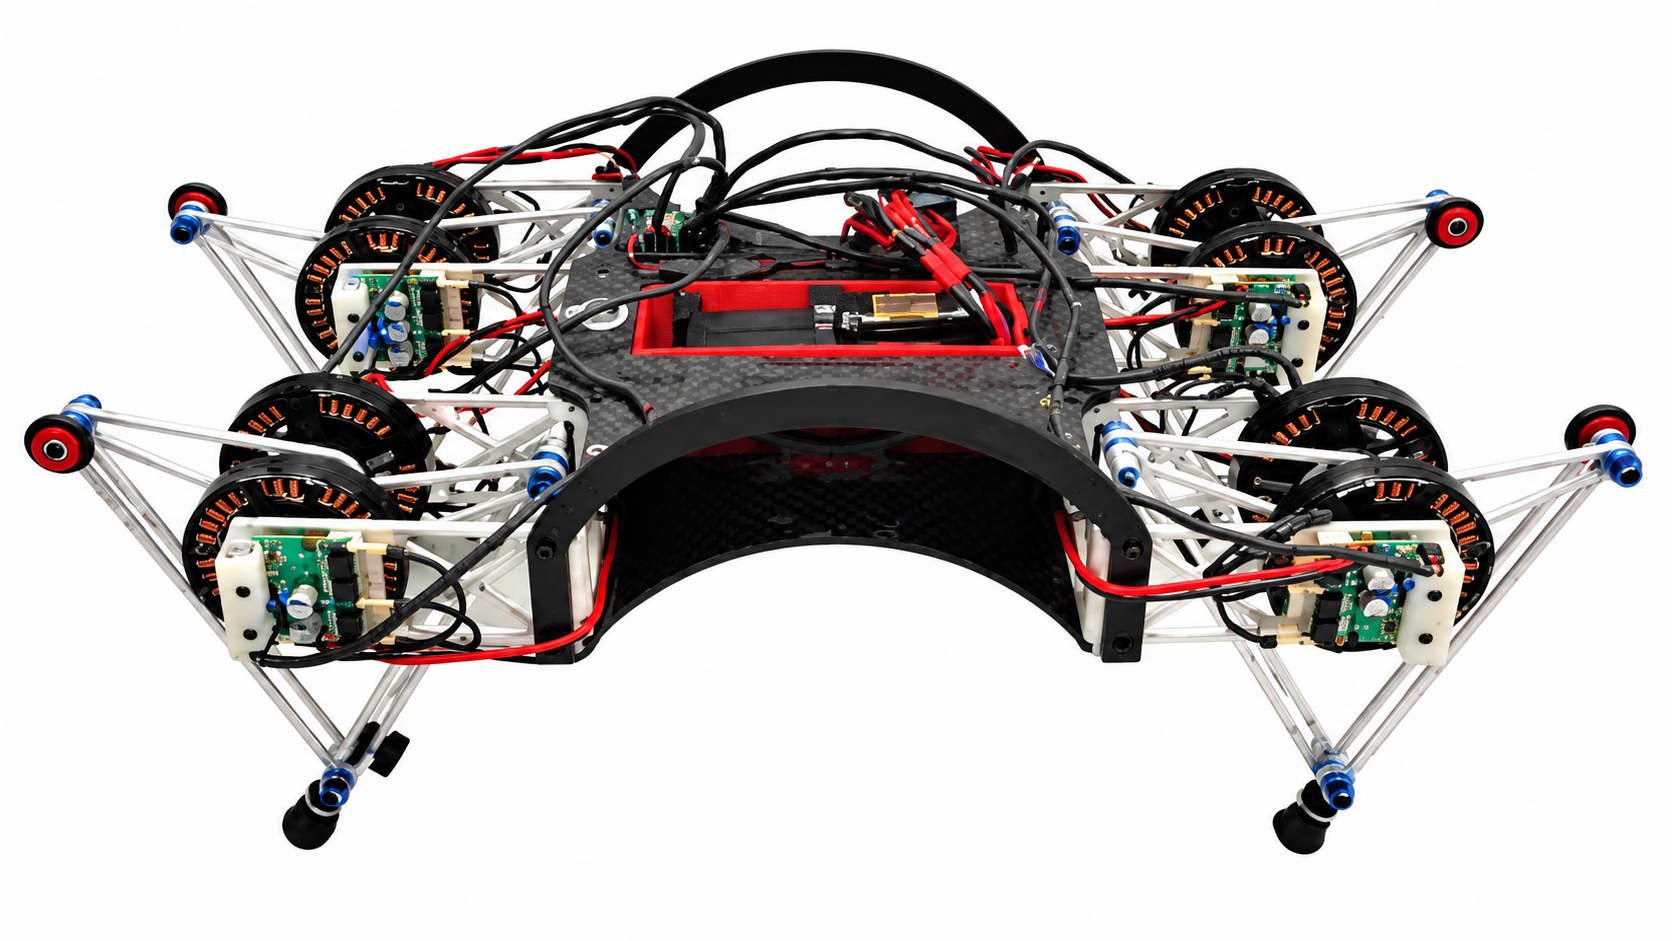
Solo 8
A quadruped robot from Germany, first released 2019.
Sources retrieved: 4 September 2026 (A, B)
- Status
- Discontinued
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- An Open Torque-Controlled Modular Robot Architecture for Legged Locomotion Research.Source and note: Intended use, per the manufacturerB open-dynamic-robot-initiative.github.io · Retrieved 4 September 2026
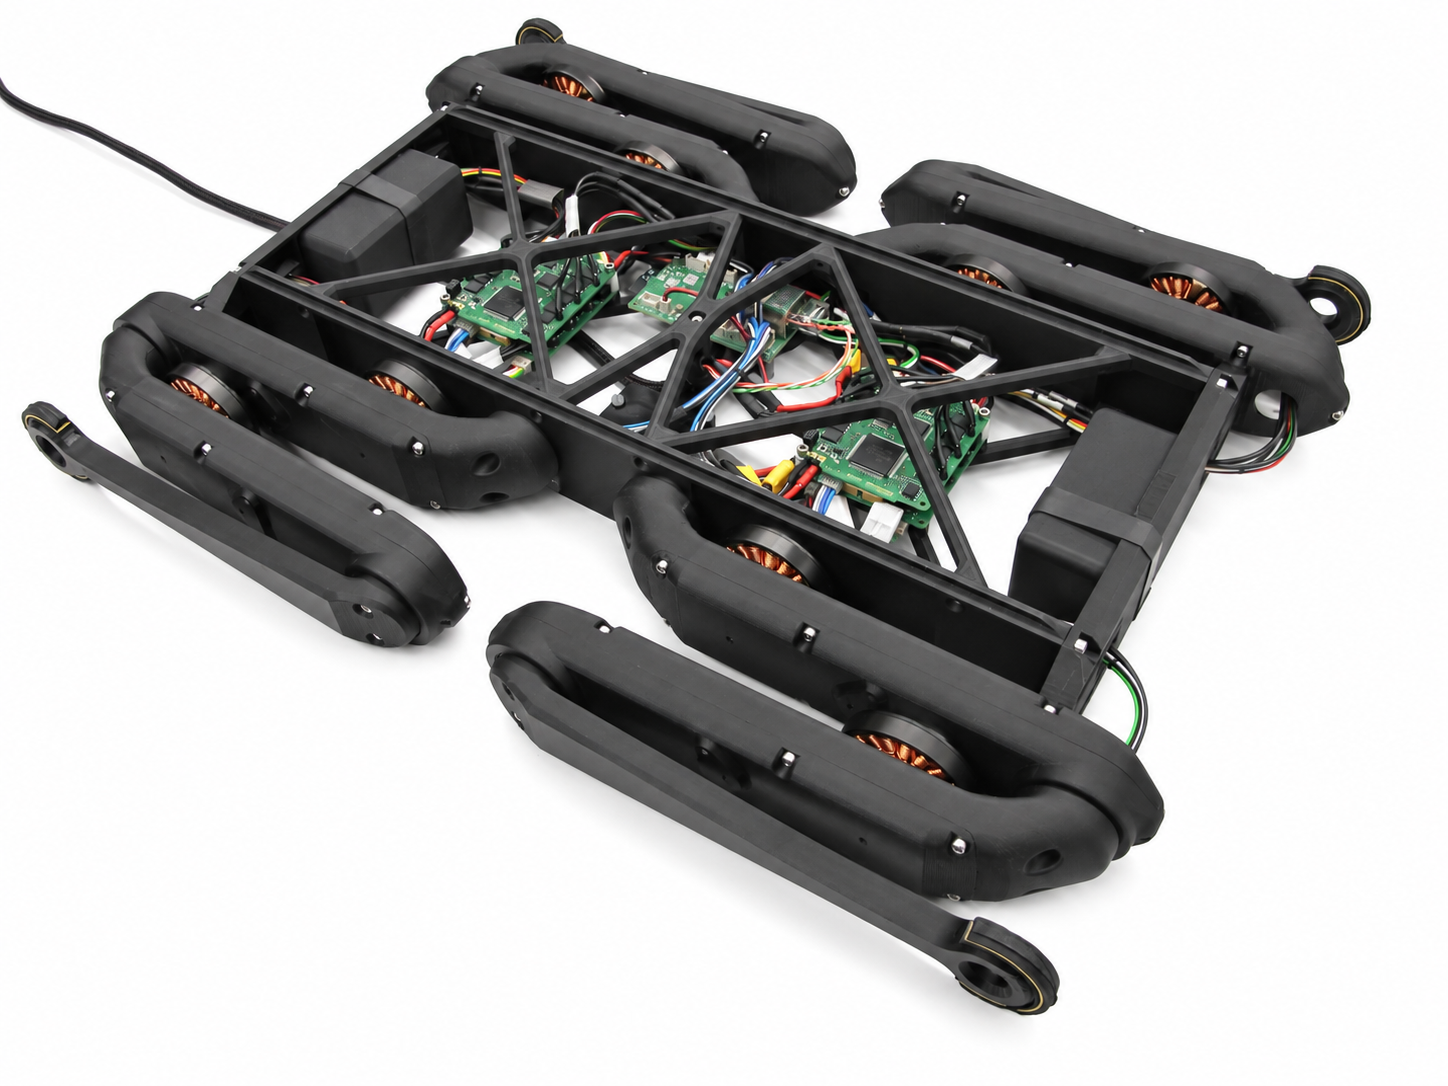
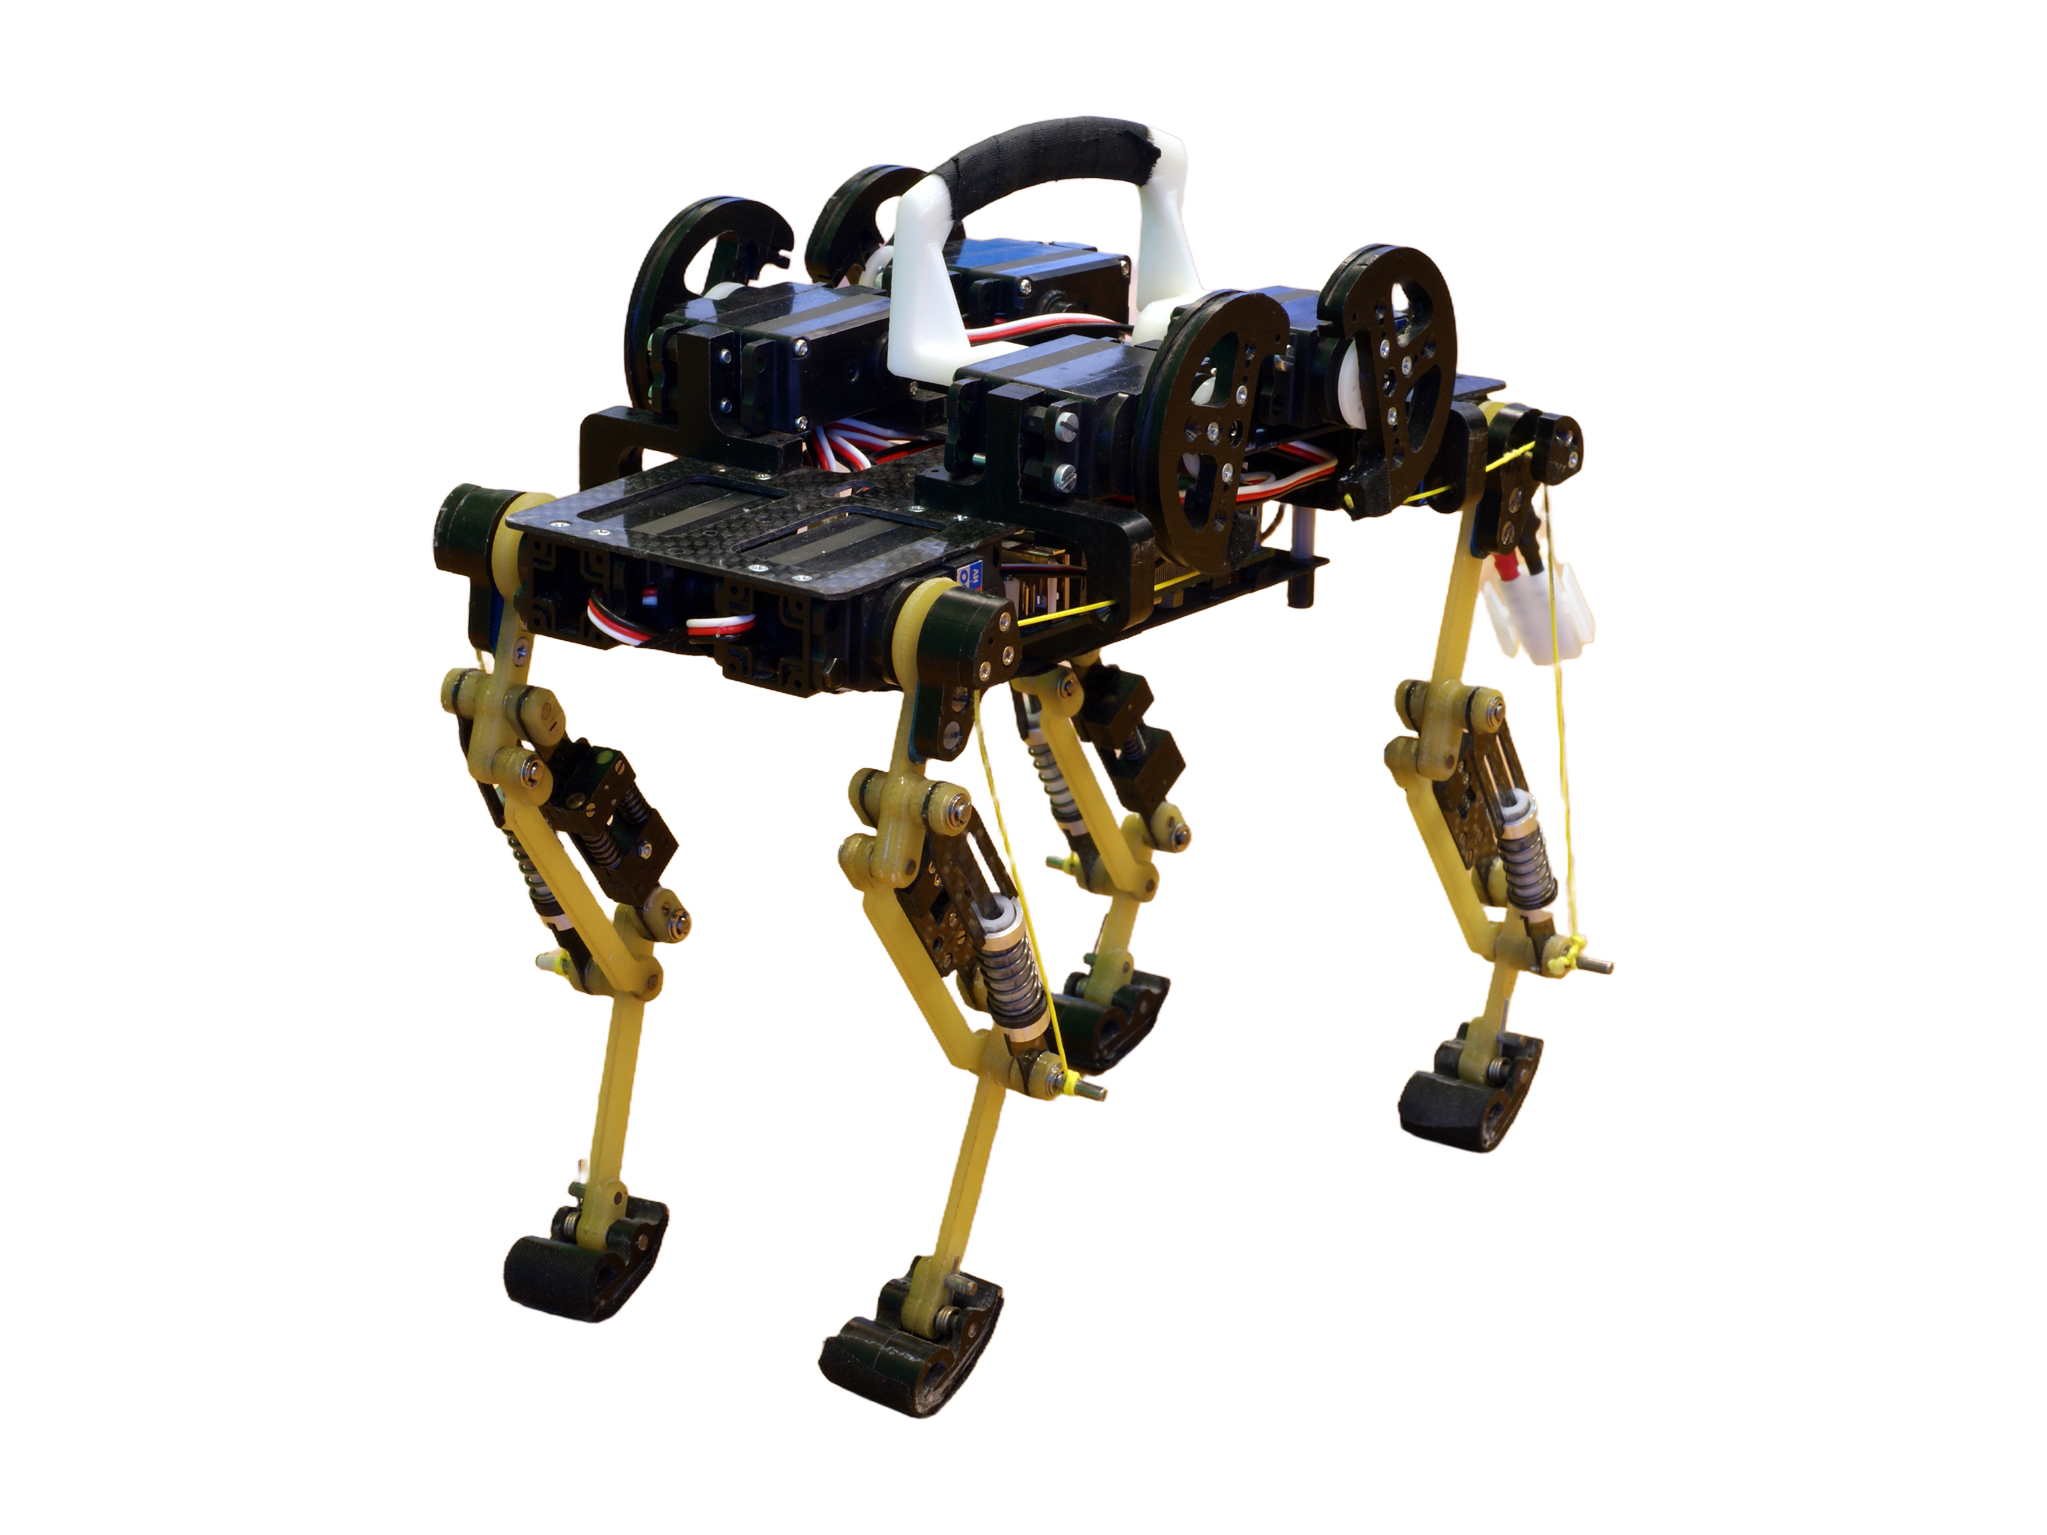
Manufacturer's own photo.
Specifications
2/33 specifications disclosed 31 not stated
31 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical2/14 disclosed
Power0/5 disclosed
Sensing and autonomy0/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Weight
1.9kg4.19lbOur conversion from 1.9 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
124 quadrupeds state a weight
118 state a higher figure, 1 a lower one. Log scale: each step along the axis multiplies the value.
Degrees of freedom
8DoF
76 quadrupeds state degrees of freedom
72 state a higher figure, 0 a lower one. 3 more state exactly the same figure.
Notes
An open-source 8-DoF quadruped research platform from the Max Planck Institute, LAAS-CNRS, and NYU.
Uses modular torque-controlled brushless actuator units with 3D-printed mechanics.
The initiative names its partners as the Max Planck Institute for Intelligent Systems in Germany, New York University in the USA and LAAS-CNRS in France; it does not give one home country.
Sources
One line per source, not per figure: a source has one retrieval date.
- Araw.githubusercontent.com/open-dynamic-robot-initiative/open_robot_actuator_hardware/master/mechanics/quadruped_robot_8dof_v2/README.mdMain source. Retrieved 4 September 2026
- Bopen-dynamic-robot-initiative.github.ioRetrieved 4 September 2026
More robots
Same manufacturer
All robots from Open Dynamic Robot Initiative