Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A approximately 125kgapproximately 276lbOur conversion from 125 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A approximately 360minWarning: load condition not stated
- Max speed A 0.36–5.4km/h0.22–3.36mphOur conversion from 0.36–5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Weight
Note Listed with an approximate sign.
Payload, moving
Note The table gives a load of 5 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry.
Runtime
Caveat Listed with an approximate sign next to the battery capacity; no load is stated.
Max speed
Note Listed as a speed range for the whole robot.
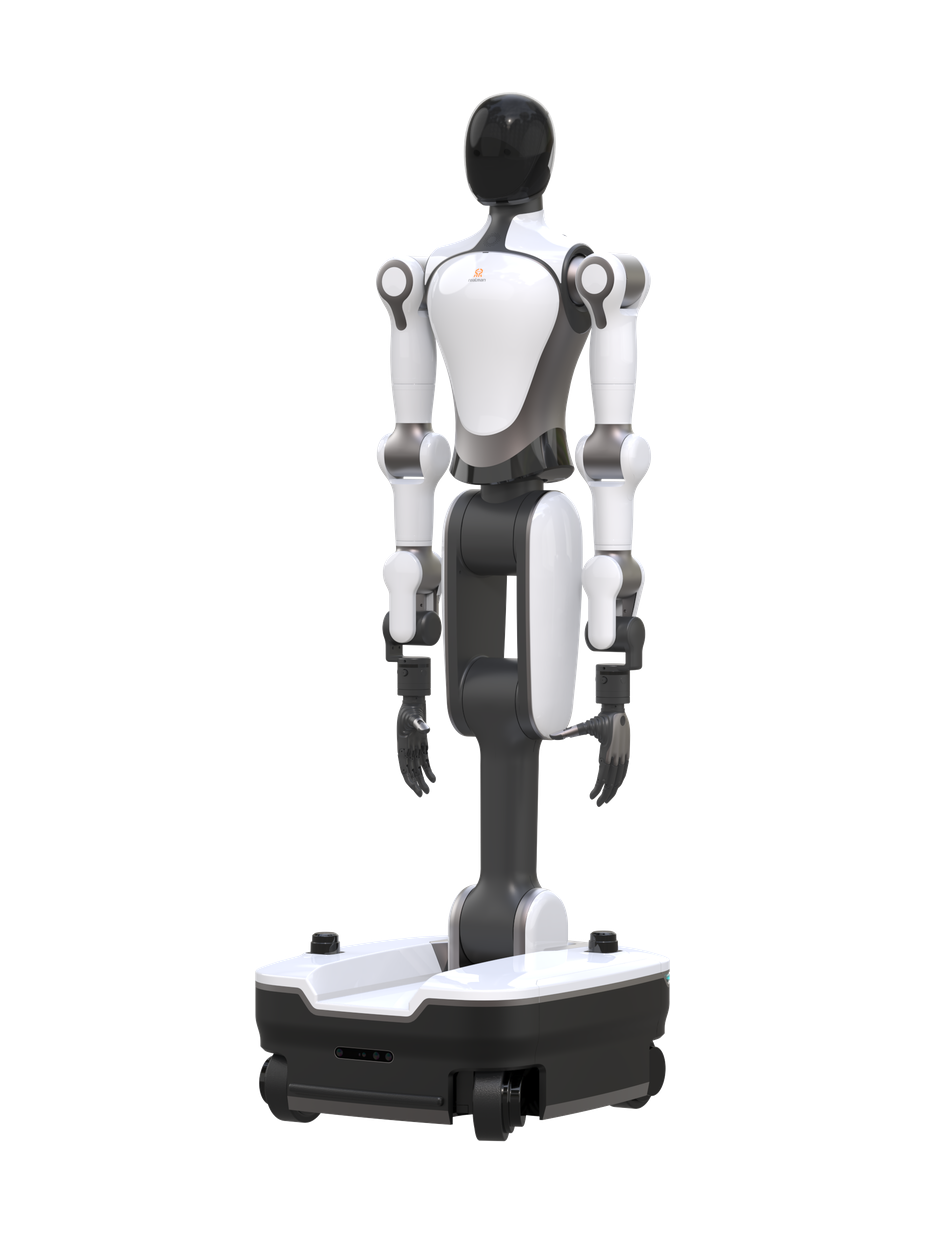
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Suitable for data-collection training, home service, commercial retail and industrial manufacturing
Source: realman-robotics.cn · Retrieved
This category is not our assessment.
Full specifications
7 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | approximately 125kgapproximately 276lbOur conversion from 125 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Listed with an approximate sign. A |
| Length | not stated | Caveat The table gives one unlabelled triplet of three numbers for the whole robot, without saying which number is length, width or height. It reads 614 x 552 x 1700 mm. A |
| Width | not stated | Caveat The table gives one unlabelled triplet of three numbers for the whole robot, without saying which number is length, width or height. It reads 614 x 552 x 1700 mm. A |
| Height | not stated | Caveat The table gives one unlabelled triplet of three numbers for the whole robot, without saying which number is length, width or height. It reads 614 x 552 x 1700 mm. A |
| Degrees of freedom | 20DoF | Caveat Active degrees of freedom of the whole robot, as given in the page summary. A |
| Payload, moving | not stated | Note The table gives a load of 5 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Note The table gives a load of 5 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | 0.36–5.4km/h0.22–3.36mphOur conversion from 0.36–5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Listed as a speed range for the whole robot. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Note The table gives the battery as 48 V and 20 Ah and no watt-hour figure. A |
| Runtime | approximately 360minWarning: load condition not stated | Caveat Listed with an approximate sign next to the battery capacity; no load is stated. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | Dual LiDAR, used for navigation. | Note Named in the feature list; no LiDAR type or model is given. A |
| Cameras | Head: stereo RGB camera x1 and fisheye cameras x2. Hand: RGB-D camera as standard, monocular RGB camera optional. | Note Sensor rows of the table. A |
| Onboard compute | Nvidia Jetson AGX Orin 64G. | Note Listed as the core processor. A |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | Note The table lists a two-finger gripper and a five-finger dexterous hand that can be changed quickly; no mounting interface is named. A |
| Power out | not stated | |
| Data ports | not stated | Note The table lists wired, Wi-Fi and optional 5G communication and names no ports. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer describes the RealBot-S2 as a full-size wheeled dual-arm folding humanoid robot (translated from the Chinese).
- The chassis is a four-wheel steering and four-wheel drive chassis (translated from the Chinese).
- The company history lists the founding of Realman Intelligent Technology (Beijing) in 2018 (translated from the Chinese).
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for RealBot-S2https://www.realman-robotics.cn/cn/products/realbot-s2.html
Sources
-
A
Manufacturer product page. www.
realman-robotics. · Retrievedcn/ cn/ products/ realbot-s2. html
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.