Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A approximately 157kgapproximately 346lbOur conversion from 157 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A 180–240minWarning: load condition not stated
- Max speed A 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Weight
Note Total weight, approximate.
Payload, moving
Caveat The page gives 5 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry.
Runtime
Caveat Continuous operation; no load condition is given.
Max speed
Note Movement speed in the specification table.
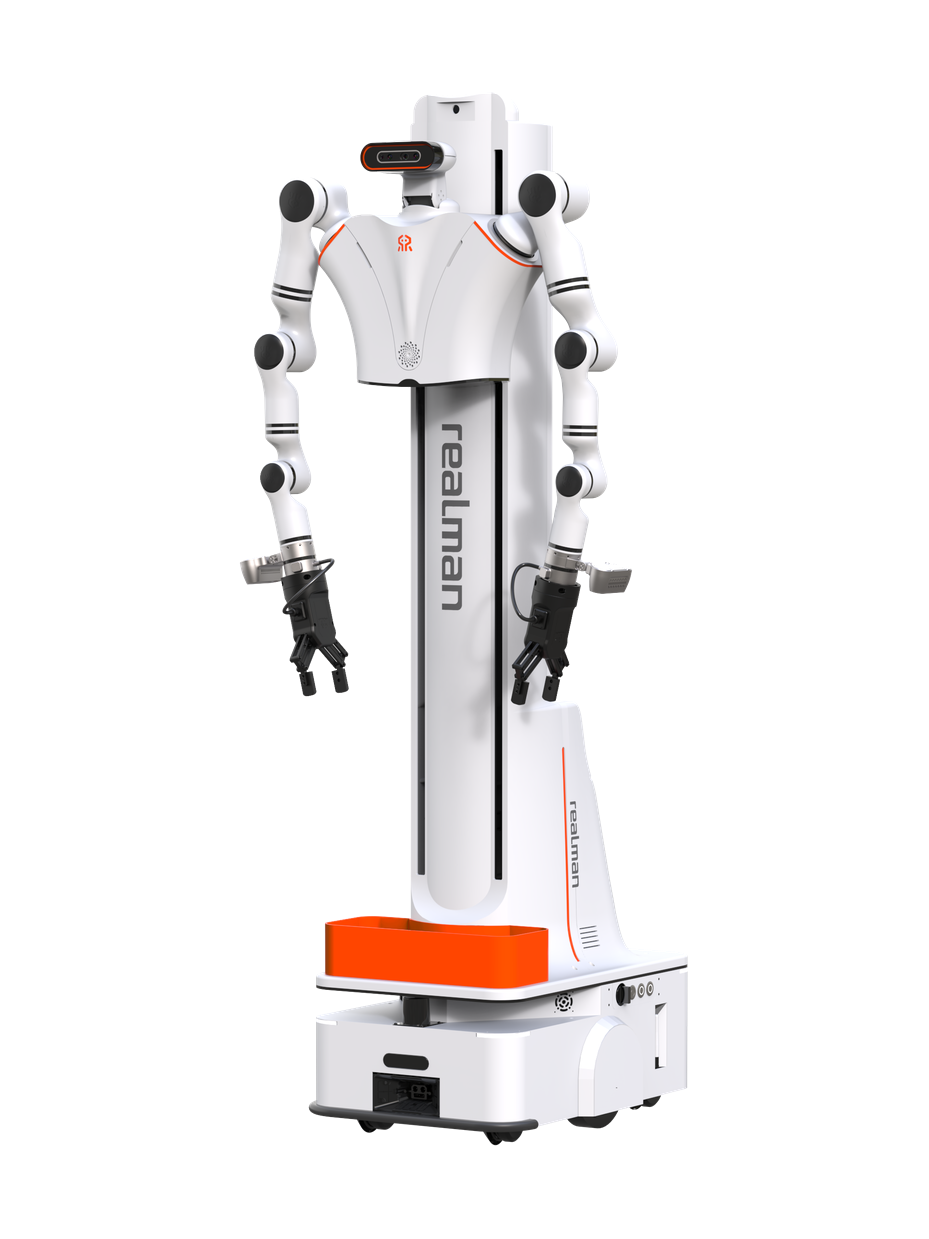
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Enables wired teleoperation for real-time robot control, dual-arm data collection, and AI model training workflows.
Source: realman-robotics.com · Retrieved
This category is not our assessment.
Full specifications
5 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | approximately 157kgapproximately 346lbOur conversion from 157 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Total weight, approximate. A |
| Length | not stated | Caveat The page gives overall dimensions of 640 × 450 × 1780 mm without naming the axes. A |
| Width | not stated | Caveat The page gives overall dimensions of 640 × 450 × 1780 mm without naming the axes. A |
| Height | not stated | Caveat The page gives overall dimensions of 640 × 450 × 1780 mm without naming the axes. A |
| Degrees of freedom | not stated | |
| Payload, moving | not stated | Caveat The page gives 5 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Caveat The page gives 5 kg per arm. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Movement speed in the specification table. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | 5°C41°FOur conversion from 5 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Lower end of the operating temperature range. A |
| Operating temperature, high | 40°C104°FOur conversion from 40 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Upper end of the operating temperature range. A |
| Power | ||
| Battery | not stated | |
| Runtime | 180–240minWarning: load condition not stated | Caveat Continuous operation; no load condition is given. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | not stated | |
| Onboard compute | not stated | |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer describes the Dual-Arm Lift as a vertical lift mobile robot with dual RM65-B-V arms, a 900 mm lifting stroke, 5 kg payload per arm, and autonomous navigation capabilities.
- The producer lists the RM75-B-V as an optional arm.
- The producer gives a lifting stroke of 900 mm and a vertical reach of 0–2400 mm, with a lateral reach of 790 mm per side and a forward reach of 0–690 mm.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Dual-Arm Lifthttps://www.realman-robotics.com/en/products/dual-arm-lift.html
Sources
-
A
Manufacturer product page. www.
realman-robotics. · Retrievedcom/ en/ products/ dual-arm-lift. html
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.