Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 135kg298lbOur conversion from 135 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A 240–360minWarning: load condition not stated
- Max speed A 0.36–5.4km/h0.22–3.36mphOur conversion from 0.36–5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Weight
Note Producer's own English documentation reads "Weight 135kg (standard configuration)"; other configurations are not described.
Runtime
Caveat No task/load condition given for the 4-6h endurance figure.
Max speed
Note From the basic-parameters table's moving-speed row, given as a range.
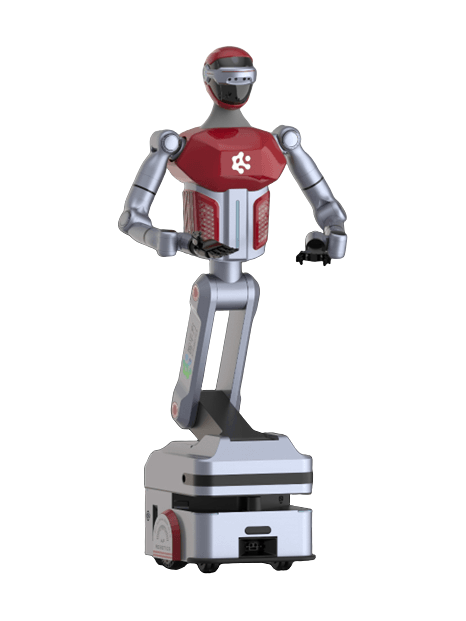
Manufacturer's own photo.
Shows an earlier exhibition configuration in red livery.
Intended use, per the manufacturer
Source: ai2robotics.com · Retrieved
AI² Robotics describes itself on its homepage as a global leader in the research, development, manufacturing and services of general-purpose robots, without naming a specific industry or usage sector for AlphaBot 2.
This category is not our assessment.
Full specifications
17 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 135kg298lbOur conversion from 135 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer's own English documentation reads "Weight 135kg (standard configuration)"; other configurations are not described. A |
| Length | 65cm25.6inOur conversion from 65 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Chassis footprint length, from the chassis specification table; this is the two-wheel differential-drive base, not an upper-body measurement. A |
| Width | 50.5cm19.9inOur conversion from 50.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Chassis footprint width, same table as length. A |
| Height | 180cm70.9inOur conversion from 180 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note From the basic-parameters table's height row. A |
| Degrees of freedom | 22DoF | Note Excludes the end effector (hand); the page gives 7 DoF per arm separately, but no whole-body figure that includes the hands. A |
| Payload, moving | not stated | |
| Payload, standing | not stated | |
| Max speed | 0.36–5.4km/h0.22–3.36mphOur conversion from 0.36–5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note From the basic-parameters table's moving-speed row, given as a range. A |
| Max slope | 0–5° | Note From the basic-parameters table's slope row. A |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | 5°C41°FOur conversion from 5 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer also states humidity 10-80%RH alongside the temperature range. A |
| Operating temperature, high | 40°C104°FOur conversion from 40 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Producer also states humidity 10-80%RH alongside the temperature range. A |
| Power | ||
| Battery | not stated | Note Producer states battery capacity as 48V and 30Ah; no combined Wh figure is given. A |
| Runtime | 240–360minWarning: load condition not stated | Caveat No task/load condition given for the 4-6h endurance figure. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | yes | Note From the chassis specification table's auto-recharging row. A |
| Sensing and autonomy | ||
| LiDAR | 2D LiDAR, measurement range up to 25 m. | Note From the chassis specification table. A |
| Cameras | 3x Intel RealSense D435 (chest/head/back); 2x Intel RealSense D405 (hands); 1x RGBD camera on the chassis. | Note Combines the basic-parameters table's camera rows with the separate chassis table's RGBD-camera row. A |
| Onboard compute | NVIDIA Orin AGX, 64GB. | Note From the basic-parameters table's computing-module row. A |
| ROS 2 | not stated | |
| SDK languages | Python C C++ | Note From the component-specifications section's external software interfaces row. A |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | Aviation-style quick connector for interchangeable end effectors (dexterous hand, gripper, suction cup, or other tools). | Note From the component-specifications section's aviation-connector description. A |
| Power out | not stated | |
| Data ports | USB 3.0 x1 HDMI x1 RJ45 x1 | Note From the basic-parameters table's debugging-ports row. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- AI² Robotics' own English-language developer documentation (docs.ai2robotics.com/en/, a subdomain of the manufacturer's own domain) states plainly that "AlphaBot 2 is a wheeled dual-arm humanoid robot"; it also separately describes a three-joint folding lift structure with a waist yaw atop a two-wheel differential-drive chassis for torso-height adjustment — a lift mechanism, not walking legs.
- Degrees of freedom (22) is stated as excluding the end effector (hand); a separate figure of 7 DoF is given per arm, and the page gives no separate hand-DoF count.
- The page separately lists a chassis-mounted RGBD camera (qty. 1) alongside the body/arm camera set (3x Intel RealSense D435 on chest/head/back, 2x Intel RealSense D405 on the hands).
- The chassis-parameter table also states a payload of up to 100kg for the mobile base itself; a base/chassis load rating is a different measurement from a walking or standing whole-body payload.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for AlphaBot 2https://docs.ai2robotics.com/en/alphabot2/hardware/architecture
Sources
-
A
Manufacturer product page. docs.
ai2robotics. · Retrievedcom/ en/ alphabot2/ hardware/ architecture -
B
ai2robotics.
com/ · Retrieveden/
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.