Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight A approximately 120kgapproximately 265lbOur conversion from 120 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A at most 180minWarning: load condition not stated
- Max speed not stated
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (2)
Weight
Note Specification table on the Torobo page, given as approximate.
Runtime
Caveat Battery continuous operation time in the specification table, given as approximate; no load condition is given.
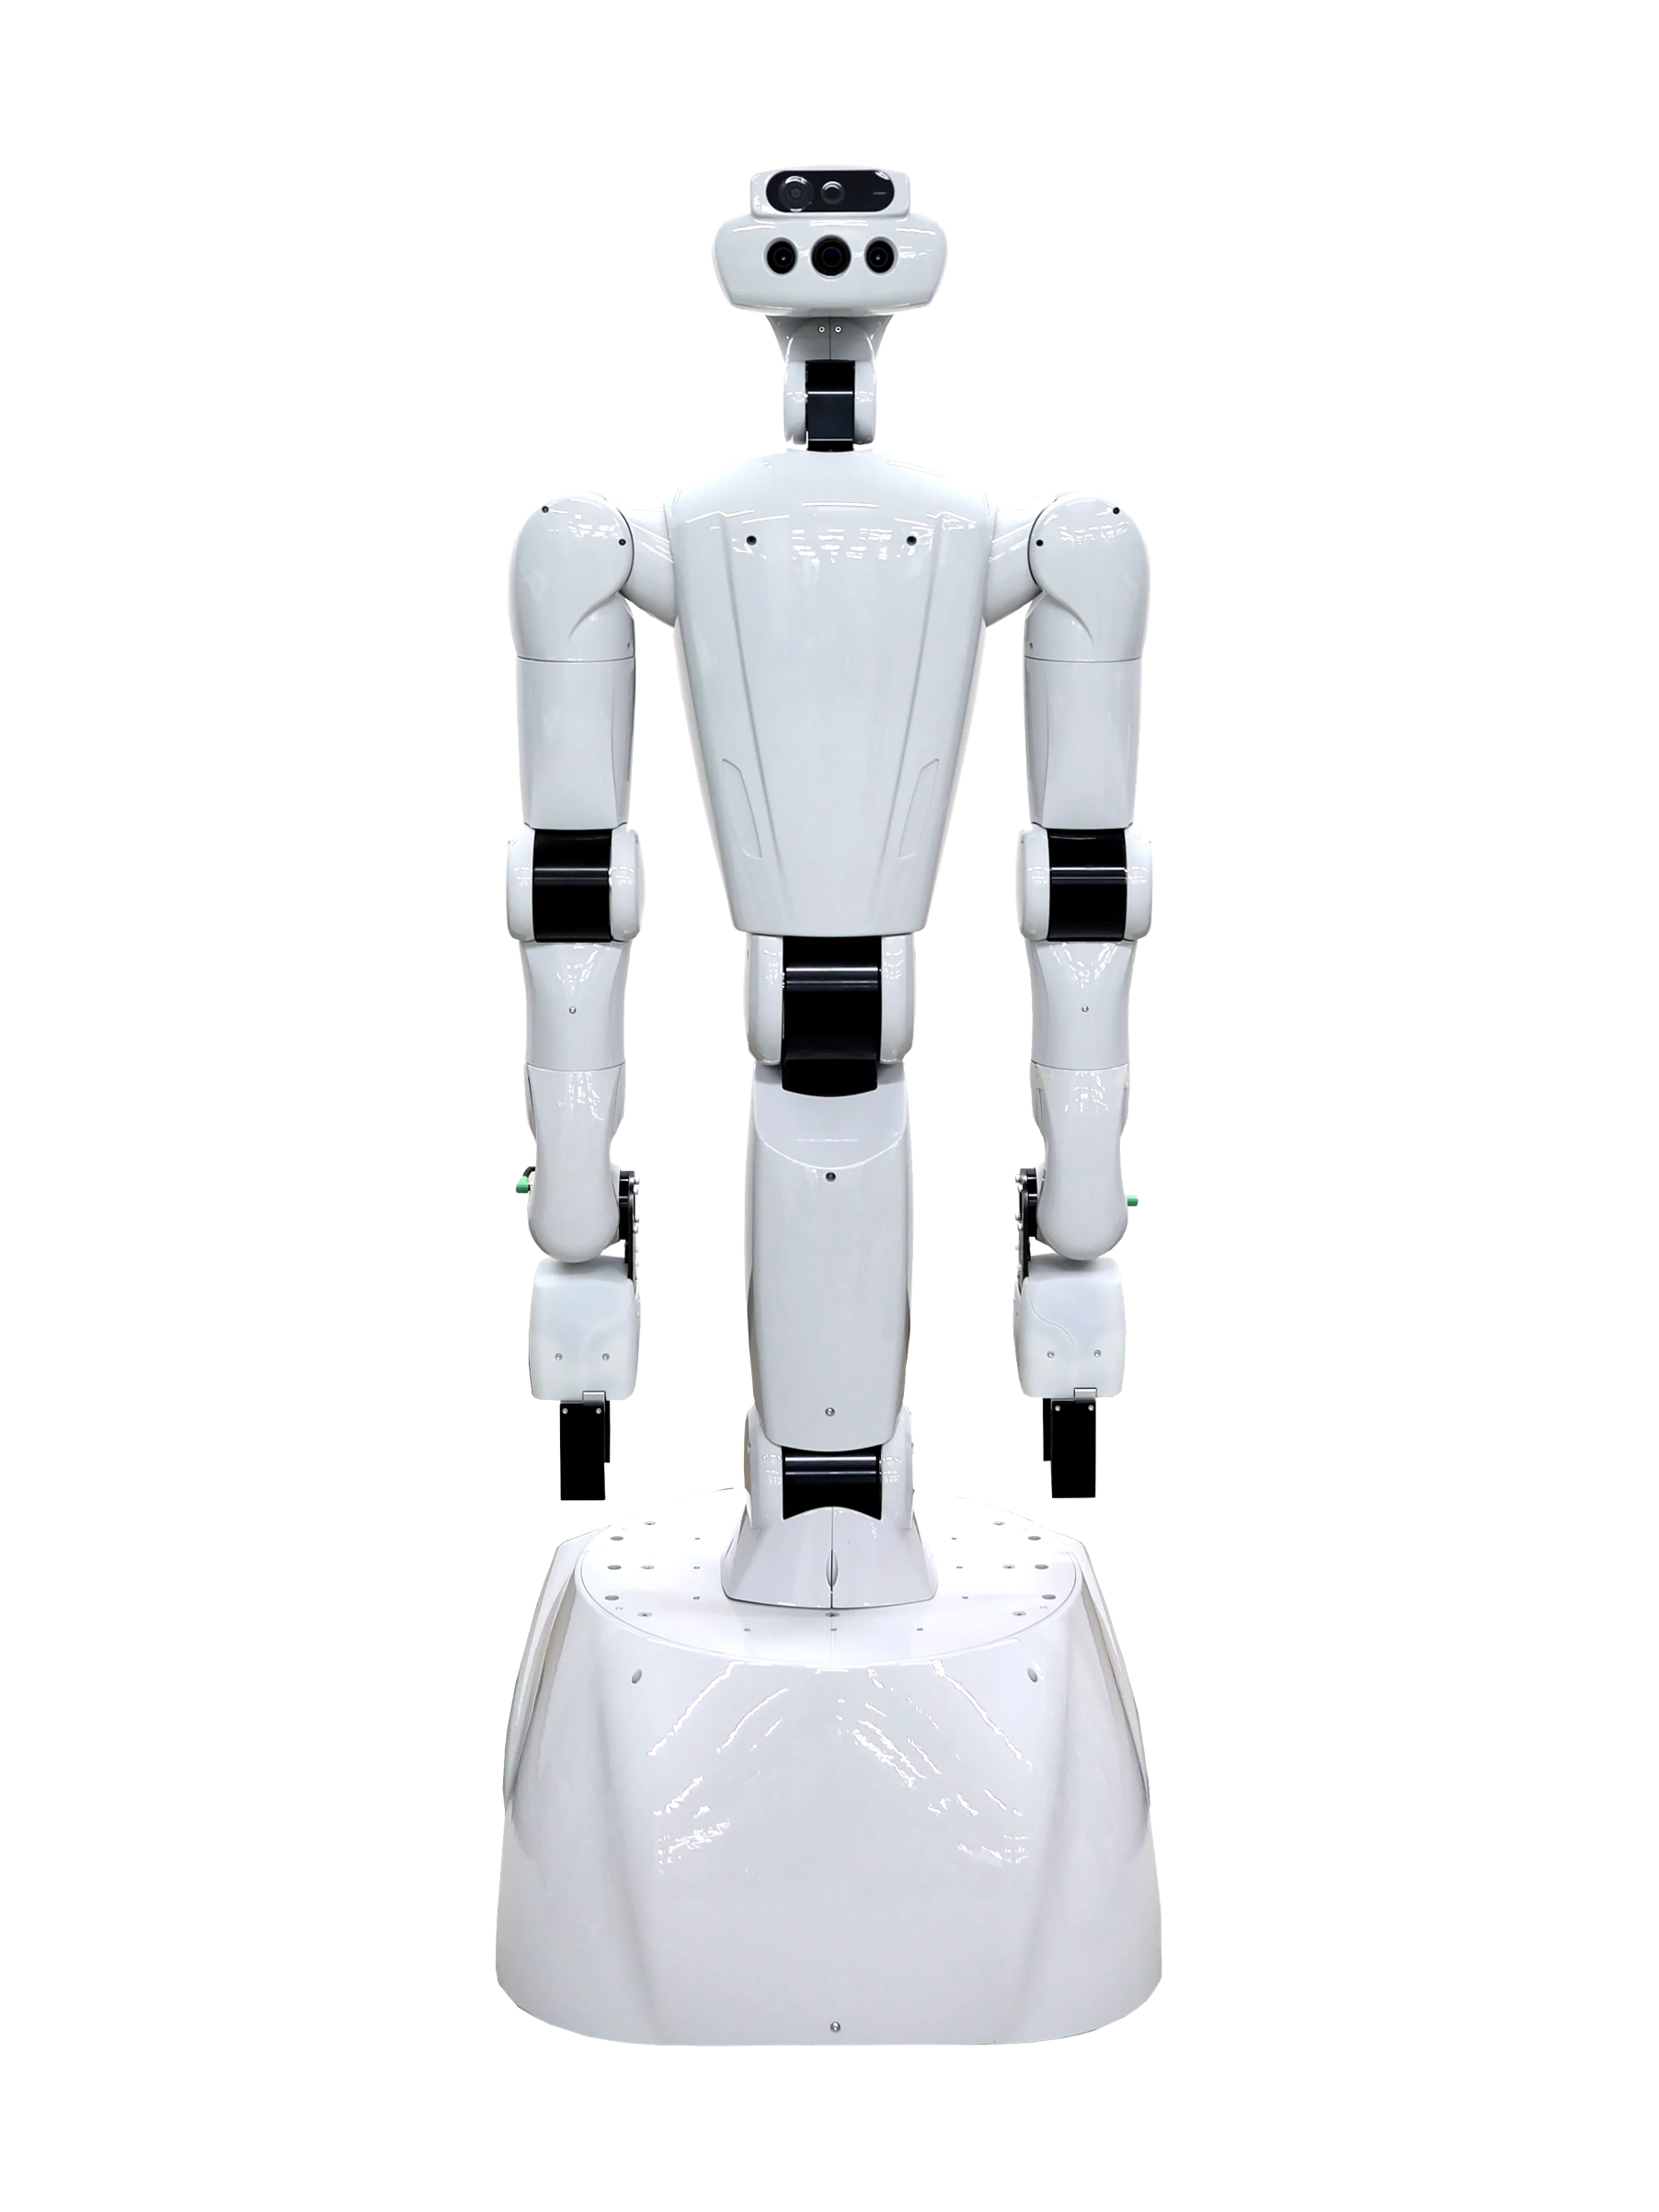
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Torobo has the following characteristics and can be used for machine learning research or to automate tasks that involve active contact with objects or the environment.
Source: robotics.tokyo · Retrieved
This category is not our assessment.
Full specifications
8 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | approximately 120kgapproximately 265lbOur conversion from 120 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Specification table on the Torobo page, given as approximate. A |
| Length | not stated | |
| Width | 59cm23.2inOur conversion from 59 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note The page gives this as the cart width. A |
| Height | 161.5cm63.6inOur conversion from 161.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Specification table on the Torobo page. A |
| Degrees of freedom | not stated | Caveat The page lists 7-axis dual arms, a 3-axis waist, a 3-axis neck and a 4-axis undercarriage, and gives no total. A |
| Payload, moving | not stated | |
| Payload, standing | not stated | Caveat The page gives a payload of 7 kg for a single arm in the worst posture. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | at most 180minWarning: load condition not stated | Caveat Battery continuous operation time in the specification table, given as approximate; no load condition is given. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | Optional head: 1 wide-angle stereo camera, 1 fisheye camera and 1 depth camera. | Note The sensors belong to the optional head; the default head has no sensors. A |
| Onboard compute | not stated | Caveat The page lists a standard control PC and an optional second PC with an Nvidia RTX 4070 for the head sensors; another section names an Nvidia RTX 5070 for the optional image-processing PC. A |
| ROS 2 | not stated | Caveat The page says the software is based on ROS and names MoveIt!; ROS 2 is not named. A |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | Tool flange at the arm tip. | Note Listed among the external terminals in the specification table. A |
| Power out | 24 V DC power supply terminal at the tool flange. | Note One terminal at the arm tip, as listed in the specification table. A |
| Data ports | Ethernet | Note Two Ethernet terminals on the back of the robot; the same table lists digital and analog input and output terminals. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Tokyo Robotics lists Torobo on its own page as a humanoid robot that is under development.
- The joint configuration is 7-axis dual arms, a 3-axis waist, a 3-axis neck and a 4-axis undercarriage that is an omni-directional mobile base.
- Tokyo Robotics dates Torobo to 2022 on its page of earlier products, where it describes Torobo as a robot developed to accelerate industrial applications of full-body humanoid robots.
- The page says that its videos show the old Torobo and that the current Torobo is lighter than the older version.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Torobohttps://robotics.tokyo/technologies/torobo
Sources
-
A
Manufacturer product page. robotics.
tokyo/ · Retrievedtechnologies/ torobo
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.