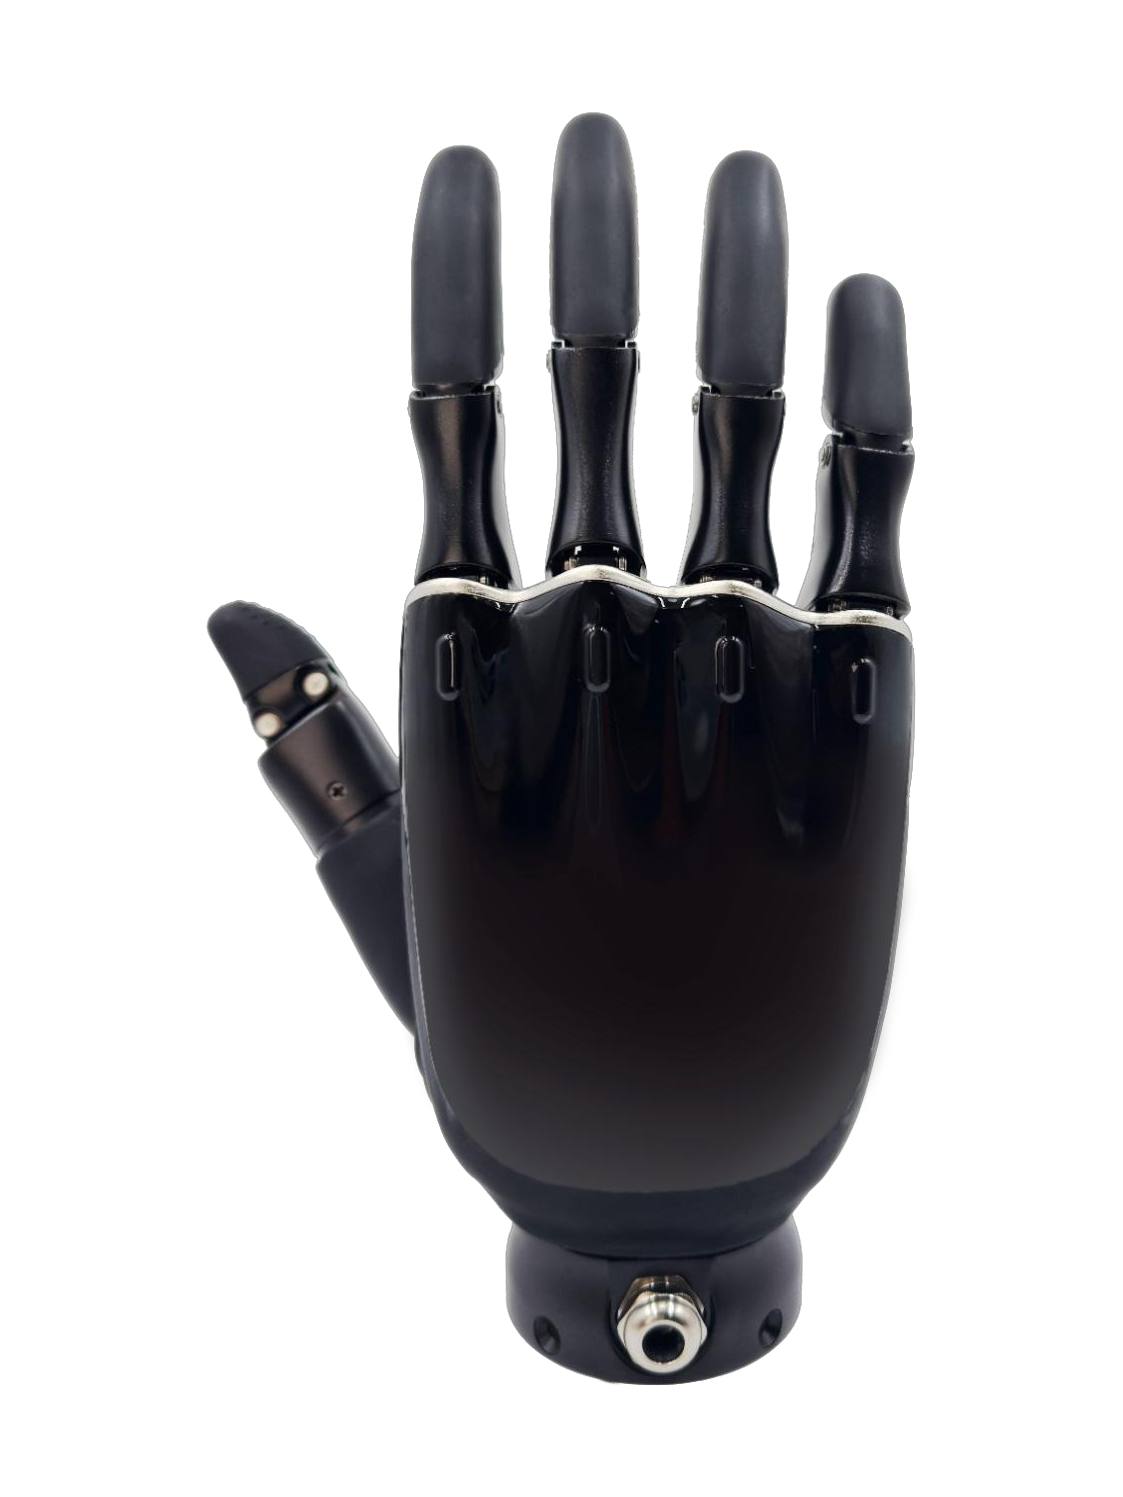
ROH-AP002
A robot hand from China, first released 2025.
Sources retrieved: 4 November 2026 (A, B, C, D)
- Status
- In production
- Applications
- Intended use, per the manufacturer
- making it suitable for humanoid robots, industrial operations, precision assembly, medical rehabilitation, and other scenariosSource and note: Intended use, per the manufacturerB oymotion.com/en/product62 · Retrieved 4 November 2026
- Indicative price
- Not stated
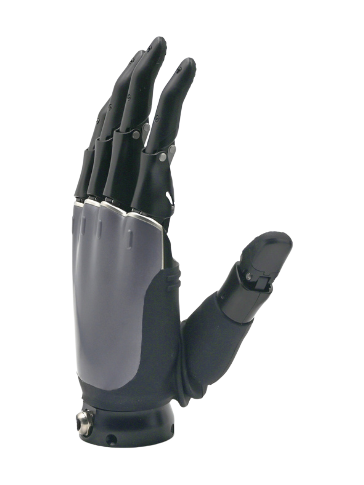
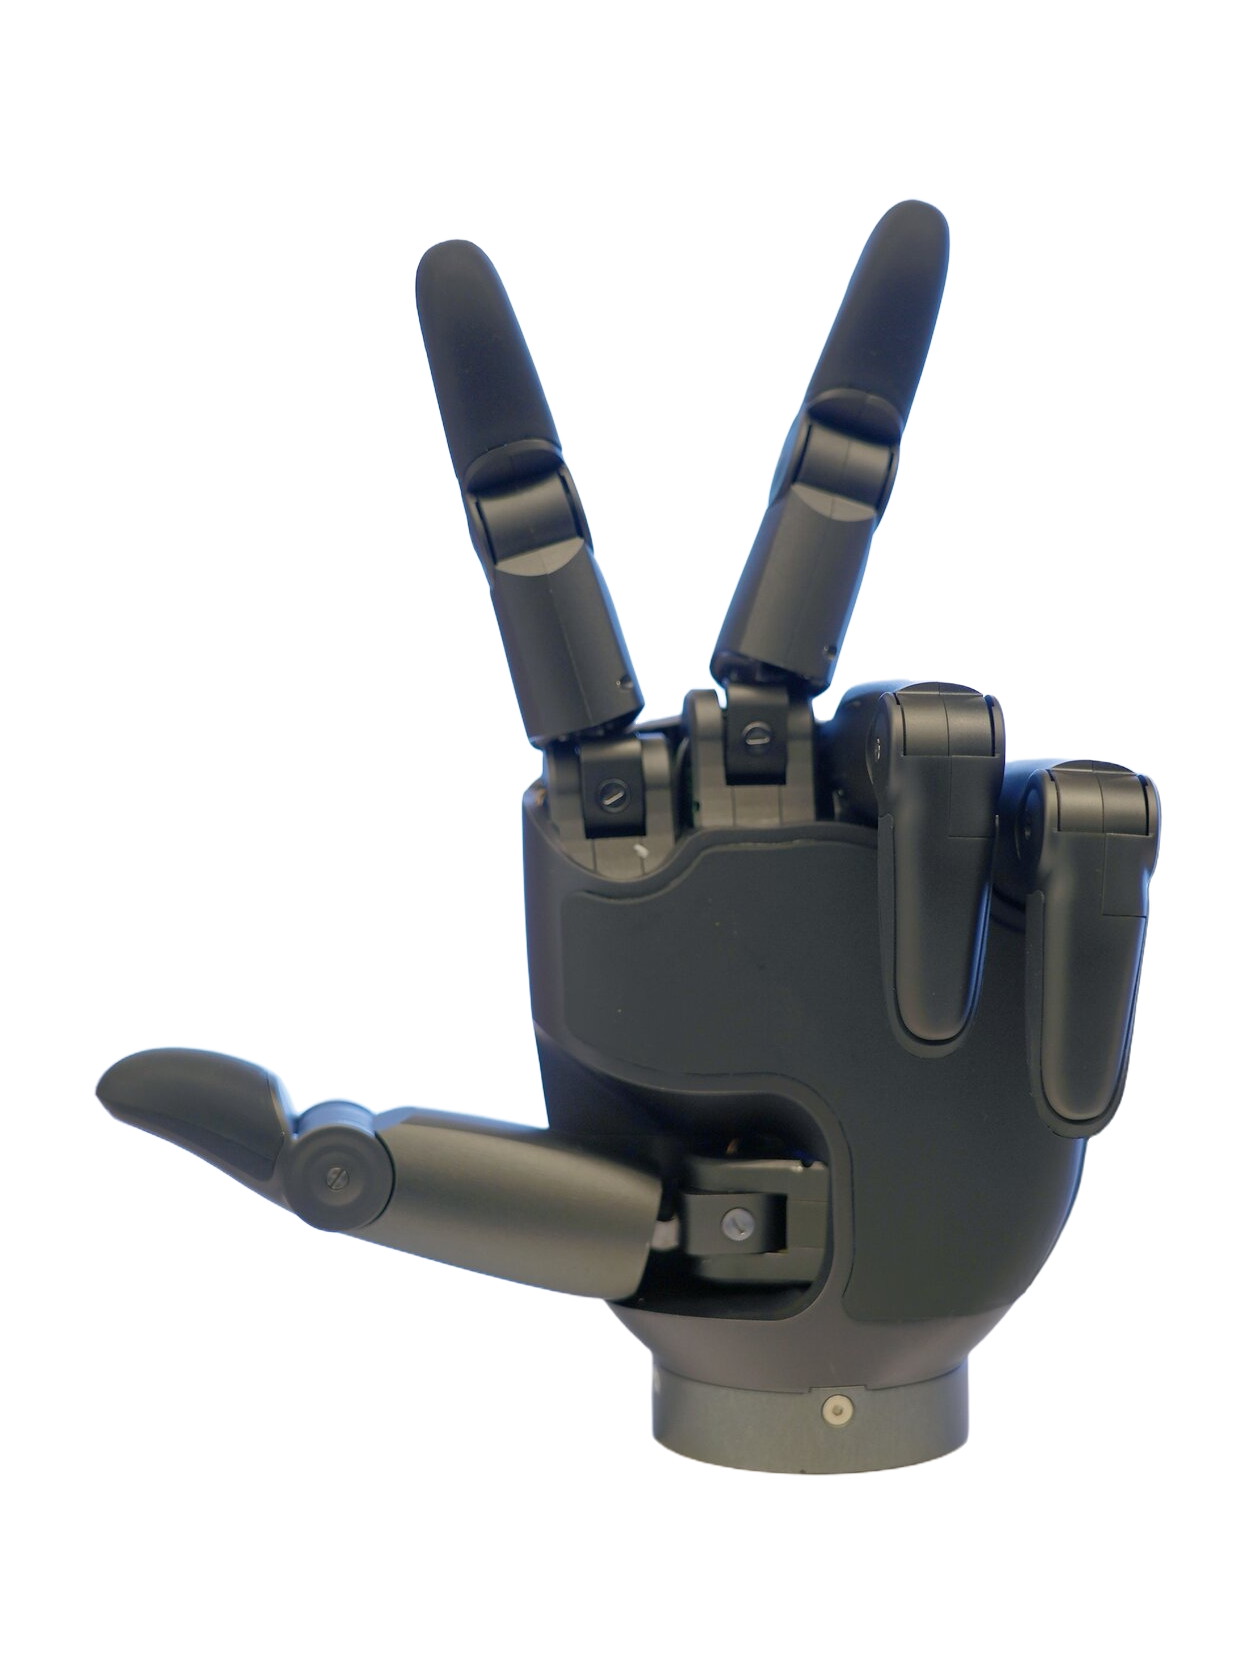
Manufacturer's own photo.
Specifications
9 of 18 stated 9 not stated
9 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand3/4 disclosed
Performance2/4 disclosed
Physical2/2 disclosed
Sensing and autonomy2/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Lifting capacity
30kg66.1lbOur conversion from 30 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
48 robot hands state a lifting capacity
5 state a higher figure, 30 a lower one. 5 more state exactly the same figure. 7 state only a bound (≥ or ≤) and are not ranked.
Weight
626g1.38lbOur conversion from 626 g. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
59 robot hands state a weight
34 state a higher figure, 19 a lower one. 1 more states exactly the same figure. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
6DoF
66 robot hands state degrees of freedom
47 state a higher figure, 4 a lower one. 14 more state exactly the same figure.
Notes
The manual's revision history starts with V1.0.0, dated 2025.9.15, marked as the initial version: “Date 2025.9.15 2026.2.6 2026.4.23 2026.9.8 Revision V1.0.0 V1.0.1 V1.0.2 V1.0.3 Modified content Initial version.” OYMotion's download page lists the ROH-AP002 user manual dated 2026/01/06: “ROH-AP002 DEXTEROUS HANDUSER MANUAL 2026/01/06”.
Available for the left and right hand; versions with the suffix -C have a CAN interface.
The manual states “12-month warranty period from the date of sale.” The packing list includes a warranty card: “Warranty card: 1 piece”.
OYMotion's industrial-solutions article dated 2026.04.22 names the AP002 among its mature series.
The product page gives a repeat positioning accuracy of ±0.05 mm and a force resolution of 0.1 N, and a full-range bending or stretching time of 0.7 s at maximum speed.
The product page says: “The OYMotion ROH-AP002 adopts a hybrid 3D + 1D force sensing architecture. The distal and middle segments of the fingers support both normal and tangential force sensing, while the palm uses an 11×5 dot-matrix sensor.”
The product page gives typical operating power of at most 15 W and standby power of at most 0.5 W.
The manual warns: “Warning: ROH-AP002 dexterous hand is not waterproof.”
Sources
One line per source, not per figure: a source has one retrieval date.
- Aoymotion.com/product61/199Retrieved 4 November 2026
- Boymotion.com/en/product62Main source. Retrieved 4 November 2026
- Coymotion.com/upload/files/20260908155949ROH-AP002-Dexterous-Hand-V1.0.3.pdfSecondary. Retrieved 4 November 2026
- Doymotion.com/en/product62/200Retrieved 4 November 2026