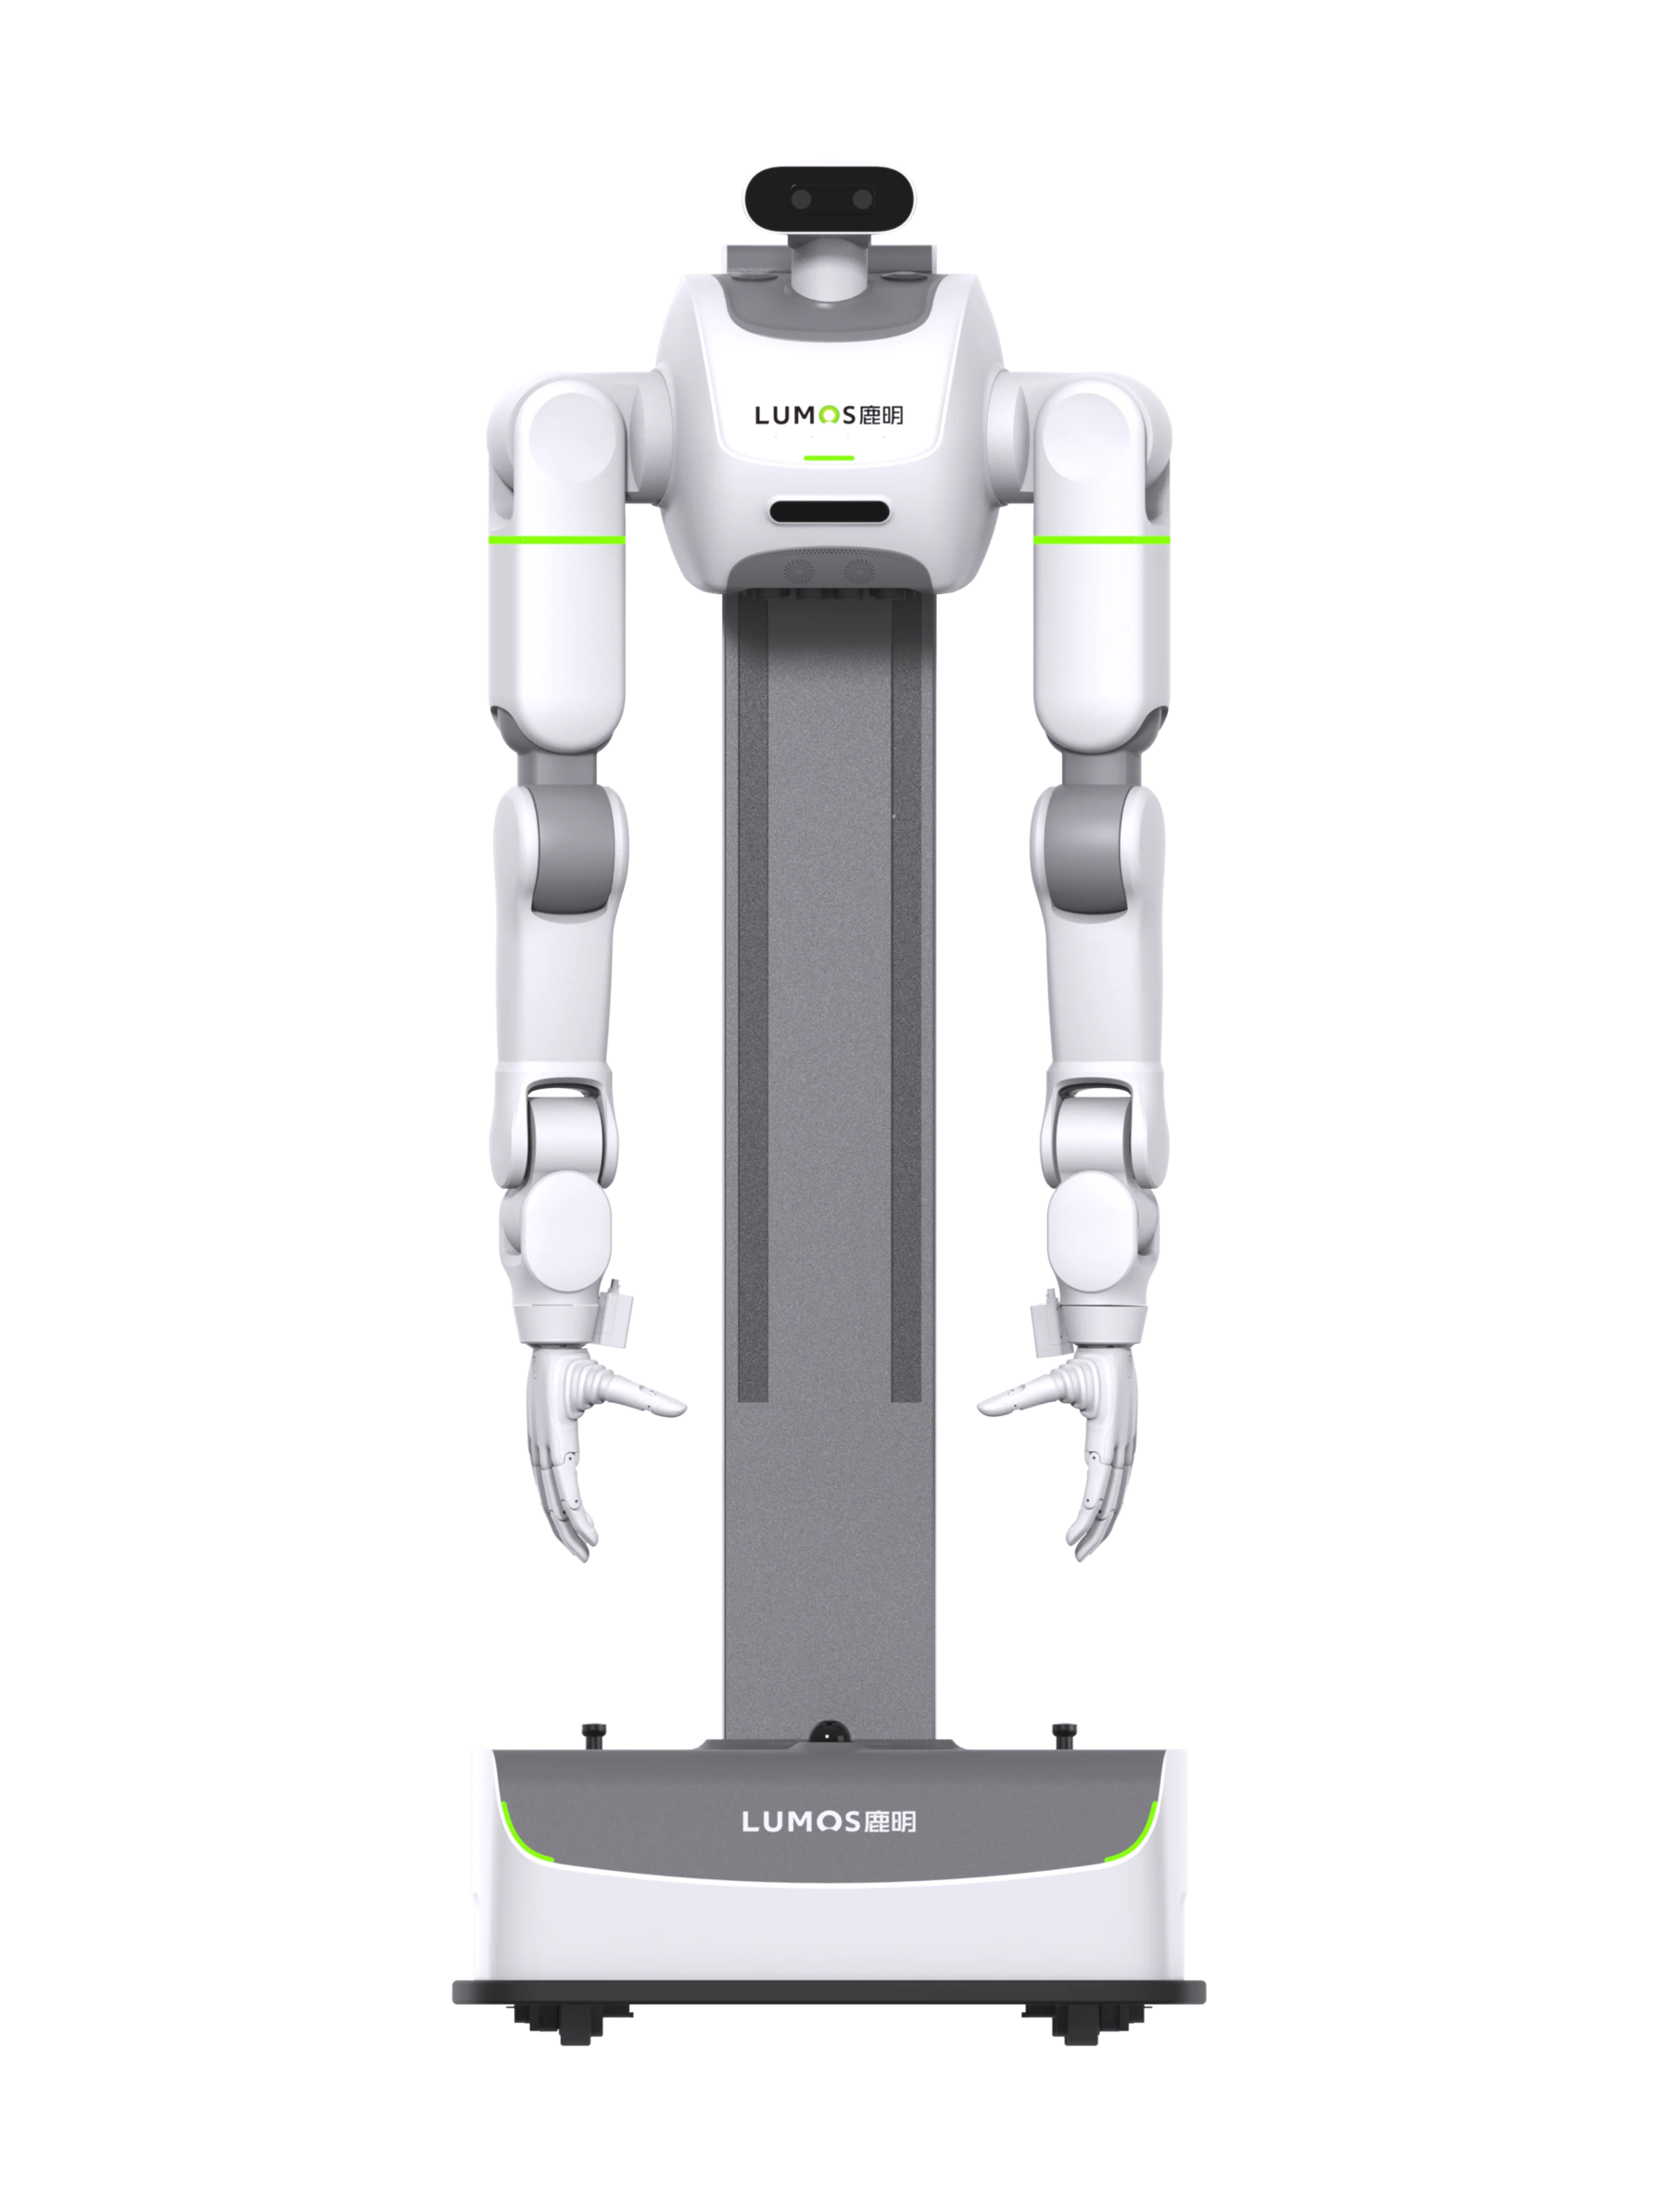
Manufacturer's own photo.
Key figures as stated by the manufacturer
3 of 6 key figures stated- Weight A at most 350kgat most 772lbOur conversion from 350 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Runtime A at least 480minWarning: load condition not stated
- Max speed A at most 5.4km/hat most 3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
Not stated: Payload, moving · AI model · Indicative price
Deviations and variants in the key figures (3)
Weight
Note Weight including the battery.
Runtime
Caveat Runtime in the specification list; no load is given.
Max speed
Caveat Travel speed of the base.
Intended use, per the manufacturer
The manufacturer’s words
A heavy-duty wheeled mobile manipulation robot built for real industrial tasks such as heavy-load handling, hazardous-environment teleoperation, and flexible inspection.
Source: lumosbot.tech · Retrieved
This category is not our assessment.
Full specifications
15 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | at most 350kgat most 772lbOur conversion from 350 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Weight including the battery. A |
| Length | not stated | Caveat The producer gives the base dimensions as 735 * 700 * 300 mm without naming the axes. A |
| Width | not stated | |
| Height | 165cm65inOur conversion from 165 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Overall height of the robot. A |
| Degrees of freedom | 22DoF | Note Whole-body total. A |
| Payload, moving | not stated | |
| Payload, standing | not stated | Caveat The producer gives 30 kg rated and 50 kg maximum for the two arms together. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | at most 5.4km/hat most 3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat Travel speed of the base. A |
| Max slope | at most 5% | Note Gradeability. A |
| Single obstacle | at most 2.5cmat most 0.98inOur conversion from 2.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Step-crossing; the producer gives trench-crossing as up to 35 mm. A |
| IP rating | not stated | |
| Operating temperature, low | 0°C32°FOur conversion from 0 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Operating temperature range. A |
| Operating temperature, high | 45°C113°FOur conversion from 45 °C. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Operating temperature range. A |
| Power | ||
| Battery | not stated | Caveat The producer gives the battery as 19.5 Ah * 2 at a rated voltage of 48 V. A |
| Runtime | at least 480minWarning: load condition not stated | Caveat Runtime in the specification list; no load is given. A |
| Hot-swap battery | yes | Note Quick-detach battery. A |
| Charge time | not stated | |
| Docking station | yes | Caveat The producer lists autonomous docking charging as an option; manual battery swap is the standard. A |
| Sensing and autonomy | ||
| LiDAR | 3D LiDAR ×2 on the base | A |
| Cameras | 2 wrist cameras, 1 head camera | A |
| Onboard compute | NVIDIA Orin AGX 275TOPS | A |
| ROS 2 | not stated | |
| SDK languages | not stated | Caveat The producer says it supports SDK development and graphical task orchestration. A |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | Standard flange | Note Listed as the end tooling. A |
| Power out | not stated | |
| Data ports | not stated | Caveat The producer lists Wi-Fi, 5G and Ethernet as the connectivity. A |
| Commercial | ||
| Indicative price | not stated | |
| Compliance & certifications | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Pages with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Notes
- The producer calls MOS 2 a heavy-duty wheeled mobile manipulation robot for industrial tasks such as heavy-load handling, hazardous-environment teleoperation and flexible inspection.
- The producer describes the arms as seven-DoF, human-like arms.
- The producer describes a swerve-drive omnidirectional base.
- RoboticsTomorrow, on 31 August 2026, reports that Lumos has officially launched MOS2, its next-generation heavy-duty mobile manipulator.
Sources
-
A
Primary source. lumosbot.
tech/ · Retrievedproducts/ mos
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.