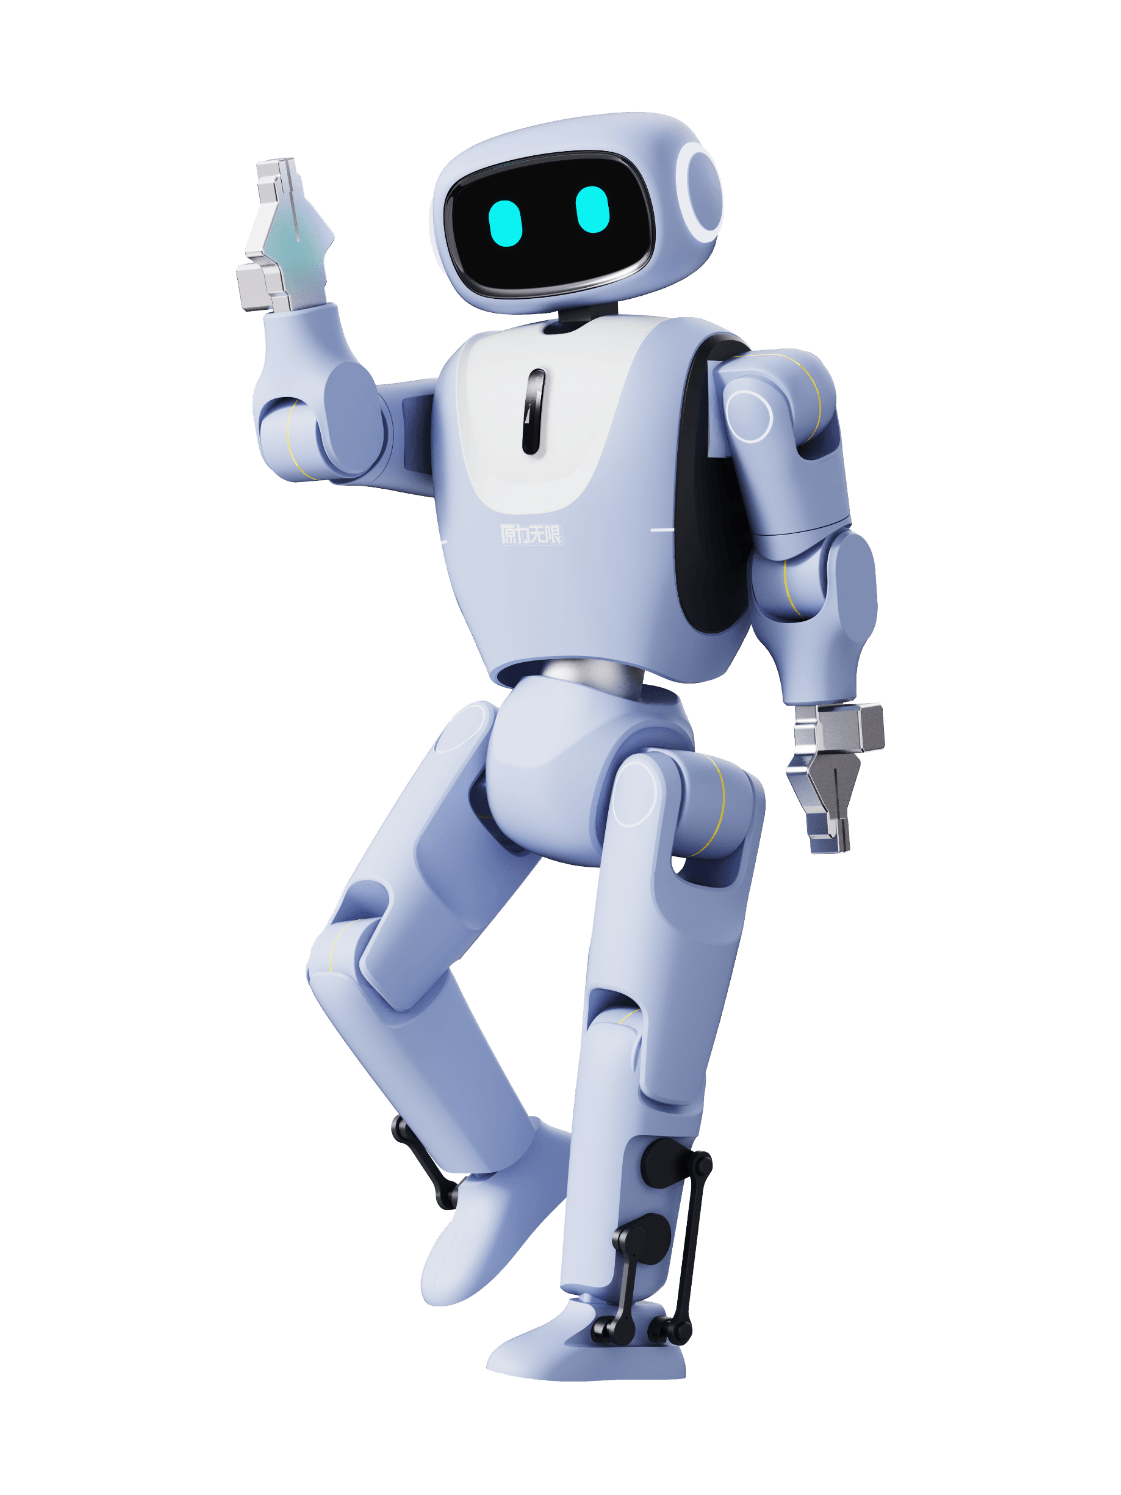
Manufacturer's own photo.
Manufacturer's rendering; the robot shown in INFIFORCE's own video is white.
Key figures as stated by the manufacturer
2 of 6 key figures stated- Weight A 20kg44.1lbOur conversion from 20 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Runtime A approximately 90minWarning: load condition not stated
Not stated: Payload, walking · Max speed · AI model · Indicative price
Deviations and variants in the key figures (2)
Weight
Note Own weight in the producer's key-figure row.
Runtime
Caveat Battery life given as "about"; no load or activity is stated.
Intended use, per the manufacturer
Source: infiforce.cn · Retrieved
This category is not our assessment.
Full specifications
7 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 20kg44.1lbOur conversion from 20 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Own weight in the producer's key-figure row. A |
| Length | not stated | |
| Width | not stated | |
| Height | 95cm37.4inOur conversion from 95 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Height in the producer's key-figure row. A |
| Degrees of freedom | 25DoF | Note Total in the producer's key-figure row; no split by limb is given. A |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | approximately 90minWarning: load condition not stated | Caveat Battery life given as "about"; no load or activity is stated. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | Dual-camera perception array. | Note The key-figure row names a dual-camera array without type or resolution. A |
| Onboard compute | 275 TOPS core compute. | Note The key-figure row gives the figure without naming a chip. A |
| ROS 2 | not stated | Caveat The page says ROS is supported for development; no ROS version is named. A |
| SDK languages | C++ Python | Note The page lists ROS, C++ and Python for development and an open SDK interface (translated from the Chinese). A |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | Caveat The page says the robot has standard expansion ports without naming or counting them. A |
| Commercial | ||
| Indicative price | not stated | |
| Compliance & certifications | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Pages with several sources carry several letters.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Notes
- The producer calls YUANZI a small-size humanoid robot (translated from the Chinese).
- Borncity, 5 February 2026, dates the official presentation of INFIFORCE's first compact bipedal robot to 4 February 2026 (translated from the German).
- The producer lists a maximum joint torque of 36 Nm (translated from the Chinese).
- The producer's page describes YUANZI as an ideal teaching tool for hands-on programming (translated from the Chinese).
Sources
-
A
Primary source. infiforce.
cn/ · Retrievedyuanzi
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.