Booster RoboticsChina2024
T1
- In production
- 20–40 kg44–88 lb
- Research and development
- Consumer and education
VariantsBasicStandardCustomized
The manufacturer sells this model in several variants. The figures on this page apply to the variant the source names.
Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight A approximately 30kgapproximately 66.1lbOur conversion from 30 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking not stated
- Runtime A 120minWarning: load condition not stated
- Max speed not stated
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (2)
Weight
Note Same figure given for all three configurations (Basic, Standard, Customized).
Runtime
Caveat Walking figure used (no carried-weight load is given for either figure). The producer separately states 4 hours for standing.
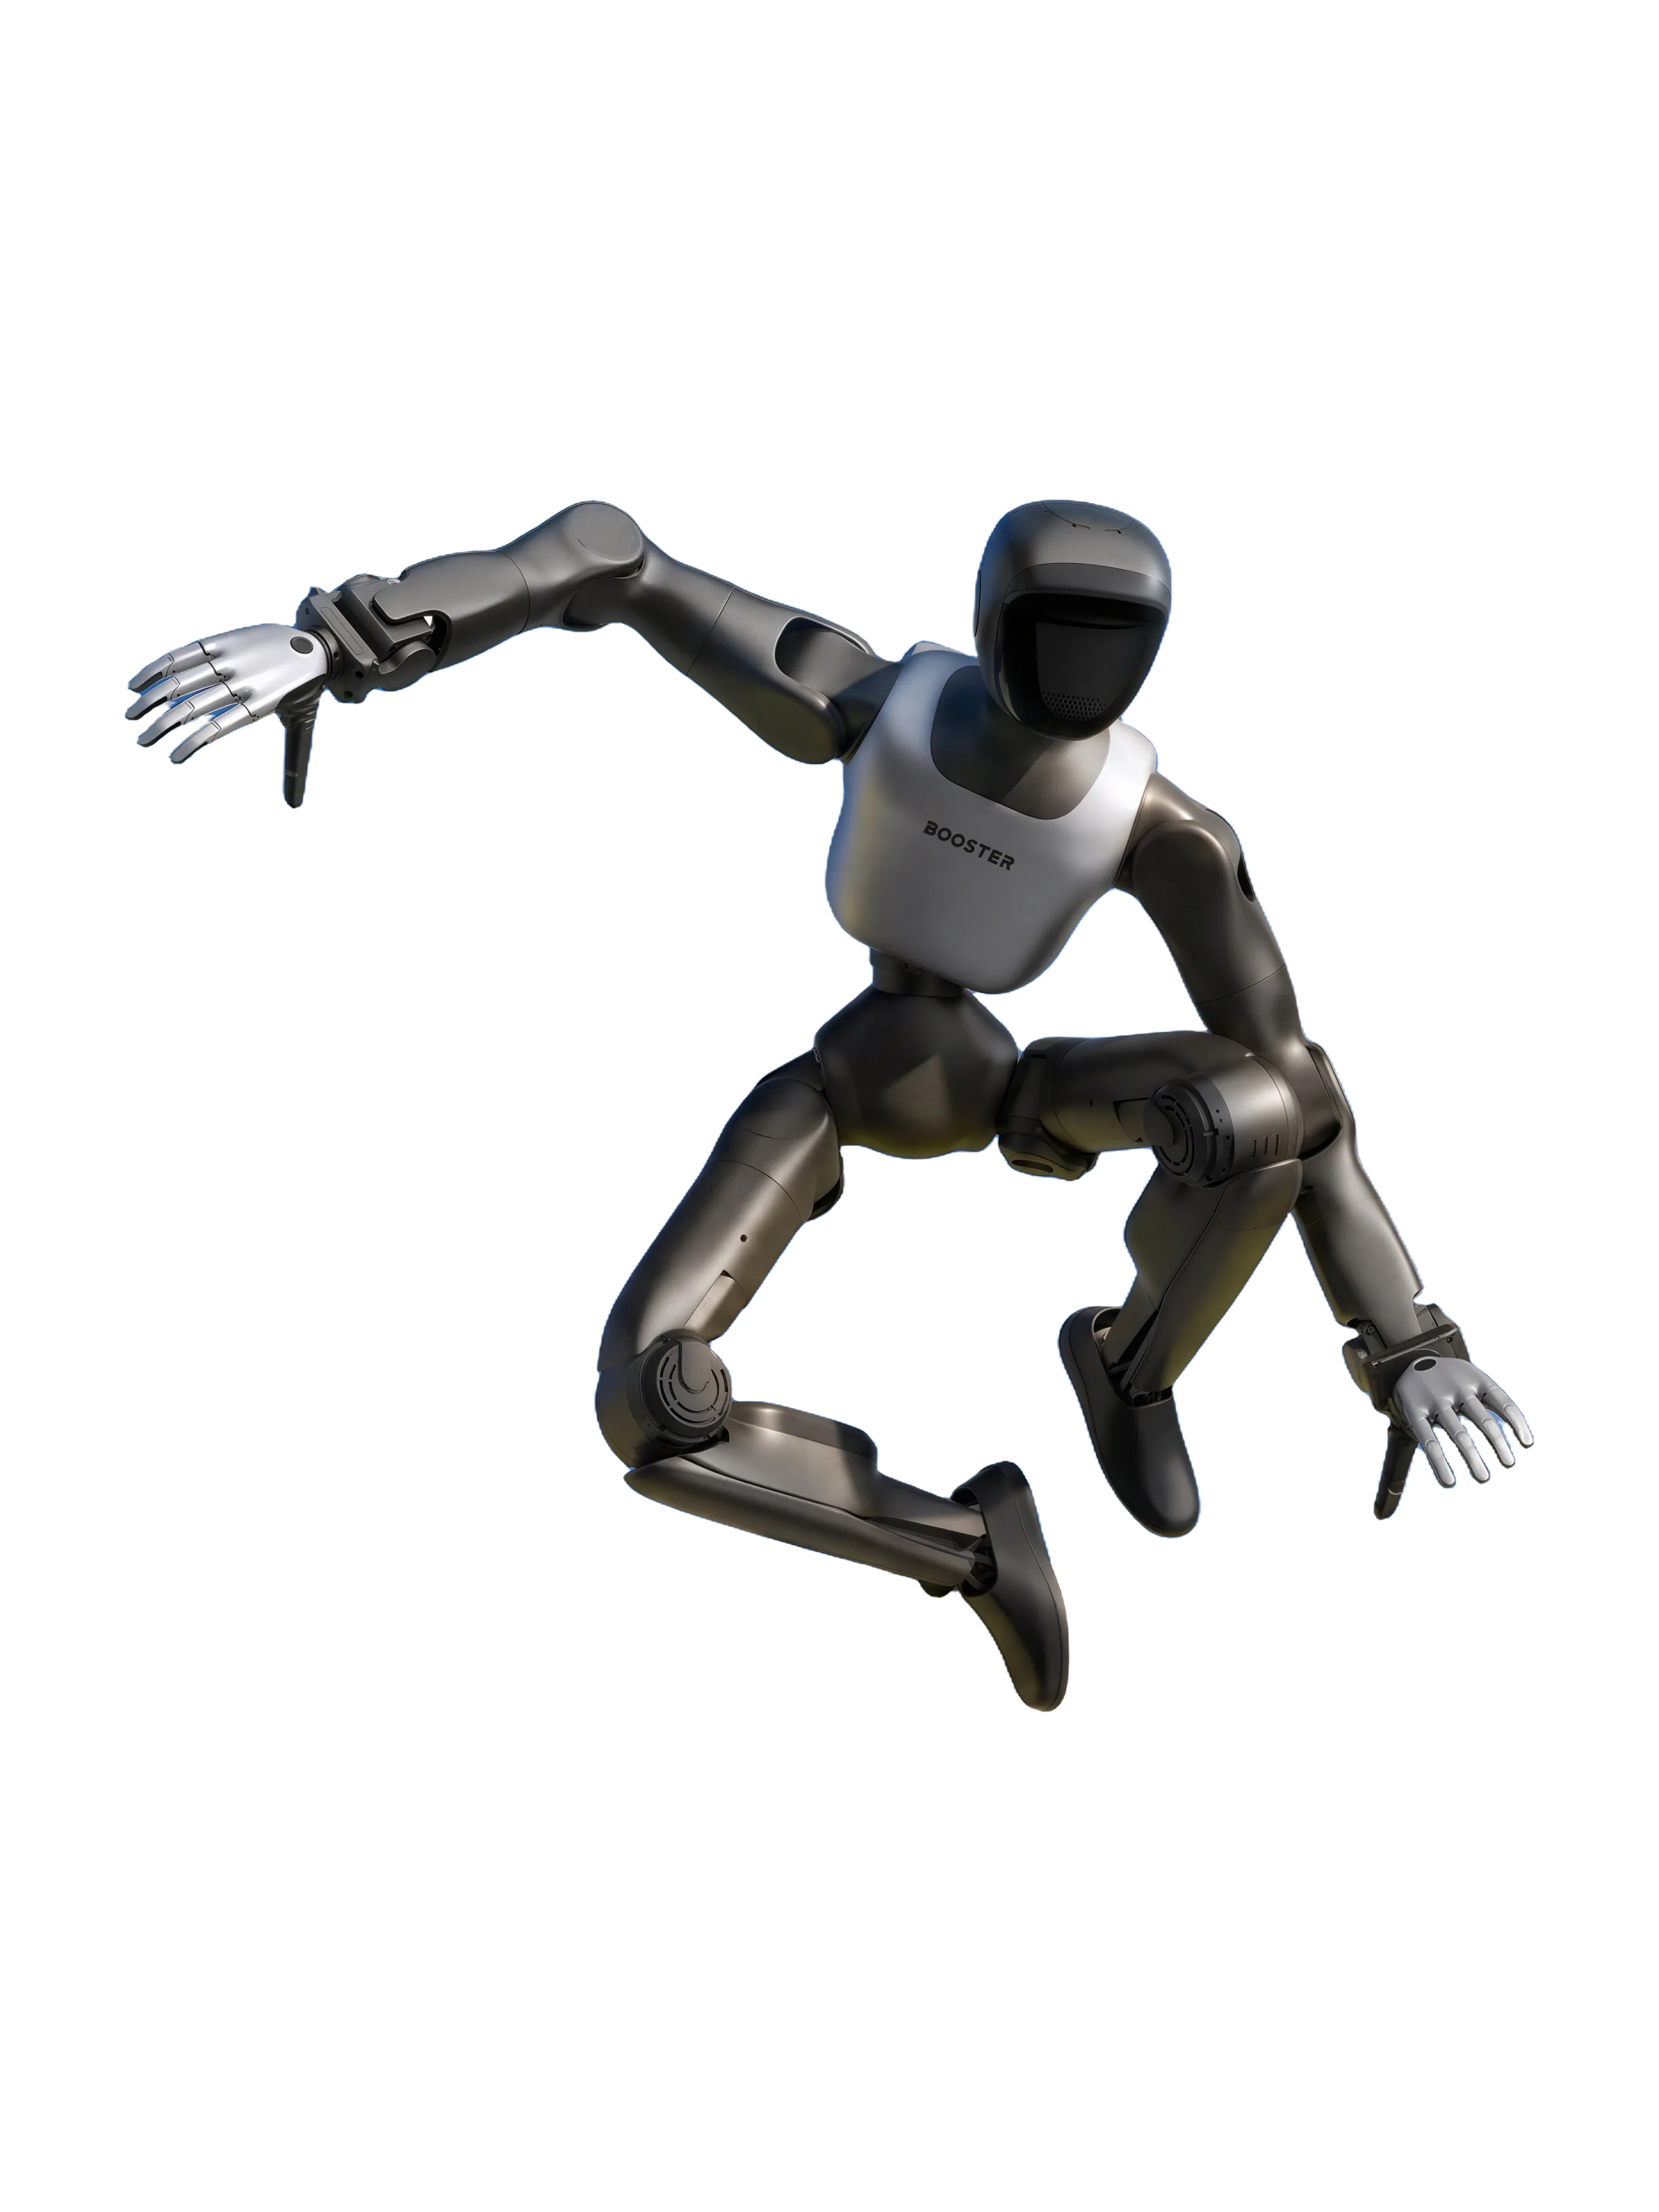
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
Our early strategy is oriented towards scientific research and education scenarios.
Source: booster.tech · Retrieved
This category is not our assessment.
Full specifications
9 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | approximately 30kgapproximately 66.1lbOur conversion from 30 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Same figure given for all three configurations (Basic, Standard, Customized). A |
| Length | 23cm9.06inOur conversion from 23 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat The producer gives 118×47×23 cm without naming the axes. 118 cm matches the "~1.2m" height stated elsewhere on the same page, so 118 cm is given as height, 47 cm as width and 23 cm as depth; the producer does not name the last two. A |
| Width | 47cm18.5inOur conversion from 47 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat The producer gives 118×47×23 cm without naming the axes. 118 cm matches the "~1.2m" height stated elsewhere on the same page, so 118 cm is given as height, 47 cm as width and 23 cm as depth; the producer does not name the last two. A |
| Height | 118cm46.5inOur conversion from 118 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat The producer gives 118×47×23 cm without naming the axes. 118 cm matches the "~1.2m" height stated elsewhere on the same page, so 118 cm is given as height, 47 cm as width and 23 cm as depth; the producer does not name the last two. A |
| Degrees of freedom | 23DoF | Note Total for the base-hand configuration (per limb: leg 6, waist 1, arm 4 each, head 2). Rises to 31 with a gripper or 41 with a dexterous hand. A |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | not stated | |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | 120minWarning: load condition not stated | Caveat Walking figure used (no carried-weight load is given for either figure). The producer separately states 4 hours for standing. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | One depth camera (Basic configuration). | Note Listed alongside a 9-axis IMU and a circular 6-microphone array plus speaker. A |
| Onboard compute | Nvidia AGX Orin GPU, 200 TOPS AI performance (Basic configuration). The Standard and Customized configurations additionally list an Intel i7 1370p CPU. | Note The Basic configuration's own spec panel lists no separate CPU line; only Standard and Customized add "CPU: Intel i7 1370p". A |
| ROS 2 | not stated | |
| SDK languages | not stated | Caveat Secondary-development support is stated but no specific SDK language is named anywhere on the page beyond "Comprehensive API Interfaces + Open-Source Framework + Open-Source Tools for Streamlined Development". Verbatim: "Secondary Development: Supported". A |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | USB Ethernet | Note Wi-Fi 6 and Bluetooth 5.2 are also listed as supported, alongside firmware-upgrade and secondary-development support. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Three purchasable configurations are listed on the producer's own page - Basic, Standard and Customized - which differ only in the hand or end-effector fitted and, for onboard compute, whether a separate CPU is included. Dimensions, weight, actuators and joint movement ranges are identical across all three; the figures here are for the Basic configuration.
- The total degree-of-freedom count rises with the end-effector: 23 for the base hand, 31 with an added gripper, or 41 with a dexterous hand, each with its own per-limb breakdown (legs, waist, arms, hands, head).
- Leg length (57 cm) and arm length (45 cm) are given as separate limb measurements alongside the overall body dimensions.
- Joint movement ranges are given for the waist, hip, knee and ankle (for example, a knee range of 0 to 123 degrees), together with a maximum actuator torque of 130 N.m and a dual encoder per joint.
- Basic, Standard and Customized configurations are sold, differing only in the fitted hand/end-effector (bare hand / gripper / dexterous hand) and, for the Basic configuration, the absence of a separate CPU. The figures are for the Basic configuration.
- Mike Kalil's technology news site reports that Booster launched the T1 in August 2024 at the World Robot Conference in Beijing.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for T1https://www.booster.tech/booster-t1/
Sources
-
A
Manufacturer product page. www.
booster. · Retrievedtech/ booster-t1/ -
B
www.
booster. · Retrievedtech/ about-us/
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.