Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 111kg245lbOur conversion from 111 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A 240–420minWarning: load condition not stated
- Max speed A 3.6km/h2.24mphOur conversion from 3.6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Weight
Note Weight with battery.
Payload, moving
Note The table gives a rated load of 1 kg and a maximum load of 1.5 kg per arm. Those are arm-specific figures, not figures for what the whole robot can carry.
Runtime
Caveat The row says the runtime depends on how the robot is used (translated from the Chinese); no load is stated. The overview page shows 4 h under the label for continuous work.
Max speed
Note Maximum speed of the base.
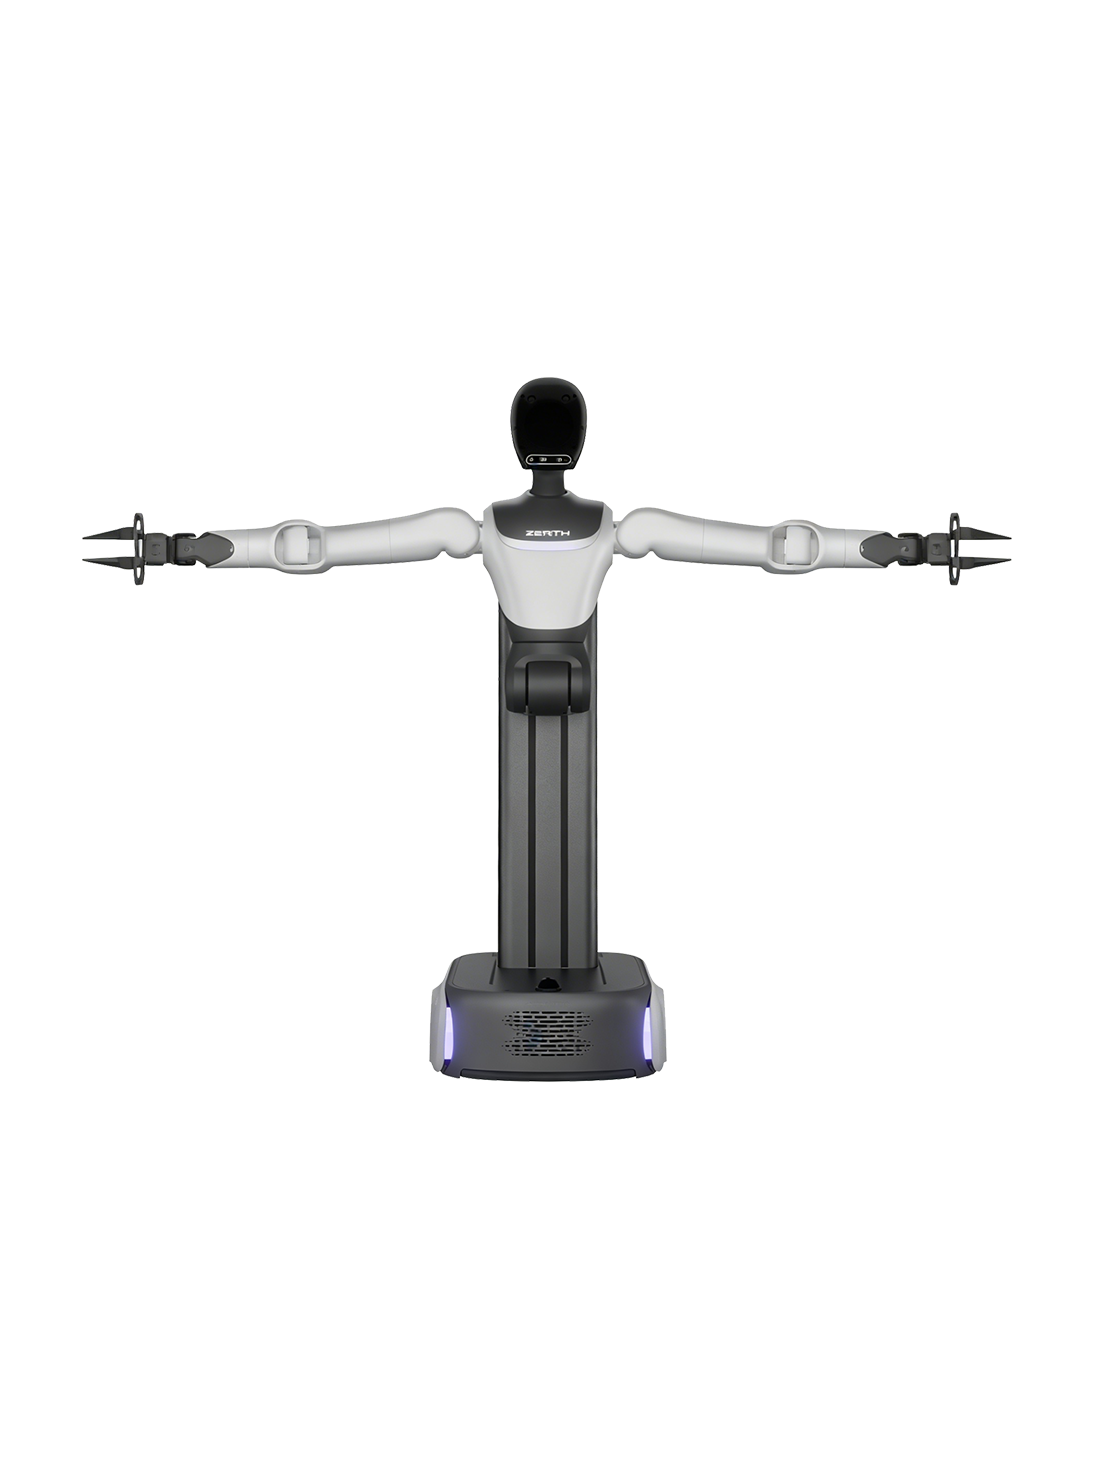
Manufacturer's own photo.
Intended use, per the manufacturer
Source: zerith.com · Retrieved
This category is not our assessment.
Full specifications
11 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 111kg245lbOur conversion from 111 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Weight with battery. A |
| Length | not stated | Caveat The table gives the chassis as 630 mm long, 463 mm wide and 226 mm high, which is the base alone and not the whole robot. A |
| Width | not stated | Caveat The table gives the chassis as 630 mm long, 463 mm wide and 226 mm high, which is the base alone and not the whole robot. A |
| Height | 95.5–175.6cm37.6–69.1inOur conversion from 95.5–175.6 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note The height is adjustable: the row gives a range from the lowest to the highest position of the lifting section. A |
| Degrees of freedom | 23DoF | Caveat Active degrees of freedom in total. The table lists 2 for the head, 7 for the "hand" row, 3 for the waist including lift, 2 for the chassis and 1 for the end effector. A |
| Payload, moving | not stated | Note The table gives a rated load of 1 kg and a maximum load of 1.5 kg per arm. Those are arm-specific figures, not figures for what the whole robot can carry. A |
| Payload, standing | not stated | Note The table gives a rated load of 1 kg and a maximum load of 1.5 kg per arm. Those are arm-specific figures, not figures for what the whole robot can carry. A |
| Max speed | 3.6km/h2.24mphOur conversion from 3.6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum speed of the base. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Note The table gives a capacity of 20000mAh and a 54.6V 10A power adapter, and names no battery voltage. A |
| Runtime | 240–420minWarning: load condition not stated | Caveat The row says the runtime depends on how the robot is used (translated from the Chinese); no load is stated. The overview page shows 4 h under the label for continuous work. A |
| Hot-swap battery | not stated | Caveat The charging-method row lists battery swapping and use while plugged in (translated from the Chinese); it does not say the robot stays powered during a swap. A |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | LiDAR. | Note Sensor row of the table, marked as present; no type or number is given. A |
| Cameras | Head depth camera and wrist depth camera. | Note Sensor rows of the table, each marked as present. A |
| Onboard compute | 20-core 28-thread high-performance CPU, 32 GB DDR5, 1 TB solid-state drive, 5060 graphics card. | Note Compute rows of the table. A |
| ROS 2 | not stated | |
| SDK languages | Python C++ | Note Named on the overview page next to "SDK fully open, upper-level and lower-level interfaces" (translated from the Chinese). B |
| Autonomy level | not stated | Caveat No named autonomy level is given. The page notes that, given current technology and compute, some functions need human operation or secondary development (translated from the Chinese), and lists VR remote operation. A |
| Payload and expansion | ||
| Mounting interface | not stated | Note The table lists a standard two-finger gripper and an optional dexterous hand; no mounting interface is named. A |
| Power out | 24V 5A x2, 48V 5A x2. | Note Power-supply interface row of the table. A |
| Data ports | Ethernet x2 HDMI x1 USB x3 | Note Communication interface row of the table. Wi-Fi and Bluetooth are listed separately. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer describes the H1 series as a "wheel-arm humanoid robot" (translated from the Chinese): a humanoid upper body on a differential-drive wheeled base with a lifting lower section of 0-800 mm.
- The specification table on the H1 page has a single column headed ZerithH1. The producer's solution pages also name an "H1 Pro" body for its robot shop and unmanned warehouse; the table does not mention a Pro version.
- The parameters page tells buyers to confirm the appearance and configuration with the producer's sales staff before purchase (translated from the Chinese). No price and no shop are shown; enquiries go through a business-cooperation contact form.
- The producer's site names the company as Hefei Zerith Robotics Co., Ltd. (translated from the Chinese).
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for H1https://www.zerith.com/product/comparison/
Sources
-
A
Manufacturer product page. www.
zerith. · Retrievedcom/ product/ comparison/ -
B
www.
zerith. · Retrievedcom/ product/ ZerithH1/
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.