Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A approximately 100kgapproximately 220lbOur conversion from 100 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A approximately 360minWarning: load condition not stated
- Max speed A approximately 0.4–3.6km/happroximately 0.25–2.24mphOur conversion from 0.4–3.6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Weight
Note Specification table, given as about 100 kg (translated from the Japanese).
Payload, moving
Caveat The producer gives a maximum payload of 10 kg for both arms within a set working area (translated from the Japanese). That is an arm figure, not a figure for what the whole robot can carry.
Runtime
Caveat The continuous operating time is given as about 6 hours; no load or task condition is given (translated from the Japanese).
Max speed
Note The travel speed is given as about 0.4 to 3.6 km/h (translated from the Japanese).
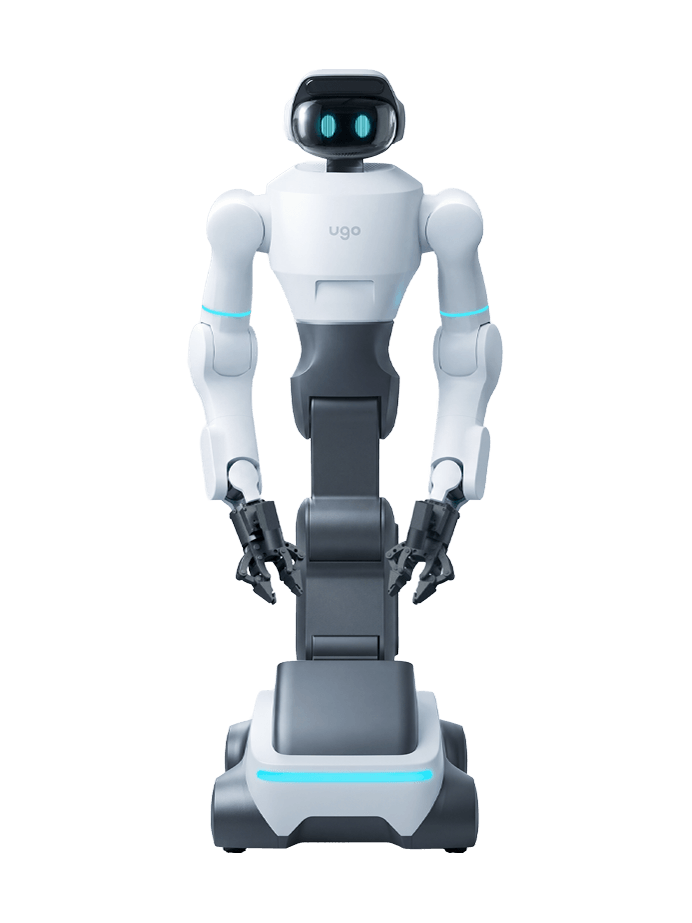
Manufacturer's own photo.
Intended use, per the manufacturer
Source: ugo.plus · Retrieved
This category is not our assessment.
Full specifications
13 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | approximately 100kgapproximately 220lbOur conversion from 100 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Specification table, given as about 100 kg (translated from the Japanese). A |
| Length | 65cm25.6inOur conversion from 65 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Specification table, given as the depth (translated from the Japanese). A |
| Width | 56cm22inOur conversion from 56 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Specification table, width (translated from the Japanese). A |
| Height | 126–162cm49.6–63.8inOur conversion from 126–162 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note The height is given as 126 cm folded to 162 cm at full extension (translated from the Japanese). A |
| Degrees of freedom | 22DoF | Note The producer gives 22 degrees of freedom in total, plus the four mecanum wheels; the breakdown is in the notes (translated from the Japanese). A |
| Payload, moving | not stated | Caveat The producer gives a maximum payload of 10 kg for both arms within a set working area (translated from the Japanese). That is an arm figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Caveat The producer gives a maximum payload of 10 kg for both arms within a set working area (translated from the Japanese). That is an arm figure, not a figure for what the whole robot can carry. A |
| Max speed | approximately 0.4–3.6km/happroximately 0.25–2.24mphOur conversion from 0.4–3.6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note The travel speed is given as about 0.4 to 3.6 km/h (translated from the Japanese). A |
| Max slope | approximately 5° | Note The climbing ability is given as about 5 degrees (a 1/12 slope, 8.5%) (translated from the Japanese). A |
| Single obstacle | approximately 1cmapproximately 0.39inOur conversion from 1 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note The step the robot can cross is given as about 1 cm (translated from the Japanese). A |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Caveat The battery is given as LiFePO4, 50.6 V and 22 Ah, without watt-hours. A |
| Runtime | approximately 360minWarning: load condition not stated | Caveat The continuous operating time is given as about 6 hours; no load or task condition is given (translated from the Japanese). A |
| Hot-swap battery | not stated | |
| Charge time | approximately 150min | Note Specification table, given as about 2.5 hours (translated from the Japanese). A |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | not stated | |
| Cameras | Stereo camera in the head; two RGB cameras in the hands. | Note Specification table (translated from the Japanese). A |
| Onboard compute | NVIDIA Jetson Thor. | Note Specification table, main PC. A |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | Ethernet USB-A USB-C | Note The table lists wired LAN of 5 Gbps or more, two USB-A (3.2 Gen2) and two USB-C (3.1) ports, plus Wi-Fi (translated from the Japanese). A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer calls ugo Nova a Japanese-made semi-humanoid robot with two arms on four mecanum wheels (translated from the Japanese).
- The joints are listed as head 2, each arm 7 plus a two-finger hand with 1, waist 4 and the wheeled base 4 (translated from the Japanese).
- The producer gives an arm reach of 843 mm and a lifting stroke of 350 mm (translated from the Japanese).
- The producer gives its address as Higashi-Kanda 1-7-8, Chiyoda-ku, Tokyo (translated from the Japanese).
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for ugo Novahttps://ugo.plus/ai/ugo-nova/
Sources
-
A
Manufacturer product page. ugo.
plus/ · Retrievedai/ ugo-nova/
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.