Peking University · robot AI model
UrbanVLA
China · 2025
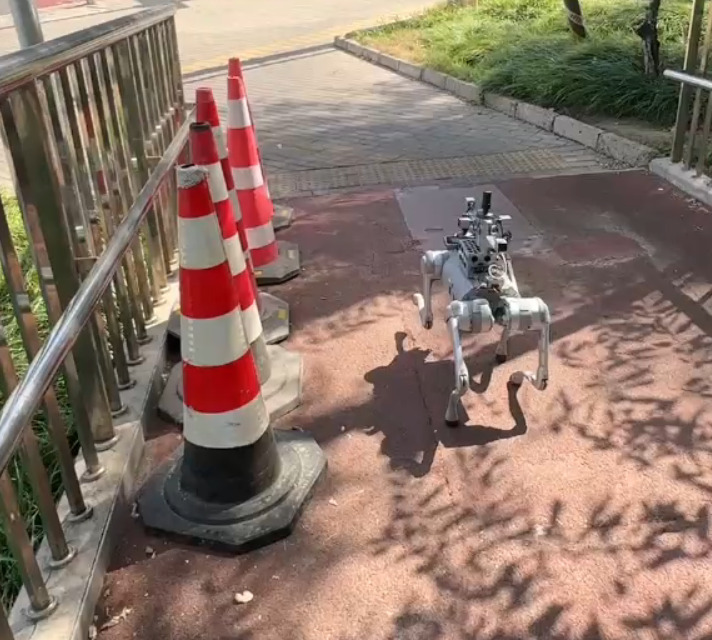
Runs on Go2 by Unitree RoboticsSource and note: Go2A arxiv.org/html/2510.23576 · Retrieved 18 November 2026
Sources retrieved: 18 November 2026 (A, B, C)
- Model type
- Vision-language-action (VLA)Source and note: Model typeC arxiv.org/abs/2510.23576 · Retrieved 18 November 2026Note. Developer wording: UrbanVLA is “a route-conditioned Vision-Language-Action (VLA) framework designed for scalable urban navigation”.
- Inputs
- Camera LanguageSource and note: InputsA arxiv.org/html/2510.23576 · Retrieved 18 November 2026Note. Real-world setup: “The robot collects visual observations from four cameras mounted on its front, left, right, and rear”. Abstract: the task is navigation “while following long-horizon route instructions”.
- Base model
- Qwen2Source and note: Base modelA arxiv.org/html/2510.23576 · Retrieved 18 November 2026Note. Technical report: the tokens are fed into “an LLM backbone (Qwen2”).
Specifications
5 of 14 stated 9 not stated
4 fields hidden 5 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Input and output2/4 disclosed
Size and speed1/2 disclosed
Where it runs and what it is built on1/2 disclosed
Openness0/3 disclosed
The developer’s own claims0/2 disclosed
Notes
The project page is on pku-epic.github.io, and the code repository is under the GitHub organisation GalaxyGeneralRobotics; the project page and the README list “Peking University” first among the affiliations, followed by “Galbot”.
Release status, repository README: “In the future, we will also release the model architecture and training code, as well as the checkpoint.”
Sources
One line per source, not per figure: a source has one retrieval date.
- Aarxiv.org/html/2510.23576Retrieved 18 November 2026
- Braw.githubusercontent.com/GalaxyGeneralRobotics/UrbanVLA/main/README.mdMain source. Retrieved 18 November 2026
- Carxiv.org/abs/2510.23576Retrieved 18 November 2026
More models
Same developer
LAWPeking University
- No photograph
LDA-1BPeking University
- No photograph
MM-NavPeking University
- No photograph
TrackVLAPeking University
- No photograph
TrackVLA++Peking University
Uni-NaVidPeking University