Peking University · robot AI model
LAW
China · 2026
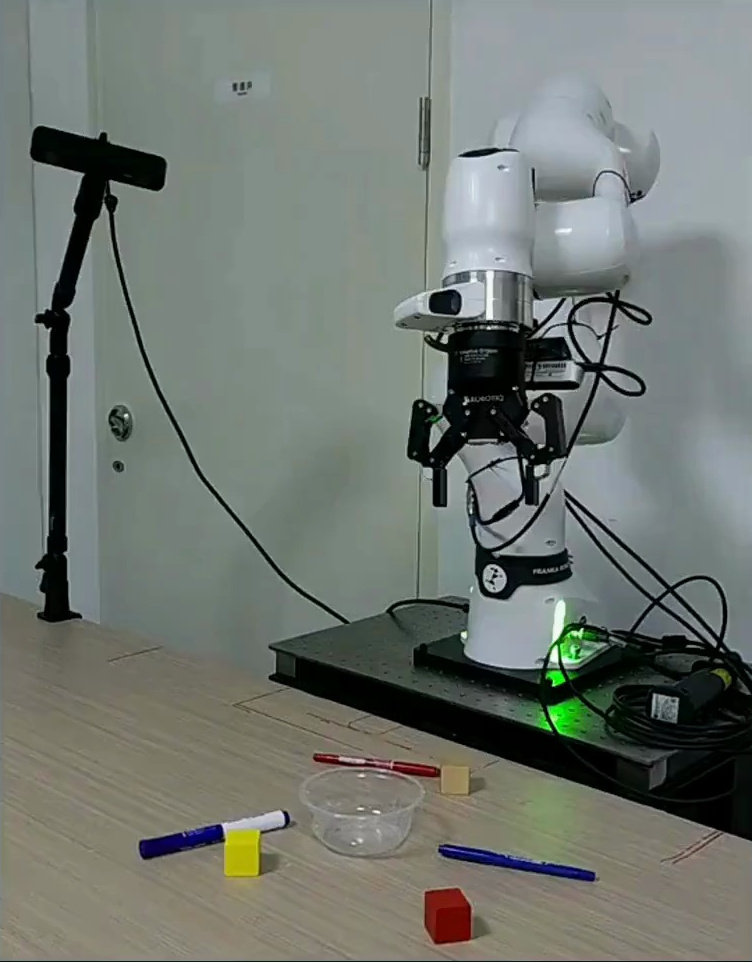
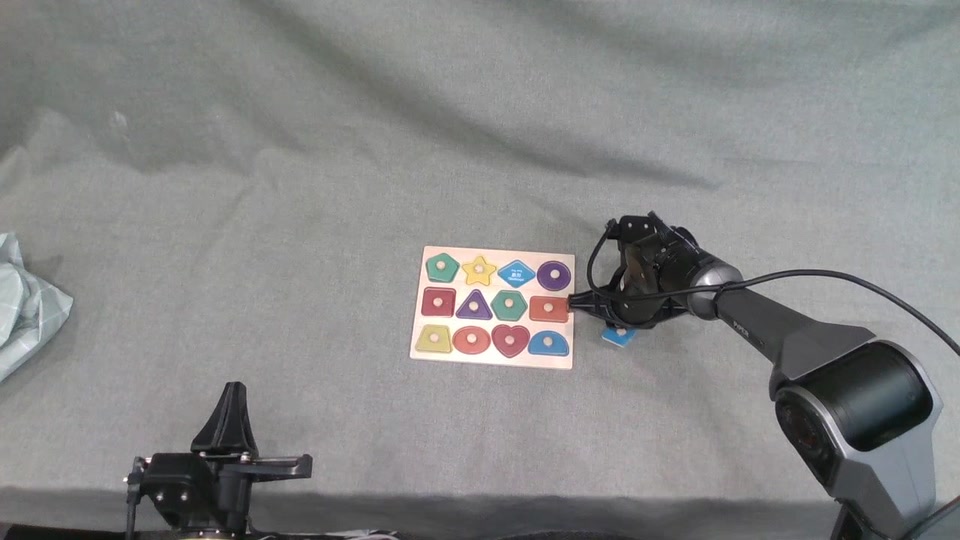
Runs on PiPER by AgileX RoboticsSource and note: PiPERA arxiv.org/html/2610.23334v2 · Retrieved 19 November 2026
Sources retrieved: 19 November 2026 (A, B, C)
- Model type
- World action modelSource and note: Model typeB arxiv.org/abs/2610.23334 · Retrieved 19 November 2026Note. “We present LAW, a closed-loop VLM--WAM framework that unifies language reasoning, action generation, and world modeling through semantic subtask progress.”
- What it controls
- Arms and handsSource and note: What it controlsB arxiv.org/abs/2610.23334 · Retrieved 19 November 2026Note. “We present LAW, a closed-loop VLM--WAM framework that unifies language reasoning, action generation, and world modeling through semantic subtask progress.” Tested on “Experiments are conducted on an AgileX (Songling) Cobot Magic platform equipped with two six-degree-of-freedom PiPER arms and parallel-jaw grippers.”
- Inputs
- Camera Language Robot stateSource and note: InputsA arxiv.org/html/2610.23334v2 · Retrieved 19 November 2026Note. “Visual observations comprise three RGB views: a scene camera covering the shared workspace and a wrist-mounted camera on each arm.” “The WAM uses RGB, EEF state, and visual memory; the VLM uses RGB and visual memory, with joint-state values additionally supplied to the state expert.” “We present LAW, a closed-loop VLM--WAM framework that unifies language reasoning, action generation, and world modeling through semantic subtask progress.”
- Access
- Open weights (download)Source and note: AccessC github.com/hey-cjj/LAW · Retrieved 19 November 2026Note. Checkpoints for LAW-FastWAM, LAW-VLM-FastWAM, LAW-OpenWAM, and LAW-VLM-OpenWAM are publicly hosted on Hugging Face (“Download checkpoints, foundation weights, RoboTwin assets and data”).
- Base model
- Qwen3-VL-2B-Instruct + Wan2.2-TI2V-5BSource and note: Base modelA arxiv.org/html/2610.23334v2 · Retrieved 19 November 2026Note. Shared VLM backbone: “We use Qwen3-VL-2B-Instruct [ 2 ] as the shared VLM backbone”. WAM backbone: “The WAM is initialized from Wan2.2-TI2V-5B”.
- Licence type
- Free, commercial useSource and note: Licence typeC github.com/hey-cjj/LAW · Retrieved 19 November 2026Note. “Root code: MIT. LAW-authored trained weights: Apache-2.0. LAW-authored annotations: CC-BY-4.0.”
Specifications
8 of 14 stated 6 not stated
2 fields hidden 4 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Input and output3/4 disclosed
Size and speed0/2 disclosed
Where it runs and what it is built on1/2 disclosed
Openness3/3 disclosed
The developer’s own claims0/2 disclosed
Notes
Developed jointly by Peking University and the Beijing Innovation Center of Humanoid Robotics.
Described by the authors as “We present LAW, a closed-loop VLM--WAM framework that unifies language reasoning, action generation, and world modeling through semantic subtask progress.”
Model weights for LAW-FastWAM, LAW-VLM-FastWAM, LAW-OpenWAM, and LAW-VLM-OpenWAM are publicly released.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aarxiv.org/html/2610.23334v2Retrieved 19 November 2026
- Barxiv.org/abs/2610.23334Main source. Retrieved 19 November 2026
- Cgithub.com/hey-cjj/LAWRetrieved 19 November 2026
More models
Same developer
- No photograph
LDA-1BPeking University
- No photograph
MM-NavPeking University
- No photograph
TrackVLAPeking University
- No photograph
TrackVLA++Peking University
Uni-NaVidPeking University
UrbanVLAPeking University