Peking University · robot AI model
LDA-1B
China · 2026
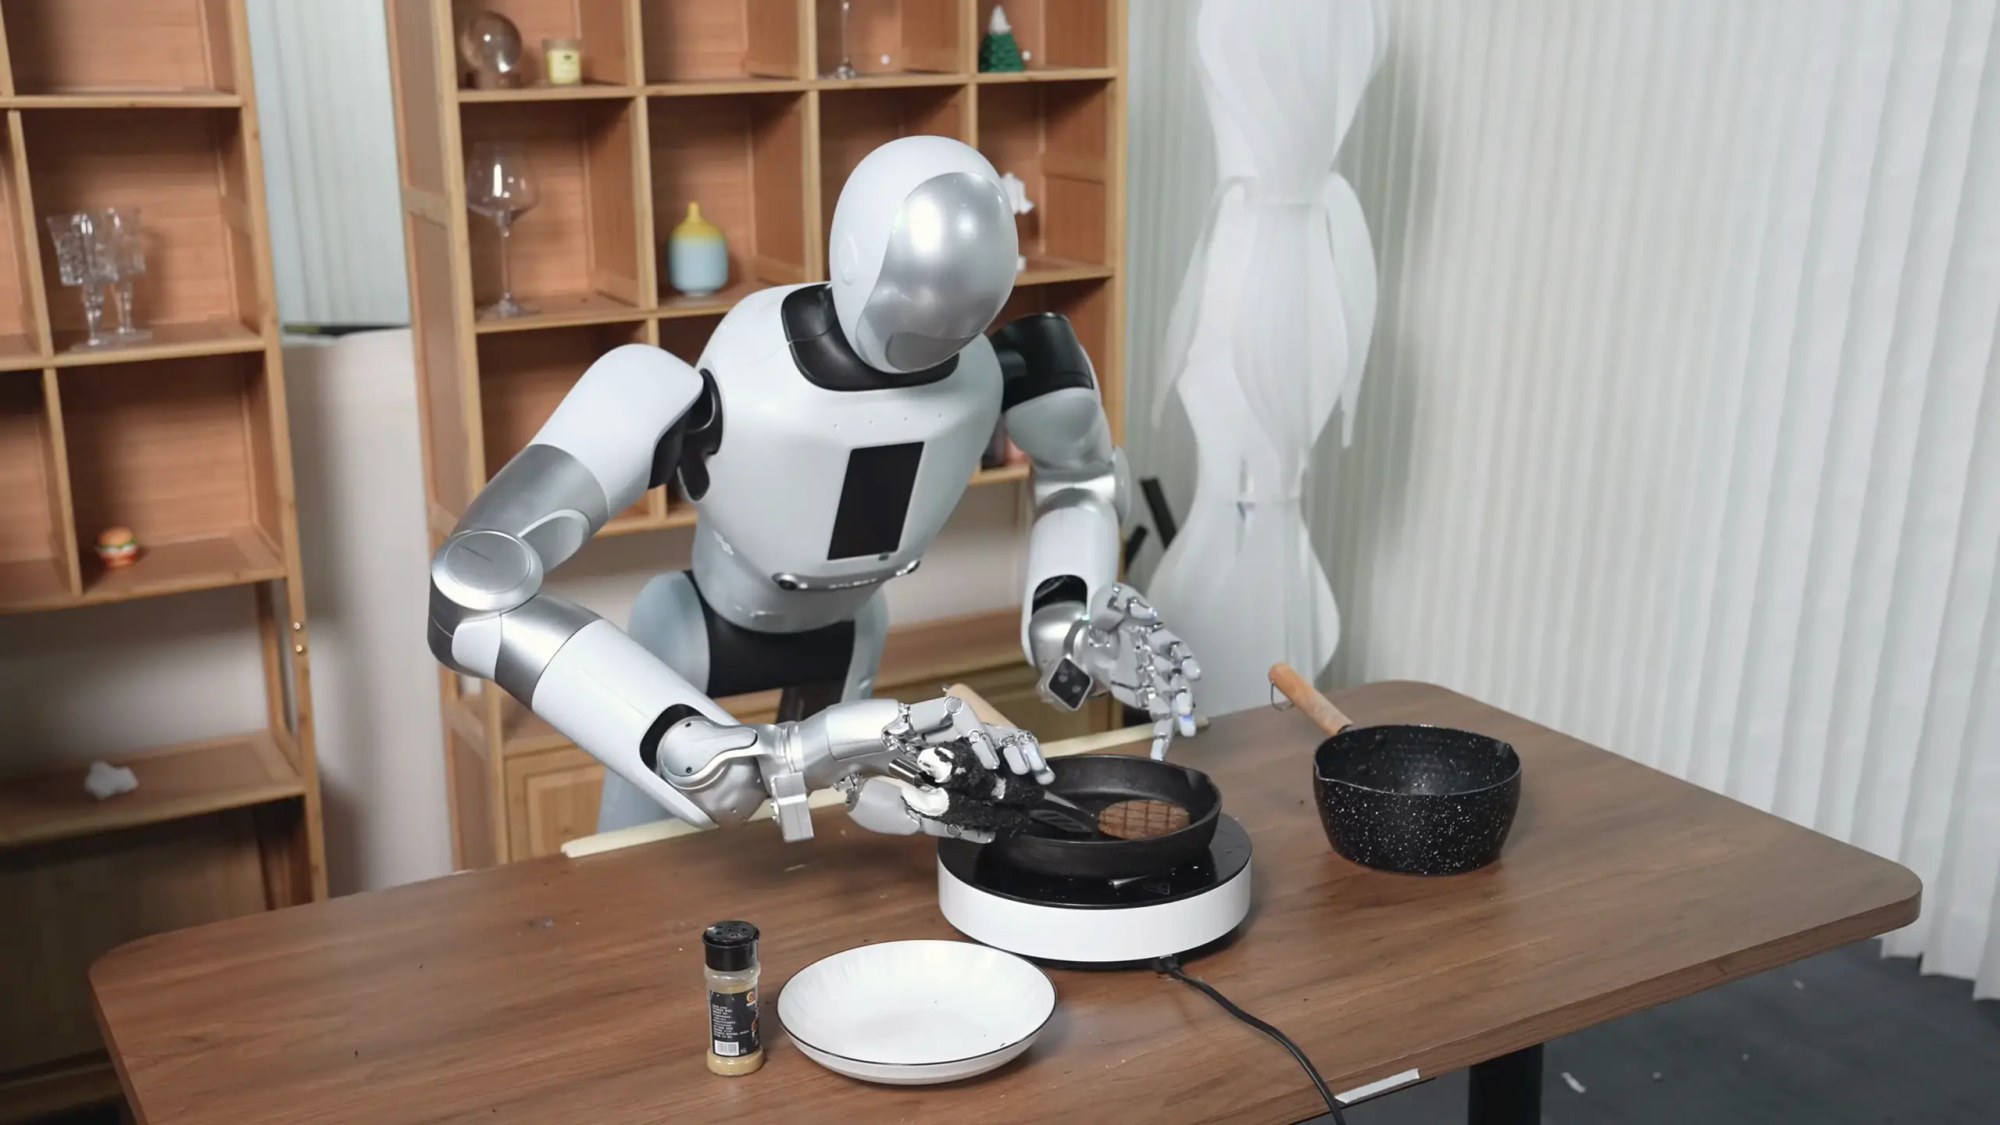
Runs on G1 by Galbot · G1 by Unitree RoboticsSource and note: G1 (Galbot), G1 (Unitree Robotics)B pku-epic.github.io/LDA/ · Retrieved 13 November 2026
Sources retrieved: 13 November 2026 (A, B, C, D)
- What it controls
- Arms and handsSource and note: What it controlsA github.com/jiangranlv/latent-dynamics-action · Retrieved 13 November 2026Note. Code repository: “Predicts denoised 16-step action chunks”. Project page, robot platforms: “Galbot G1 equipped with a standard two-finger parallel gripper for basic grasping tasks”; “Galbot G1 fitted with the SharpaWave dexterous hand (22 DoF) for fine manipulation”; “Unitree G1 mounted with the BrainCo dexterous hand (10 DoF) and a Zed Mini camera”.
- Inputs
- Camera LanguageSource and note: InputsA github.com/jiangranlv/latent-dynamics-action · Retrieved 13 November 2026Note. Code repository: the language and vision encoder is “Qwen3-VL (4B) → extracts semantics information”; image tokens are DINOv3 patch embeddings.
- Access
- Open weights (download)Source and note: AccessD huggingface.co/api/models/Wayer2/LDA-pretrain · Retrieved 13 November 2026Note. Hugging Face repository metadata list the file “LDA-pretrain.pt” and mark the repository as not gated.
- Licence type
- Free, commercial useSource and note: Licence typeD huggingface.co/api/models/Wayer2/LDA-pretrain · Retrieved 13 November 2026Note. Pretrained checkpoint under “license:apache-2.0”, not gated. The project page lists the training data as coming soon.
Specifications
8 of 14 stated 6 not stated
3 fields hidden 3 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- yesStated by a source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Input and output2/4 disclosed
Size and speed0/2 disclosed
Where it runs and what it is built on0/2 disclosed
Openness3/3 disclosed
The developer’s own claims2/2 disclosed
Notes
The project page credits Peking University and Galbot, together with CASIA, BAAI, Tsinghua University, Sun Yat-sen University and NVIDIA. The paper title calls it a Latent Dynamics Action Model, and the abstract says: “We introduce LDA-1B, a robot foundation model that scales through universal embodied data ingestion by jointly learning dynamics, policy, and visual forecasting”.
Sources
One line per source, not per figure: a source has one retrieval date.
- Agithub.com/jiangranlv/latent-dynamics-actionRetrieved 13 November 2026
- Bpku-epic.github.io/LDA/Main source. Retrieved 13 November 2026
- Carxiv.org/abs/2602.12215Retrieved 13 November 2026
- Dhuggingface.co/api/models/Wayer2/LDA-pretrainRetrieved 13 November 2026