Dexmal · robot AI model
DM0.5
China · 2026
Sources retrieved: 2 November 2026 (A, B, C, D, E, F)
- Model type
- Vision-language-action (VLA)Source and note: Model typeD github.com/dexmal/opendm · Retrieved 2 November 2026Note. Dexmal's own term in the code repository: “DM0.5 is Dexmal's next-generation Vision-Language-Action model (VLA) for open-world robot control.”
- What it controls
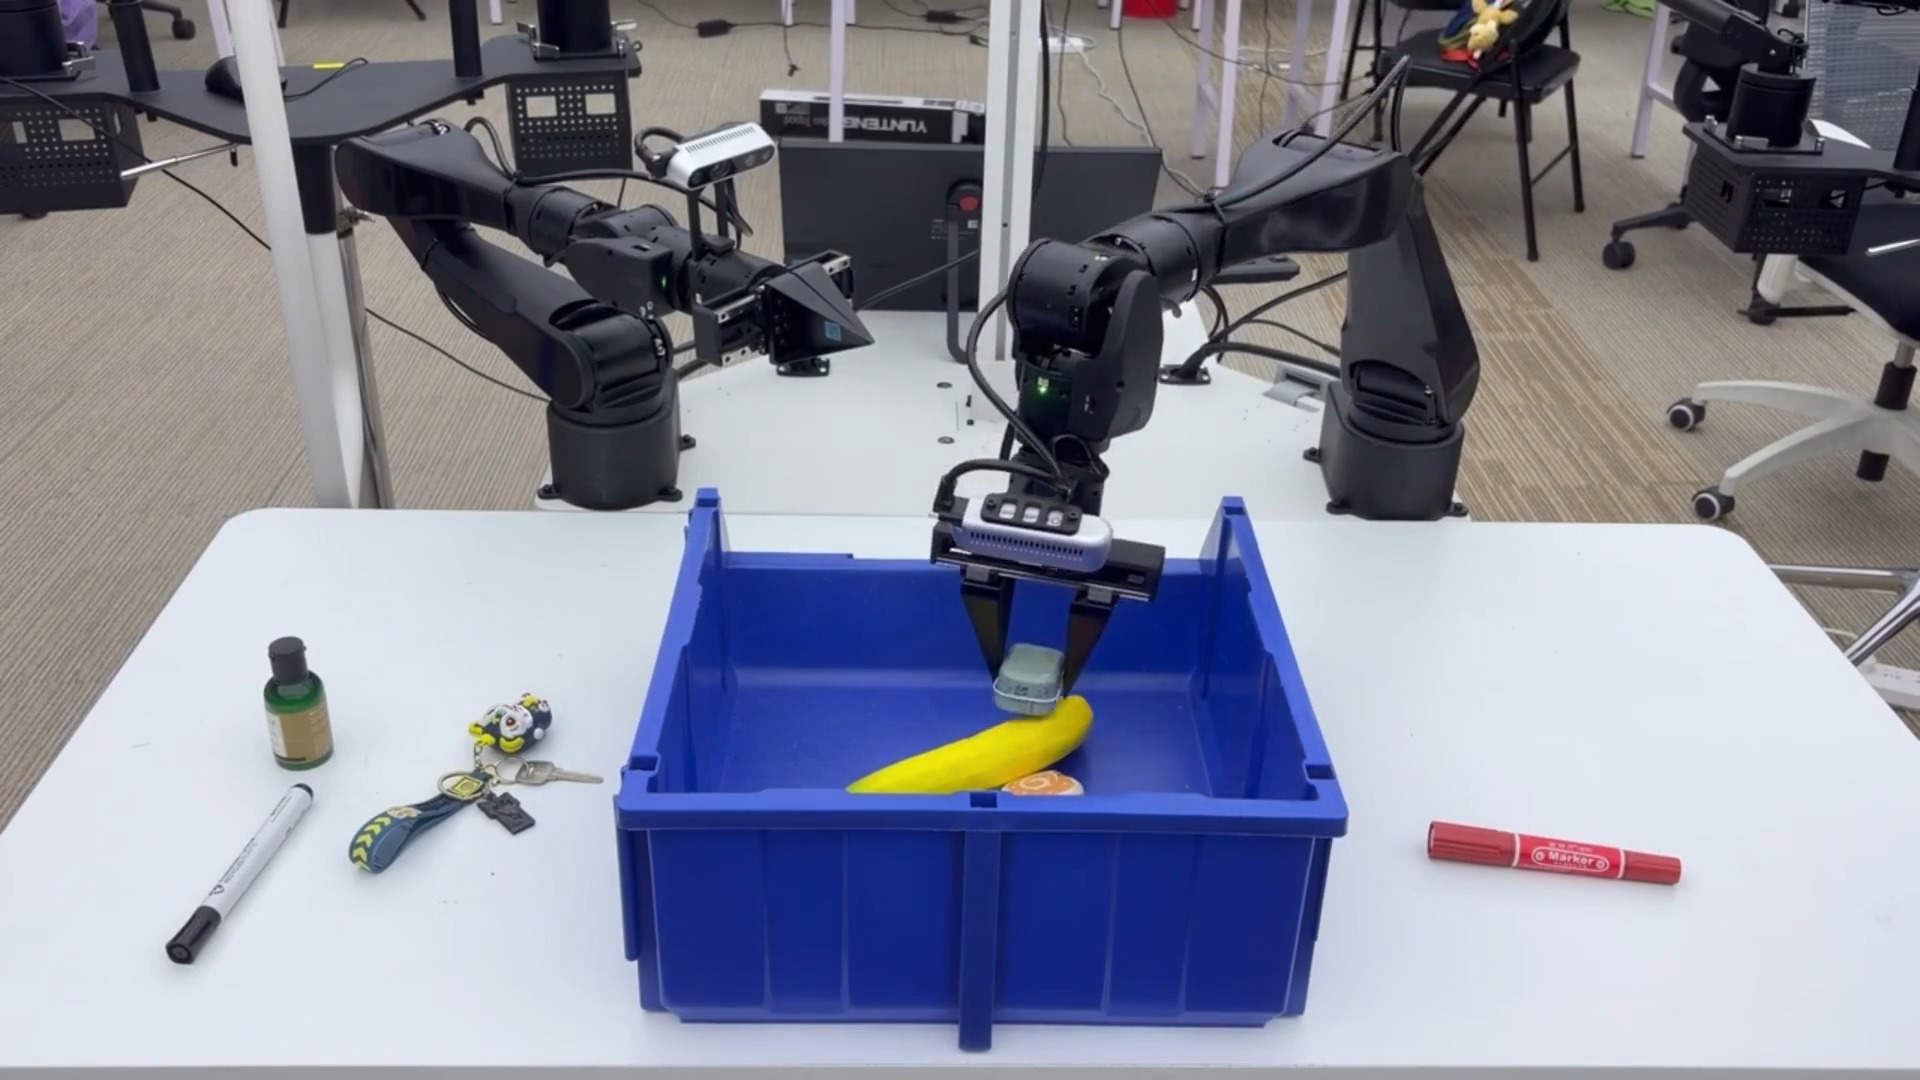
- Arms and hands Whole bodySource and note: What it controlsB dexmal.com/models/dm0.5 · Retrieved 2 November 2026Note. Dexmal's model page (Chinese) says one model supports navigation, grasping and whole-body control: “一个模型支持导航、抓取、全身控制 3 大任务”. The arm and gripper joints are listed in the physical robot guide: “six left-arm joints, the left gripper, six right-arm joints, and the right gripper, for 14 dimensions in total”.
- Inputs
- Camera Language Robot stateSource and note: InputsA dexmal.com/blog/dm0.5?lang=en-US · Retrieved 2 November 2026Note. Technical blog: “the current image, robot state, task instruction, and historical context”. The inference example uses three cameras: “This example uses three images and a 14-dimensional state/action.”.
- Access
- Open weights (download)Source and note: AccessD github.com/dexmal/opendm · Retrieved 2 November 2026Note. Hugging Face repository, listed as not gated: “OpenDM provides DM0.5 model weights, training and inference scripts”
- Parameters
- 4BSource and note: ParametersB dexmal.com/models/dm0.5 · Retrieved 2 November 2026Note. Dexmal's model page headline is “4B参数”. Layers: “DM0.5 follows a VLA architecture using a 4B Vision-Language Model (VLM) as the backbone and a 680M Action Expert”.
- Base model
- Gemma 3Source and note: Base modelF huggingface.co/Dexmal/DM05/blob/main/config.json · Retrieved 2 November 2026Note. Hugging Face config.json of the base checkpoint lists model type gemma3 for the language model; the backbone size is the 4B Vision-Language Model named in the technical blog.
- Licence document
- GemmaSource and note: Licence documentE huggingface.co/api/models/Dexmal/DM05 · Retrieved 2 November 2026Note. Weights: the Hugging Face repository carries the tag “license:gemma”. Code: the repository licence file starts with “Apache License”.
Specifications
12/14 specifications disclosed 2 not stated
0 fields hidden 2 not-stated fields with a note stay ·
How to read the figuresShow guideClose
Not statedThe developer publishes nothing on itYesThe developer says it does
Select a source marker for source details and notes.
Release1/1 disclosed
Released9 July 2026
Source and note: ReleasedD github.com/dexmal/opendm · Retrieved 2 November 2026Note. [A] “[2026-07-09] DM0.5 is officially released.”
Input and output4/4 disclosed
Model typeVision-language-action (VLA)
Source and note: Model typeD github.com/dexmal/opendm · Retrieved 2 November 2026Note. Dexmal's own term in the code repository: “DM0.5 is Dexmal's next-generation Vision-Language-Action model (VLA) for open-world robot control.”
InputsCamera Language Robot state
Source and note: InputsA dexmal.com/blog/dm0.5?lang=en-US · Retrieved 2 November 2026Note. Technical blog: “the current image, robot state, task instruction, and historical context”. The inference example uses three cameras: “This example uses three images and a 14-dimensional state/action.”.
What it controlsArms and hands Whole body
Source and note: What it controlsB dexmal.com/models/dm0.5 · Retrieved 2 November 2026Note. Dexmal's model page (Chinese) says one model supports navigation, grasping and whole-body control: “一个模型支持导航、抓取、全身控制 3 大任务”. The arm and gripper joints are listed in the physical robot guide: “six left-arm joints, the left gripper, six right-arm joints, and the right gripper, for 14 dimensions in total”.
Degrees of freedom controlled14DoF
Source and note: Degrees of freedom controlledC github.com/dexmal/opendm/blob/main/docs/en/robot_platforms.md · Retrieved 2 November 2026Note. For the AgileX COBOT Magic setup (Dexmal's physical robot guide): “six left-arm joints, the left gripper, six right-arm joints, and the right gripper, for 14 dimensions in total”.
Size and speed2/2 disclosed
Parameters4B
Source and note: ParametersB dexmal.com/models/dm0.5 · Retrieved 2 November 2026Note. Dexmal's model page headline is “4B参数”. Layers: “DM0.5 follows a VLA architecture using a 4B Vision-Language Model (VLM) as the backbone and a 680M Action Expert”.
Control rate20Hz
Source and note: Control rateA dexmal.com/blog/dm0.5?lang=en-US · Retrieved 2 November 2026Note. Model inference, the fastest stated rate: “DM0.5 runs at 10 Hz on a single NVIDIA RTX 4090 and 20 Hz on a single NVIDIA H100”. Each pass produces an action chunk: “it uses 10 diffusion / Flow Matching steps to generate a 50-step action chunk”. The model page states “50ms推理延迟” (inference latency).
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Source and note: On robot or cloudD github.com/dexmal/opendm · Retrieved 2 November 2026Note. The README says “1 GPU is sufficient for deployment inference”; it does not say where the model runs on a robot.
Base modelGemma 3
Source and note: Base modelF huggingface.co/Dexmal/DM05/blob/main/config.json · Retrieved 2 November 2026Note. Hugging Face config.json of the base checkpoint lists model type gemma3 for the language model; the backbone size is the 4B Vision-Language Model named in the technical blog.
Openness2/3 disclosed
AccessOpen weights (download)
Source and note: AccessD github.com/dexmal/opendm · Retrieved 2 November 2026Note. Hugging Face repository, listed as not gated: “OpenDM provides DM0.5 model weights, training and inference scripts”
Licence documentGemma
Source and note: Licence documentE huggingface.co/api/models/Dexmal/DM05 · Retrieved 2 November 2026Note. Weights: the Hugging Face repository carries the tag “license:gemma”. Code: the repository licence file starts with “Apache License”.
Licence typeNot stated
Source and note: Licence typeE huggingface.co/api/models/Dexmal/DM05 · Retrieved 2 November 2026Note. The Hugging Face repository tags the weights “license:gemma” and the code is licensed under Apache 2.0; the Gemma terms are not quoted by Dexmal.
The developer’s own claims2/2 disclosed
Learns new tasksWithout examples
Source and note: Learns new tasksA dexmal.com/blog/dm0.5?lang=en-US · Retrieved 2 November 2026Note. Developer claim, technical blog: “DM0.5 extends the zero-shot capability of VLA models to unseen open environments, where it follows natural-language instructions from users to complete robotic manipulation tasks.”
Works across robotsYes
Source and note: Works across robotsA dexmal.com/blog/dm0.5?lang=en-US · Retrieved 2 November 2026Note. Technical blog: “We evaluate four model-platform configurations: Pi0.5-Droid and DM0.5-Droid on the Franka platform; DM0 and DM0.5 on the Dexmal-Mirror platform.” It adds: “DM0.5 can be transferred through post-training to robot embodiments that were not seen during pretraining”.Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
Dexmal presents DM0.5 as the successor of its first model DM0, released in February 2026.
Dexmal says the model can take up to 60 seconds of task history into account.
Dexmal gives its company address in Beijing.
Dexmal tests DM0.5 on its own Dexmal-Mirror platform and on the AgileX COBOT Magic.
Sources
One line per source, not per figure: a source has one retrieval date.
- Adexmal.com/blog/dm0.5?lang=en-USMain source. Retrieved 2 November 2026
- Bdexmal.com/models/dm0.5Retrieved 2 November 2026
- Cgithub.com/dexmal/opendm/blob/main/docs/en/robot_platforms.mdRetrieved 2 November 2026
- Dgithub.com/dexmal/opendmRetrieved 2 November 2026
- Ehuggingface.co/api/models/Dexmal/DM05Retrieved 2 November 2026
- Fhuggingface.co/Dexmal/DM05/blob/main/config.jsonRetrieved 2 November 2026