Zhejiang University · robot AI model
Atomic-WAM
China · 2026
Sources retrieved: 19 November 2026 (A, B, C)
- Model type
- World action modelSource and note: Model typeA arxiv.org/abs/2610.20157 · Retrieved 19 November 2026Note. “To this end, we introduce Atomic-WAM, an understand-then-execute framework that connects task reasoning to action generation through atomic-motion descriptions.”
- What it controls
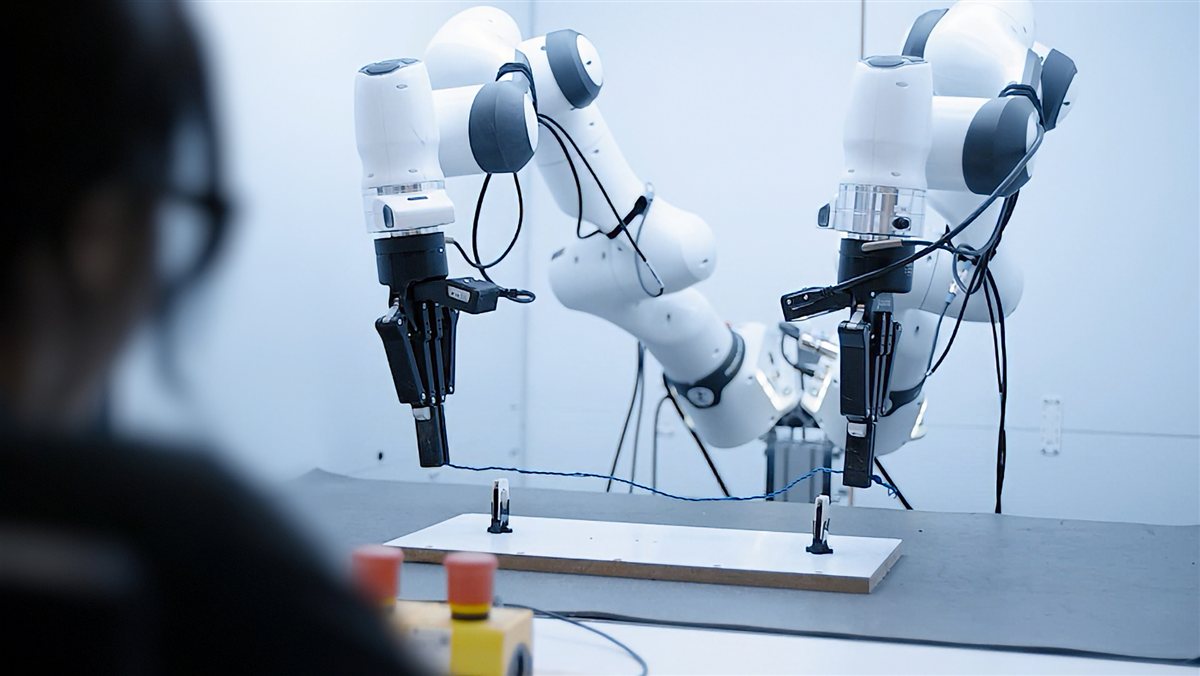
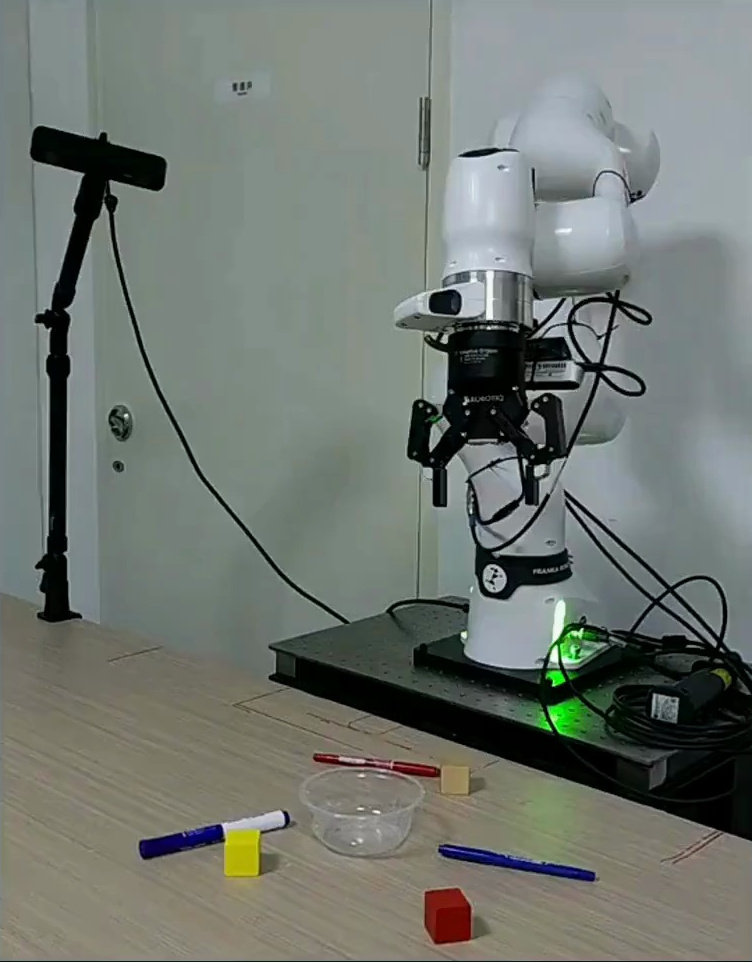
- Arms and handsSource and note: What it controlsA arxiv.org/abs/2610.20157 · Retrieved 19 November 2026Note. “Specifically, a vision-language reasoner describes the next local motion from the task instruction and visual context, guiding a WAM to predict future video and an action chunk.” Real-world evaluation: “We train on DROID and deploy on our Franka setup without further fine-tuning.”
- Inputs
- Camera Language Robot stateSource and note: InputsA arxiv.org/abs/2610.20157 · Retrieved 19 November 2026Note. “Specifically, a vision-language reasoner describes the next local motion from the task instruction and visual context, guiding a WAM to predict future video and an action chunk.” The WAM also receives current observation “and robot state”.
- Access
- Open weights (download)Source and note: AccessB github.com/ssj9596/Atomic-WAM · Retrieved 19 November 2026Note. “Paper, inference code, and model weights released.”
- Base model
- Cosmos3-NanoSource and note: Base modelC arxiv.org/html/2610.20157v1 · Retrieved 19 November 2026Note. Built as an “understand-then-execute framework with Cosmos3-Nano”.
- Licence document
- OpenMDW-1.1Source and note: Licence documentB github.com/ssj9596/Atomic-WAM · Retrieved 19 November 2026Note. Cosmos files are covered by OpenMDW-1.1; RoboLab files are covered by Apache-2.0.
Specifications
7 of 14 stated 7 not stated
4 fields hidden 3 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released14 October 2026
Source and note: ReleasedA arxiv.org/abs/2610.20157 · Retrieved 19 November 2026Note. arXiv submission date: “Submitted on 14 Oct 2026”.
Input and output3/4 disclosed
Model typeWorld action model
Source and note: Model typeA arxiv.org/abs/2610.20157 · Retrieved 19 November 2026Note. “To this end, we introduce Atomic-WAM, an understand-then-execute framework that connects task reasoning to action generation through atomic-motion descriptions.”
InputsCamera Language Robot state
Source and note: InputsA arxiv.org/abs/2610.20157 · Retrieved 19 November 2026Note. “Specifically, a vision-language reasoner describes the next local motion from the task instruction and visual context, guiding a WAM to predict future video and an action chunk.” The WAM also receives current observation “and robot state”.
What it controlsArms and hands
Source and note: What it controlsA arxiv.org/abs/2610.20157 · Retrieved 19 November 2026Note. “Specifically, a vision-language reasoner describes the next local motion from the task instruction and visual context, guiding a WAM to predict future video and an action chunk.” Real-world evaluation: “We train on DROID and deploy on our Franka setup without further fine-tuning.”
Degrees of freedom controlledNot stated
Size and speed0/2 disclosed
ParametersNot stated
Control rateNot stated
Where it runs and what it is built on1/2 disclosed
On robot or cloudNot stated
Source and note: On robot or cloudB github.com/ssj9596/Atomic-WAM · Retrieved 19 November 2026Note. “The model server runs on Linux with an NVIDIA CUDA GPU.”
Base modelCosmos3-Nano
Source and note: Base modelC arxiv.org/html/2610.20157v1 · Retrieved 19 November 2026Note. Built as an “understand-then-execute framework with Cosmos3-Nano”.
Openness2/3 disclosed
AccessOpen weights (download)
Source and note: AccessB github.com/ssj9596/Atomic-WAM · Retrieved 19 November 2026Note. “Paper, inference code, and model weights released.”
Licence documentOpenMDW-1.1
Source and note: Licence documentB github.com/ssj9596/Atomic-WAM · Retrieved 19 November 2026Note. Cosmos files are covered by OpenMDW-1.1; RoboLab files are covered by Apache-2.0.
Licence typeNot stated
Source and note: Licence typeB github.com/ssj9596/Atomic-WAM · Retrieved 19 November 2026Note. Cosmos files are covered by OpenMDW-1.1; RoboLab files are covered by Apache-2.0.
The developer’s own claims0/2 disclosed
Learns new tasksNot stated
Works across robotsNot stated
Source and note: Works across robotsYes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
Developed by researchers from Zhejiang University, University of Hong Kong, ACE Robotics, and Jiangnan University; first-author work was completed during an internship at ACE Robotics.
Described by the authors as “To this end, we introduce Atomic-WAM, an understand-then-execute framework that connects task reasoning to action generation through atomic-motion descriptions.”
WAM weights, Reasoner LoRA, and inference code are publicly released.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aarxiv.org/abs/2610.20157Main source. Retrieved 19 November 2026
- Bgithub.com/ssj9596/Atomic-WAMRetrieved 19 November 2026
- Carxiv.org/html/2610.20157v1Retrieved 19 November 2026