BeingBeyond · robot AI model
Being-H0.8
China · 2026
Sources retrieved: 10 November 2026 (A)
- Model type
- World action modelSource and note: Model typeA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. BeingBeyond's own term, the title of the blog post: “Being-H0.8: A Latent Tactile World-Action Model at Scale”.
- What it controls
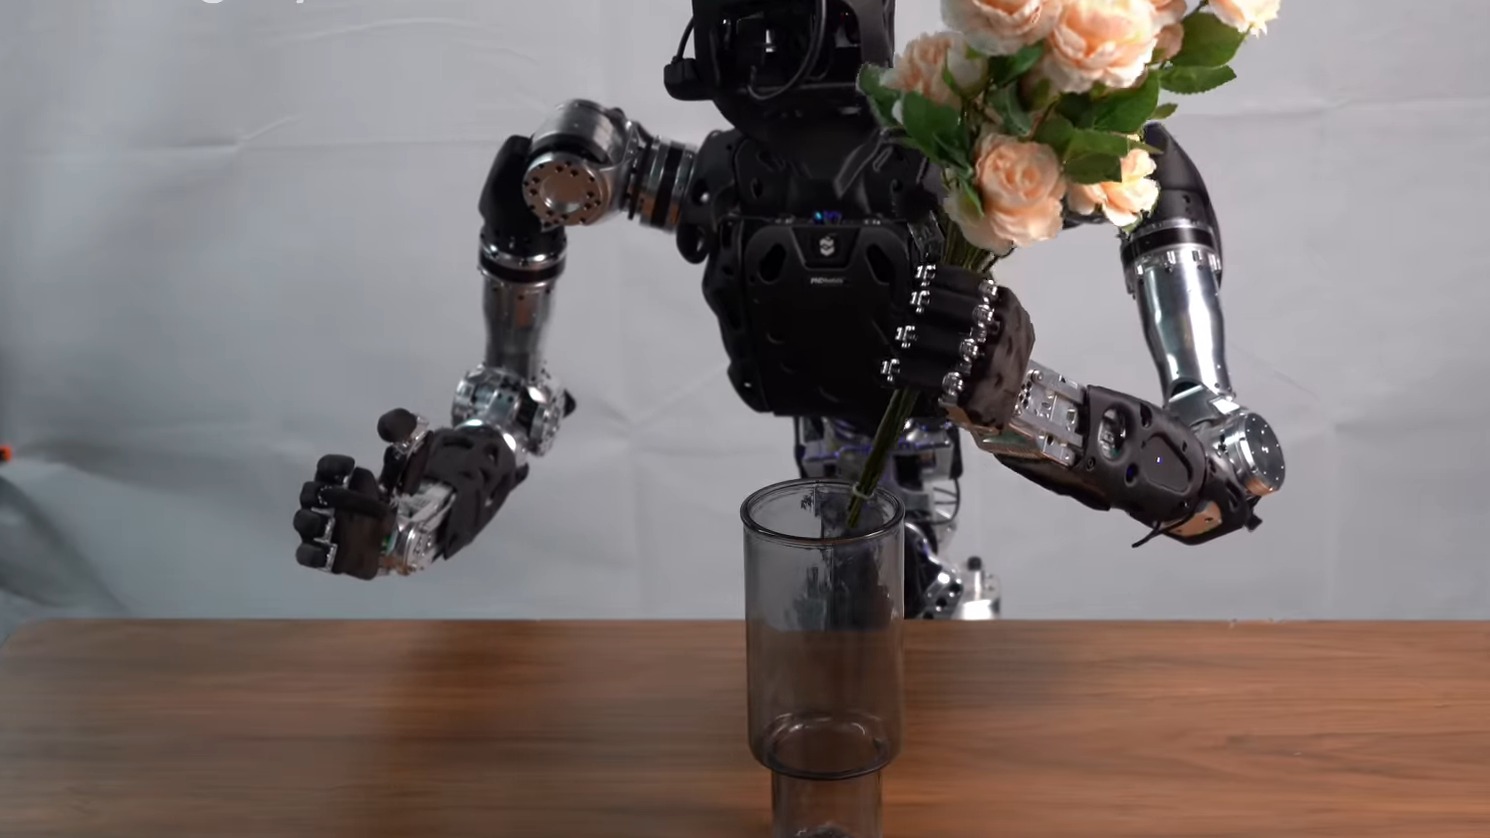
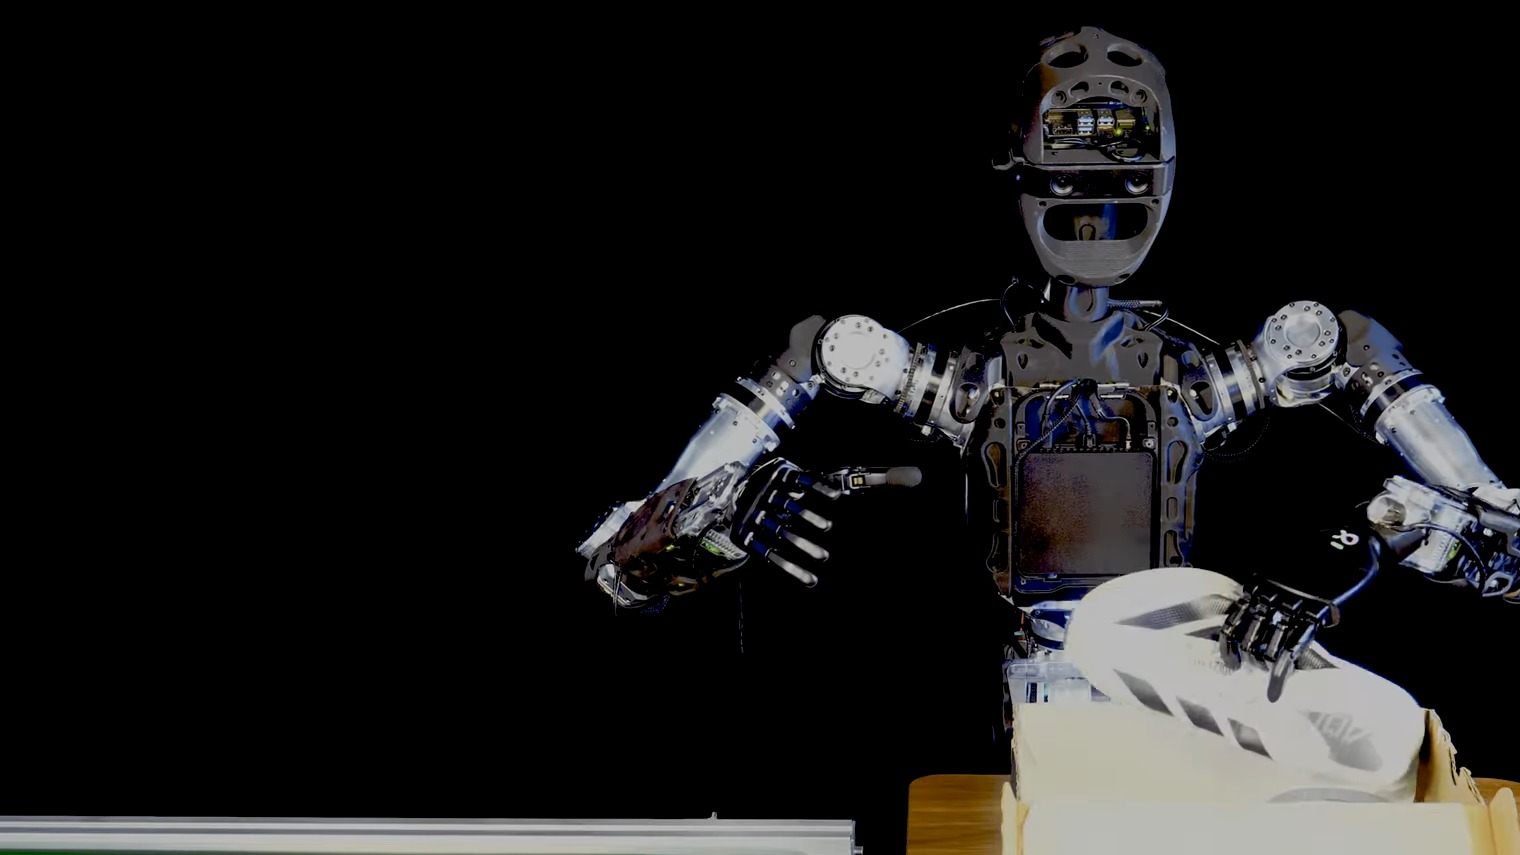
- Arms and handsSource and note: What it controlsA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. Blog post: “Being-H0.8 is deployed on two complementary bimanual platforms.” “The first uses two ROKAE AR5 manipulators and supports interchangeable dexterous hands for cross-embodiment evaluation”. “The action comprises wrist translation and rotation updates followed by absolute target joint angles.”
- Inputs
- Camera Language Robot state TouchSource and note: InputsA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. Blog post: “The deployable prior combines the current instruction and visual observations with learned latent queries”. The action expert “incorporates the latest proprioceptive state and tactile feedback”.
Specifications
5 of 14 stated 9 not stated
5 fields hidden 4 not-stated fields with a note stay ·
How to read the figuresShow guideClose
- not statedNo source
- yesStated by a source
- 0Reported as zero
- ASource
Select a source marker for source details and notes.
Release1/1 disclosed
Released28 July 2026
Source and note: ReleasedA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. [A] The blog post is dated “Jul 28, 2026”.
Input and output3/4 disclosed
Model typeWorld action model
Source and note: Model typeA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. BeingBeyond's own term, the title of the blog post: “Being-H0.8: A Latent Tactile World-Action Model at Scale”.
InputsCamera Language Robot state Touch
Source and note: InputsA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. Blog post: “The deployable prior combines the current instruction and visual observations with learned latent queries”. The action expert “incorporates the latest proprioceptive state and tactile feedback”.
What it controlsArms and hands
Source and note: What it controlsA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. Blog post: “Being-H0.8 is deployed on two complementary bimanual platforms.” “The first uses two ROKAE AR5 manipulators and supports interchangeable dexterous hands for cross-embodiment evaluation”. “The action comprises wrist translation and rotation updates followed by absolute target joint angles.”
Degrees of freedom controlledNot stated
Source and note: Degrees of freedom controlledA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. The blog post gives the hand-model action interface, not a DoF total for a named robot setup: “wrist motion and 20 canonical joint angles describe the current state and future action”.
Size and speed0/2 disclosed
ParametersNot stated
Control rateNot stated
Source and note: Control rateA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. The blog post gives no frequency in Hz: “This preserves full-horizon planning with higher-frequency reactive control”.
Where it runs and what it is built on0/2 disclosed
On robot or cloudNot stated
Base modelNot stated
Source and note: Base modelA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. The blog post names its predecessor but no base checkpoint: “Being-H0.8 extends the latent World–Action Model of Being-H0.7 from visual prediction to tactile-aware interaction learning.”
Openness0/3 disclosed
AccessNot stated
Source and note: AccessA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. The blog post says “Paper coming soon” and names no checkpoint, code or API release.
Licence documentNot stated
Licence typeNot stated
The developer’s own claims1/2 disclosed
Learns new tasksNot stated
Works across robotsYes
Source and note: Works across robotsA research.beingbeyond.com/being-h08 · Retrieved 10 November 2026Note. Blog post: “Being-H0.8 is deployed on two complementary bimanual platforms.” “The first uses two ROKAE AR5 manipulators and supports interchangeable dexterous hands for cross-embodiment evaluation”. “The second platform combines two RealMan RM65 manipulators with Inspire grippers”. The shared action space works “without embodiment-specific policy heads”.Yes only if the developer itself says the model runs on different robot models, for example robots from two manufacturers or two of one manufacturer’s models. Several units of the same robot do not count.
Notes
BeingBeyond introduces Being-H0.8 on its research blog as its latest general-purpose embodied foundation model; the technical paper is not yet published.
BeingBeyond lists its Beijing address on its own website.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aresearch.beingbeyond.com/being-h08Main source. Retrieved 10 November 2026