Istituto Italiano di Tecnologia
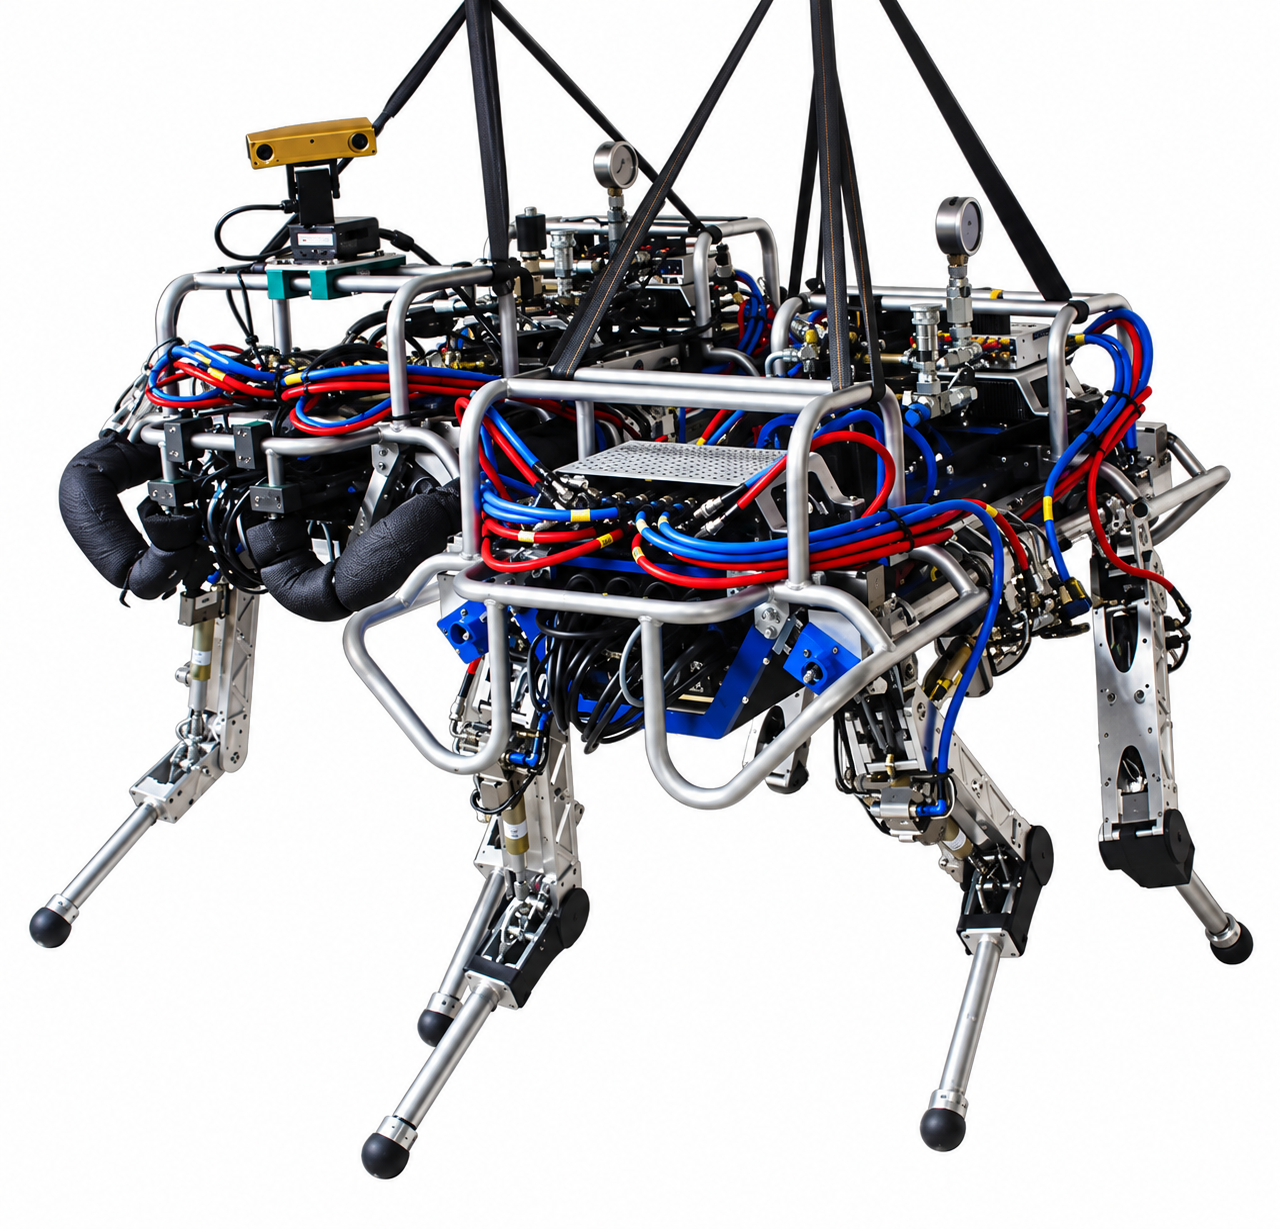
HyQ
A quadruped robot from Italy, first released 2010.
Sources retrieved: 4 September 2026 (A)
- Status
- Discontinued
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- Legged robots are vehicles with the potential to replace humans in dangerous and dirty tasks where vehicles with wheels and tracks cannot go. Possible applications are disaster recovery... search and rescue, forestry technology and construction.Source and note: Intended use, per the manufacturerA iit.it/web/dynamic-legged-systems/hyq · Retrieved 4 September 2026
- Person
175 cm68.9 in - 100 cm39.4 inHeight
98 cm38.6 in
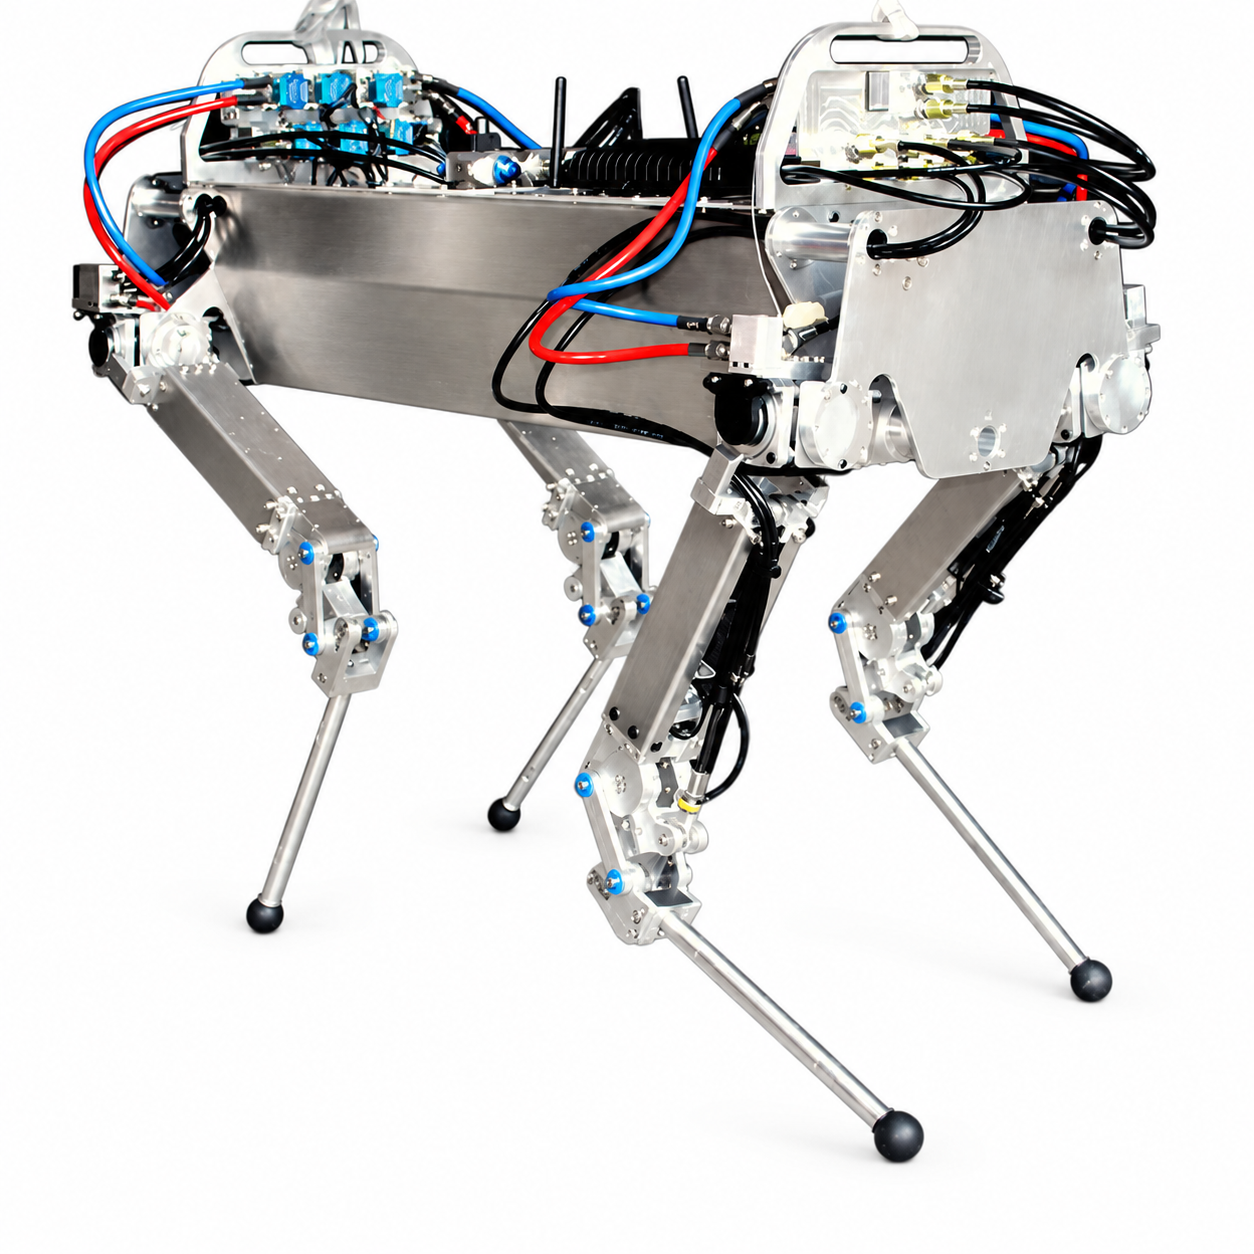
Manufacturer's own photo.
Drawn at one scale next to a 175 cm person, from the figures the maker states: height 98 cm and length 100 cm.Drawn at one scale next to a 68.9 in person, from the figures the maker states, converted to inches: height 38.6 in and length 39.4 in.
Specifications
8/33 specifications disclosed 25 not stated
25 fields hidden
Not statedThe manufacturer states nothing about this field.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical7/14 disclosed
Power0/5 disclosed
Sensing and autonomy1/6 disclosed
Payload and expansion0/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Height
98cm38.6inOur conversion from 980 mm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
89 quadrupeds state a height
1 states a higher figure, 87 a lower one.
Weight
80kg176lbOur conversion from 80 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
124 quadrupeds state a weight
11 state a higher figure, 109 a lower one. 1 more states exactly the same figure. Log scale: each step along the axis multiplies the value.
Degrees of freedom
12DoF
76 quadrupeds state degrees of freedom
15 state a higher figure, 4 a lower one. 56 more state exactly the same figure.
Max speed
7.2km/h4.47mphOur conversion from 2 m/s. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
113 quadrupeds state a top speed
61 state a higher figure, 19 a lower one. 5 more state exactly the same figure.
Notes
A hydraulically actuated quadruped developed by the Dynamic Legged Systems lab at Istituto Italiano di Tecnologia, starting in 2010.
12 active joints powered by hydraulic cylinders and rotary actuators; a research predecessor to IIT's later hydraulic quadrupeds.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aiit.it/web/dynamic-legged-systems/hyqMain source. Retrieved 4 September 2026
More robots
Same manufacturer
All robots from Istituto Italiano di Tecnologia