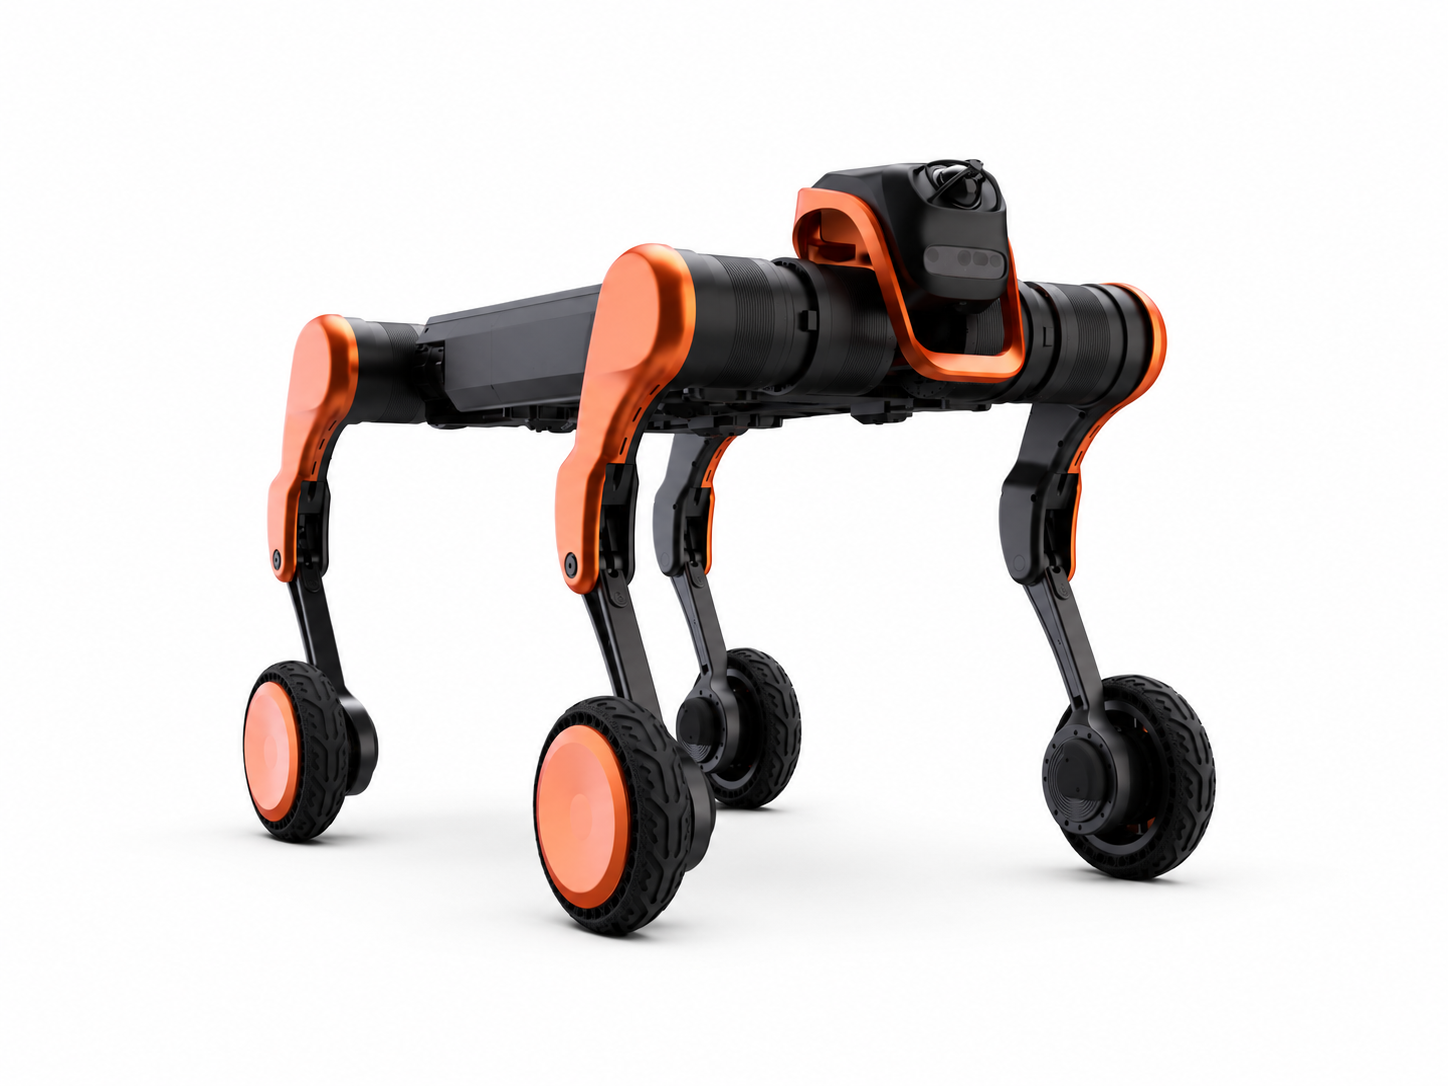
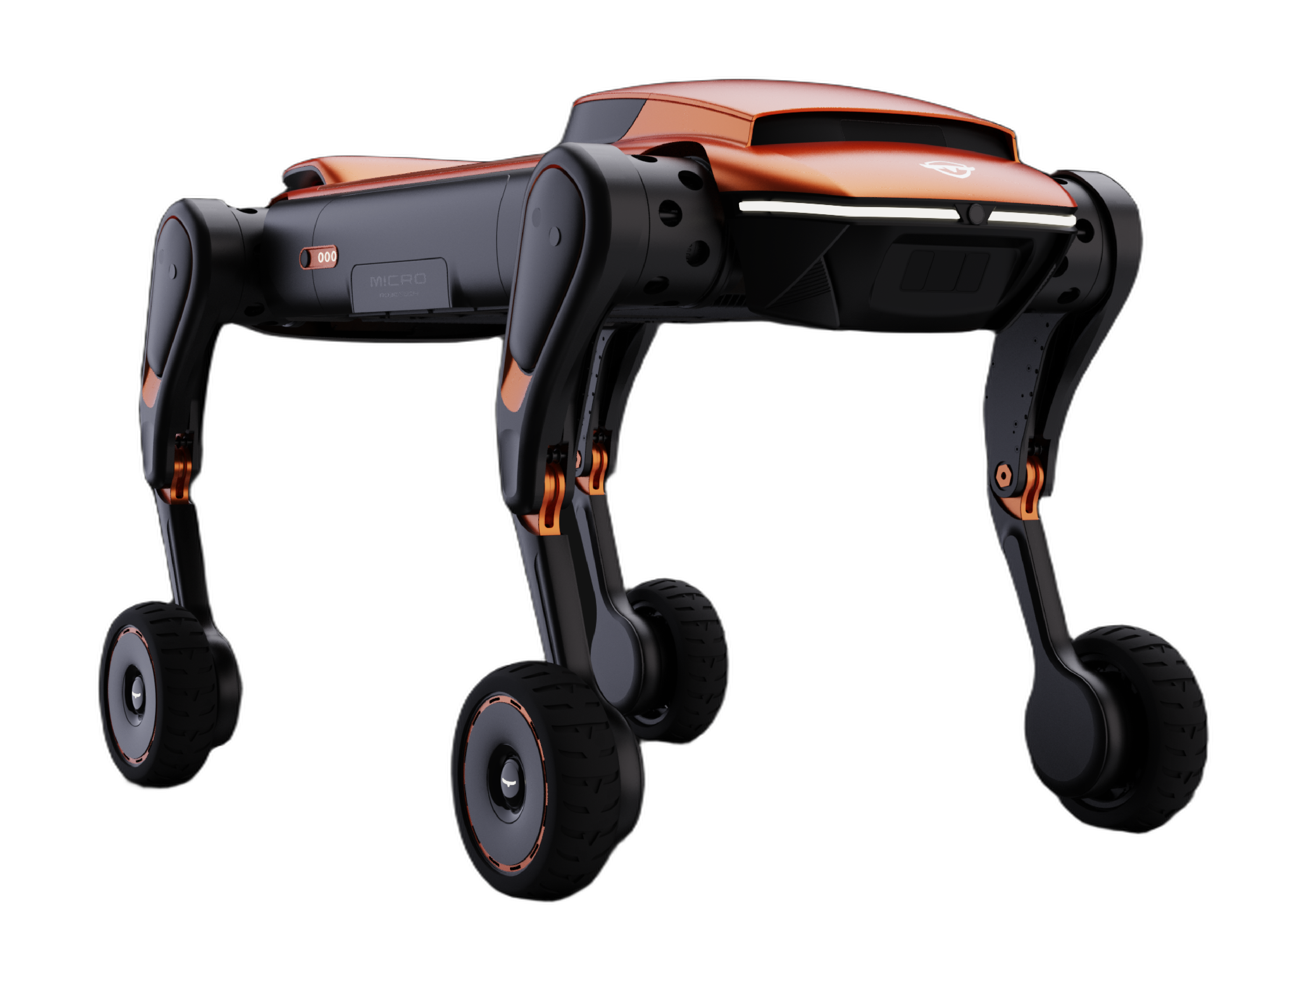
Hypertron-T01
A quadruped robot from China, first released 2026.
Sources retrieved: 24 August 2026 (A)
- Applications
- Indicative price
- Not stated
- Intended use, per the manufacturer
- The menu items on the homepage and product page.Mapping of the eight menu items to the seven allowed values: electric power/energy, construction/utility tunnels, mining/rail and water supply are all industrial infrastructure sectors -> industrial. fire/emergency response -> defense and emergency response. industrial-park/factory-area patrol (the page itself says whole-area surveillance) and police/security -> security and surveillance. petrochemical -> industrial. None of the eight map to logistics, inspection, research and development, or consumer and education.Source and note: Intended use, per the manufacturerA astralldynamics.com/project-Hypertron-T01.html · Retrieved 24 August 2026
- Person
175 cm68.9 in - 111 cm43.7 inHeight
74.5 cm29.3 in
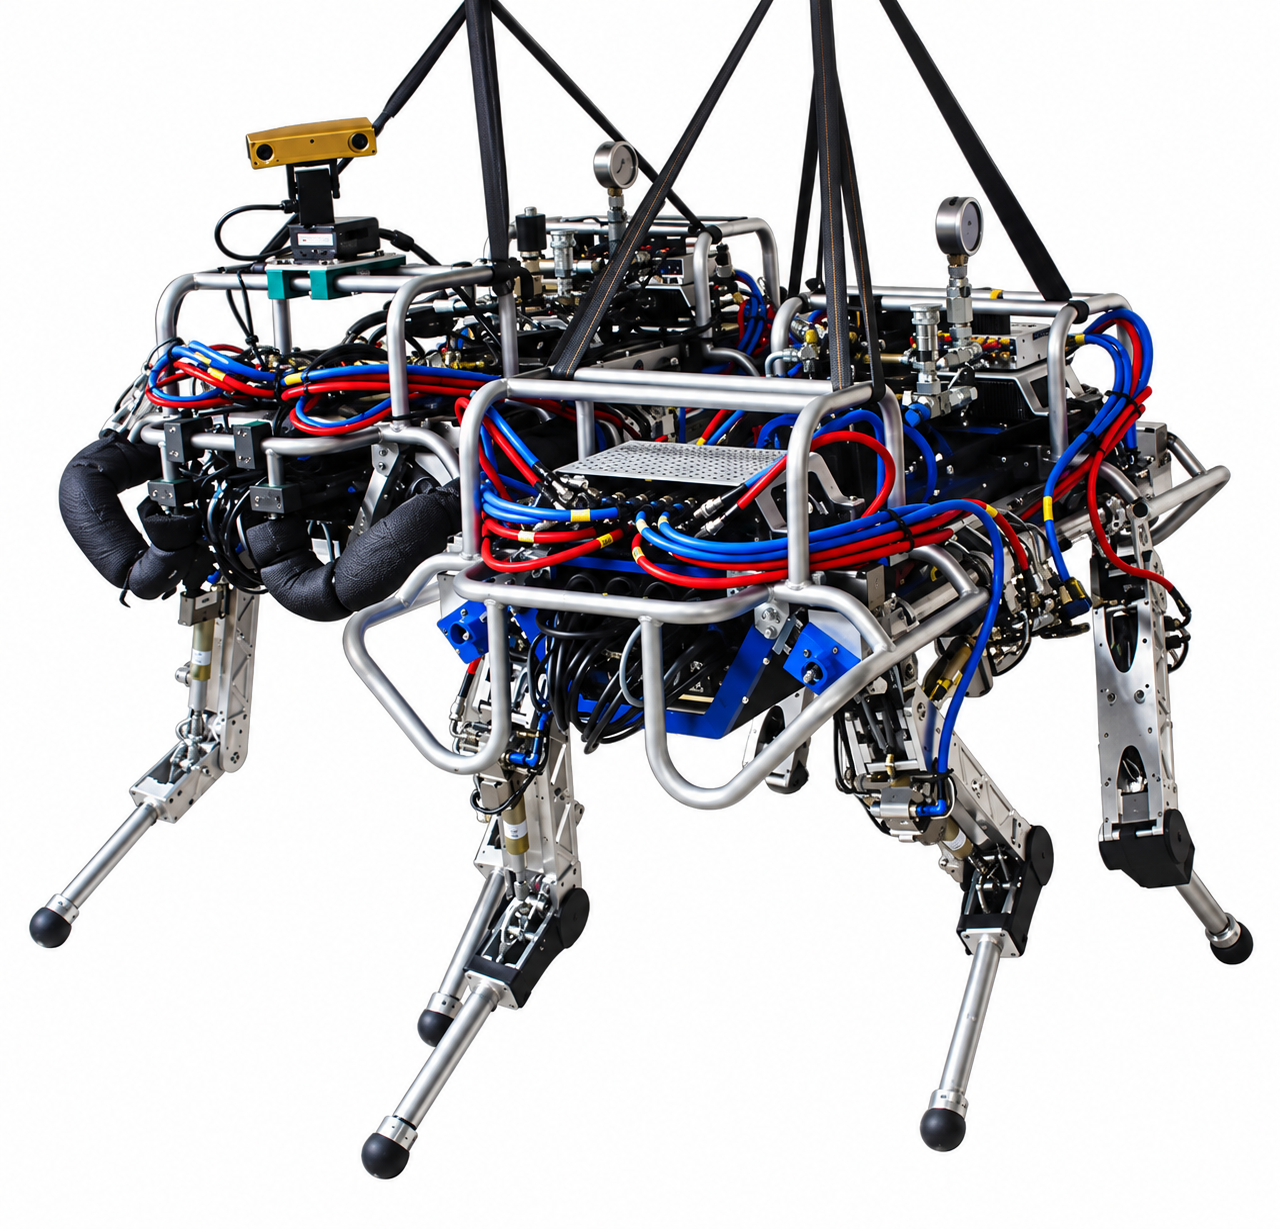
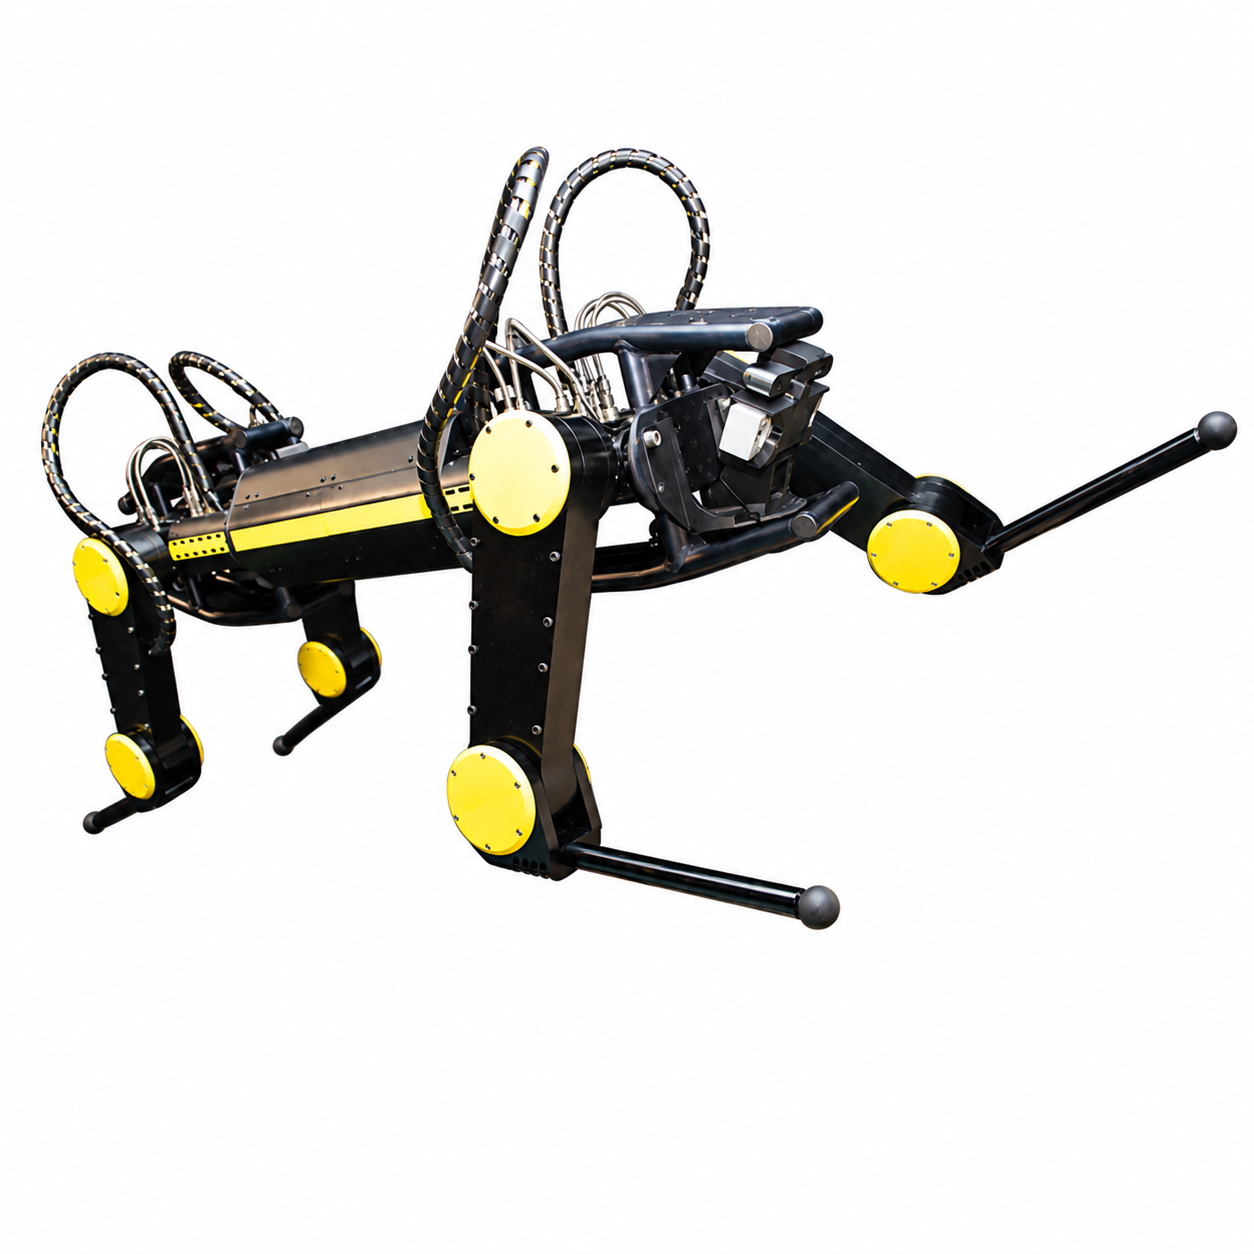
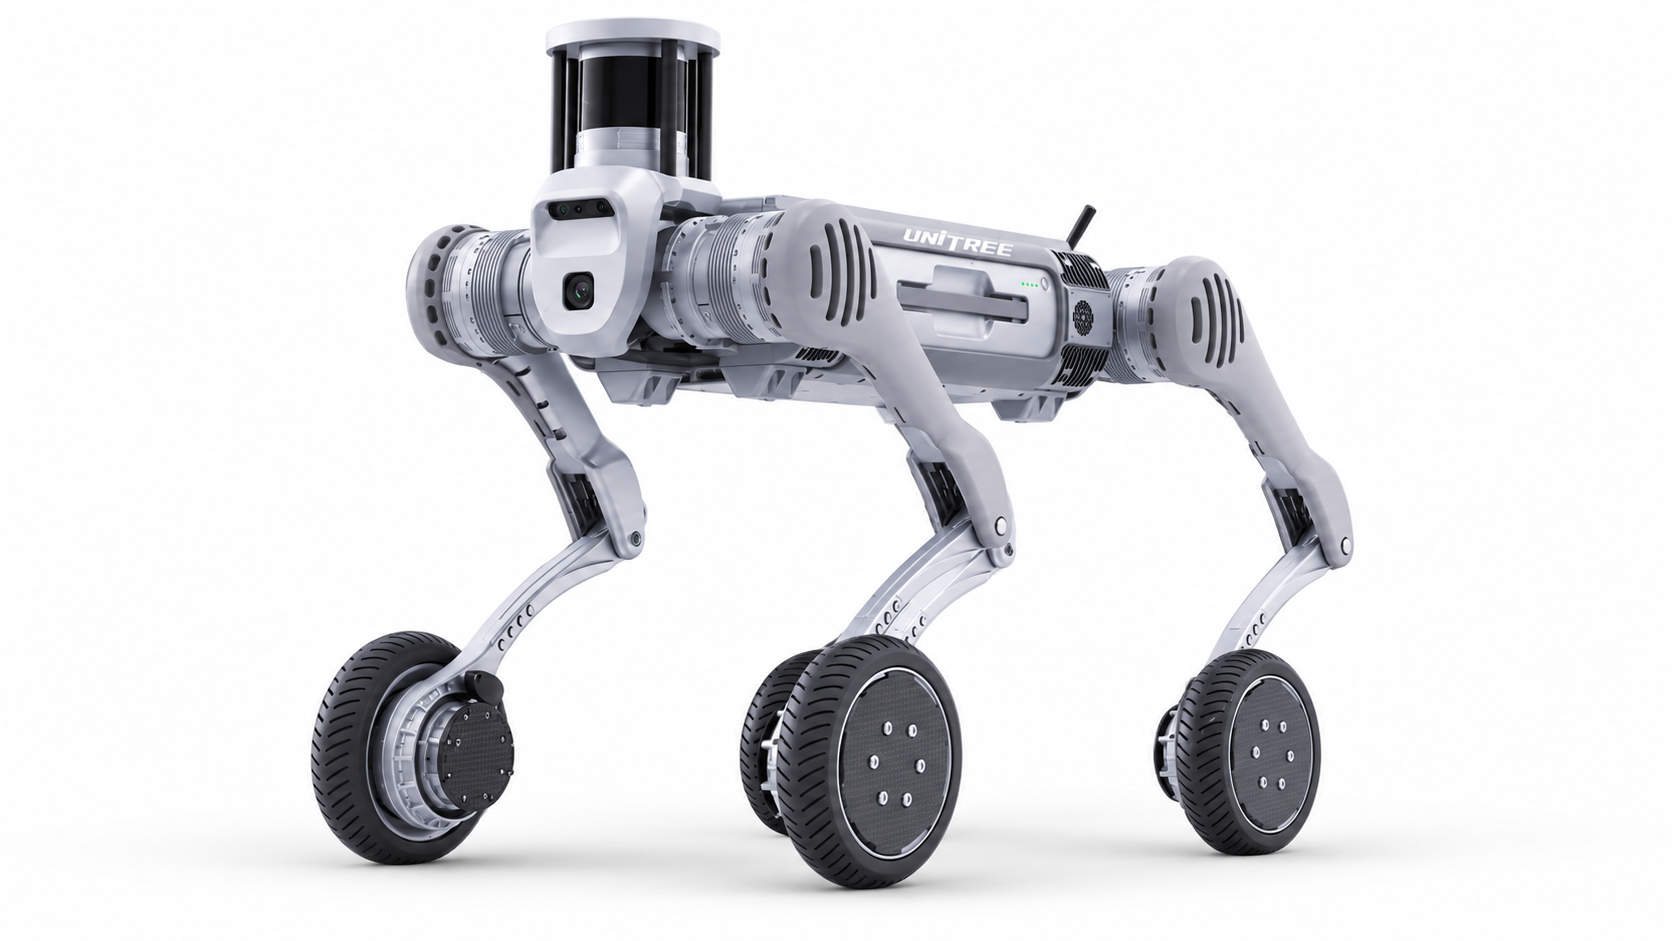
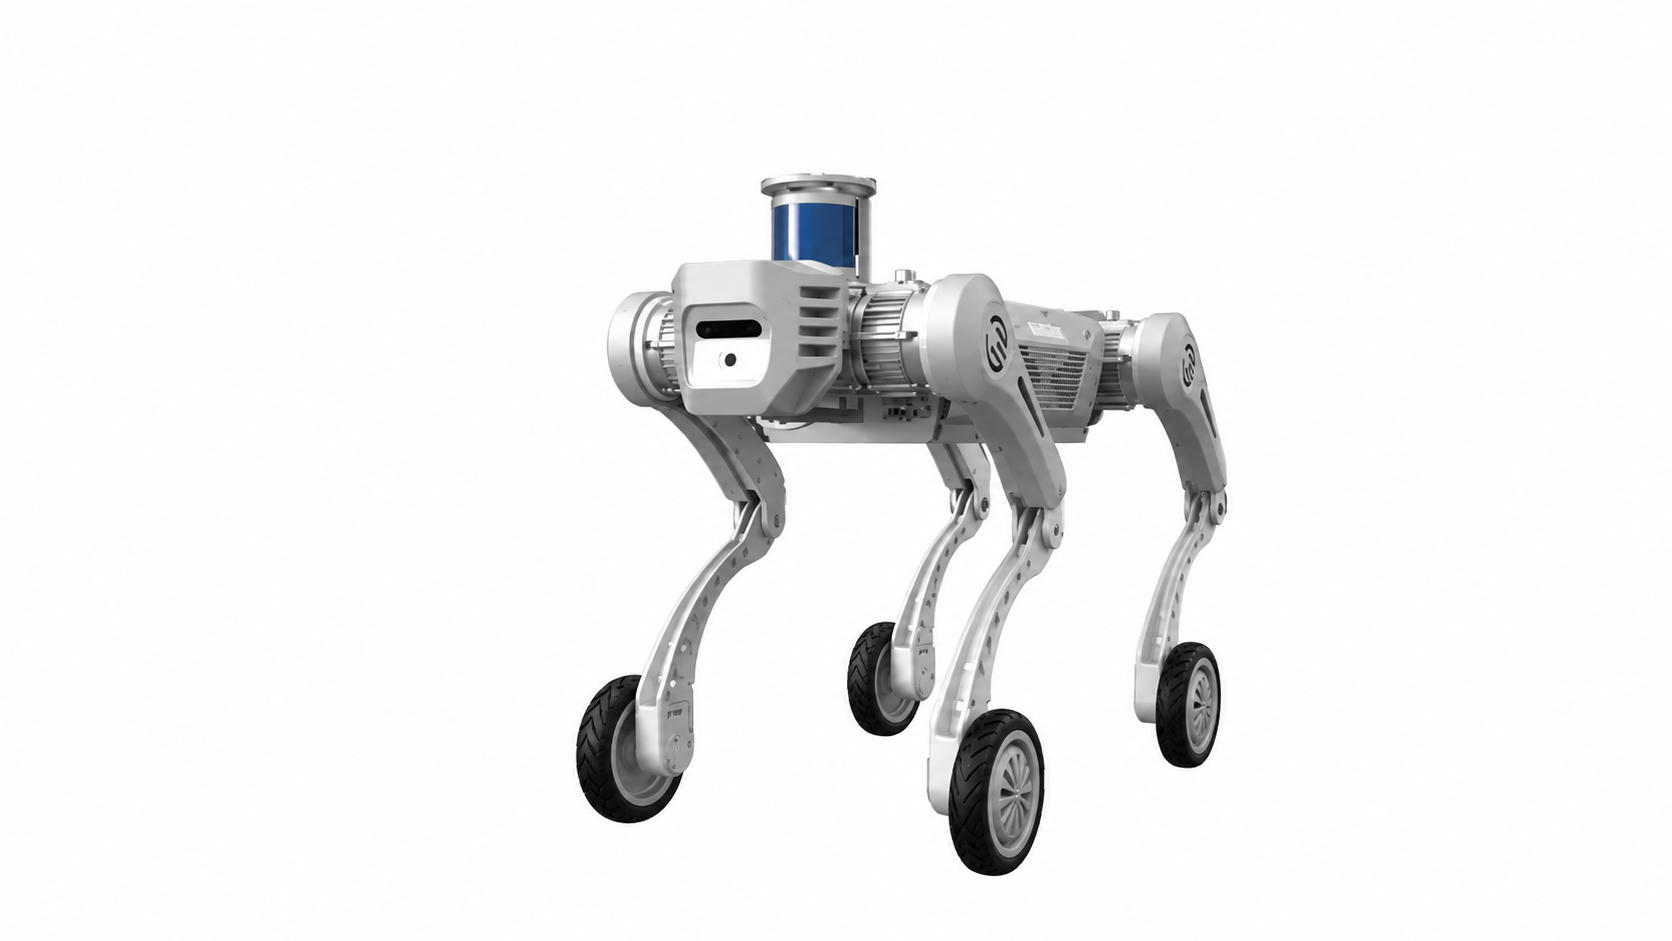
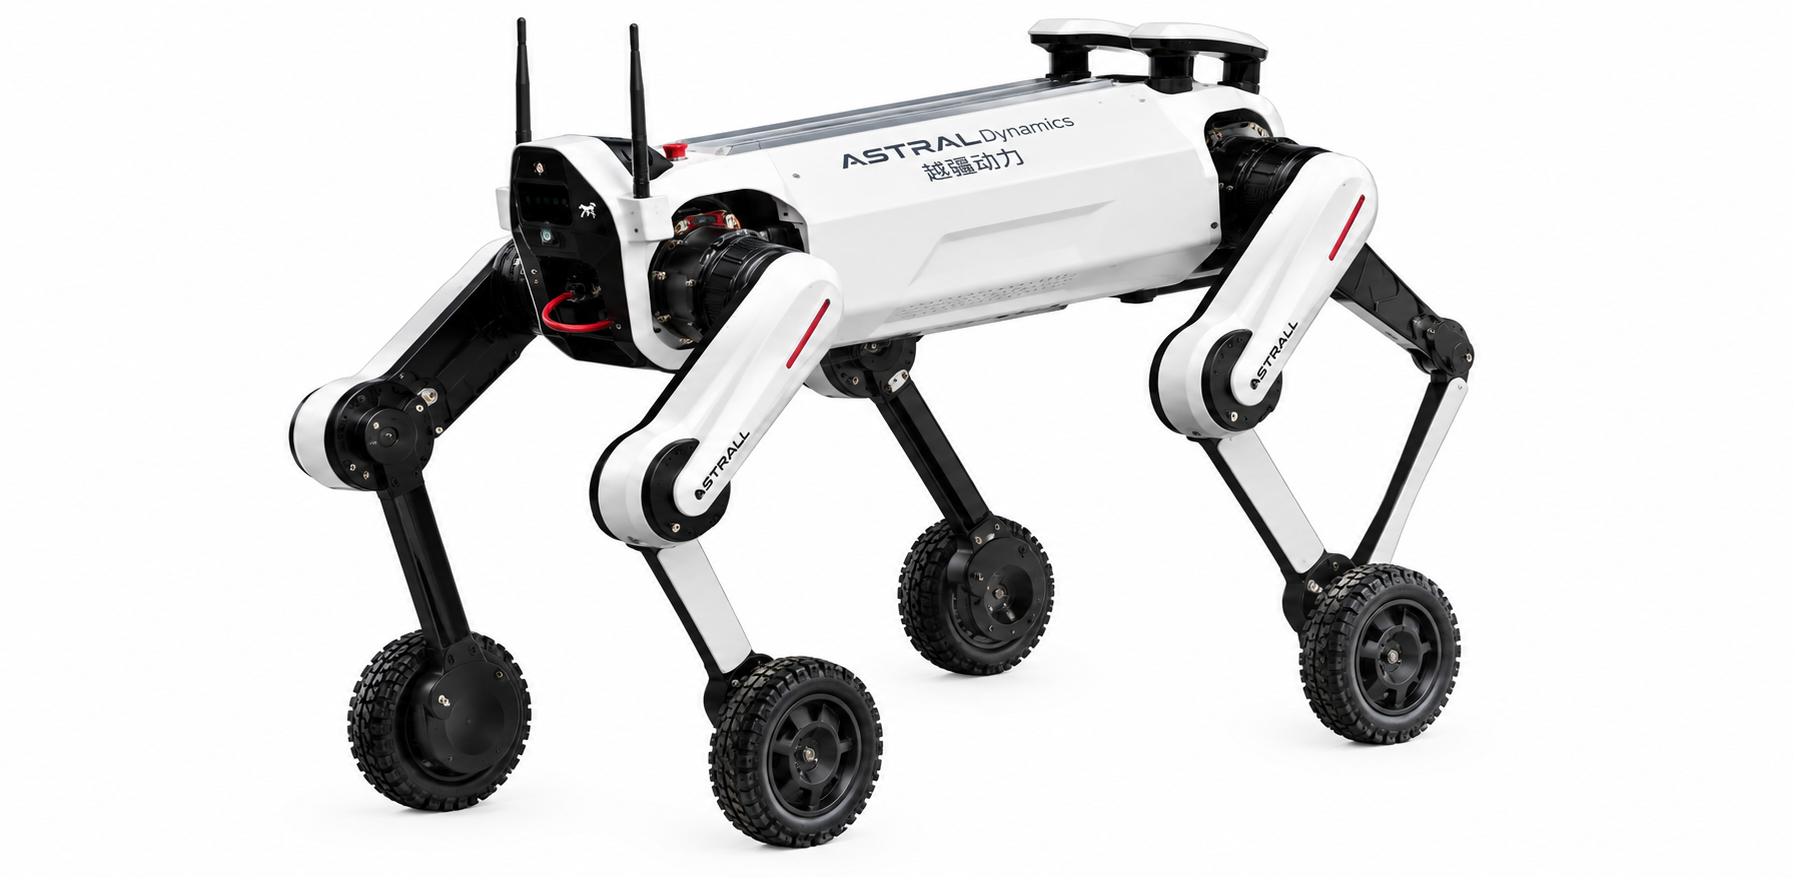
Manufacturer's own photo.
Drawn at one scale next to a 175 cm person, from the figures the maker states: height 74.5 cm and length 111 cm.Drawn at one scale next to a 68.9 in person, from the figures the maker states, converted to inches: height 29.3 in and length 43.7 in.
Specifications
20/33 specifications disclosed 13 not stated
13 fields hidden
Not statedThe manufacturer states nothing about this field.YesStated: the robot has this.NoStated: the robot does not have this.A marker with an asterisk (*) also carries a caveat.
Select a source marker for source details and notes.
Physical13/14 disclosed
Power2/5 disclosed
Sensing and autonomy3/6 disclosed
Payload and expansion2/3 disclosed
RS485 x2 CAN x2 Ethernet x2Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot.
Height
74.5cm29.3inOur conversion from 745 mm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
89 quadrupeds state a height
9 state a higher figure, 77 a lower one.
Weight
82kg181lbOur conversion from 82 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
124 quadrupeds state a weight
10 state a higher figure, 111 a lower one. Log scale: each step along the axis multiplies the value.
Runtime
240–480minNote: load condition not stated
104 quadrupeds state a runtime
Hypertron-T01 states a range, not one figure, so it is shown as a band and not ranked against the others.
Max speed
25.2km/h15.7mphOur conversion from 7 m/s. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
113 quadrupeds state a top speed
4 state a higher figure, 99 a lower one.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aastralldynamics.com/project-Hypertron-T01.htmlMain source. Retrieved 24 August 2026