Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 55kg121lbOur conversion from 55 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, walking not stated
- Runtime A approximately 120minWarning: load condition not stated
- Max speed A 7.2km/h4.47mphOur conversion from 7.2 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 1,100mmB43.3inB
- A dashed letter marks a secondary source – a datasheet, manual or developer documentation from the manufacturer, or a press report used only where the manufacturer gives no figure.
- Payload, walking
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Weight
Note Weight in the company introduction, given together with the height.
Runtime
Caveat Continuous working endurance of about 2 hours in the specification table; no load condition is given.
Max speed
Note Navigation speed: the brochure says the robot supports high-speed navigation at 2.0 m/s, together with stable long-range running of 6 km and centimetre-level positioning.
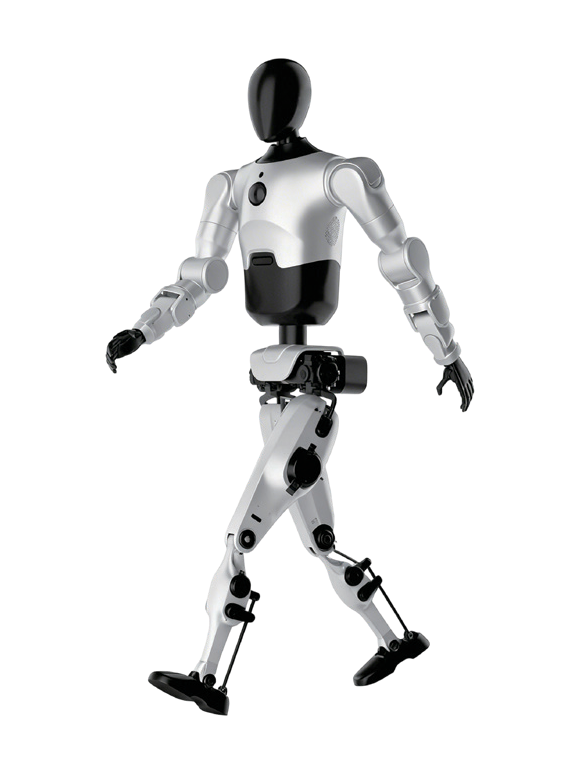
Manufacturer's own photo.
Intended use, per the manufacturer
Source: worldrobotconference.com · Retrieved
This category is not our assessment.
Full specifications
9 of 33 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 55kg121lbOur conversion from 55 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Weight in the company introduction, given together with the height. A |
| Length | not stated | |
| Width | not stated | |
| Height | 175cm68.9inOur conversion from 175 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Height in the company introduction; the specification table repeats 175 cm. A |
| Degrees of freedom | at most 43DoF | Note The introduction says up to 43 degrees of freedom across the body. The specification table lists 43 in total, 7 per arm (shoulder 3, elbow 1, wrist 3) and 6 per leg (hip 3, knee 1, ankle 2); the remaining joints are not broken down (translated from the Chinese). A |
| Payload, walking | not stated | |
| Payload, standing | not stated | |
| Max speed | 7.2km/h4.47mphOur conversion from 7.2 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Navigation speed: the brochure says the robot supports high-speed navigation at 2.0 m/s, together with stable long-range running of 6 km and centimetre-level positioning. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| Stair step, continuous | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | approximately 120minWarning: load condition not stated | Caveat Continuous working endurance of about 2 hours in the specification table; no load condition is given. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | LiDAR. | Note The sensor configuration is listed as LiDAR plus RGBD. A |
| Cameras | RGBD camera. | Note The sensor configuration is listed as LiDAR plus RGBD. A |
| Onboard compute | AGX Orin / NX Orin. | Note The high-compute module is listed as AGX Orin or NX Orin. A |
| ROS 2 | not stated | |
| SDK languages | Python C++ | Note The brochure's education section says the open development interface supports ROS, Python and C++ (translated from the Chinese). A |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer's brochure is in Chinese only.
- The brochure gives the company name as Hubei Qiling Robotics Co., Ltd. (translated from the Chinese).
- The company says it draws on the research and development strength of Huazhong University of Science and Technology (translated from the Chinese).
- The company says it has developed the Shennong humanoid series and the Chitu quadruped series (translated from the Chinese).
- The brochure calls Shennong a fully in-house developed, industrial-grade general-purpose humanoid robot (translated from the Chinese).
- The brochure lists science and education, guiding and industrial logistics as the main application fields (translated from the Chinese).
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Shennonghttps://www.worldrobotconference.com/profile/robot/download/2026/07/30/20260730123237000308_20260730123237A012.pdf
Sources
-
A
Secondary: www.
worldrobotco · Retrievednference. com/ profile/ robot/ download/ 2026/ 07/ 30/ 202607301232 37000308_ 20260730123237A012. pdf
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.