Key figures as stated by the manufacturer
2 of 6 stated · 4 gaps- Weight not stated
- Payload, moving not stated
- Runtime A 480minWarning: load condition not stated
- Max speed A 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 1,100mmB43.3inB
- A dashed letter marks a secondary source – a datasheet, manual or developer documentation from the manufacturer, or a press report used only where the manufacturer gives no figure.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (3)
Payload, moving
Caveat The table gives a maximum of 30 kg per arm and 60 kg for both arms. That is an arm-specific figure, not a figure for what the whole robot can carry.
Runtime
Caveat Working time in the specification table; no load condition is given.
Max speed
Note Maximum travel speed.
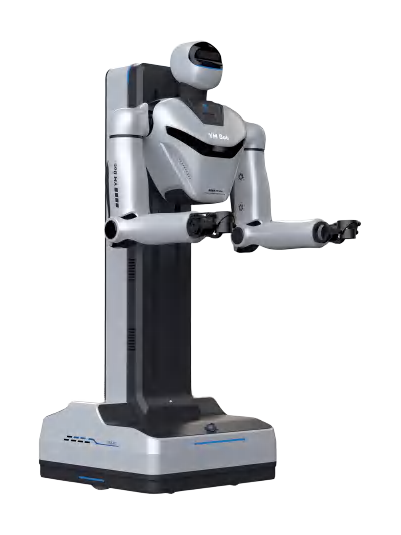
Manufacturer's own photo.
Intended use, per the manufacturer
Source: worldrobotconference.com · Retrieved
This category is not our assessment.
Full specifications
10 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | not stated | |
| Length | 80cm31.5inOur conversion from 80 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat The brochure labels the three values height, base length and base width. A |
| Width | 68cm26.8inOur conversion from 68 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat The brochure labels the three values height, base length and base width. A |
| Height | 182cm71.7inOur conversion from 182 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Caveat The brochure labels the three values height, base length and base width. A |
| Degrees of freedom | 27DoF | Caveat Total, excluding end effectors. A |
| Payload, moving | not stated | Caveat The table gives a maximum of 30 kg per arm and 60 kg for both arms. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Caveat The table gives a maximum of 30 kg per arm and 60 kg for both arms. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | 5.4km/h3.36mphOur conversion from 5.4 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum travel speed. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Caveat The table gives two batteries of 48 V and 30 Ah each. A |
| Runtime | 480minWarning: load condition not stated | Caveat Working time in the specification table; no load condition is given. A |
| Hot-swap battery | not stated | Caveat The table says quick battery swapping is supported. A |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | LiDAR, listed among the perception sensors. | Note Perception row of the specification table. A |
| Cameras | Binocular camera, RGBD camera and fisheye camera. | Note Perception row of the specification table, which also lists a six-axis force sensor. A |
| Onboard compute | not stated | |
| ROS 2 | yes | Note Listed under the expansion interfaces, together with low-level joint and sensor interfaces and high-level motion interfaces. A |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | RJ45 Gigabit Ethernet ×1 USB 3.0 ×2 | Note External interfaces in the specification table. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Aibang Robotics reports that the D4 was shown publicly for the first time at WAIC 2026, which opened on 17 July 2026 (translated from the Chinese).
- The brochure describes the D4 as an industrial heavy-load embodied intelligent robot built around a dual-arm load of 60 kg (translated from the Chinese).
- The chassis is a four-steer four-drive omnidirectional mobile chassis with a vertical lifting platform (translated from the Chinese).
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for YMBot D4https://www.worldrobotconference.com/profile/robot/download/2026/07/23/20260723170520000751_20260723170520A912.pdf
Sources
-
A
Secondary: www.
worldrobotco · Retrievednference. com/ profile/ robot/ download/ 2026/ 07/ 23/ 202607231705 20000751_ 20260723170520A912. pdf
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.