Prima 1
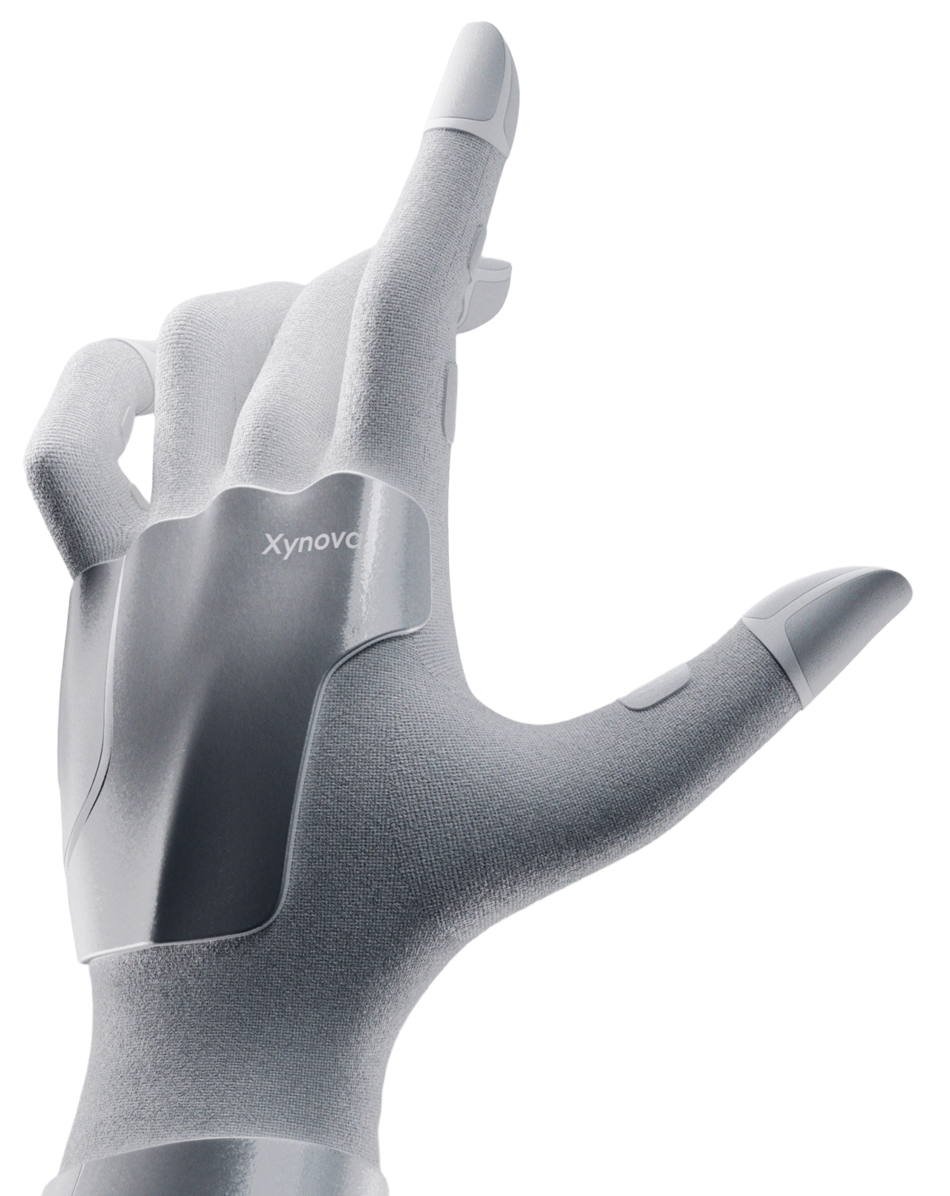
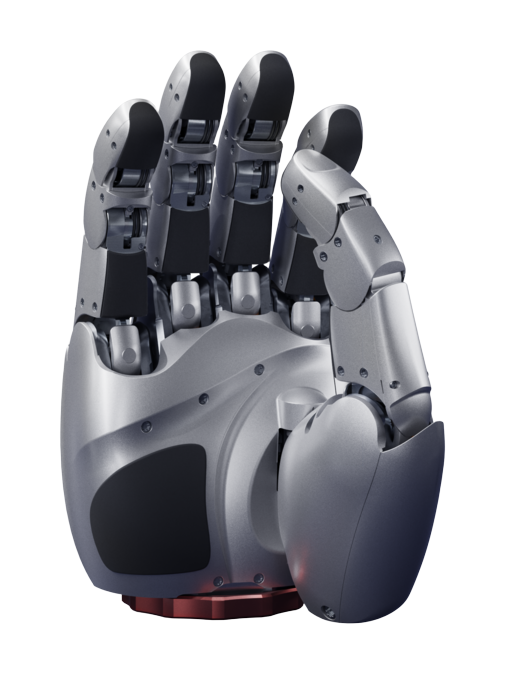
A robot hand from China, announced 2026.
Sources retrieved: 12 November 2026 (A, B)
- Applications
- Intended use, per the manufacturer
- uses direct drive at every joint and is designed for high-precision force-controlled manipulation and advanced embodied intelligence researchSource and note: Intended use, per the manufacturerA docs.xynova.com.cn · Retrieved 12 November 2026
- Indicative price
- Not stated
Specifications
11 of 18 stated 7 not stated
7 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand4/4 disclosed
Performance3/4 disclosed
Physical2/2 disclosed
Sensing and autonomy2/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Fingertip force
20N
38 robot hands state a fingertip force
9 state a higher figure, 14 a lower one. 2 more state exactly the same figure. 12 state only a bound (≥ or ≤) and are not ranked. DG-5F-M lies beyond the end of the axis and is drawn at its edge as an open bar.
Lifting capacity
at most 20kgat most 44.1lbOur conversion from 20 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
48 robot hands state a lifting capacity
Prima 1 states an upper limit, not one figure, so it is shown open-ended and not ranked against the others. 6 state only a bound (≥ or ≤) and are not ranked.
Weight
850g1.87lbOur conversion from 850 g. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
59 robot hands state a weight
22 state a higher figure, 32 a lower one. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
22DoF
66 robot hands state degrees of freedom
1 states a higher figure, 60 a lower one. 4 more state exactly the same figure.
Notes
Xynova's company page lists for August 2026: “Released Prima 1, a research-grade 22-DoF pure direct-drive dexterous hand, forming a dual-product strategy together with Flex 2.”
The documentation says the hand “uses direct drive at every joint and is designed for high-precision force-controlled manipulation and advanced embodied intelligence research”.
The documentation lists a hand size of 190 × 90.5 × 44 mm, a grip diameter range of 10 to 220 mm, a repeatability of 0.5 mm and a minimum backdrive force of 0.2 N.
Xynova's company page gives its address as “Floors 15-16, Building B2, Cloud Valley Center, No. 1009 Dengcai Street, Xihu District, Hangzhou, Zhejiang, China.”
Sources
One line per source, not per figure: a source has one retrieval date.
- Adocs.xynova.com.cnSecondary. Retrieved 12 November 2026
- Bxynova.com.cn/en/xynova-prima-1Main source. Retrieved 12 November 2026