Flex 2
A robot hand from China, announced 2026.
Sources retrieved: 12 November 2026 (A, B)
- Applications
- Intended use, per the manufacturer
- precision tasks in research, industrial sorting, rehabilitation, and other applicationsSource and note: Intended use, per the manufacturerB docs.xynova.com.cn · Retrieved 12 November 2026
- Indicative price
- Not stated
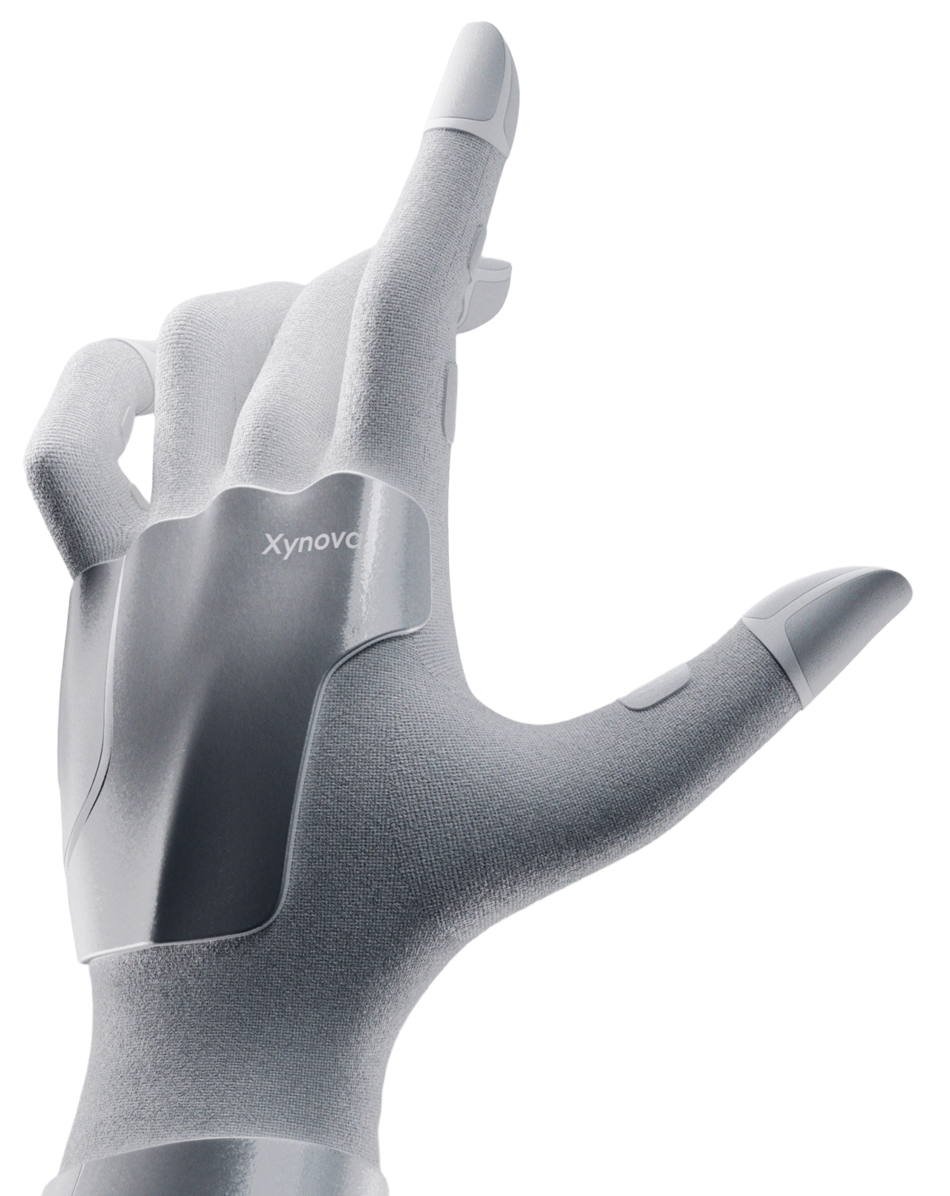
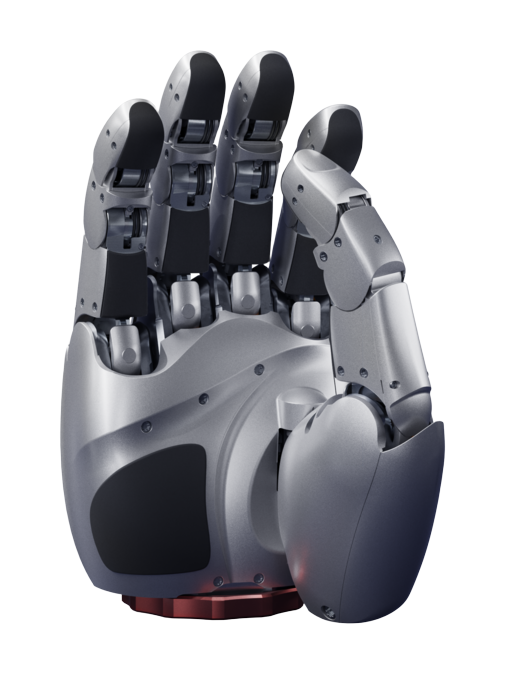
Product render from the manufacturer's own website (xynova.com.cn).
Specifications
9 of 18 stated 9 not stated
9 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand3/4 disclosed
Performance3/4 disclosed
Physical1/2 disclosed
Sensing and autonomy2/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Fingertip force
20N
38 robot hands state a fingertip force
9 state a higher figure, 14 a lower one. 2 more state exactly the same figure. 12 state only a bound (≥ or ≤) and are not ranked. DG-5F-M lies beyond the end of the axis and is drawn at its edge as an open bar.
Lifting capacity
20kg
48 robot hands state a lifting capacity
15 state a higher figure, 21 a lower one. 4 more state exactly the same figure. 7 state only a bound (≥ or ≤) and are not ranked.
Active degrees of freedom
19DoF
66 robot hands state degrees of freedom
18 state a higher figure, 47 a lower one.
Notes
Xynova's company timeline lists for June 2026: “Released Flex 2, the world’s first fully in-house developed, high-DoF hybrid-drive (tendon+direct) dexterous hand.”
The documentation says: “The Xynova Flex 2 is a general-purpose end-effector platform designed for dexterous manipulation by humanoid robots and embodied-intelligence research.”
Sources
One line per source, not per figure: a source has one retrieval date.
- Axynova.com.cn/en/xynova-flex-2Main source. Retrieved 12 November 2026
- Bdocs.xynova.com.cnSecondary. Retrieved 12 November 2026