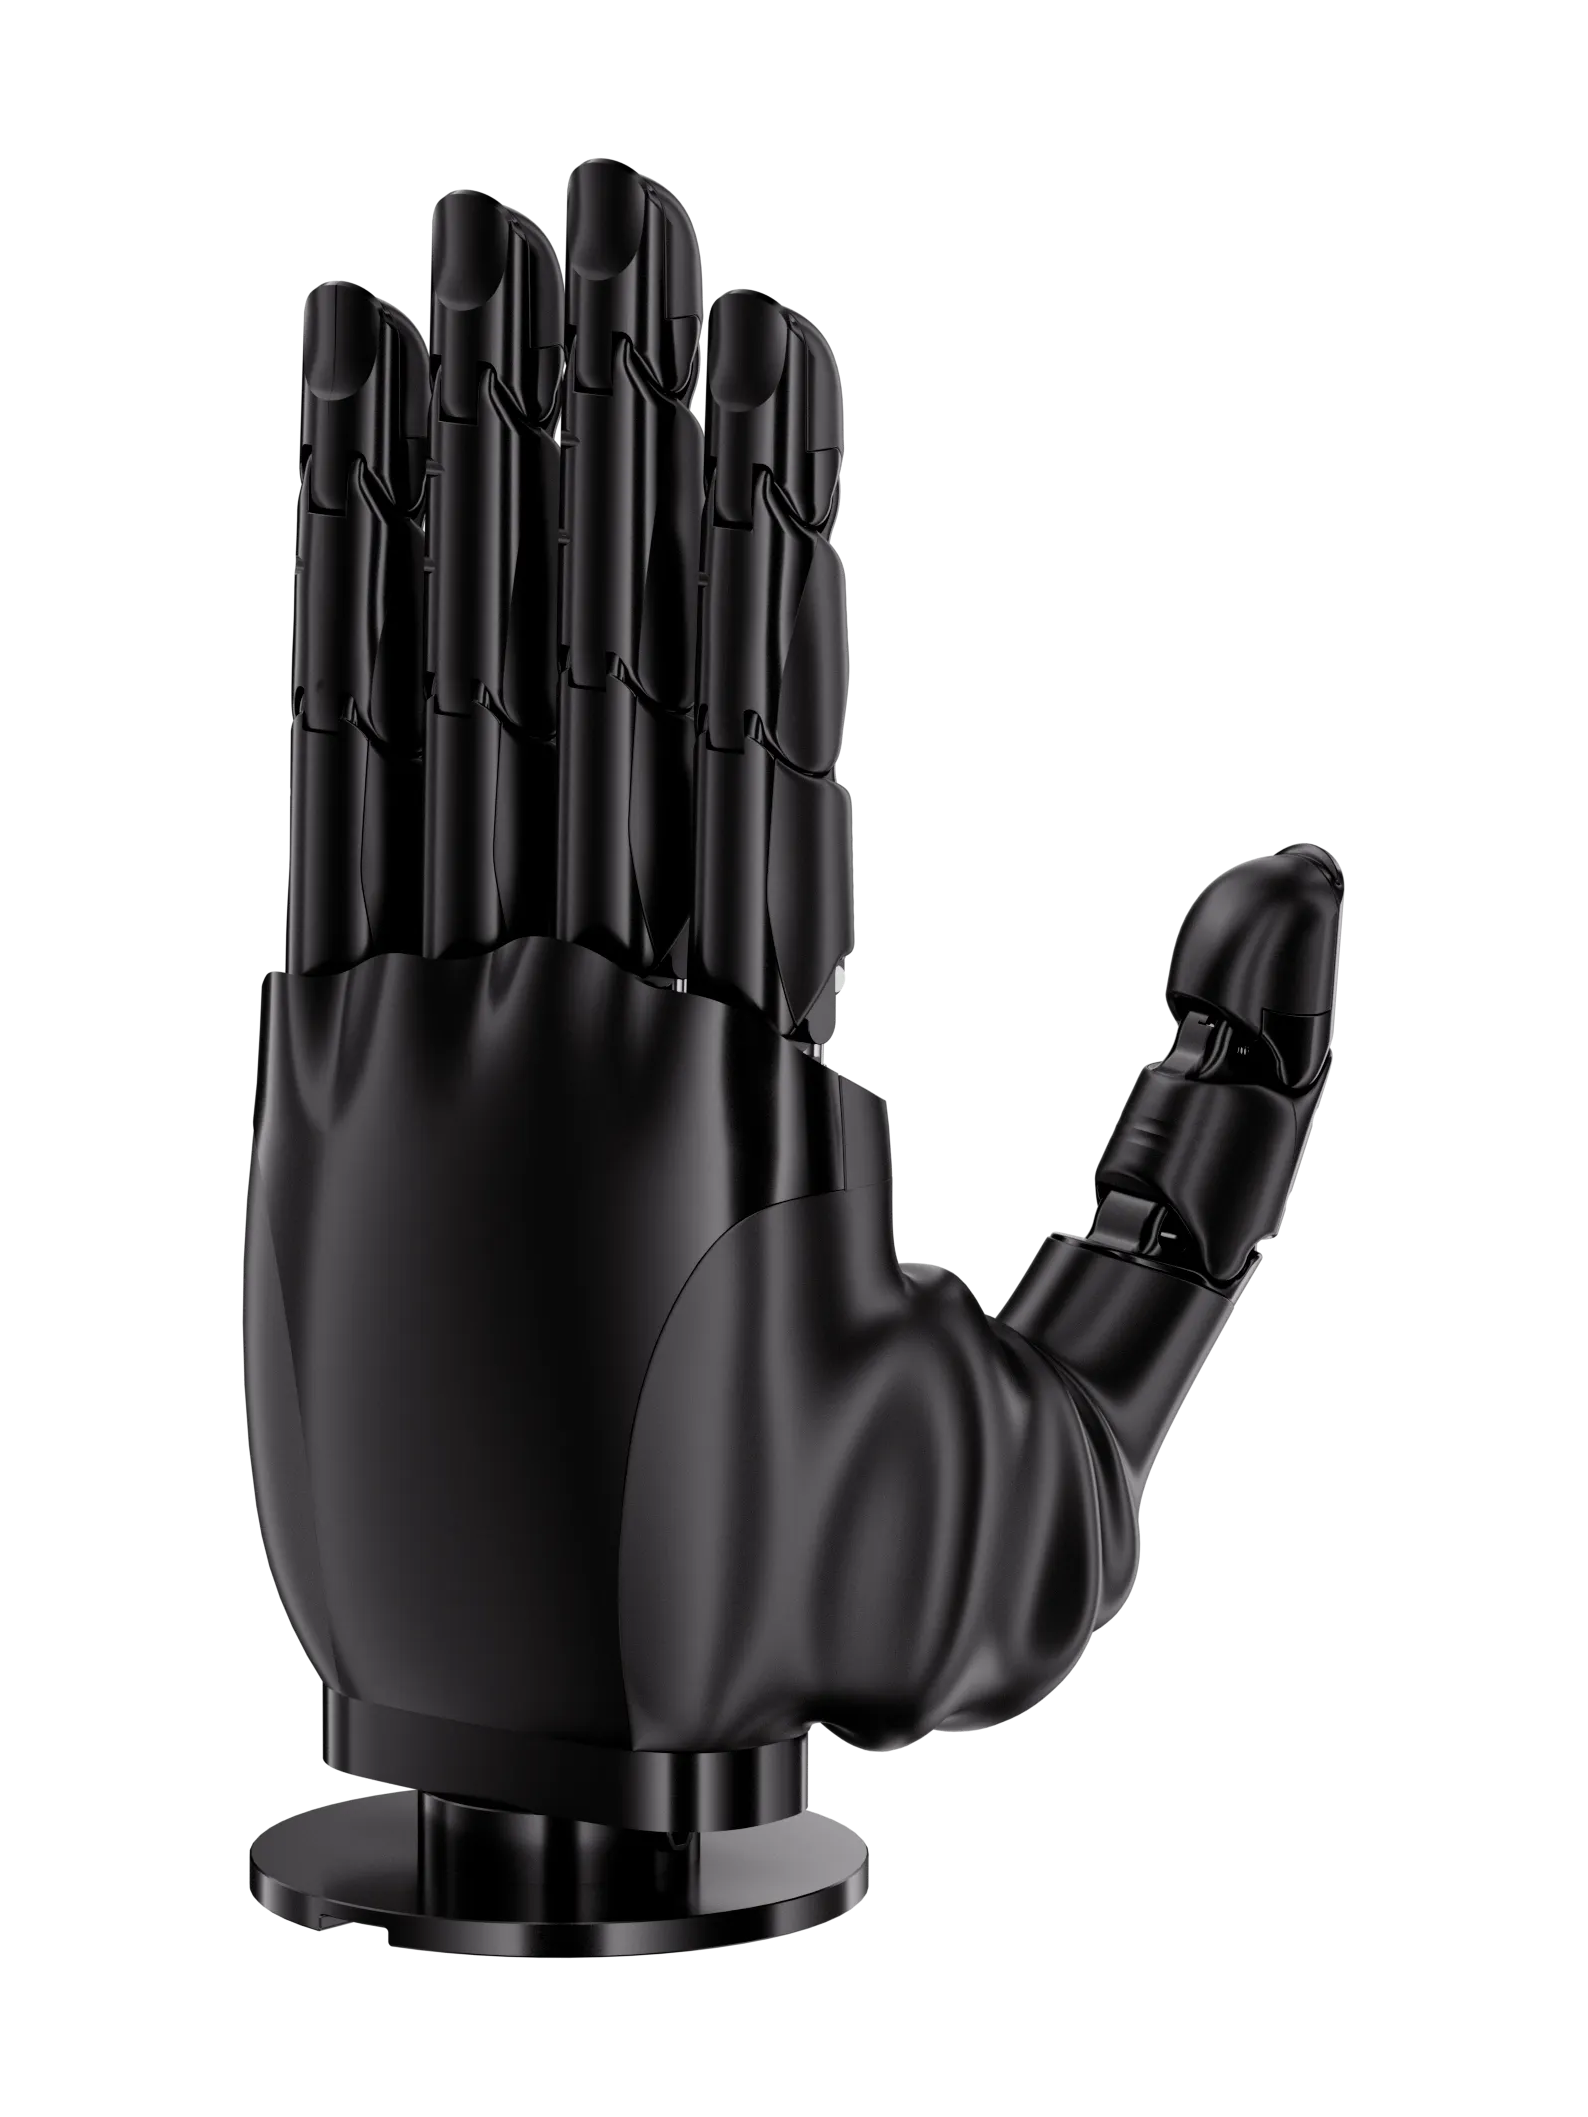
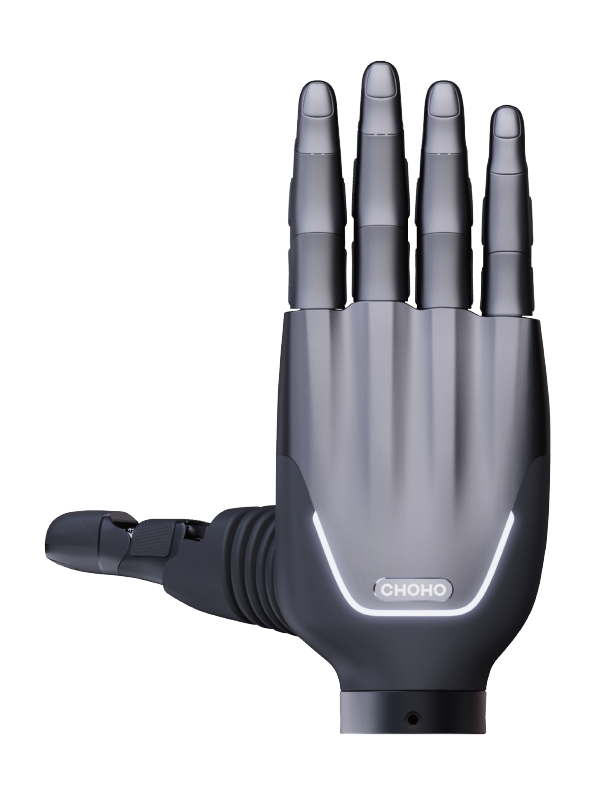
Allegro Hand V6 F
A robot hand from South Korea, first released 2026.
Sources retrieved: 4 November 2026 (A, B)
- Status
- In production
- Applications
- Intended use, per the manufacturer
- V6 F was developed for use across a wide range of robotic environments—from research and development to humanoid robotics and industrial automationSource and note: Intended use, per the manufacturerB allegrohand.com/sub/about/news.php?mode=view&bid=4&idx=648 · Retrieved 4 November 2026
- Indicative price
- Not stated
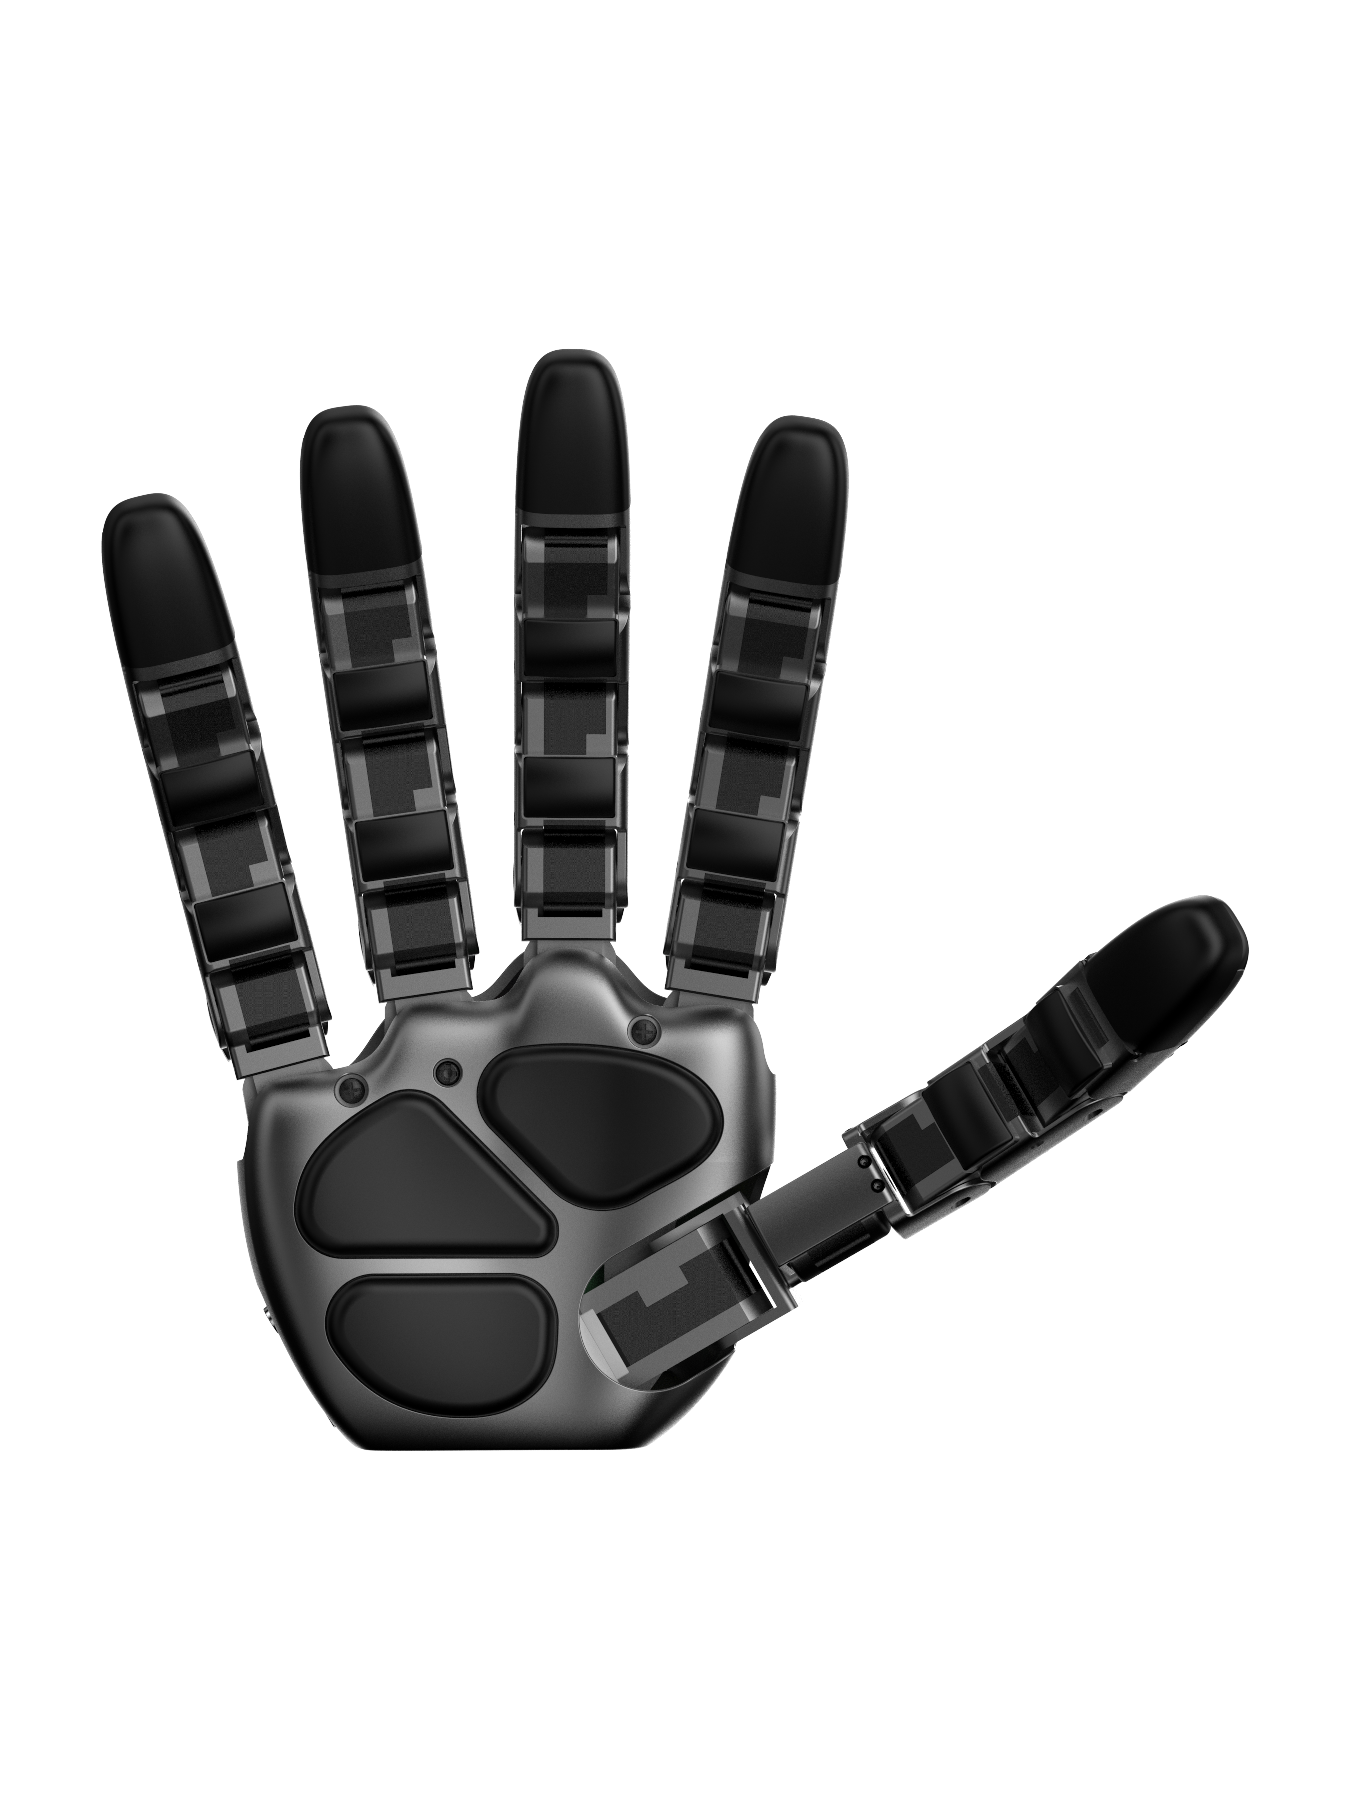
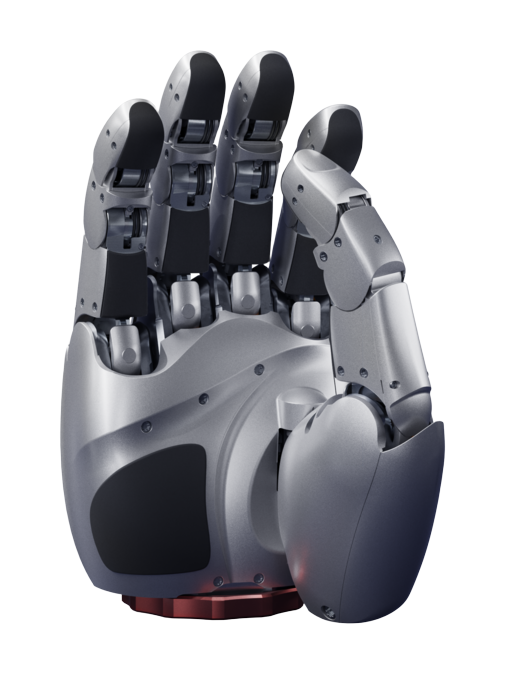
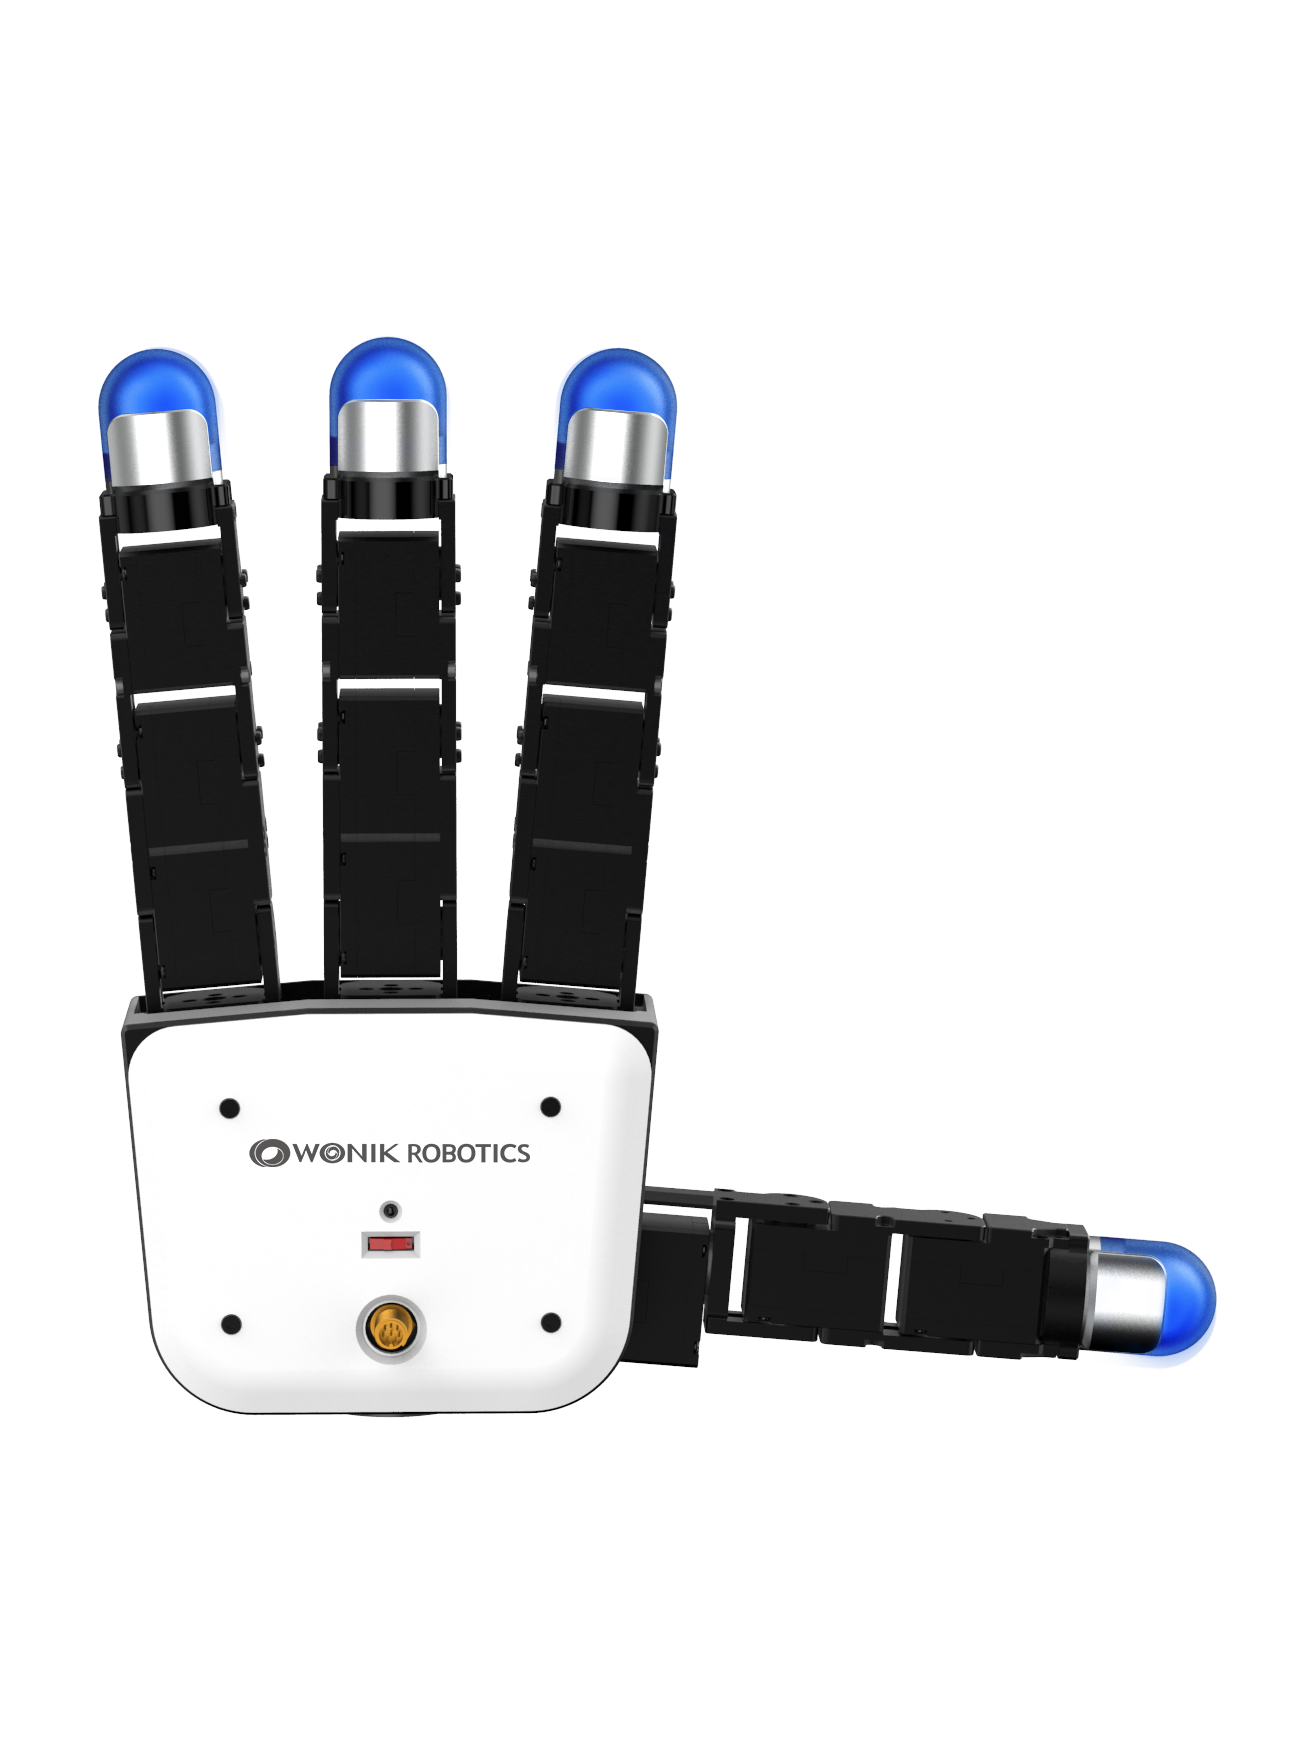
Product render from the manufacturer's own website (allegrohand.com).
Specifications
9 of 18 stated 9 not stated
9 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand3/4 disclosed
Performance2/4 disclosed
Physical2/2 disclosed
Sensing and autonomy2/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Lifting capacity
15kg33.1lbOur conversion from 15 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
48 robot hands state a lifting capacity
20 state a higher figure, 13 a lower one. 7 more state exactly the same figure. 7 state only a bound (≥ or ≤) and are not ranked.
Weight
1,150g2.54lbOur conversion from 1,150 g. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
59 robot hands state a weight
8 state a higher figure, 45 a lower one. 1 more states exactly the same figure. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
20DoF
66 robot hands state degrees of freedom
9 state a higher figure, 48 a lower one. 8 more state exactly the same figure.
Notes
Launch announcement dated 2026.09.07: “Wonik Robotics has launched the Allegro Hand V6 F (V6 F), a new 5-finger, 20-degree-of-freedom (DoF) articulated robotic hand.”
Control modes: “Supports multiple control modes, including current, position, and stiffness control.”
Gear ratio 288.35:1, stall torque 0.92 Nm, nominal torque 0.23 Nm and joint resolution 0.088 deg.
Pressure sensing range 260 to 1260 hPa with 1 kPa accuracy; atmospheric pressure is 1,013.25 hPa.
The Allegro Hand FAQ says: “If you would like to purchase the Allegro Hand, please contact us through the Contact Us page on our website.” “We, Wonik Robotics, offer a one-year hardware warranty from the date of purchase.”
Sources
One line per source, not per figure: a source has one retrieval date.
- Aallegrohand.com/sub/product/p.php?idx=25Main source. Retrieved 4 November 2026
- Ballegrohand.com/sub/about/news.php?mode=view&bid=4&idx=648Retrieved 4 November 2026
More robots
Same manufacturer
All robots from Wonik Robotics