Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 90kg198lbOur conversion from 90 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A 180minWarning: load condition not stated
- Max speed B 7.2km/h4.47mphOur conversion from 7.2 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- 1,100mmB43.3inB
- A dashed letter marks a secondary source – a datasheet, manual or developer documentation from the manufacturer, or a press report used only where the manufacturer gives no figure.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Weight
Note Technical specifications on the product page.
Payload, moving
Caveat The producer gives a payload of 4 kg per arm. That is an arm figure, not a figure for what the whole robot can carry.
Runtime
Caveat The product page gives a battery time of 3 hours and says the robot supports plug-in operation; no load is given.
Max speed
Note Specification sheet, labelled as the top speed.
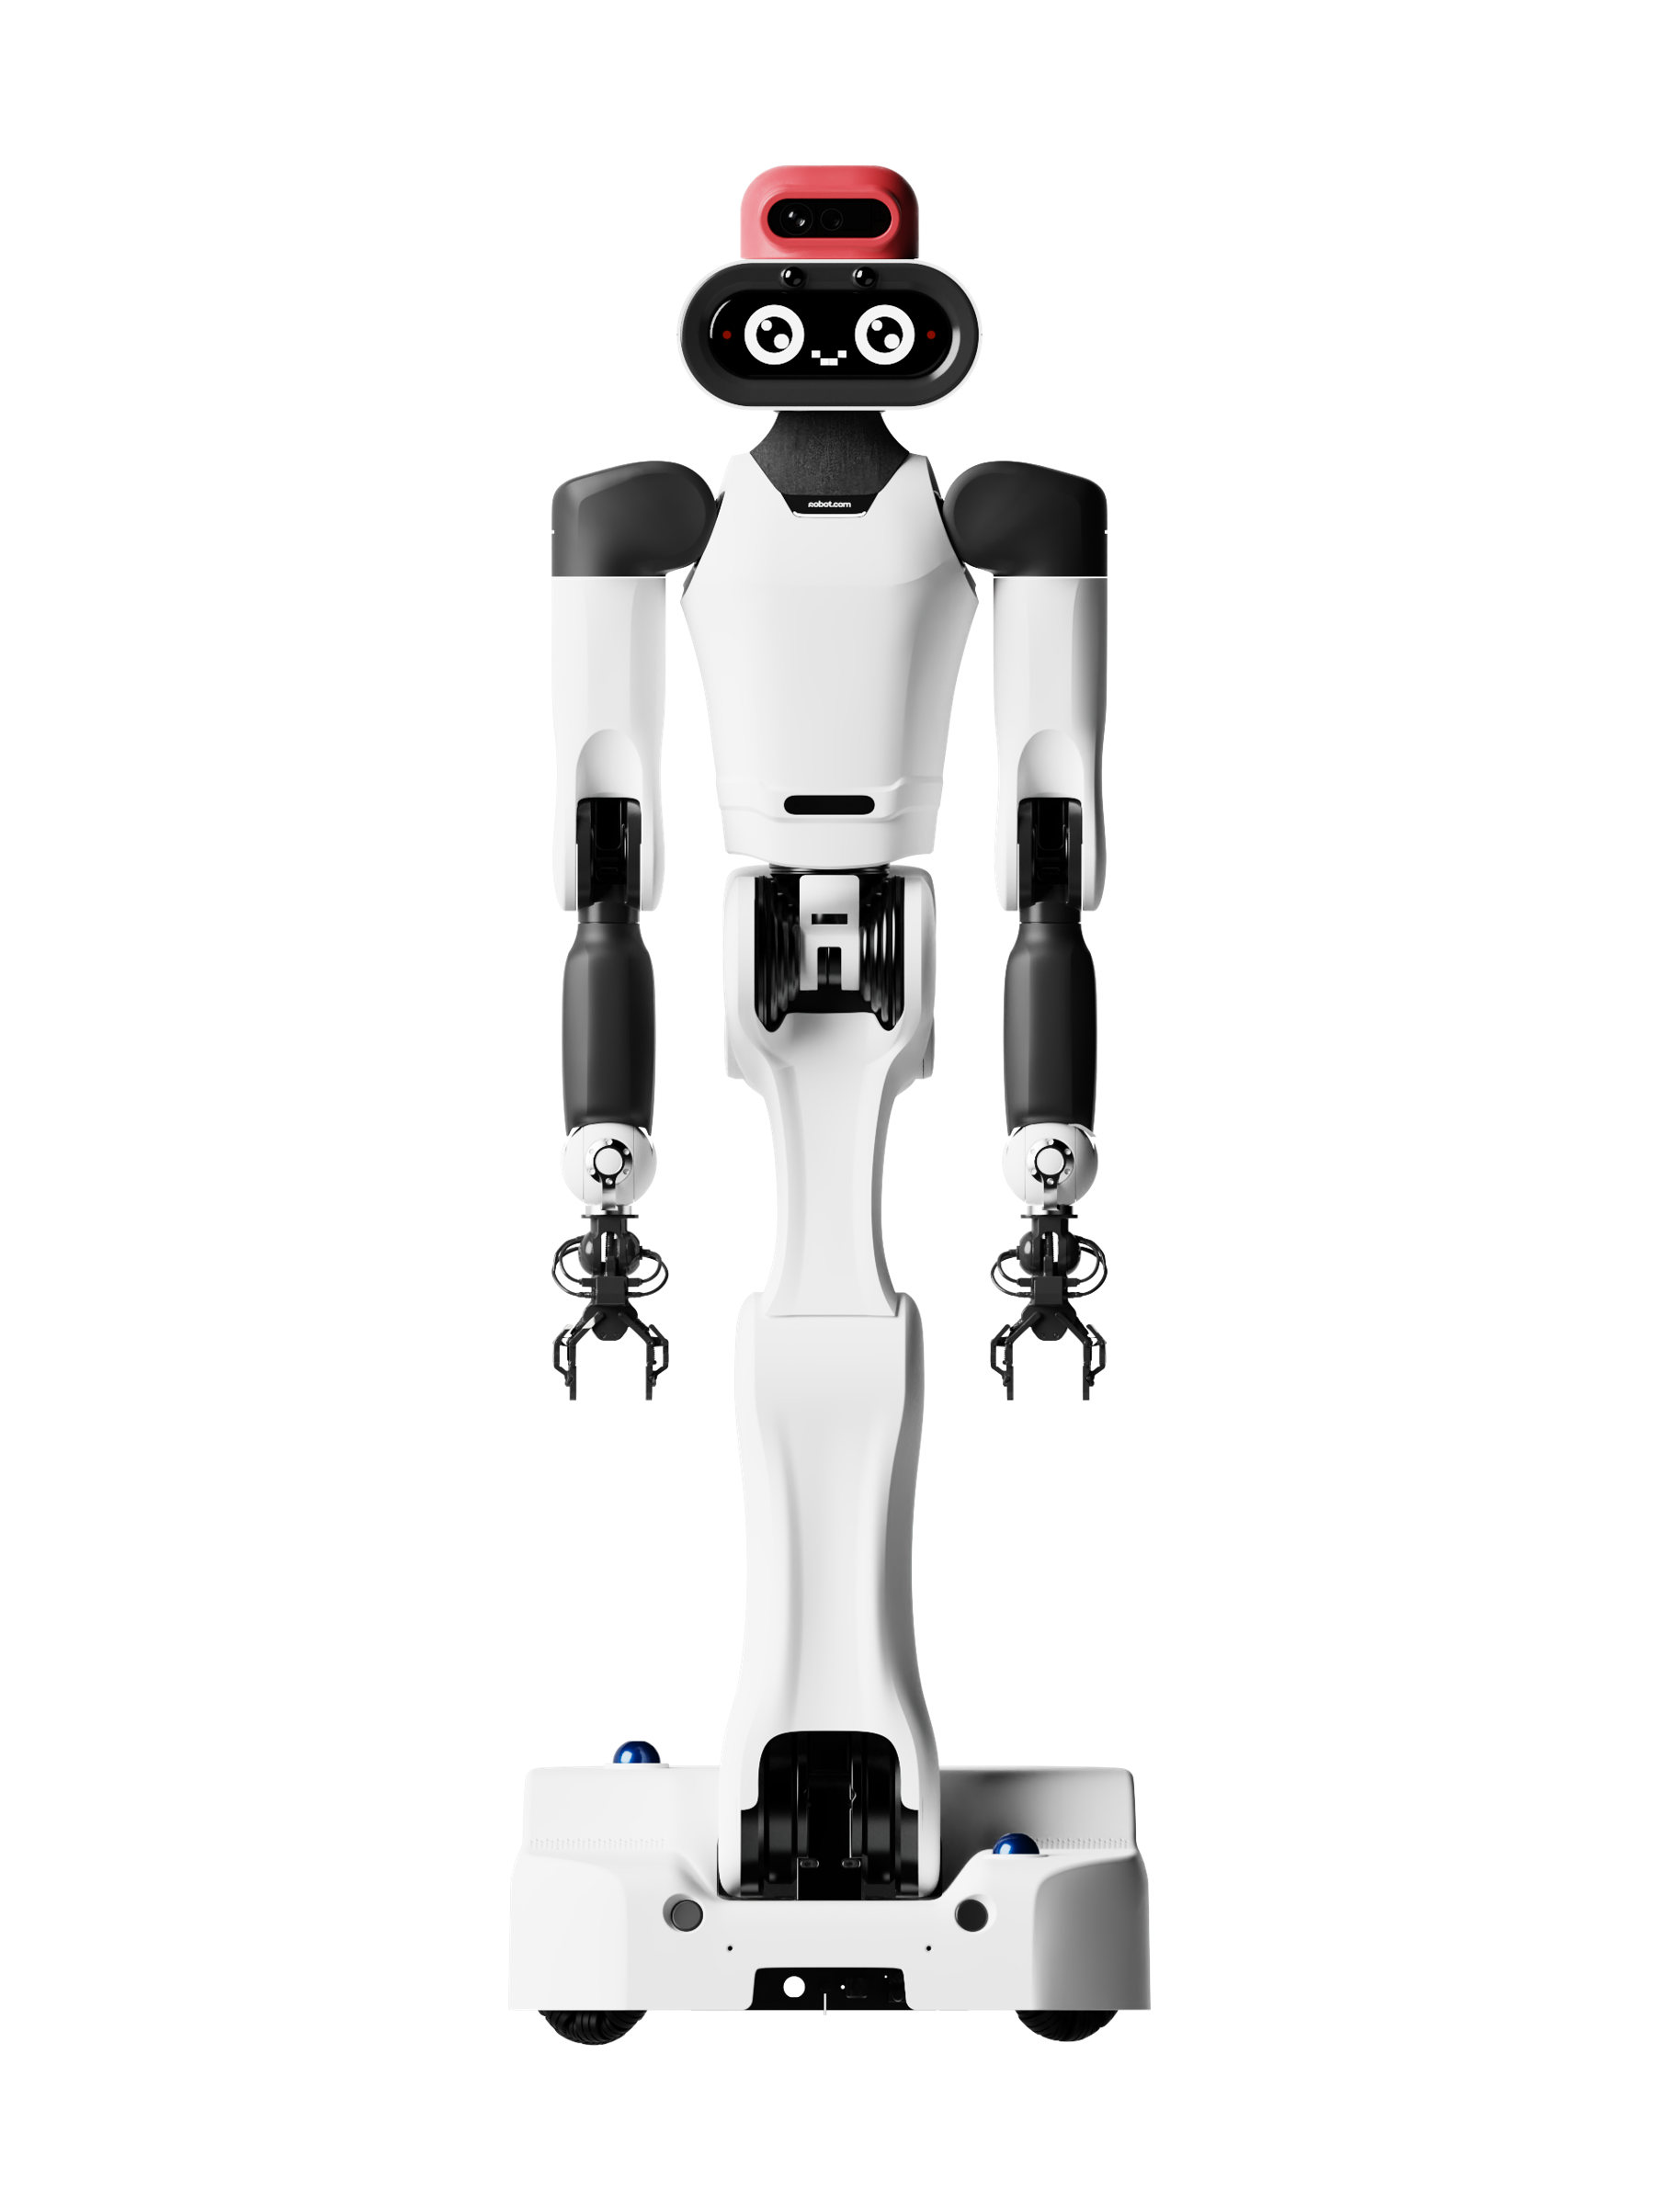
Manufacturer's own photo.
Intended use, per the manufacturer
The manufacturer’s words
R Noid is a humanoid robot that assists kitchens, packs lines, picks orders, folds linens, and hosts guests in five job-ready roles on one platform, working on your floor in weeks.
Source: robot.com · Retrieved
This category is not our assessment.
Full specifications
7 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 90kg198lbOur conversion from 90 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Technical specifications on the product page. A |
| Length | not stated | |
| Width | not stated | |
| Height | 170cm66.9inOur conversion from 170 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Technical specifications on the product page. A |
| Degrees of freedom | not stated | Caveat The product page gives 7 DOF per arm but no total for the whole robot. A |
| Payload, moving | not stated | Caveat The producer gives a payload of 4 kg per arm. That is an arm figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Caveat The producer gives a payload of 4 kg per arm. That is an arm figure, not a figure for what the whole robot can carry. A |
| Max speed | 7.2km/h4.47mphOur conversion from 7.2 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Specification sheet, labelled as the top speed. B |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | |
| Runtime | 180minWarning: load condition not stated | Caveat The product page gives a battery time of 3 hours and says the robot supports plug-in operation; no load is given. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | LiDAR for 360° front and rear mapping. | Note Specification sheet, computing and sensors. B |
| Cameras | Two RGB-D cameras; wrist cameras. | Note Specification sheet; the RGB-D cameras are listed as 120 FPS, up to 1600×1200, in the head and chest. B |
| Onboard compute | NVIDIA Jetson AGX Orin AI module; AMD Ryzen 5 7640HS base computer. | Note Specification sheet, computing and sensors. B |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | Caveat The product page lists two operating modes, autonomous and VR teleoperated; no autonomy level is named. A |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | not stated | |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- Robot.com calls R-noid its flagship full-body humanoid, 1.7 m tall, with two arms and omnidirectional movement.
- The specification sheet gives a 0.55 m wheel base.
- The producer lists Astribot among its partners for R-noid, alongside NVIDIA, FieldAI, Formic, Pi and Yukai Engineering.
- The producer's site gives no address; company registers (Crunchbase, CB Insights, PitchBook) give San Francisco, USA, for Robot.com, formerly Kiwibot.
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for R-noidhttps://www.robot.com/r-noid
Sources
-
A
Manufacturer product page. www.
robot. · Retrievedcom/ r-noid -
B
Secondary: lp.
robot. · Retrievedcom/ rnoid/ specs. pdf
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.