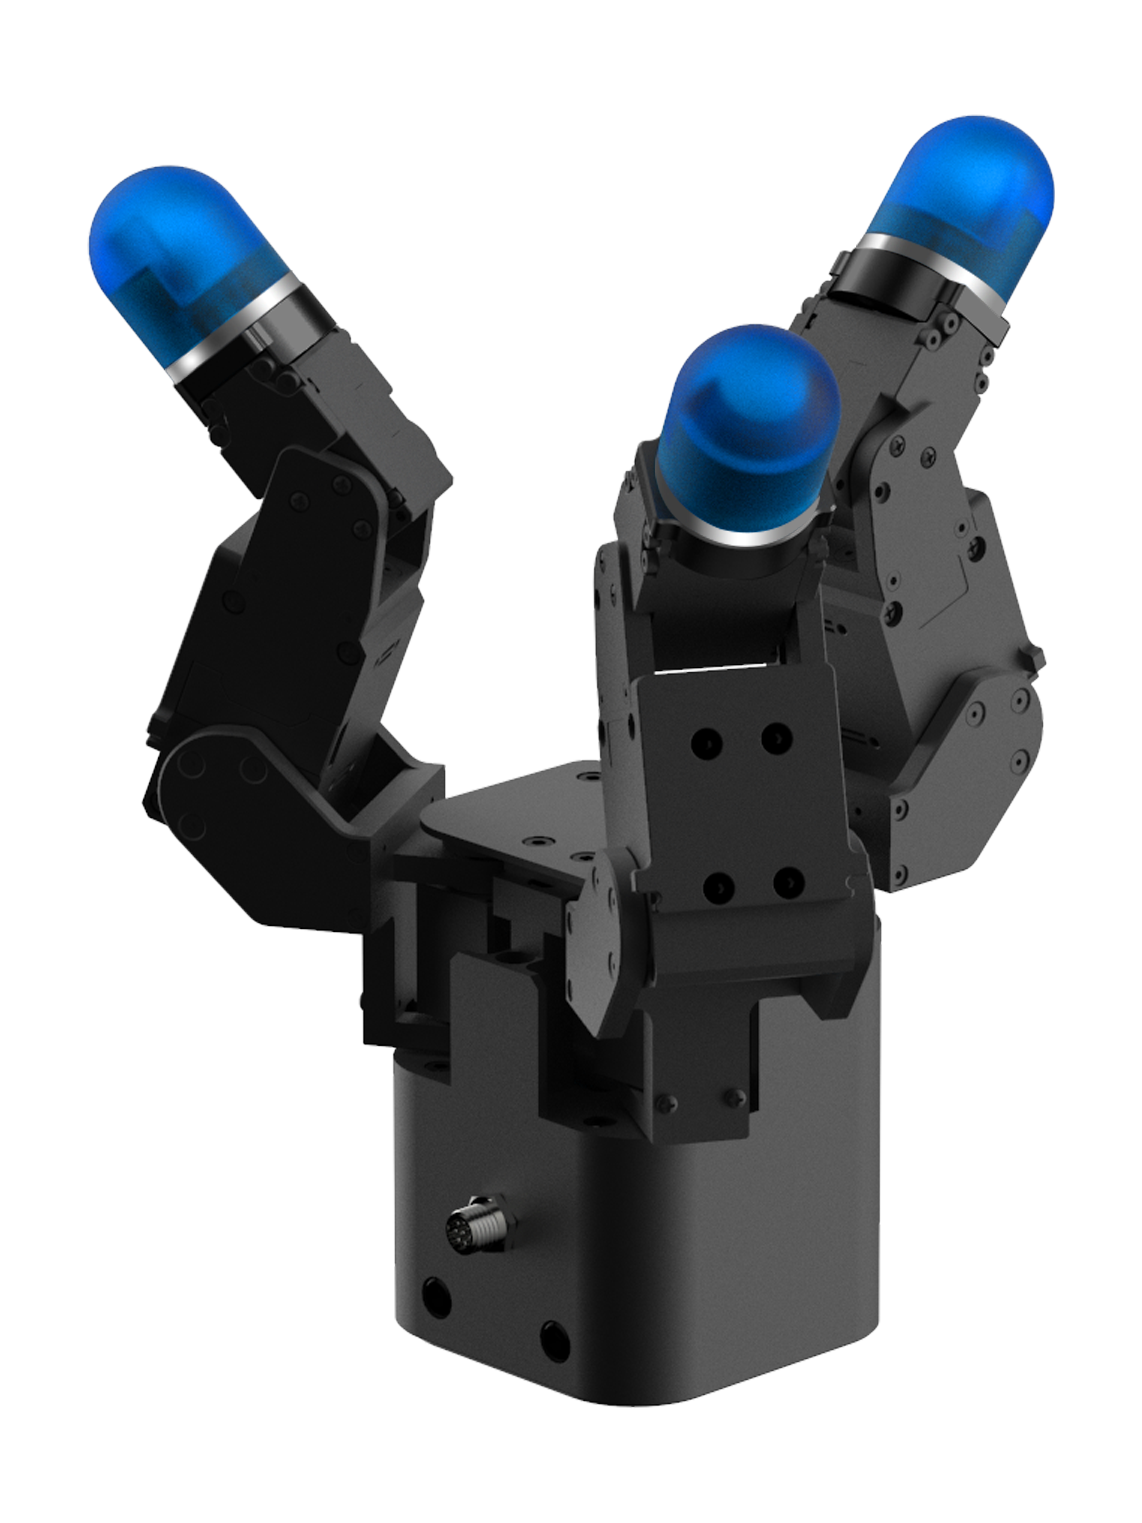
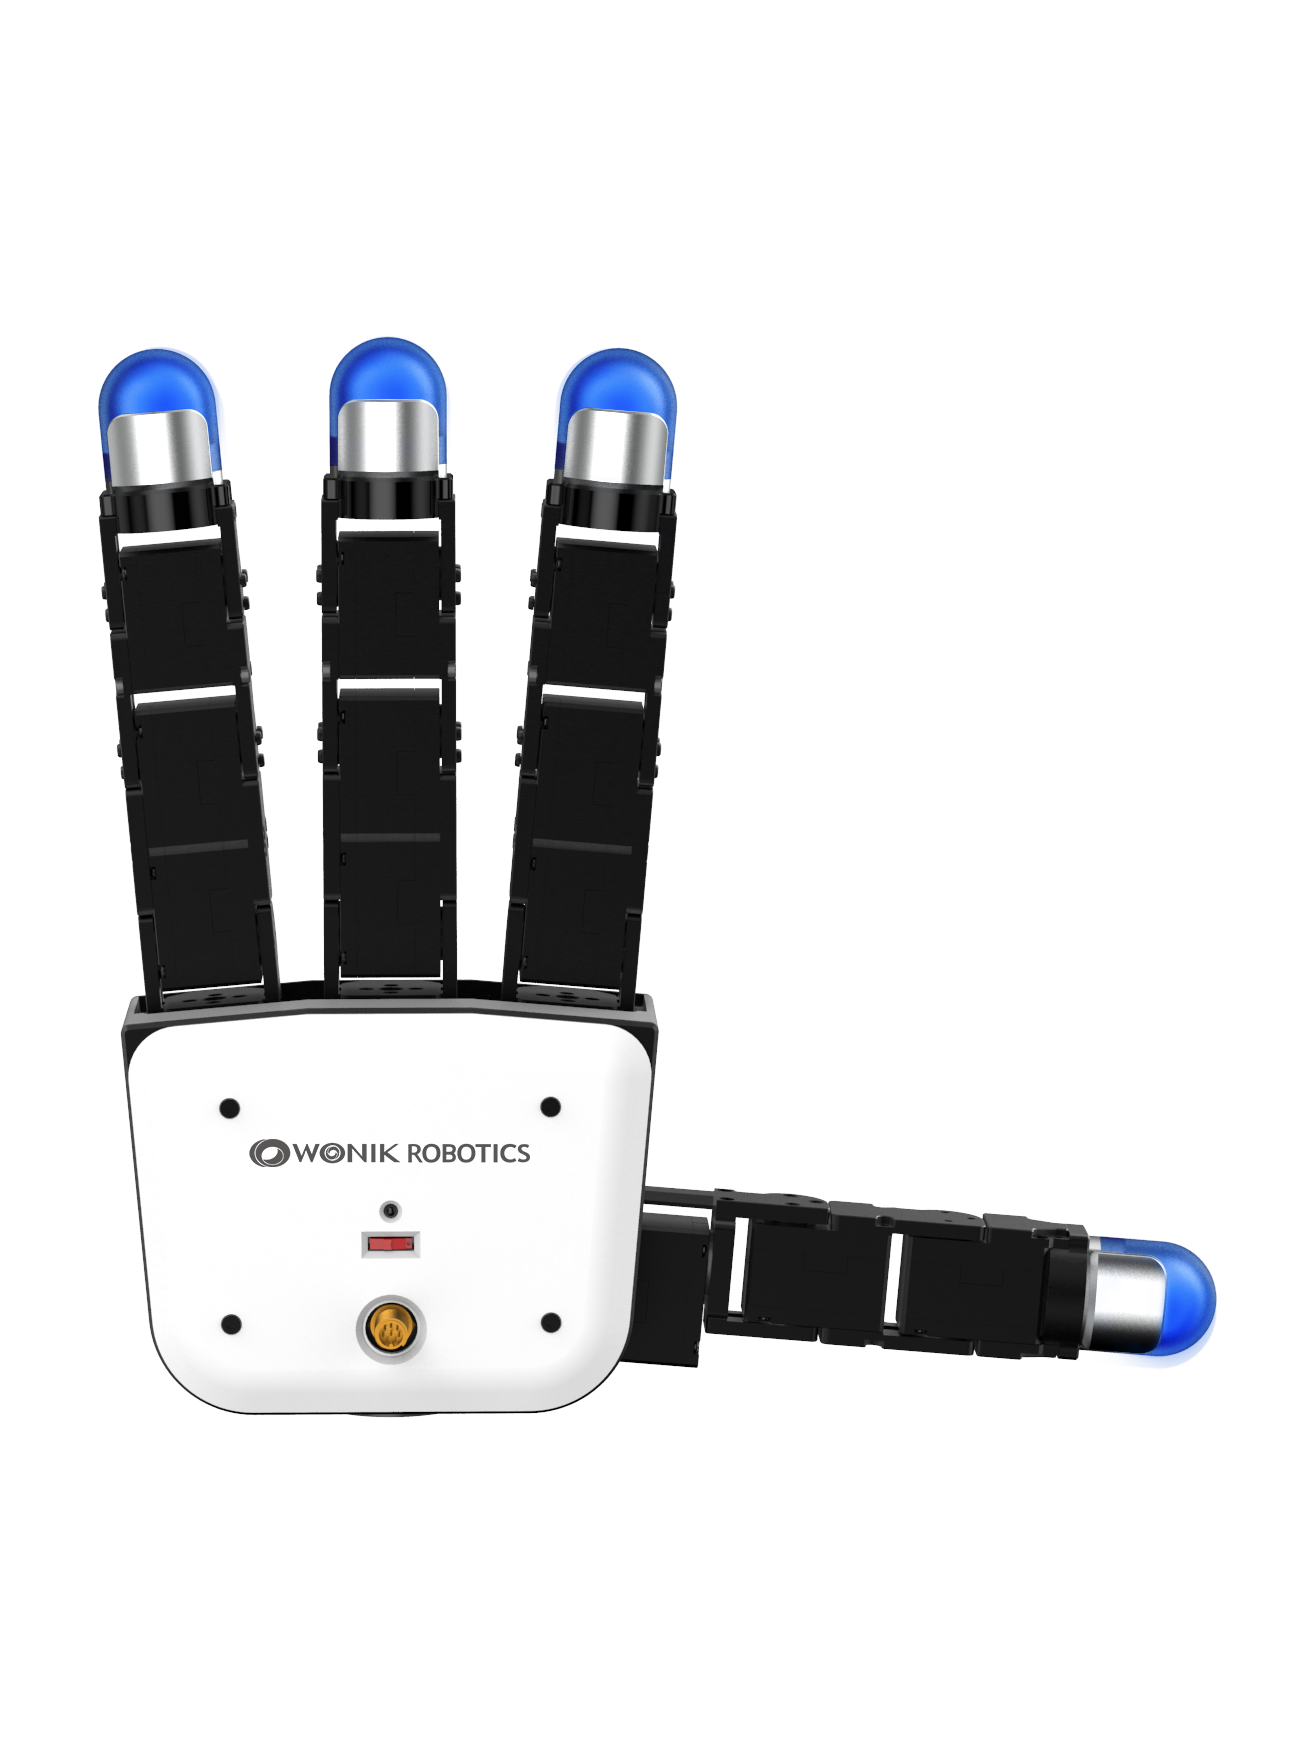
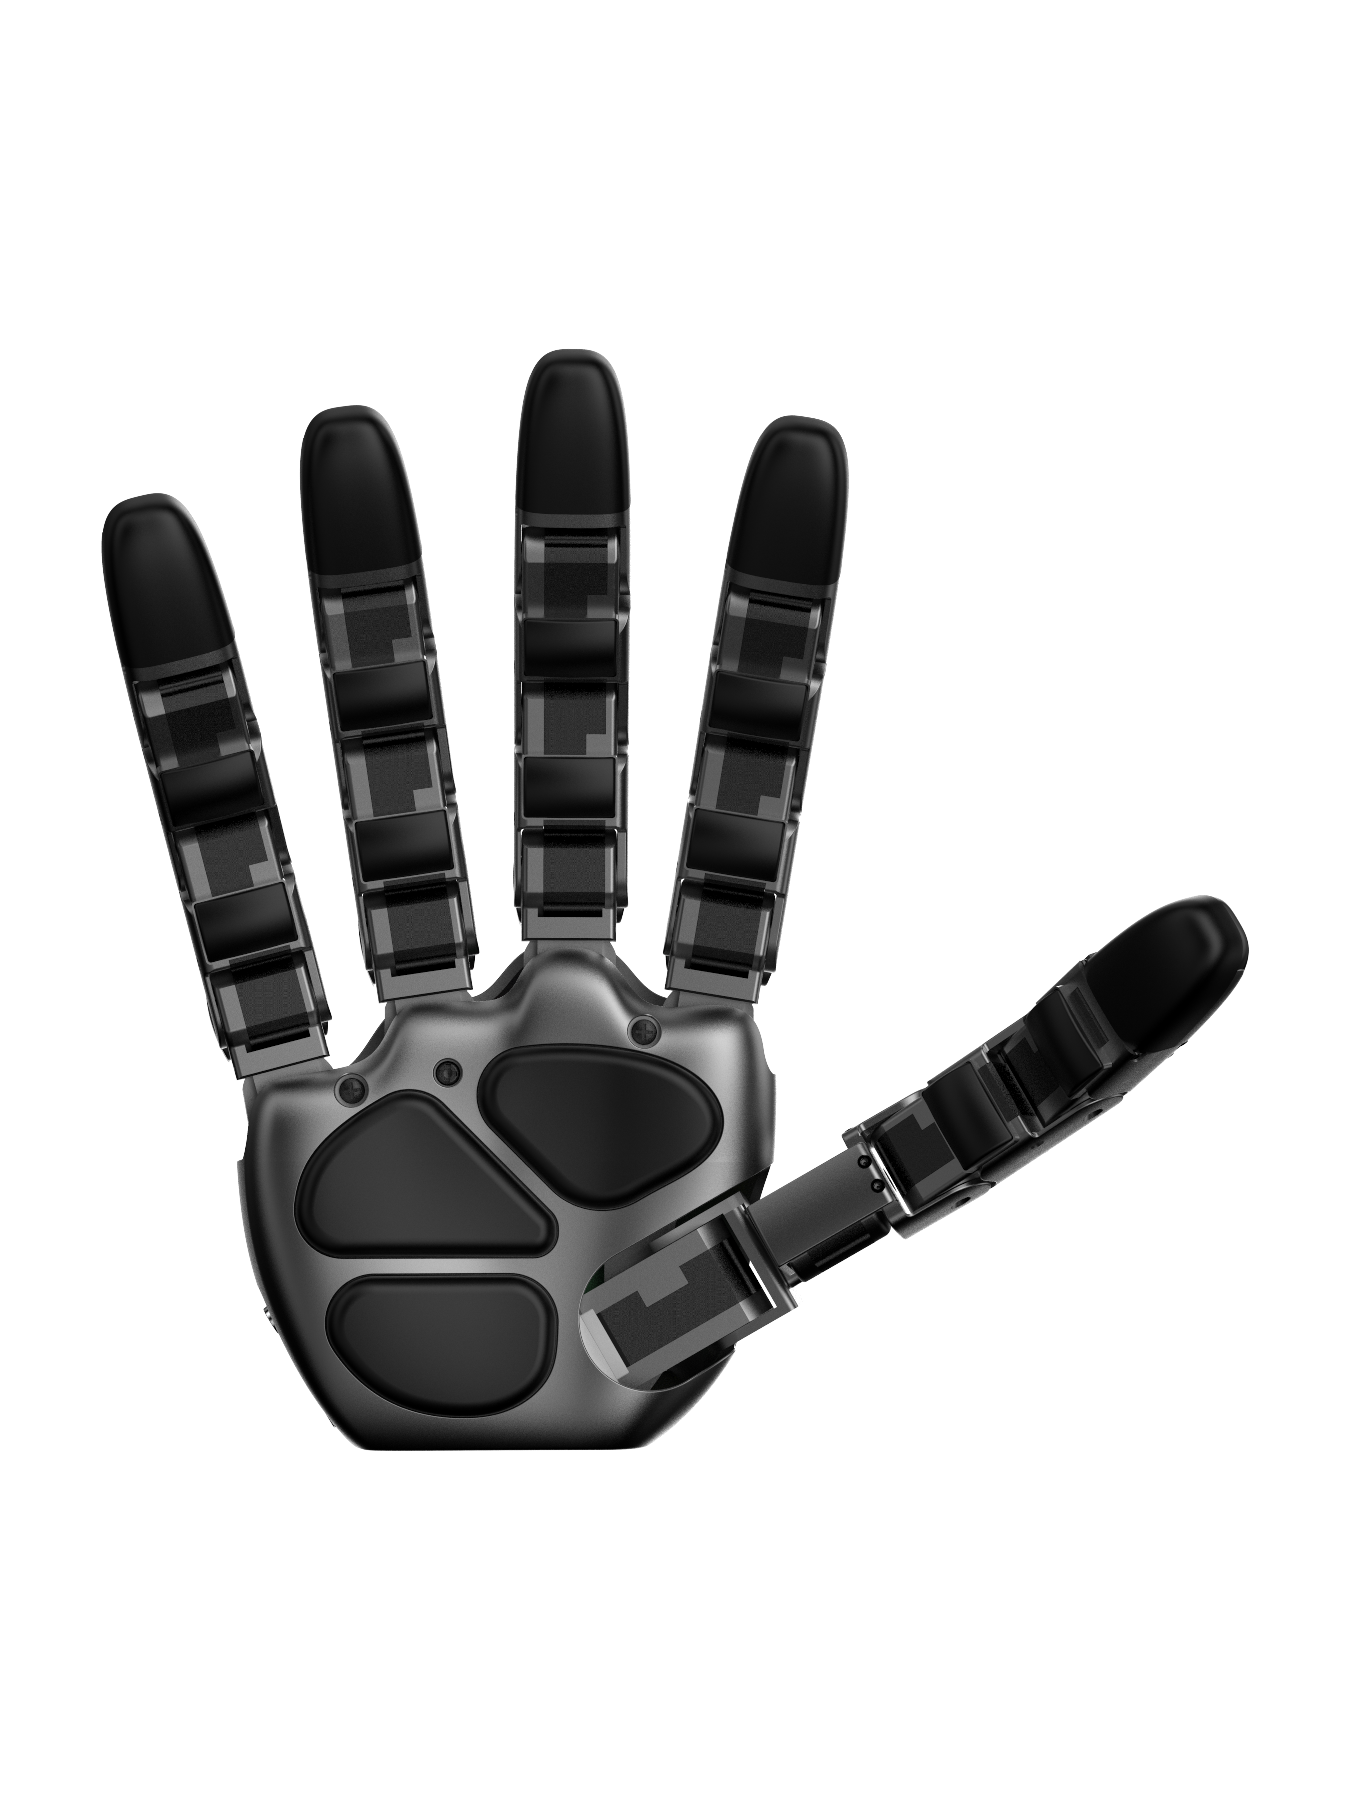
UDH-3-7
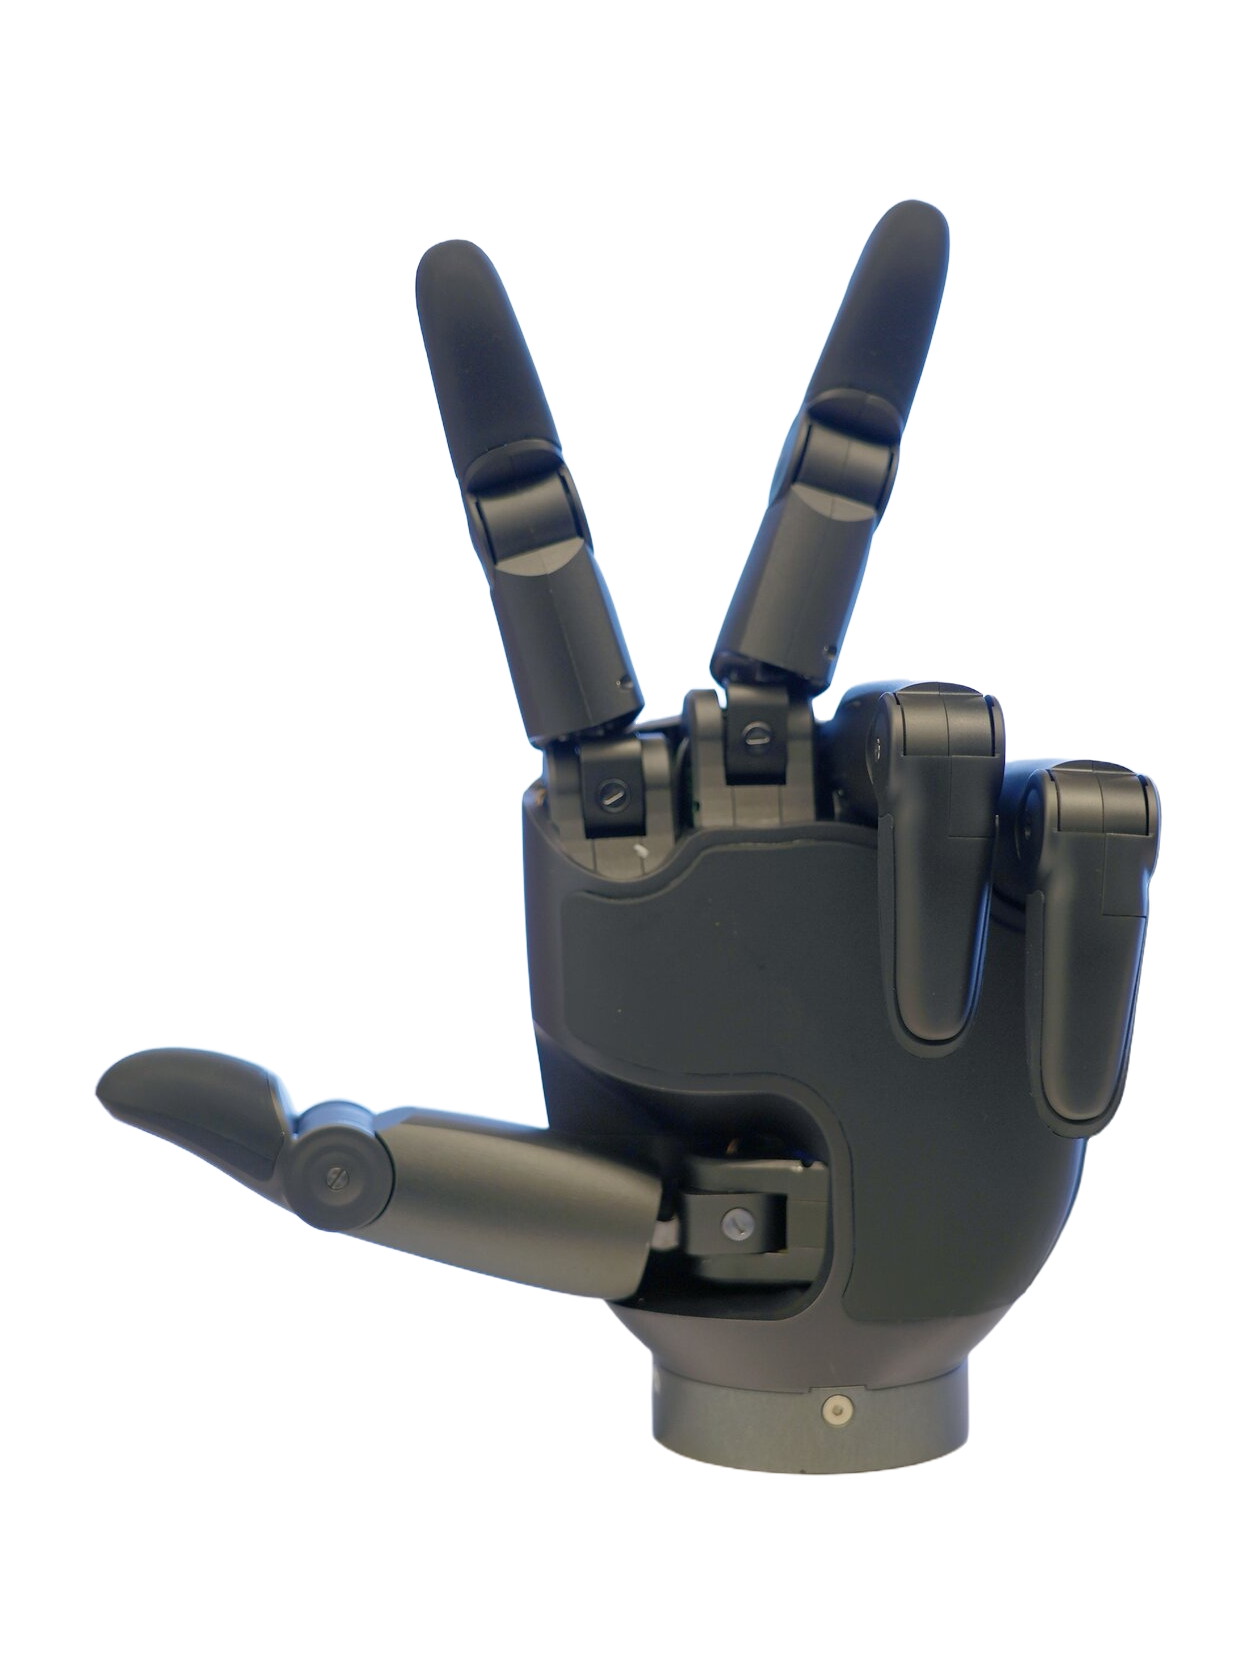
A robot hand from China, announced 2026.
Sources retrieved: 3 November 2026 (A, B)
- Applications
- Intended use, per the manufacturer
- This lightweight design combines high gripping strength with the stability required for real-world warehouse logistics.Source and note: Intended use, per the manufacturerA en.dh-robotics.com/15259.html · Retrieved 3 November 2026
- Indicative price
- Not stated
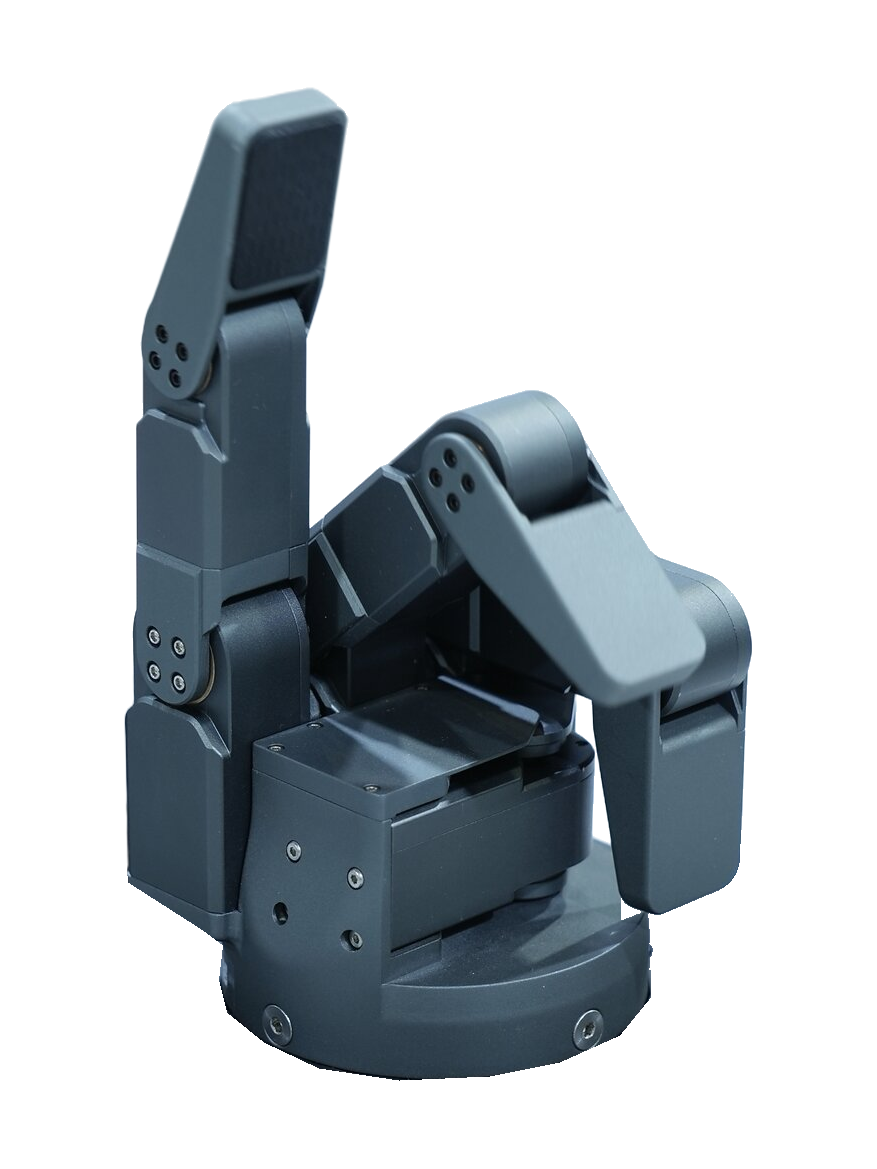
Manufacturer's own photo. Press photo: PR Newswire release from DH-Robotics, 30 Sep 2026 (IROS 2026 exhibition display, cropped from a two-hand photo; the display label reads UDH-3-7).
Specifications
9 of 18 stated 9 not stated
9 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand3/4 disclosed
Performance3/4 disclosed
Physical1/2 disclosed
Sensing and autonomy2/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Fingertip force
at most 50N
38 robot hands state a fingertip force
UDH-3-7 states an upper limit, not one figure, so it is shown open-ended and not ranked against the others. 11 state only a bound (≥ or ≤) and are not ranked.
Lifting capacity
15kg33.1lbOur conversion from 15 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
48 robot hands state a lifting capacity
20 state a higher figure, 13 a lower one. 7 more state exactly the same figure. 7 state only a bound (≥ or ≤) and are not ranked.
Weight
900g1.98lbOur conversion from 900 g. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
59 robot hands state a weight
18 state a higher figure, 36 a lower one. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
7DoF
66 robot hands state degrees of freedom
43 state a higher figure, 19 a lower one. 3 more state exactly the same figure.
Notes
On 17 July 2026 DH-Robotics showed the 7-DOF three-finger hand handling irregular objects in dynamic environments.
At WAIC 2026 (news page of 5 August 2026) the UDH-3-7 was integrated with seven Geek+ general-purpose humanoid robots, which together completed warehouse logistics tasks including tote handling and the sorting of bananas, plush toys, towels, packaged bread and snack bags.
DH-Robotics' end-effector solutions are aimed at humanoid robotics, warehouse automation and embodied intelligence.
The seven active degrees of freedom are “three in the thumb and two each in the index and middle fingers”.
Positioning repeatability is ±0.02 mm and the design life is one million cycles.
The thumb supports a 180° range of rotation and opposition.
Sources
One line per source, not per figure: a source has one retrieval date.
- Aen.dh-robotics.com/15259.htmlMain source. Retrieved 3 November 2026
- Bprnewswire.com/news-releases/dh-robotics-debuts-13-dof-direct-drive-dexterous-hand-at-iros-2026-302894571.htmlRetrieved 3 November 2026