Key figures as stated by the manufacturer
3 of 6 stated · 3 gaps- Weight A 170kg375lbOur conversion from 170 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- Payload, moving not stated
- Runtime A 300minWarning: load condition not stated
- Max speed A 3.6km/h2.24mphOur conversion from 3.6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
- AI model not stated
- Indicative price not stated
How to read the figures
- 14kgA30.9lbA
- The letter in the grey square after a figure points to the source the figure came from. Robots with several sources carry several letters.
- 1,100mmB43.3inB
- A dashed letter marks a secondary source – a datasheet, manual or developer documentation from the manufacturer, or a press report used only where the manufacturer gives no figure.
- Payload, moving
- A stroke before a field name means the figure carries a caveat that affects how it compares with other robots. The caveat is printed with the figure.
- 74.5lb
- Imperial figures are our own conversion unless the manufacturer states an imperial figure itself. The source letter always belongs to the metric figure — a conversion has no source of its own.
Deviations and variants in the key figures (4)
Weight
Note Specification table.
Payload, moving
Caveat The table gives a maximum load of 7.5 kg per arm; the page text gives more than 15 kg for both arms. That is an arm-specific figure, not a figure for what the whole robot can carry.
Runtime
Caveat Battery runtime in the specification table; no load condition is given.
Max speed
Note Maximum chassis speed in the specification table.
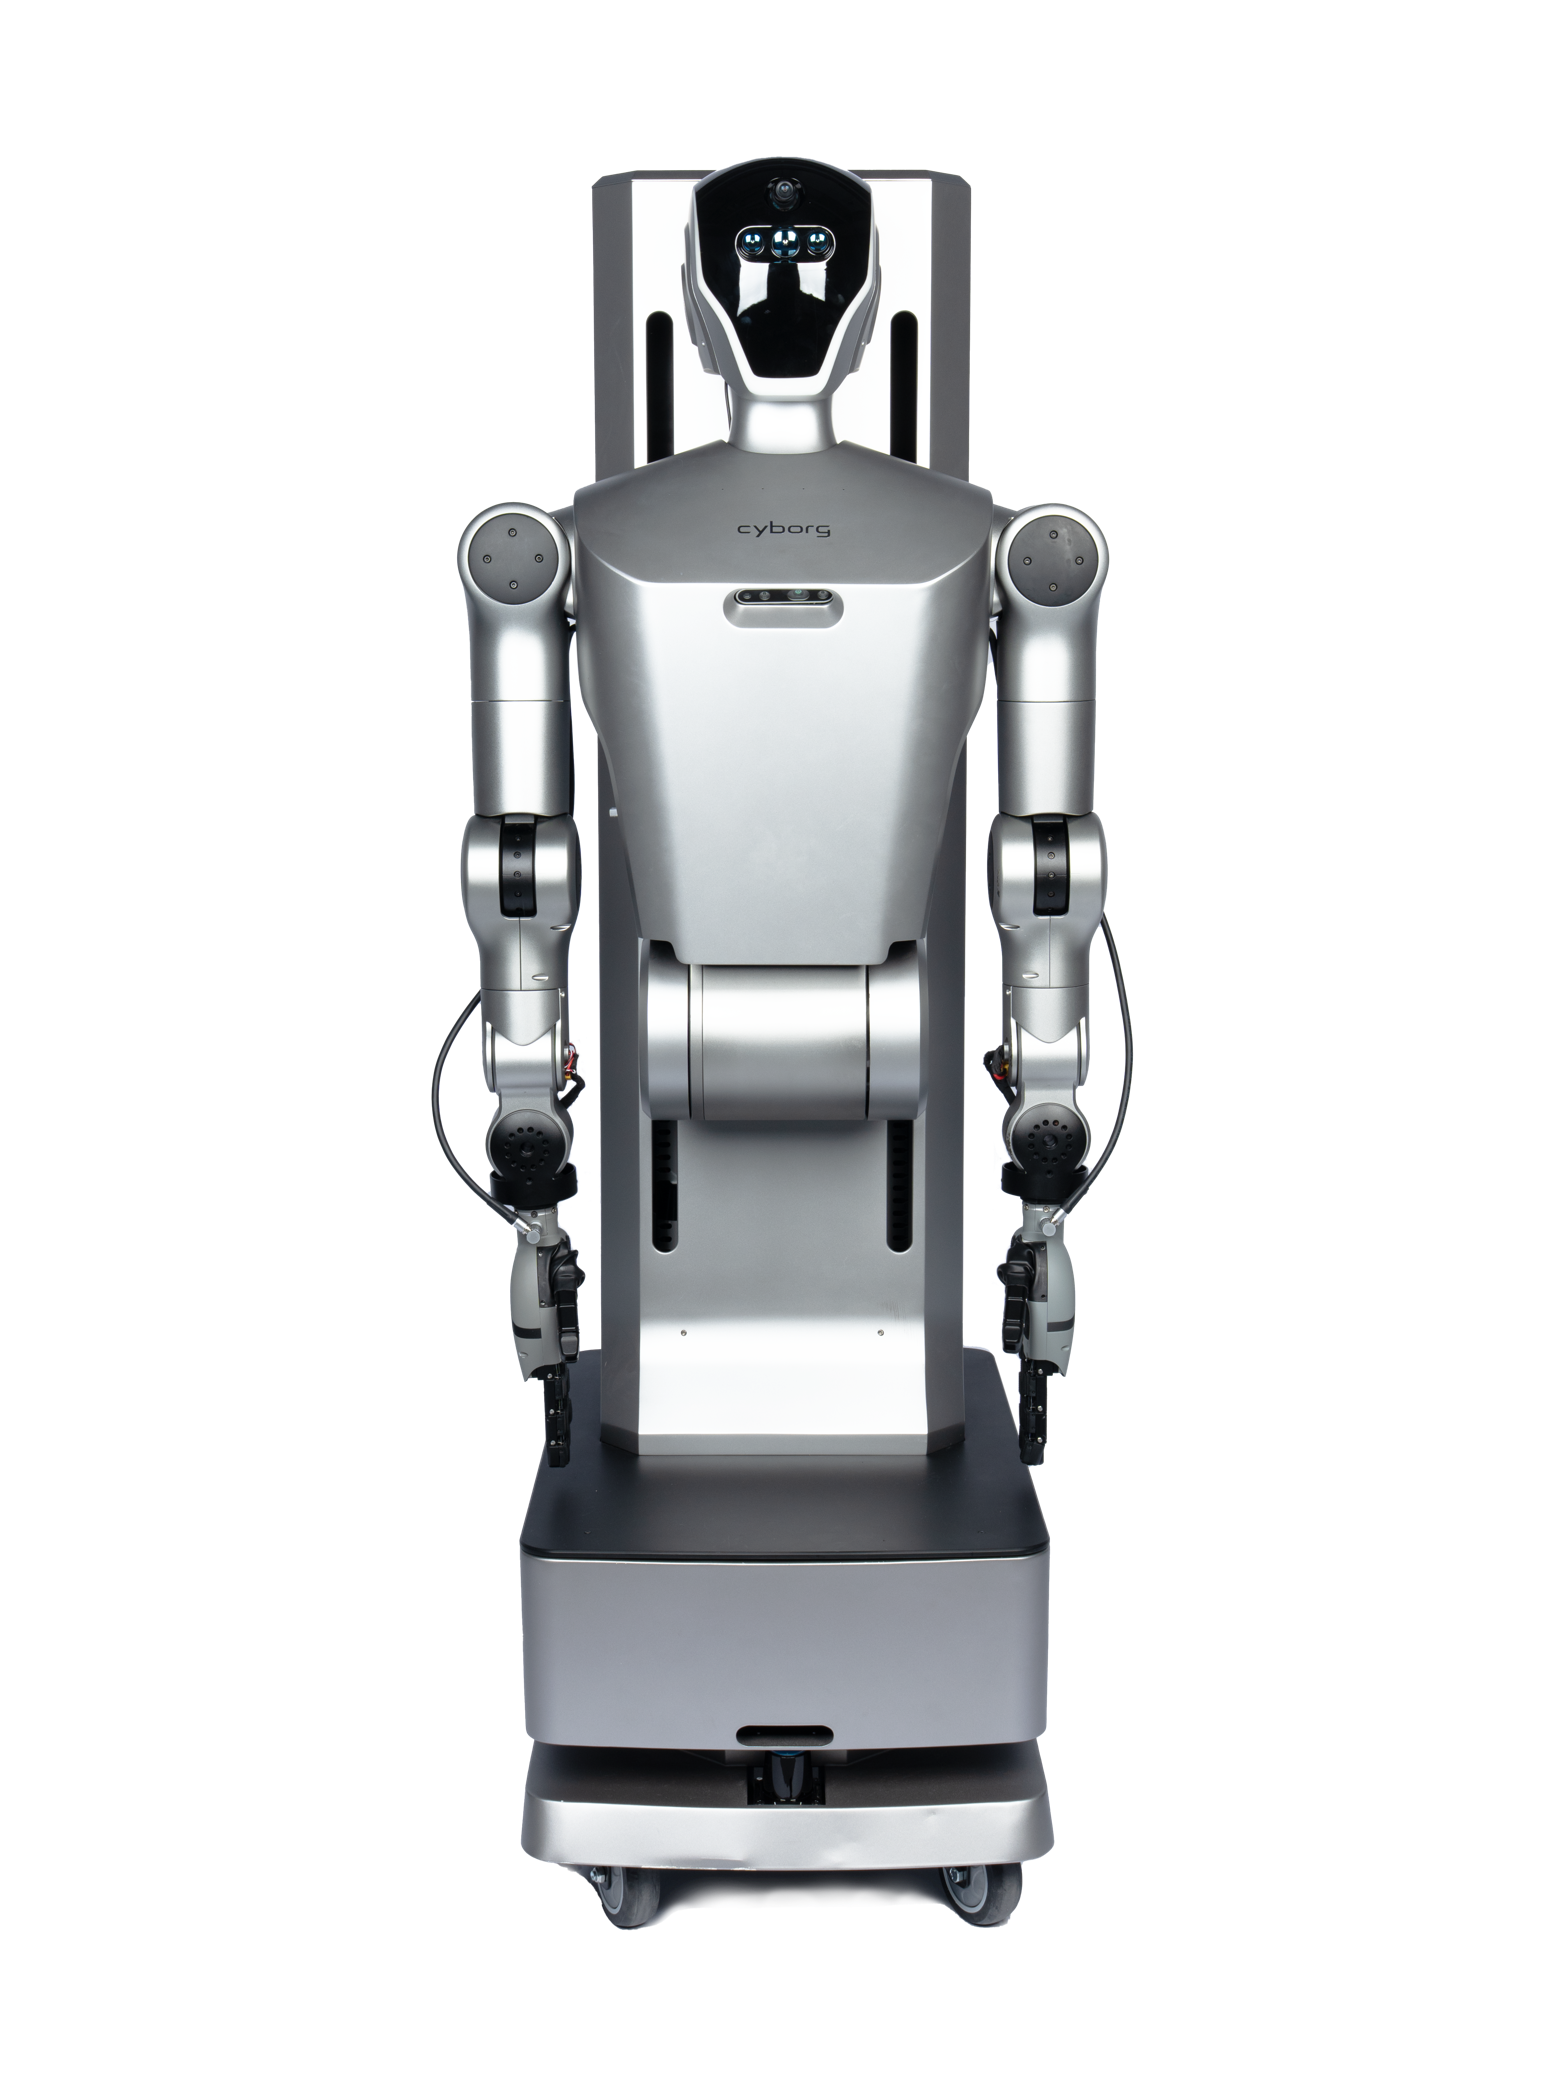
Manufacturer's own photo.
Intended use, per the manufacturer
Source: cyb-org.cn · Retrieved
This category is not our assessment.
Full specifications
10 of 32 fields stated| Field | Value | Source and caveats |
|---|---|---|
| Physical | ||
| Weight | 170kg375lbOur conversion from 170 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Specification table. A |
| Length | 71cm28inOur conversion from 71 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Length in the specification table, given as length, width and height 710*585*1600mm. A |
| Width | 58.5cm23inOur conversion from 58.5 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Width in the specification table, given as length, width and height 710*585*1600mm. A |
| Height | 160cm63inOur conversion from 160 cm. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Height in the specification table, given as length, width and height 710*585*1600mm. A |
| Degrees of freedom | not stated | Caveat The table gives 53 in total, the text on the same page gives 50, and the producer's launch news gives 51. A |
| Payload, moving | not stated | Caveat The table gives a maximum load of 7.5 kg per arm; the page text gives more than 15 kg for both arms. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Payload, standing | not stated | Caveat The table gives a maximum load of 7.5 kg per arm; the page text gives more than 15 kg for both arms. That is an arm-specific figure, not a figure for what the whole robot can carry. A |
| Max speed | 3.6km/h2.24mphOur conversion from 3.6 km/h. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own. | Note Maximum chassis speed in the specification table. A |
| Max slope | not stated | |
| Single obstacle | not stated | |
| IP rating | not stated | |
| Operating temperature, low | not stated | |
| Operating temperature, high | not stated | |
| Power | ||
| Battery | not stated | Caveat The producer's launch news gives a 48 V, 35000 mAh battery and no energy figure. B |
| Runtime | 300minWarning: load condition not stated | Caveat Battery runtime in the specification table; no load condition is given. A |
| Hot-swap battery | not stated | |
| Charge time | not stated | |
| Docking station | not stated | |
| Sensing and autonomy | ||
| LiDAR | LiDAR. | Note The same table row lists an IMU, an infrared sensor and a six-axis force sensor. A |
| Cameras | Monocular camera and RGB-D depth camera. | Note Specification table. A |
| Onboard compute | 12-core perception computing platform, 275 TOPS. | Note Specification table. A |
| ROS 2 | not stated | |
| SDK languages | not stated | |
| Autonomy level | not stated | |
| Payload and expansion | ||
| Mounting interface | not stated | |
| Power out | not stated | |
| Data ports | USB 3.0 Gigabit Ethernet DP | Note External interfaces in the specification table. A |
| Commercial | ||
| Indicative price | not stated | |
| EU | ||
| CE stated | not stated | Records only what the manufacturer states regarding CE marking. |
| FCC stated | not stated | |
| UL stated | not stated | |
| CCC stated | not stated | |
Notes
- The producer's launch news calls the Cyborg-W01 a wheeled humanoid bionic robot (translated from the Chinese).
- The launch news says the chassis turns in place and can pass through aisles 0.75 m wide (translated from the Chinese).
- The producer launched the robot at the China Hi-Tech Fair in Shenzhen on 14 November 2025 (translated from the Chinese).
- The producer's launch news gives the company name as Shenzhen Cyborg Robot Technology Co., Ltd. (translated from the Chinese).
The manufacturer’s own page
The manufacturer’s original product page for this model.
Open the manufacturer’s page for Cyborg-W01https://www.cyb-org.cn/index.php?id=4
Sources
-
A
Manufacturer product page. www.
cyb-org. · Retrievedcn/ index. php? id= 4 -
B
Secondary: www.
cyb-org. · Retrievedcn/ index. php? id= 38
One line per source, not per figure: a source has one retrieval date. The letter beside a figure points to the line it came from.