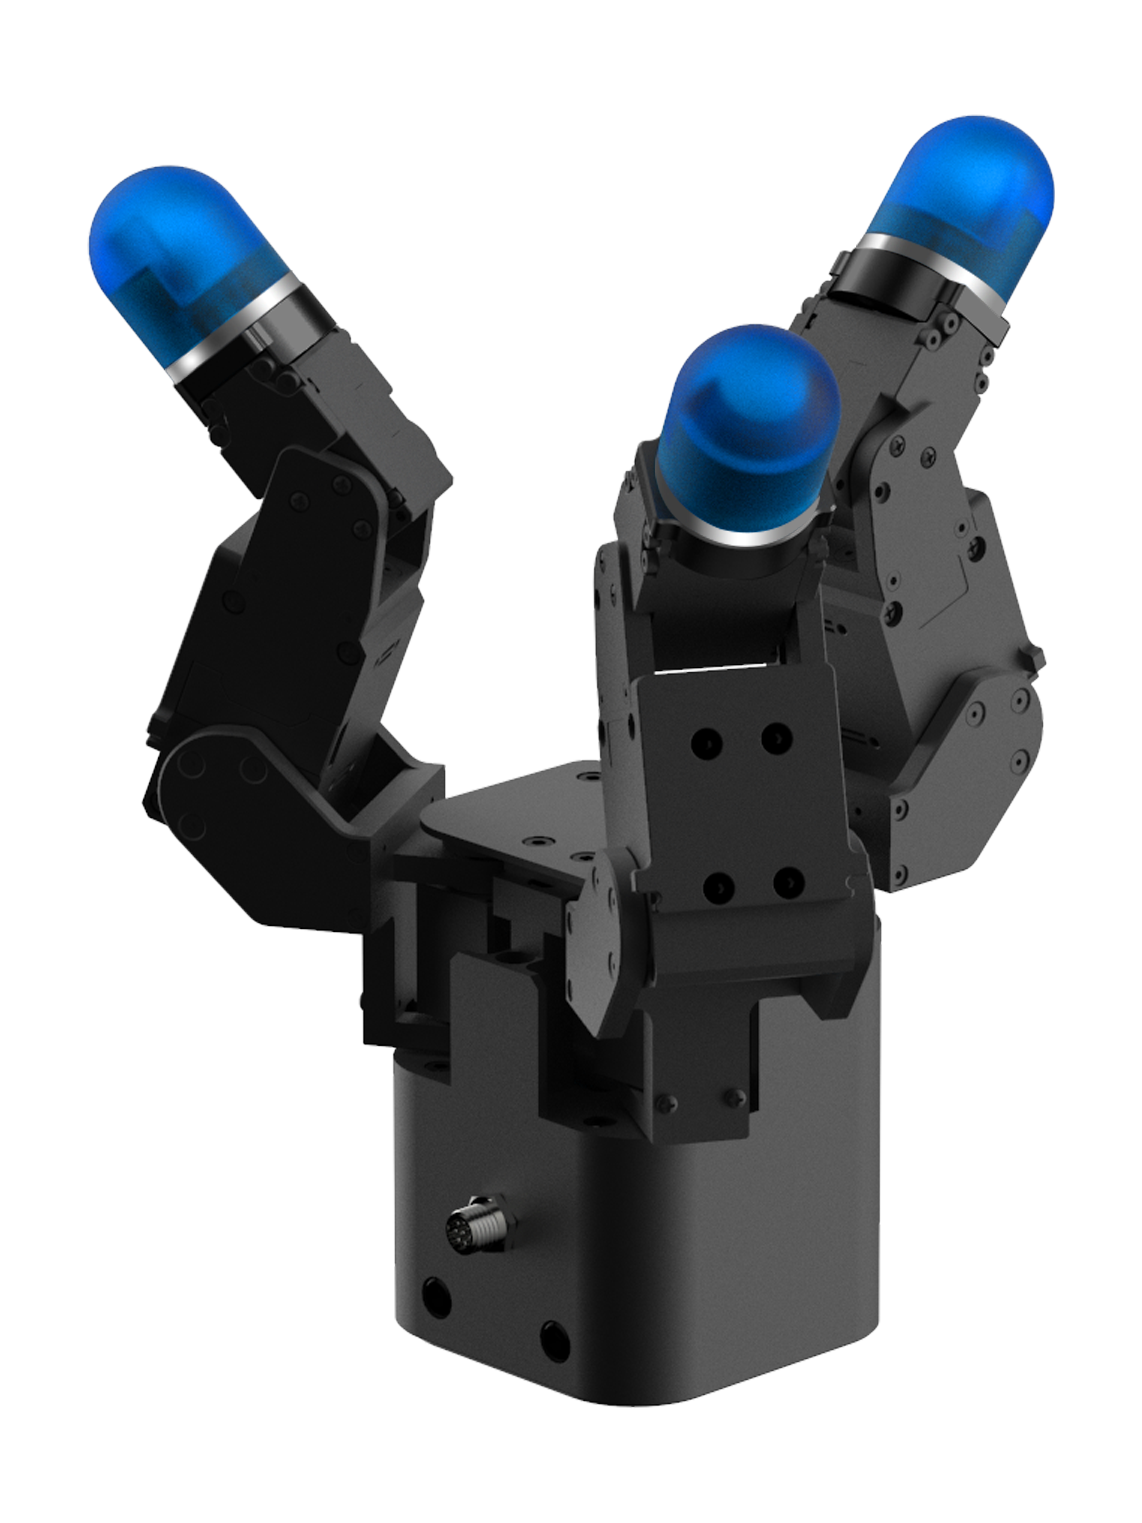
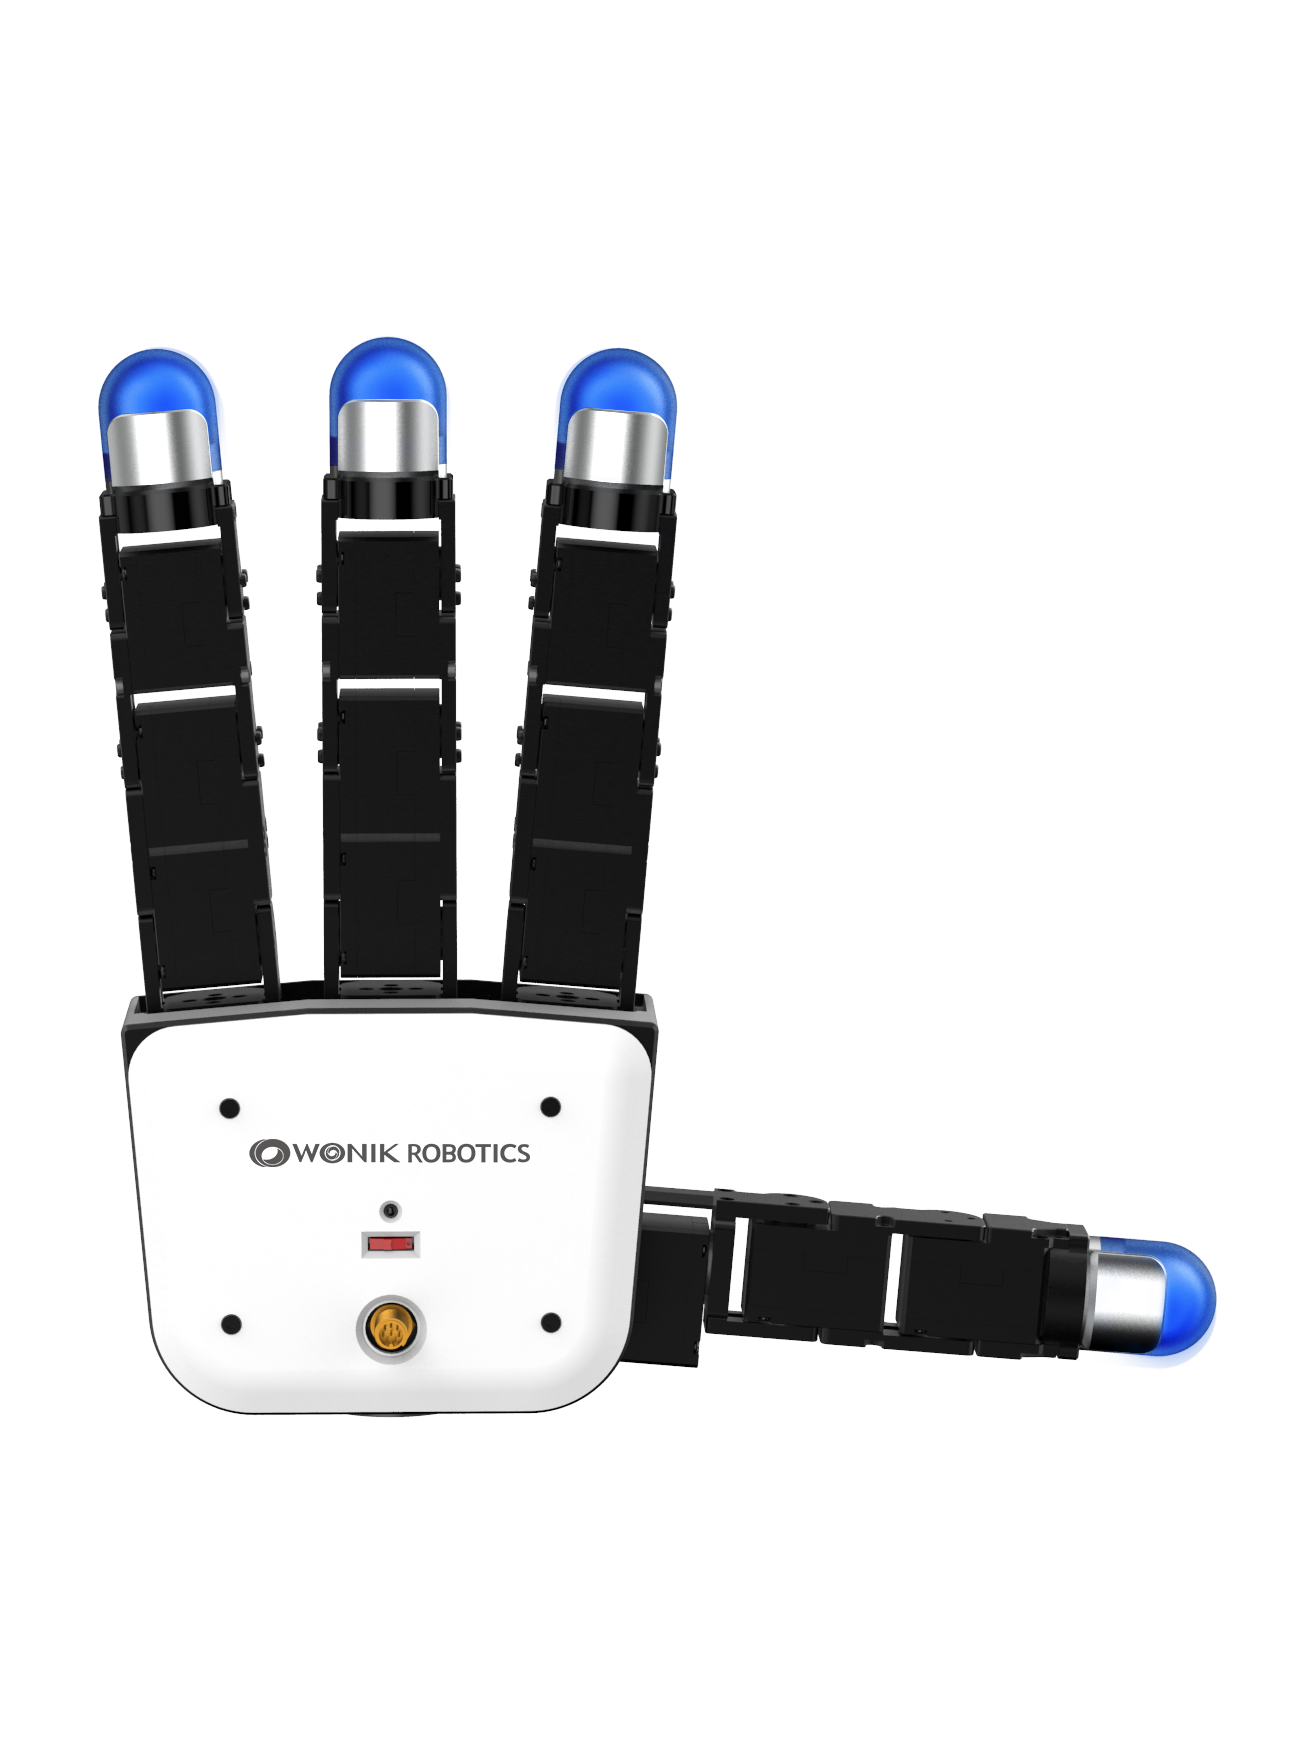
DEX-EE Chiral
A robot hand from the United Kingdom.
Sources retrieved: 4 November 2026 (A, B, C)
- Status
- In production
- Applications
- Intended use, per the manufacturer
- Designed to reliably meet the needs of long-running reinforcement learning experimentsSource and note: Intended use, per the manufacturerB shadowrobot.com/dex-ee_series/ · Retrieved 4 November 2026
- Indicative price
- Not stated
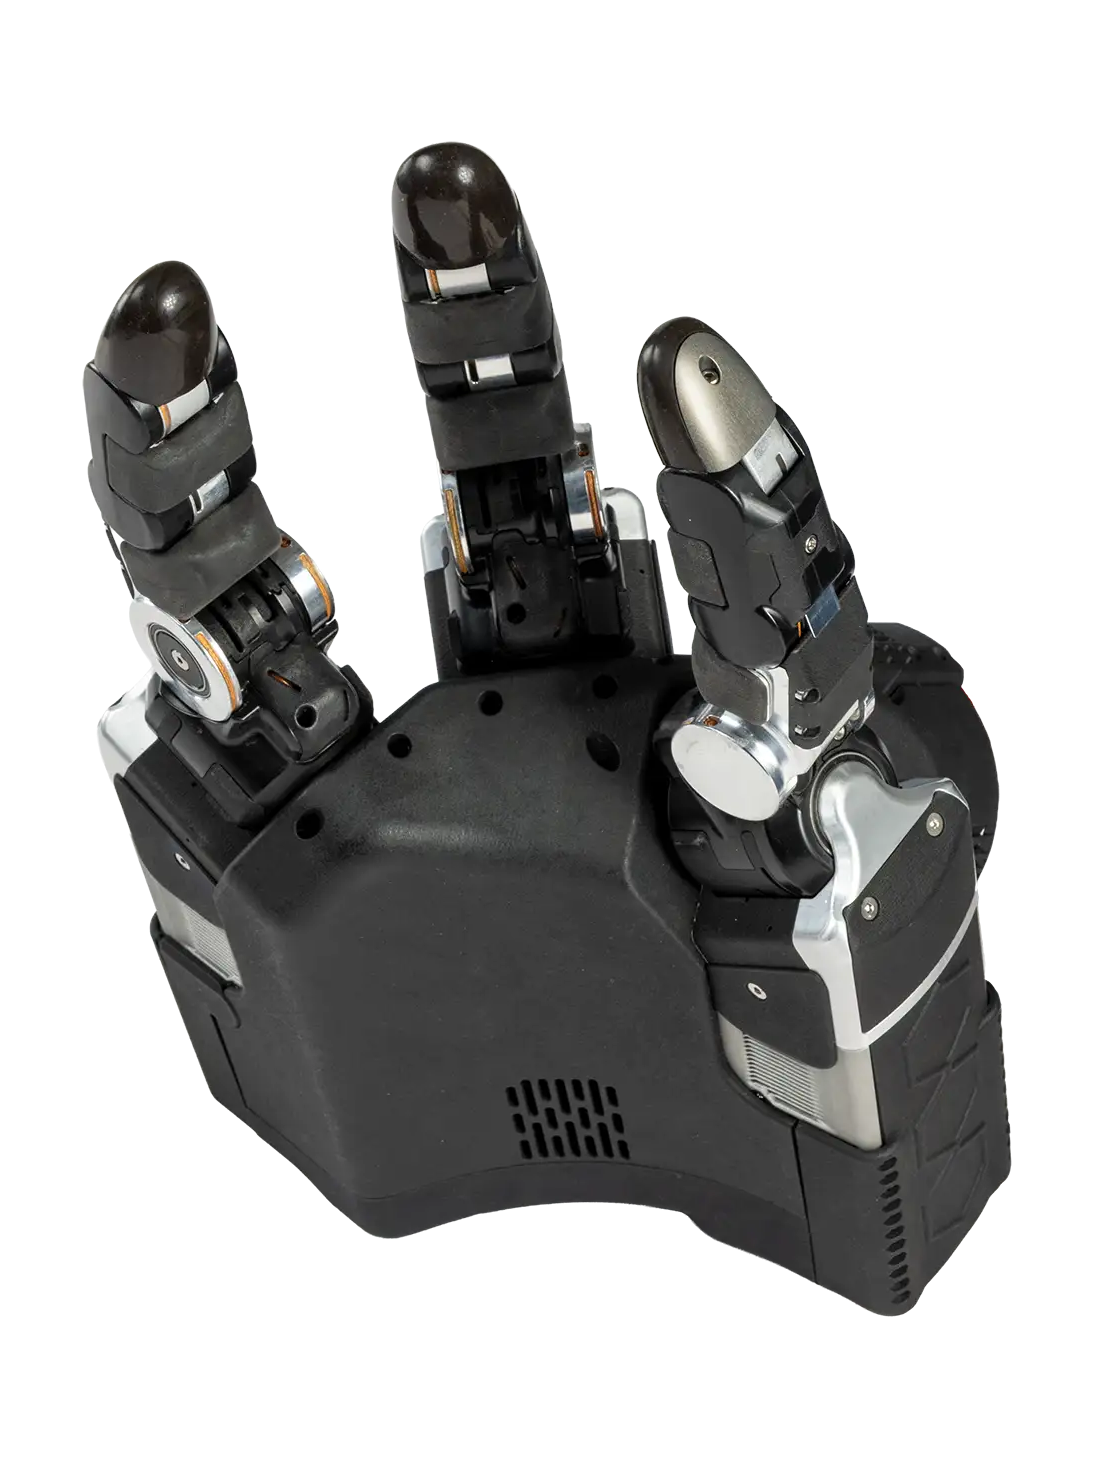
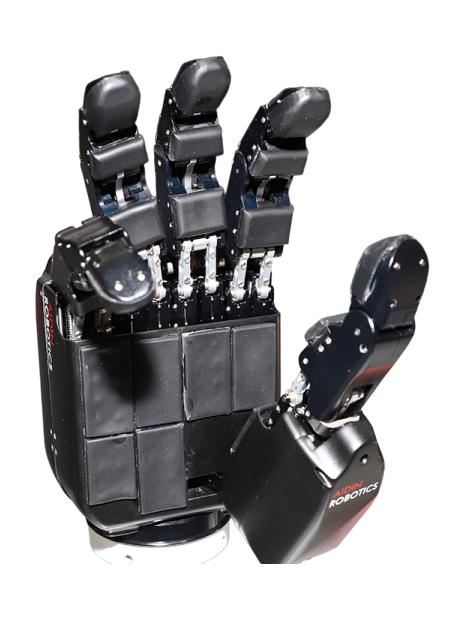
Manufacturer's own photo.
Specifications
9 of 18 stated 9 not stated
9 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand3/4 disclosed
Performance3/4 disclosed
Physical2/2 disclosed
Sensing and autonomy1/3 disclosed
Commercial0/1 disclosed
Compliance & certifications0/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Fingertip force
at least 8N
38 robot hands state a fingertip force
DEX-EE Chiral states a lower limit, not one figure, so it is shown open-ended and not ranked against the others. 11 state only a bound (≥ or ≤) and are not ranked. DG-5F-M lies beyond the end of the axis and is drawn at its edge as an open bar.
Weight
4.1kg9.04lbOur conversion from 4.1 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
59 robot hands state a weight
0 state a higher figure, 54 a lower one. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
12DoF
66 robot hands state degrees of freedom
36 state a higher figure, 27 a lower one. 2 more state exactly the same figure.
Notes
Shadow's DEX-EE Series page says: “Now available for purchase, DEX-EE & DEX-EE Chiral are an ideal hardware platform for dexterous manipulation research.”
Shadow's ICRA 2026 recap says: “Unlike the standard DEX-EE hand, which features a symmetric three-finger configuration, DEX-EE Chiral incorporates a human-like thumb offset.”
The DEX-EE Series page says: “Available in “Left”, “Right”, and “Bi-Manual Pair”, DEX-EE Chiral opens up new possibilities in robust manipulation”.
The DEX-EE Series page says: “Stereo camera-based fingertip tactile sensors provide an unprecedented level of 3D interaction detail in a robust package”. It adds: “Multi-taxel, 3 DOF tactile sensors on middle and proximal phalanges give additional information during grasping and manipulation”.
The ICRA 2026 recap says: “The hand is equipped with multi-taxel magnetic tactile sensors across the distal, middle, and proximal phalanges, providing rich tactile feedback for dexterous manipulation tasks.”
The DEX-EE Series page says: “High bandwidth torque and position control loops give delicate and precise fingertip dexterity”.
Sources
One line per source, not per figure: a source has one retrieval date.
- Ashadowrobot.com/icra-2026-recap/Main source. Retrieved 4 November 2026
- Bshadowrobot.com/dex-ee_series/Retrieved 4 November 2026
- Cshadowrobot.com/wp-content/uploads/2026/05/Shadow-DEX-EE-Series-Technical-Specifications.pdfSecondary. Retrieved 4 November 2026