Mia Hand R&D
Other variants Without force sensors · With force sensors
Figures below are for Mia Hand R&D.
A robot hand from Italy.
Sources retrieved: 4 November 2026 (A, B)
- Status
- In production
- Applications
- Intended use, per the manufacturer
- The small size and weight make Mia Hand R&D the perfect tool for humanoid robotics, industrial automation, ergonomics, human-machine interfaces and prosthetics. Its robustness allows it to be used in unsupervised scenarios in longitudinal studies.Source and note: Intended use, per the manufacturerA prensilia.com/mia-hand-research/ · Retrieved 4 November 2026
- Indicative price
- Not stated
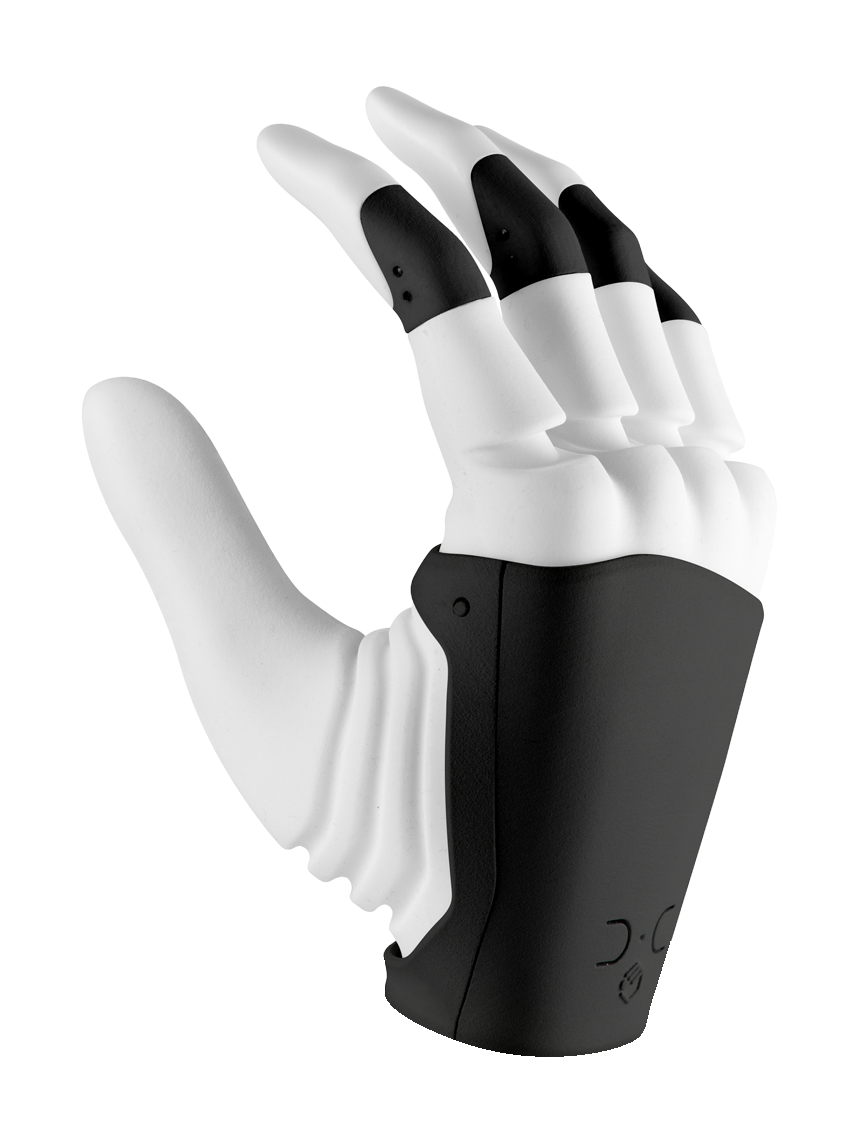
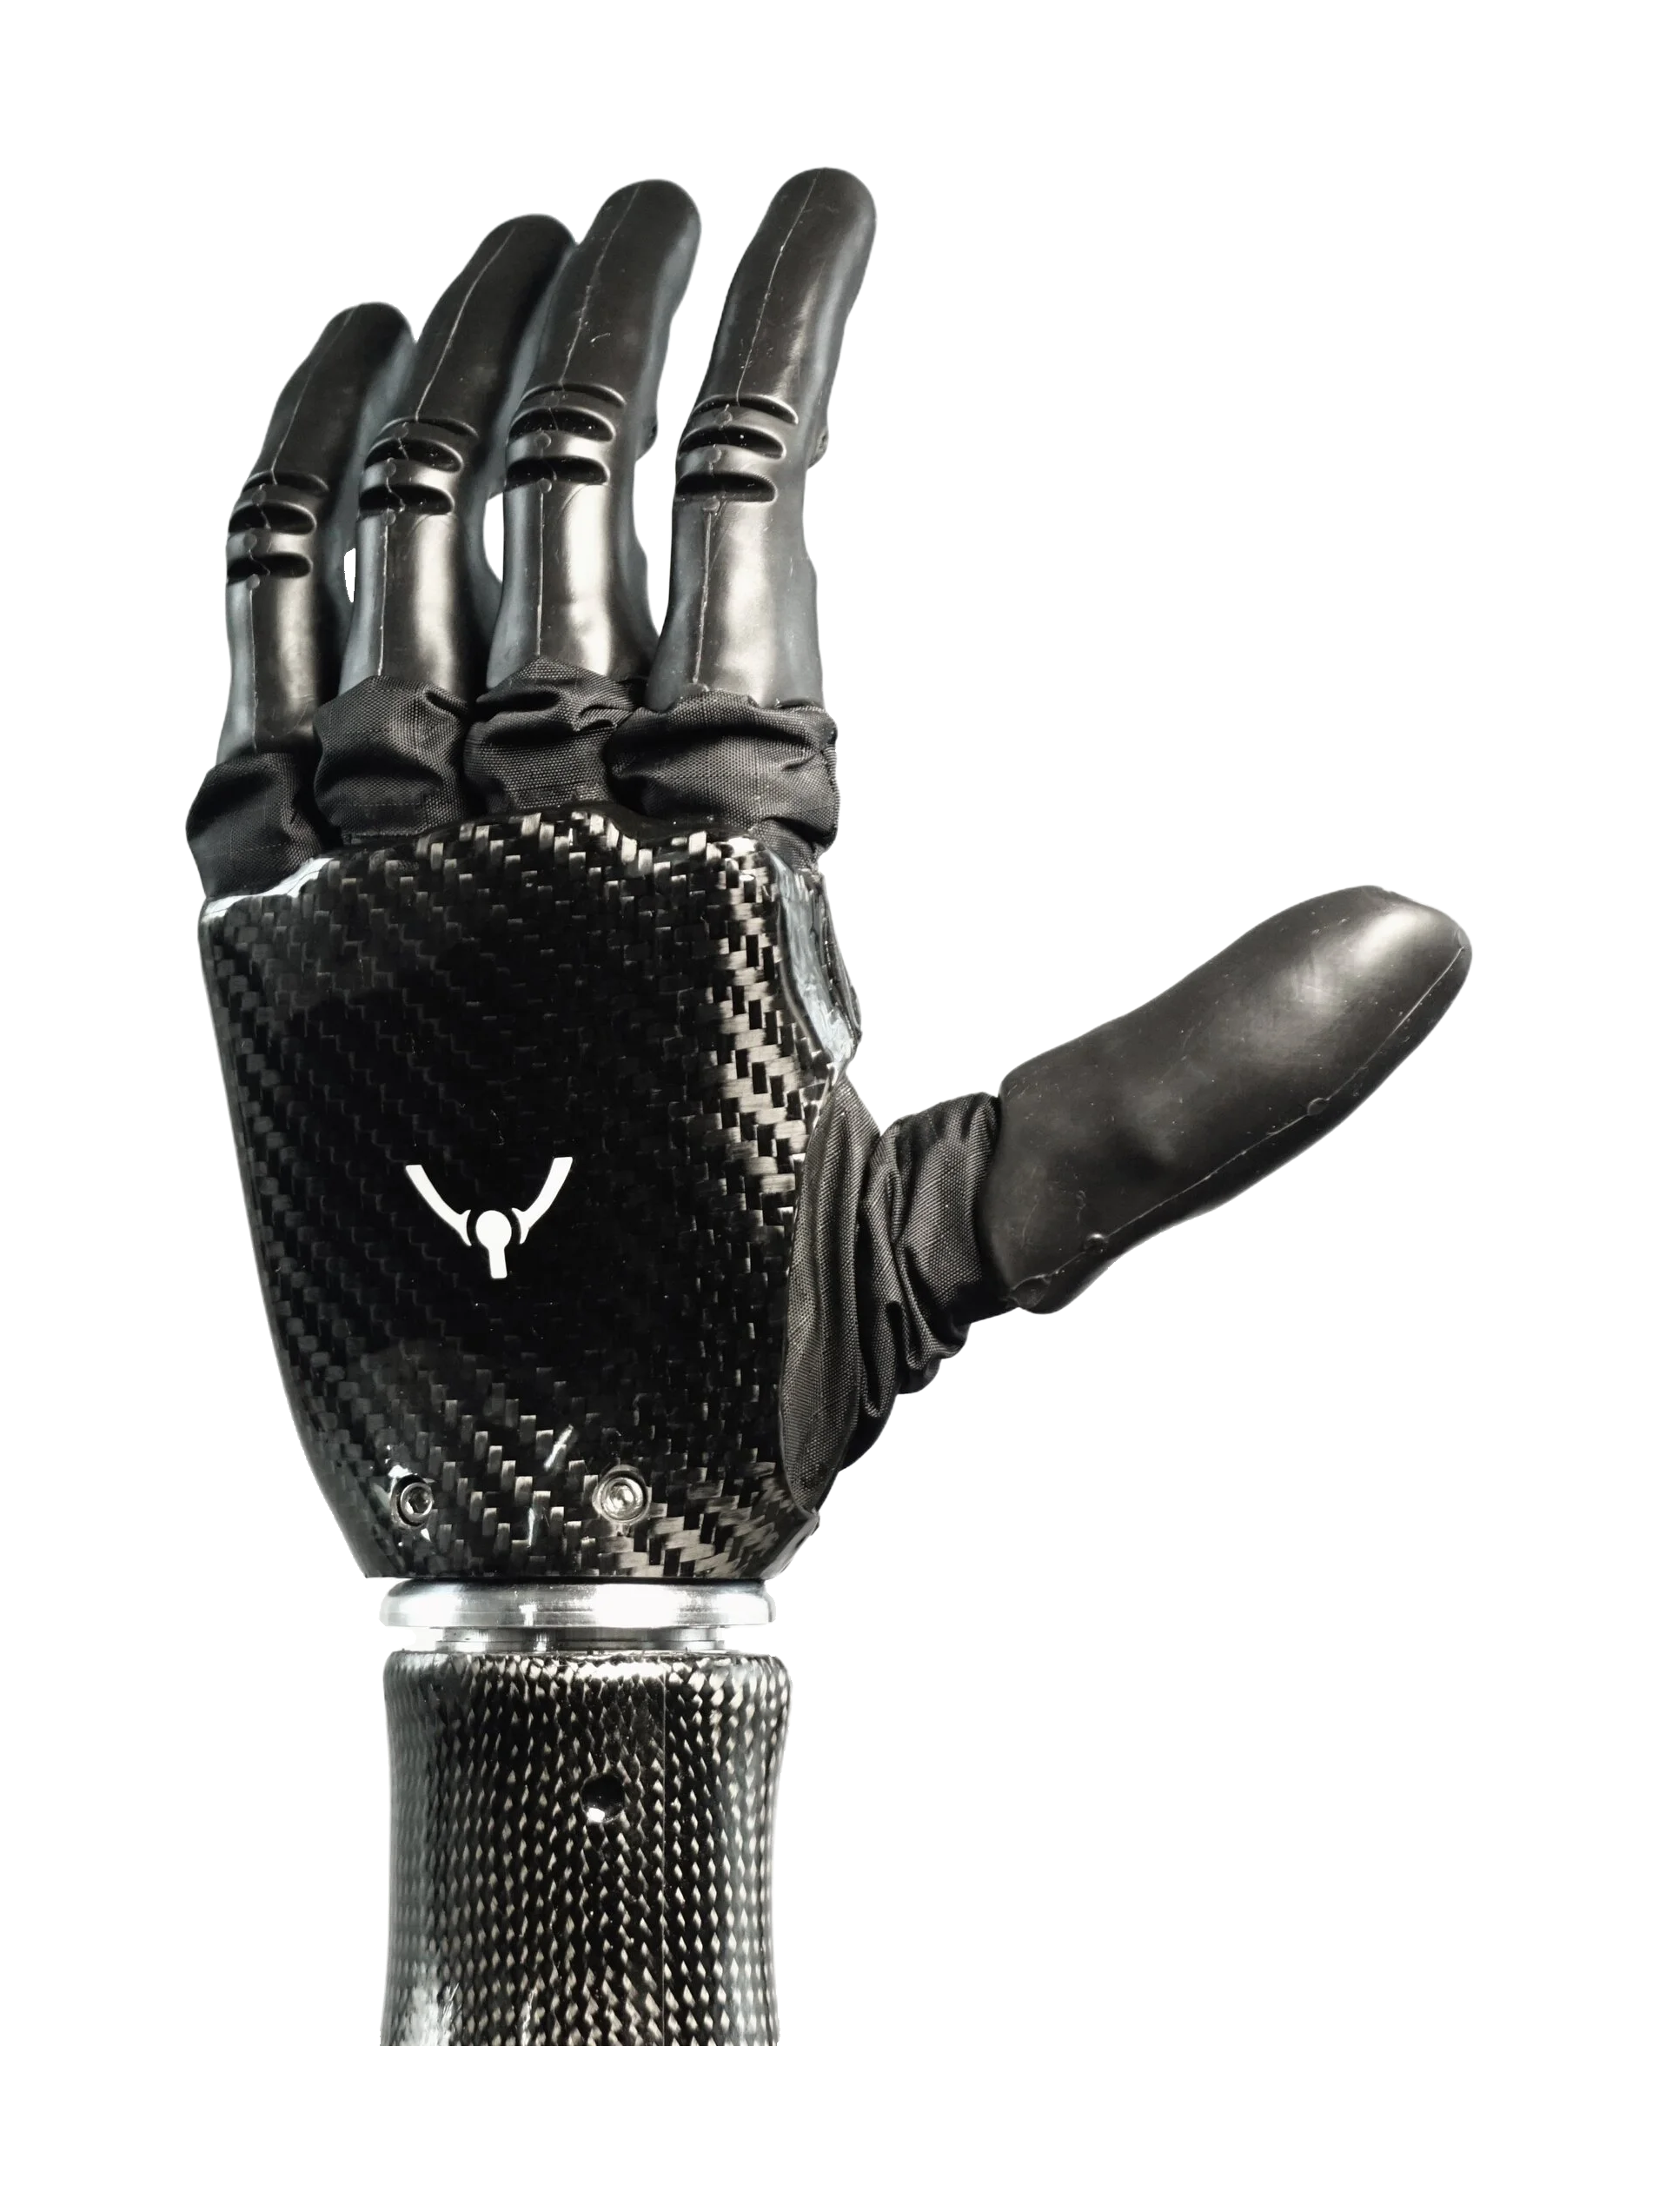
Manufacturer's own photo.
Specifications
10 of 18 stated 8 not stated
8 fields hidden
How to read the figuresShow guideClose
- not statedNo source
- noyesStated by a source
- 0Reported as zero
- ASource
- A*Source with a caveat (select it)
- VariantsDiffers between variants
- CERecords only what the manufacturer states regarding CE marking.
Select a source marker for source details and notes.
The hand2/4 disclosed
Performance3/4 disclosed
Physical2/2 disclosed
Sensing and autonomy2/3 disclosed
- Variants
- With force sensors
- yes
Commercial0/1 disclosed
Compliance & certifications1/4 disclosed
Against the field
Each strip holds every robot of this type in the guide that states the figure, one bar per group of values. Further right means a larger figure, not a better robot. A taller bar means more robots in that group.
Lifting capacity
2kg4.41lbOur conversion from 2 kg. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
48 robot hands state a lifting capacity
37 state a higher figure, 1 a lower one. 2 more state exactly the same figure. 7 state only a bound (≥ or ≤) and are not ranked.
Weight
520g1.15lbOur conversion from 520 g. The manufacturer does not state an imperial figure itself, so the conversion has no source of its own.
59 robot hands state a weight
44 state a higher figure, 10 a lower one. 4 state only a bound (≥ or ≤) and are not ranked. Log scale: each step along the axis multiplies the value.
Active degrees of freedom
3DoF
66 robot hands state degrees of freedom
65 state a higher figure, 0 a lower one.
Notes
Prensilia offers mechanical interfaces on request: “Several mechanical interfaces are available on request (for robot arms from UR, FRANKA, KUKA, as well as QDW from Ottobock).”
The product page gives a maximum size of 140 x 135 x 190 mm and a closing time of 0.4 s; the middle, ring and little fingers are coupled.
The research user manual describes the hand as a prototype and says “Thanks for acquiring this prototype!” and “The prototype should be used and experimented for research only in laboratory.”
The datasheet adds that the hand is also available with the mechanical interface of Mia Hand Industrial (ISO 9409-1-50-4-M6) and Mia Hand Prosthesis (EQD).
Sources
One line per source, not per figure: a source has one retrieval date.
- Aprensilia.com/mia-hand-research/Main source. Retrieved 4 November 2026
- Bprensilia.com/wp-content/uploads/2026/05/260324_SERIAL_UserManual_MK2_v1-0.pdfSecondary. Retrieved 4 November 2026